
In the realm of advanced technology, particularly within autonomous systems and artificial intelligence, the concept of “ruminating thoughts” takes on a unique, metaphorical interpretation. Far from its psychological origin, this term can describe a state where an AI system or autonomous drone process becomes caught in a repetitive, often unproductive computational loop. It signifies an algorithm or decision-making framework that continuously re-evaluates the same data, re-executes redundant operations, or persists in a localized, sub-optimal state, failing to progress towards a more efficient or desired outcome. This algorithmic “rumination” can manifest in various forms across drone operation, flight technology, and advanced sensing, presenting significant challenges to system efficiency, autonomy, and overall performance. Understanding and mitigating these computational dead-ends are critical for the advancement of truly intelligent and adaptive robotic platforms.
Repetitive Processing in Autonomous Flight Systems
Autonomous flight systems are designed to navigate complex environments, perform intricate maneuvers, and execute missions with minimal human intervention. However, the sophisticated algorithms governing these systems can, under certain conditions, exhibit patterns akin to “ruminating thoughts.” This typically occurs when a drone’s navigation or control system becomes ensnared in a repetitive evaluation cycle, constantly re-assessing the same limited set of options without convergence towards an optimal or novel solution.
Consider a drone tasked with navigating through a dense forest using real-time obstacle avoidance. An algorithm prone to “rumination” might repeatedly detect and re-evaluate the same tree trunk or branch, leading to a series of micro-adjustments that keep the drone oscillating in place rather than finding a clear path forward. This isn’t due to a physical inability to move but rather an algorithmic stagnation, where the processing loop consistently prioritizes immediate, localized corrections over a broader, strategic path planning. Such a system might, for instance, be programmed with a high penalty for collision and a lower priority for forward progress, causing it to perpetually prioritize avoidance over advancement, even when a viable, albeit slightly riskier, route exists. The drone effectively becomes “stuck in thought,” unable to break free from its immediate sensory inputs and process information for a more global objective.
Persistent Error States and Navigation Loops
Persistent error states are another manifestation of algorithmic rumination within flight technology. Imagine a drone operating in an environment with GPS signal degradation or intermittent sensor interference. A robust system would adapt, perhaps switching to alternative navigation methods or adjusting its confidence in position estimates. A “ruminating” system, however, might continuously attempt to reconcile conflicting or unreliable GPS data, leading to repeated, minor positional corrections that fail to stabilize its flight path. It keeps “thinking” about the same erroneous data, leading to a persistent wobble or drift, consuming energy and time without achieving stable flight.
This can be particularly problematic in dynamic environments where conditions change rapidly. A system that persistently re-evaluates outdated or noisy information risks falling behind real-time requirements, leading to predictable and inefficient flight paths. The key challenge lies in designing decision-making frameworks that can recognize such unproductive loops and implement strategies to break free, such as activating alternative sensor fusion methods, increasing the threshold for minor adjustments, or initiating a wider search pattern for clearer navigation cues.
Algorithmic Stagnation in AI Follow Mode
AI follow mode is a cornerstone of advanced drone functionality, allowing systems to autonomously track a moving subject. When improperly optimized or facing specific environmental challenges, even these sophisticated tracking algorithms can exhibit signs of “ruminating thoughts,” manifesting as algorithmic stagnation. This typically involves the drone’s AI making repeated, unnecessary, or overly sensitive adjustments to maintain tracking, rather than predicting and smoothly anticipating the subject’s movement.
For instance, an AI follow mode might continuously over-correct for minute deviations in a subject’s path. If the subject subtly shifts their weight, causing a tiny tremor in their movement, a “ruminating” tracking algorithm might react with a series of small, jerky micro-adjustments that disrupt the smoothness of the recording or flight path. Instead of filtering out noise and focusing on the overall trajectory, the AI becomes fixated on every micro-data point, repeatedly re-evaluating and correcting for trivial fluctuations. This “overthinking” leads to an inefficient and less cinematic performance, consuming more power and placing unnecessary stress on the drone’s motors and gimbals.
The “Overthinking” AI in Predictive Tracking
The essence of effective AI follow mode lies in its ability to predict a subject’s future position based on past and current movement data. An “overthinking” AI, however, can get bogged down in the minutiae of real-time data, hindering its predictive capabilities. Rather than abstracting the subject’s general velocity and direction to anticipate their next move, a ruminating algorithm might constantly re-evaluate short-term, granular data segments. This prevents it from forming a cohesive, longer-term predictive model, leading to reactive rather than proactive tracking.
Such an AI struggles to establish a stable “mental model” of the subject’s motion. Every new data frame prompts a fresh, detailed re-calculation of the immediate next step, rather than an update to an overarching prediction. This creates a cycle where the drone is always catching up, always making small, repetitive corrections, instead of flowing seamlessly with the subject. Mitigating this requires more robust Kalman filters, advanced machine learning models trained on diverse motion patterns, and decision-making processes that can intelligently weigh the significance of short-term data against long-term trend predictions.
Data Processing Loops in Mapping and Remote Sensing
Mapping and remote sensing applications, which involve the collection and analysis of vast datasets from aerial platforms, are also susceptible to forms of “ruminating thoughts” within their data processing pipelines. Here, rumination manifests as inefficient data analysis cycles, where systems repeatedly process or re-evaluate the same information without generating novel insights or optimizing output.
Consider a drone-based remote sensing system tasked with monitoring agricultural health over large areas. A ruminating data processing pipeline might continuously re-segment or re-classify the same image tiles, perhaps due to ambiguous boundary conditions or subtle variations in spectral data. Instead of consolidating its findings and moving on, the system gets stuck in a loop of re-analysis, expending computational resources to re-confirm already established conclusions or to resolve minor, non-critical discrepancies. This can significantly slow down the generation of crucial insights, such as identifying areas of pest infestation or nutrient deficiency.
Inefficient Data Aggregation and Analysis
Inefficient data aggregation is another critical area where rumination can occur. Systems that continuously collect and re-process redundant information without effective synthesis can become overwhelmed. For example, if a drone repeatedly captures overlapping imagery of the same area but the stitching or mosaicking algorithm struggles with slight misalignments, it might enter a repetitive cycle of attempting to correct these errors. Each attempt consumes resources, and if the underlying problem isn’t addressed (e.g., better GPS precision, more stable flight), the system merely re-engages in the same, fruitless reprocessing.
Furthermore, in complex data analysis, such as identifying changes over time, a ruminating system might struggle to differentiate between noise and significant shifts. It could repeatedly flag minor environmental fluctuations as potential changes, triggering a cycle of re-evaluation that ultimately wastes computational power on inconsequential data points. The challenge here is to develop intelligent filtering mechanisms and hierarchical analysis frameworks that can prioritize data processing, identify true anomalies, and synthesize information efficiently, breaking the cycle of micro-analysis without progression.
Breaking the Cycle: Innovation in AI Architectures
Preventing and overcoming these forms of algorithmic “rumination” in drones and autonomous systems is a central focus of innovation in AI architectures. The goal is to design systems that are not only capable of complex tasks but also possess the intelligence to recognize and escape unproductive computational loops, ensuring efficient and effective operation.
Predictive Modeling and Reinforcement Learning
Advanced predictive modeling is crucial for moving beyond reactive “rumination.” Instead of constantly adjusting to current data, predictive models allow systems to anticipate future states and actions, enabling smoother, more proactive responses. In autonomous flight, this means predicting environmental changes or subject movements to plan optimal trajectories in advance, rather than just reacting to immediate obstacles. Reinforcement learning (RL) further enhances this by training AI agents to learn optimal behaviors through trial and error, enabling them to discover and prioritize efficient paths and strategies that avoid repetitive, unproductive actions. RL systems can learn to identify when an action sequence is leading to stagnation and autonomously explore alternative approaches.
Meta-Learning and Adaptive Control
Meta-learning, or “learning to learn,” offers a promising avenue for breaking ruminative cycles. A meta-learning system can adapt its own learning algorithms and strategies based on performance, allowing it to quickly identify and correct inefficient processing patterns. For example, if an AI follow mode repeatedly over-corrects, a meta-learning layer could dynamically adjust the sensitivity of its tracking parameters or switch to a different predictive model. Similarly, adaptive control systems can dynamically modify their parameters based on real-time performance, ensuring that drone flight control remains stable and efficient even under variable conditions, preventing the system from getting stuck in a single, sub-optimal control strategy.

Robust Error Handling and Self-Correction
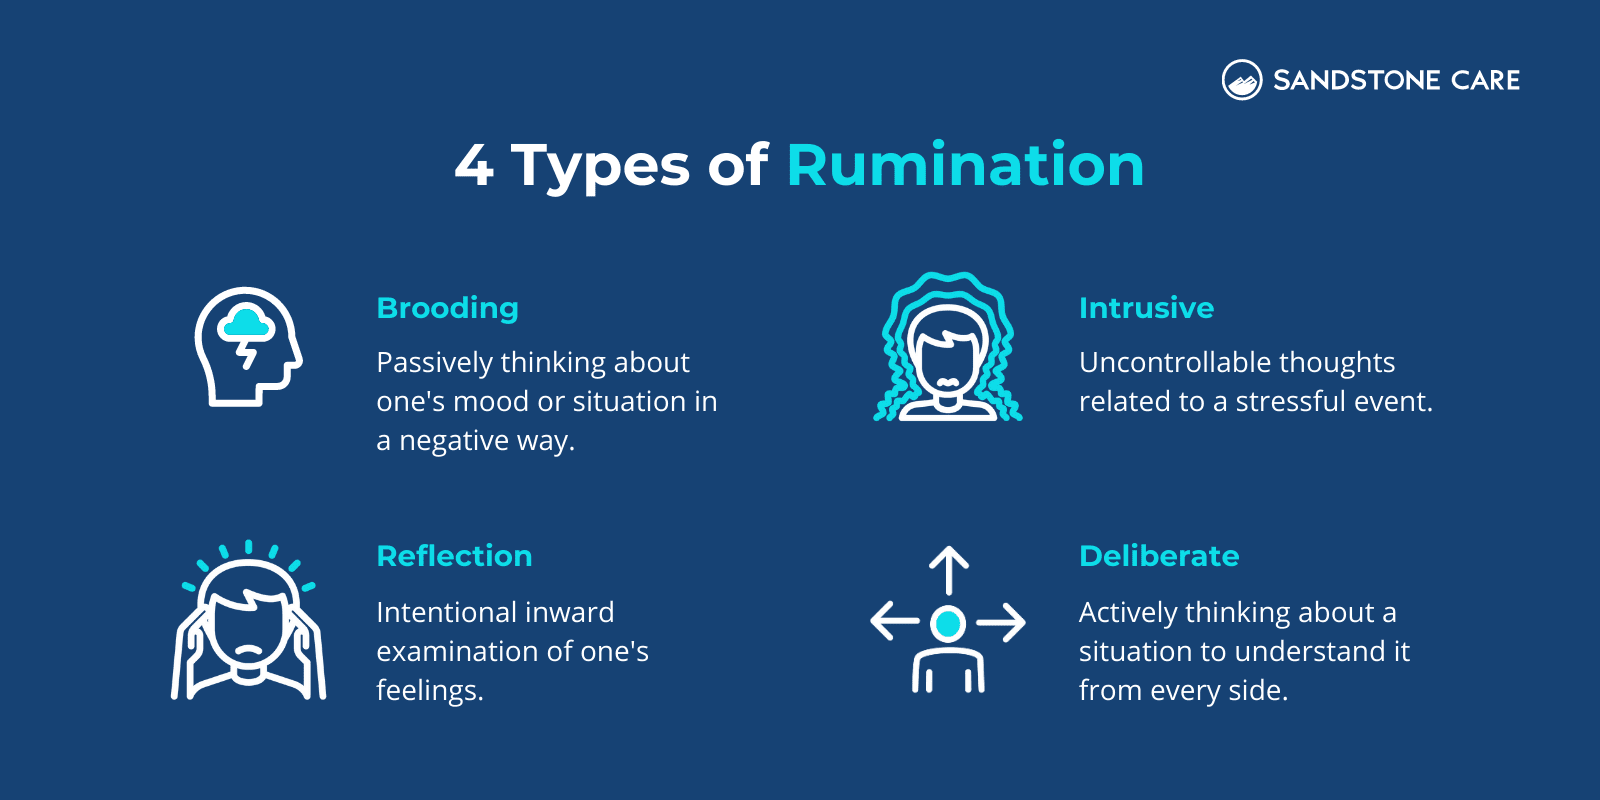
Finally, robust error handling and self-correction mechanisms are paramount. Systems must be designed with the capability to detect persistent error states or algorithmic stagnation and then initiate corrective actions. This could involve triggering a reset of certain processing modules, engaging alternative algorithms, or requesting human oversight. The ability for an autonomous system to “reflect” on its own performance and identify when it is operating sub-optimally—analogous to a human recognizing ruminating thoughts—is essential for truly intelligent and resilient drone technology. By continuously improving these architectures, we can ensure that drones and AI systems operate with maximum efficiency, agility, and cognitive fluency, free from the burden of unproductive “ruminating thoughts.”