
In the rapidly evolving fields of drone technology, particularly within mapping and remote sensing, the ability to collect, process, and analyze vast quantities of data is paramount. However, resources such as flight time, battery life, data storage, and computational power are often finite. This is where the strategic methodology of probability sampling becomes indispensable. Far from being a mere academic exercise, probability sampling offers a robust framework for making statistically sound inferences from drone-collected data, ensuring that the insights derived are both accurate and representative, even when complete coverage is impractical or impossible.
The Foundation of Data-Driven Drone Operations
Probability sampling is a fundamental statistical technique where every element within a defined population has a known, non-zero chance of being selected for study. This principle stands in stark contrast to non-probability sampling methods, where selection is based on convenience, judgment, or other non-random criteria, often leading to biased and non-generalizable results. For drone operations, the “population” could be an expansive agricultural field, a vast forest canopy, an intricate urban landscape, or a lengthy stretch of infrastructure. The “elements” might be individual plants, specific ground pixels, sections of a river, or discrete components of a power line network.
The core advantage of probability sampling lies in its ability to quantify the margin of error and provide a statistical confidence level for the conclusions drawn from the sample. This is crucial for applications such as environmental monitoring, precision agriculture, infrastructure inspection, and urban planning, where decisions are often based on the data gathered. Without a scientifically rigorous sampling approach, the risk of misinterpretation or drawing inaccurate conclusions from drone surveys significantly increases, potentially leading to costly errors or misguided policies.
Why Probability Sampling Matters in Drone Tech
The sheer scale of data that drones can acquire through mapping and remote sensing presents both an opportunity and a challenge. While a drone can cover significant ground and collect high-resolution imagery, multispectral data, or LiDAR scans, processing every single byte of data from an extensive area can be computationally intensive and time-consuming. Furthermore, conducting an exhaustive flight over every square inch of a vast region might be limited by battery capacity, regulatory restrictions on flight duration, or simply the practicalities of field operations.
Probability sampling offers a strategic solution to these constraints. By carefully selecting representative portions of the survey area, drone operators and data analysts can glean accurate insights about the entire population without the need for 100% coverage. This efficiency not only saves time and resources but also enhances the feasibility of large-scale, repetitive monitoring tasks. For instance, in precision agriculture, sampling specific zones of a large farm can provide sufficient data to infer the health status of an entire crop, guiding targeted irrigation or fertilization efforts. In environmental science, analyzing samples of forest health imagery can reveal trends across an entire ecosystem. The adoption of probability sampling transforms drone data collection from an exhaustive task into an intelligent, targeted operation, enhancing the reliability of autonomous flight missions focused on mapping and remote sensing.
Key Probability Sampling Techniques for Drone-Based Data Collection
Adapting traditional probability sampling methods for drone applications requires innovative thinking about flight path planning, sensor deployment, and data management. Each method offers unique advantages depending on the nature of the terrain, the characteristics of the population being studied, and the specific research objectives.
Simple Random Sampling (SRS) in the Sky
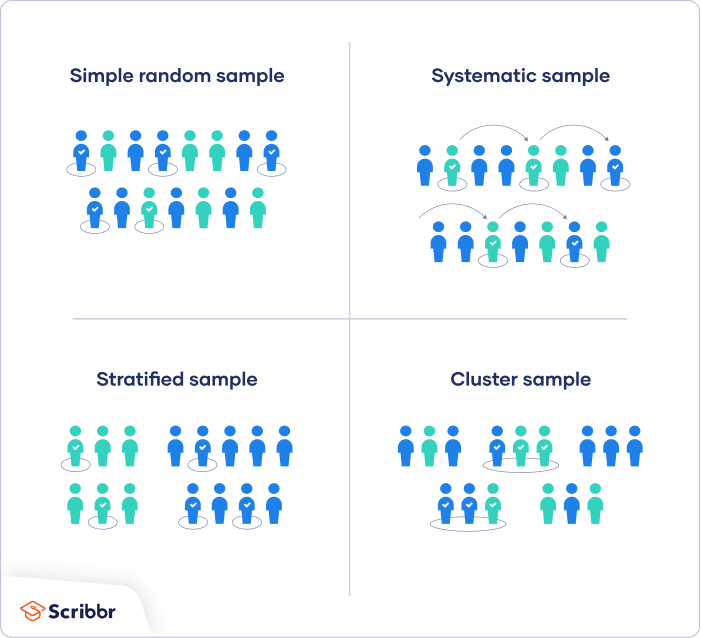
Simple Random Sampling is the most straightforward probability sampling method. In the context of drones, this would involve defining a complete list of potential sampling units (e.g., grid cells covering the survey area, specific waypoints, or even individual pixels in a potential high-resolution map) and then selecting a subset of these units entirely at random. Every unit has an equal chance of being chosen, eliminating subjective bias.
For drone operations, SRS might translate to randomly generating a set of GPS coordinates within a defined area, which the drone would then navigate to and capture data (e.g., high-resolution photos, thermal images, or multispectral scans). This method is particularly useful when the population is relatively homogeneous, such as a uniform forest canopy or a single large crop field, and there’s no prior knowledge suggesting specific variations across the landscape. Challenges include ensuring true randomness in flight planning software and the potential for a randomly generated flight path to be inefficient in terms of battery usage, as the drone might have to traverse large distances between sampling points. However, the unbiased nature of SRS makes it a robust choice for preliminary surveys or baseline data collection.
Stratified Sampling for Diverse Environments
When a survey area is heterogeneous, meaning it comprises distinct sub-regions with different characteristics (e.g., varied terrain, different land uses, varying vegetation types), Stratified Sampling becomes highly advantageous. This method involves dividing the entire population into homogeneous subgroups, or “strata,” and then applying a simple random or systematic sampling technique within each stratum.
Consider using drones for environmental monitoring of a watershed that includes urban areas, agricultural land, forests, and wetlands. Instead of random sampling across the entire, diverse area, a stratified approach would involve delineating these distinct land cover types as strata. Drones could then be programmed to collect a proportional or equal number of samples (e.g., specific flight patterns, image capture points) from each stratum. This ensures that each important sub-population is adequately represented in the final data set, preventing overrepresentation of common features and underrepresentation of rare but significant ones. For remote sensing applications, this method significantly enhances the accuracy of models that classify land use, assess biodiversity, or monitor changes across diverse landscapes, as it guarantees that the variability within each segment is captured.
Systematic Sampling: Structured Efficiency
Systematic Sampling involves selecting sampling units at regular, predefined intervals from an ordered list or along a determined path. This method is often preferred in drone-based mapping and remote sensing due to its practical efficiency and ease of implementation in automated flight planning.
A classic application involves programming a drone to fly a series of parallel transects across a survey area, capturing imagery or sensor data at fixed intervals along each transect. For example, a drone mapping a large agricultural field might be programmed to fly lines 20 meters apart, taking an image every 10 meters along each line. This creates a highly structured and repeatable data collection pattern. Systematic sampling is efficient for generating comprehensive coverage with a high degree of precision, especially for tasks like volumetric measurements (e.g., stockpile assessment), change detection over time, or detailed topographic mapping. While it shares some characteristics with comprehensive mapping, the key difference in a sampling context is that the intervals are chosen such that only a sample of the total area is covered, intended to be representative, rather than attempting 100% overlap or dense coverage typically associated with full mapping missions. The periodicity of the sampling ensures a uniform spread across the target area, making it a reliable choice for remote sensing data acquisition.
Cluster Sampling for Broad Area Assessments
Cluster Sampling is a method where the population is divided into naturally occurring groups or “clusters,” and then a random sample of these clusters is selected. All units within the chosen clusters are then surveyed. This technique is particularly useful when the population is widely dispersed or when it is logistically challenging or expensive to survey individual units across a vast area.
In drone applications, clusters might be defined as distinct geographical areas, such as 1km x 1km grid squares within a large national park, specific blocks in an urban environment, or isolated habitat patches for wildlife monitoring. Instead of flying the drone across the entire national park to capture individual images of wildlife or vegetation, a random selection of these 1km x 1km grid squares (clusters) would be made. The drone would then conduct a comprehensive survey (e.g., high-resolution mapping, thermal imaging for animal detection) within only these selected clusters. This method significantly reduces the total flight time and data volume, making it an efficient choice for large-scale, extensive surveys where precise, granular data is required only within specific, representative sub-regions. It is especially valuable for remote sensing projects aiming to assess broad environmental conditions or track migratory patterns across vast, heterogeneous regions.
Implementing Probability Sampling with Drone Technology
Integrating probability sampling into drone operations goes beyond theoretical statistical concepts; it demands sophisticated pre-flight planning, robust data acquisition strategies, and advanced post-processing capabilities.
Pre-Flight Planning and GIS Integration
The cornerstone of effective probability sampling with drones is meticulous pre-flight planning, heavily leveraging Geographic Information Systems (GIS) software. GIS platforms allow operators to define the target population, delineate survey boundaries, create sampling frames (e.g., a grid of potential flight paths or individual points), and apply specific sampling designs. For stratified sampling, GIS is used to accurately segment the area into relevant strata based on land cover, elevation, or other relevant features. Automated mission planning software can then integrate these sampling strategies, generating optimized flight paths that precisely adhere to the chosen sampling points or areas. This integration ensures that the drone autonomously navigates to the pre-determined sample locations, captures data with consistent parameters (e.g., altitude, camera angle, overlap), and minimizes human error in the field. The ability to program a drone with complex, scientifically designed flight missions is a key advancement in autonomous flight for mapping and remote sensing.
Data Acquisition and Processing Considerations
Once the sampling strategy is in place, the drone’s role shifts to precise data acquisition. This requires consistent sensor calibration and strict adherence to flight parameters across all sampled areas to maintain data quality and comparability. Geotagging of all acquired data (images, LiDAR points, multispectral readings) is absolutely critical, allowing for accurate spatial analysis and linking sampled data back to its exact location within the larger population.
Post-processing involves not only stitching together imagery to create orthomosaics or generating point clouds but also applying statistical methodologies to the sampled data. This often includes scaling up findings from the sample to infer characteristics of the entire population, calculating confidence intervals, and performing hypothesis testing. Advanced analytical tools, including AI and machine learning algorithms, are increasingly being used to analyze sampled data, identify patterns, classify features, or detect anomalies within the sampled segments, and then extrapolate these insights across the broader survey area. For instance, an AI model trained on a sample of crop imagery could accurately estimate disease prevalence across an entire farm.
Challenges and Future Directions
Implementing probability sampling with drones faces several practical challenges. Battery life remains a primary constraint, potentially limiting the number of samples or the geographical spread of random samples. Dynamic environmental conditions (e.g., wind, changing light) can affect data consistency across sampled segments. Furthermore, developing robust, user-friendly software that seamlessly integrates complex sampling designs with drone flight controllers is an ongoing area of innovation.
Future directions point towards more adaptive and intelligent sampling. Drones equipped with real-time processing capabilities could potentially adjust their sampling strategy on the fly, for instance, increasing sampling density in areas where initial data suggests higher variability or identifies “hot spots” of interest. This concept, often termed “adaptive sampling,” could significantly enhance efficiency and responsiveness. The integration of advanced AI for autonomous decision-making in sampling, coupled with improved drone endurance and sensor capabilities, promises to make probability sampling an even more powerful tool for the next generation of remote sensing and mapping applications.

The Impact on Remote Sensing and Mapping Accuracy
The systematic integration of probability sampling into drone-based remote sensing and mapping workflows fundamentally transforms the accuracy and reliability of the derived insights. By providing a statistically robust framework, probability sampling directly addresses several critical aspects of data quality and utility.
Firstly, it significantly reduces the risk of sampling bias. Unlike convenience or judgmental sampling, where human discretion can inadvertently lead to unrepresentative data, probability sampling ensures that every part of the population has a quantifiable chance of inclusion. This impartiality is crucial for generating data that can be generalized with known levels of confidence to the entire area of interest, whether it’s for agricultural yield estimation, environmental impact assessments, or urban change detection.
Secondly, probability sampling allows for the calculation of statistical error margins and confidence intervals. This quantitative measure of uncertainty is vital for decision-makers, as it provides a clear understanding of the reliability of the drone-derived findings. Knowing that a conclusion is, for example, 95% confident within a certain margin of error, lends immense credibility to the data, supporting more informed and robust decisions in areas like infrastructure planning, disaster response, and natural resource management.
Finally, the efficiency gained through probability sampling makes complex, large-scale remote sensing projects more feasible and cost-effective. By obtaining reliable data from a representative subset, organizations can minimize flight time, reduce data storage and processing burdens, and accelerate the analytical phase. This efficiency does not come at the expense of accuracy; rather, it optimizes resource allocation to achieve statistically valid results that might otherwise be prohibitively expensive or time-consuming to obtain through exhaustive full-coverage surveys. In essence, probability sampling elevates drone technology from a powerful data acquisition tool to a scientifically rigorous platform for generating actionable, data-driven intelligence across diverse applications in mapping and remote sensing.