
The Foundation of Flight: Decoding Location Coordinates
In the complex tapestry of modern flight technology, understanding and precisely determining location coordinates is not merely a convenience but a fundamental imperative. For Unmanned Aerial Vehicles (UAVs), commonly known as drones, accurate positional awareness is the bedrock upon which all advanced operations, from stable hovering to complex autonomous missions, are built. Without a precise answer to “what are my location coordinates,” a drone would be little more than an unguided object, incapable of executing its myriad tasks with reliability and safety.
Defining Location Coordinates: Latitude, Longitude, and Altitude
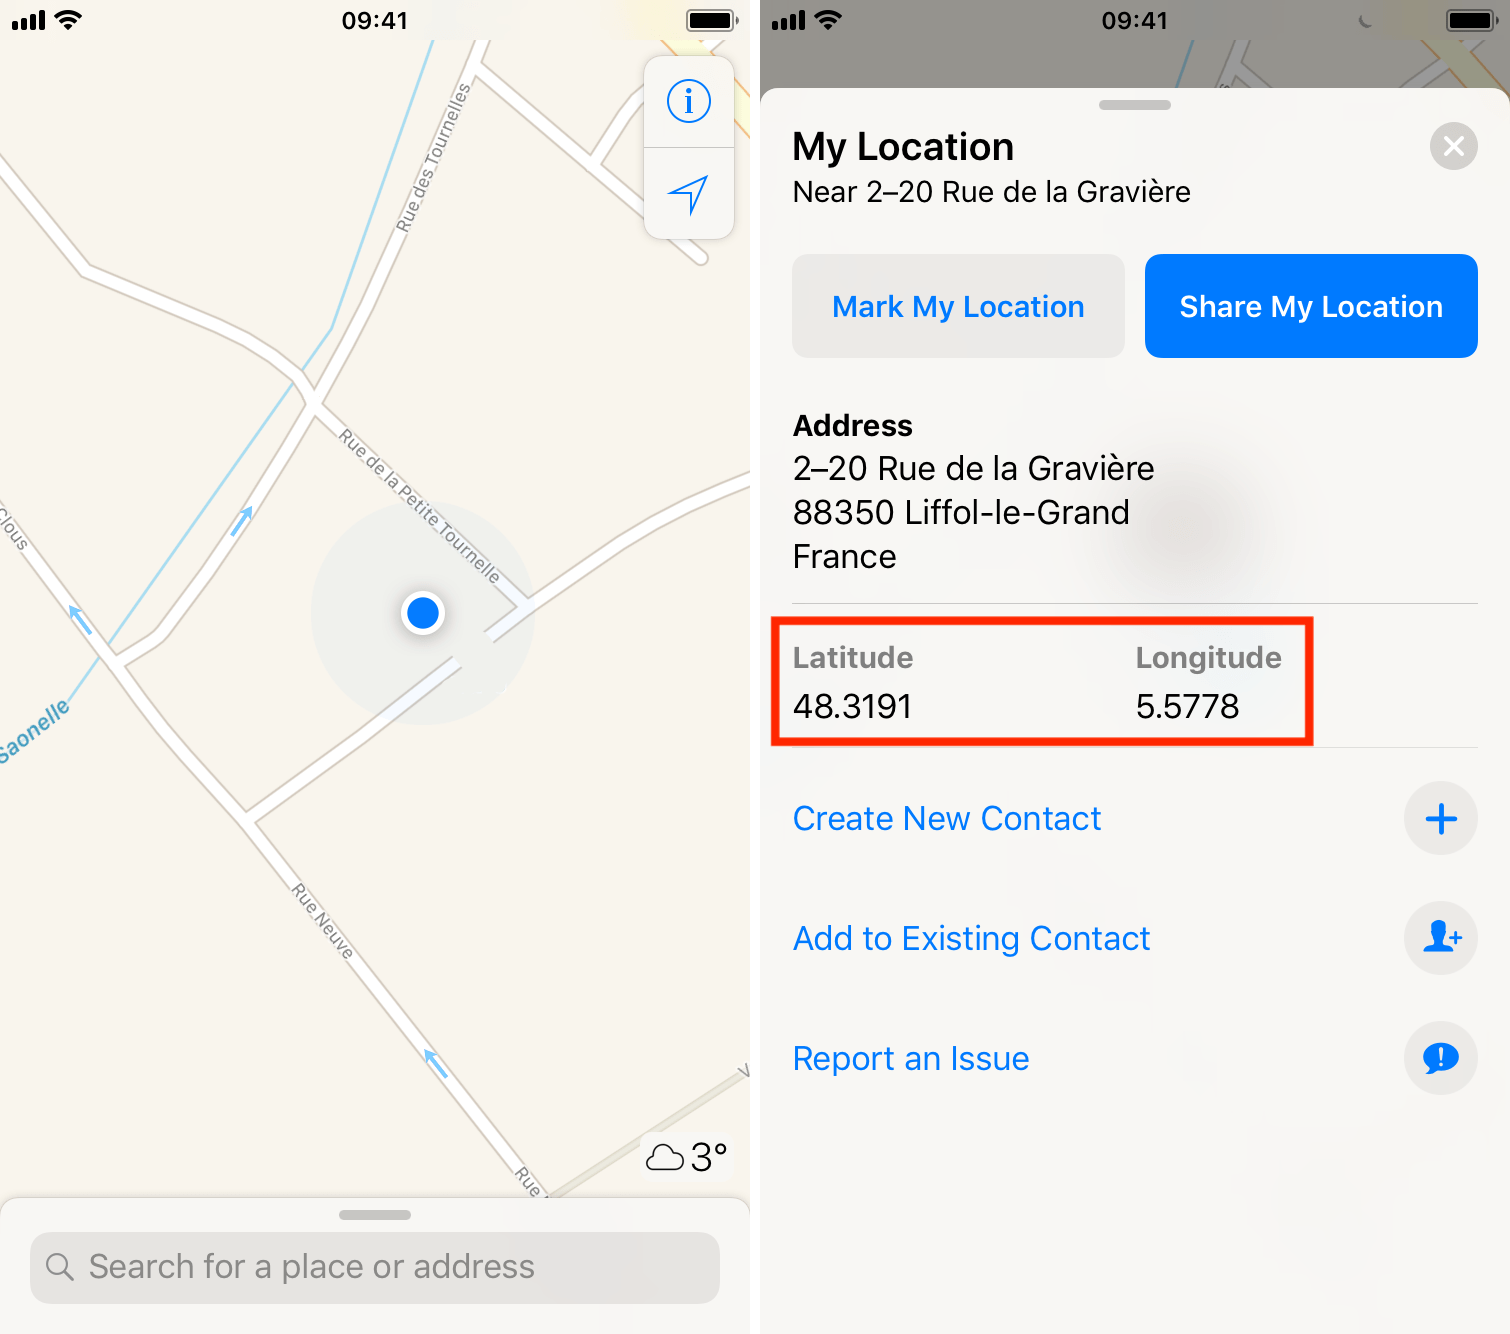
At its core, a location coordinate system provides a universal language for pinpointing any spot on Earth. The most widely adopted system is based on latitude and longitude. Latitude measures a position’s distance north or south of the Equator, expressed in degrees from 0° (Equator) to 90° (poles). Longitude measures a position’s distance east or west of the Prime Meridian (which passes through Greenwich, London), expressed in degrees from 0° to 180°. These values can be represented in degrees, minutes, and seconds (DMS) or, more commonly in digital systems, as decimal degrees. For drones, especially those performing precise mapping or surveying, these decimal degree values often require many significant figures to achieve the necessary accuracy.
Beyond horizontal position, altitude completes the three-dimensional picture. While often simply measured as height above sea level (MSL – Mean Sea Level, or orthometric height), drones frequently also rely on ellipsoidal height, which is measured from a mathematical model of the Earth’s surface (the WGS84 ellipsoid). The distinction can be critical for applications requiring extreme vertical precision, such as volumetric calculations in construction or mining. Accurate altitude data, often derived from barometric sensors combined with GPS, is vital for maintaining safe flight envelopes and adhering to regulatory airspace limits.
The Role of Geospatial Systems: WGS84 and Beyond
These coordinates do not exist in a vacuum; they are part of a larger geospatial reference system. The most ubiquitous is the World Geodetic System 1984 (WGS84), which defines the Earth’s shape and gravity field, providing a standardized framework for all GPS measurements. Almost all modern navigation systems, including those aboard drones, reference WGS84. The ability of a drone to consistently and accurately communicate its position within this global standard is paramount for interoperability, mission planning, and data integration. The precision requirements for drone operations have steadily increased, moving from meters to centimeters, particularly as UAVs take on roles in highly sensitive industries like infrastructure inspection, agriculture, and construction. This demand for hyper-accuracy drives continuous innovation in the underlying flight technology, ensuring that “what are my location coordinates” can be answered with unwavering exactitude.
GPS: The Global Standard for Positional Awareness
The Global Positioning System (GPS) is arguably the most transformative flight technology of the last few decades, enabling capabilities that were once confined to science fiction. For drones, GPS is the primary technology used to answer “what are my location coordinates,” providing a global, continuous, and highly reliable source of positioning information. Its integration has revolutionized navigation, allowing drones to maintain stable flight, execute complex routes, and record precise geospatial data.
How GPS Works: Satellite Triangulation and Signal Reception
The fundamental principle of GPS involves a constellation of satellites orbiting Earth, each continuously broadcasting radio signals containing precise timing and orbital data. A drone’s GPS receiver passively listens for these signals. When a receiver picks up signals from at least four satellites, it can calculate its exact position through a process known as trilateration. The receiver determines its distance from each satellite by measuring the time delay between the signal’s transmission and reception. Knowing the precise location of each satellite (from their orbital data) and its distance to them, the receiver can geometrically determine its own three-dimensional position on Earth. This intricate dance of signals and calculations occurs continuously, providing real-time location updates, typically several times per second.
GPS Accuracy and Limitations
While remarkably effective, standard consumer-grade GPS receivers have inherent limitations in accuracy, typically providing positions within a few meters. Several factors contribute to these inaccuracies:
- Atmospheric Delays: Signals can slow down as they pass through the Earth’s ionosphere and troposphere, causing slight errors in distance calculations.
- Satellite Geometry (Dilution of Precision – DOP): The spatial arrangement of visible satellites affects accuracy. A wide spread of satellites provides better geometry and more precise results than a cluster.
- Multipath Errors: Signals can bounce off nearby objects (buildings, terrain) before reaching the receiver, creating an erroneous path length. This is particularly problematic in urban environments or rugged terrain.
- Receiver Noise: Internal electronic noise within the GPS receiver can slightly distort signal measurements.
- Signal Availability: Obstructions like dense foliage or urban canyons can block satellite signals, leading to signal loss or reduced accuracy.
These limitations, while acceptable for general navigation, often fall short of the precision required for professional drone applications such as high-accuracy mapping, precise agricultural spraying, or construction progress monitoring.
Enhancing GPS Precision: RTK and PPK
To overcome standard GPS limitations and achieve centimeter-level accuracy, two advanced techniques are widely employed in drone flight technology: Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK). Both methods rely on using a stationary ground-based receiver, known as a base station, at a precisely known location.
-
Real-Time Kinematic (RTK): In an RTK system, the base station continuously observes the same satellite signals as the drone’s “rover” receiver. It calculates the errors in the satellite signals and immediately transmits these correction data to the drone via a radio link. The drone’s receiver then applies these corrections in real-time, drastically improving its positional accuracy to within 1-2 centimeters. This real-time capability is invaluable for applications requiring immediate precise positioning, such as dynamic flight paths or certain live data collection scenarios.
-
Post-Processed Kinematic (PPK): PPK operates on a similar principle but performs the correction process after the flight. Both the drone and the base station record raw satellite observation data during the mission. After landing, these data logs are downloaded and processed together using specialized software. This post-processing approach can often yield slightly better accuracy than RTK because it has the advantage of backward and forward processing of data, and it is less susceptible to temporary radio link disruptions during flight. PPK is particularly favored for photogrammetry and mapping applications where the ultimate goal is the highest possible accuracy for geotagged images.
Both RTK and PPK represent critical advancements in flight technology, transforming drones from general aerial platforms into highly precise instruments capable of delivering survey-grade data.
Beyond GPS: The Synergistic Power of Integrated Navigation Systems
While GPS is indispensable, a drone’s ability to maintain stable flight and navigate accurately, especially in challenging environments, relies on a sophisticated fusion of multiple sensors. This integrated approach, often referred to as sensor fusion, provides redundancy, enhances robustness, and ensures continuous positional awareness even when GPS signals are weak or unavailable. This synergistic interplay between various navigation technologies is a hallmark of advanced drone flight systems.
Inertial Measurement Units (IMUs): The Drone’s Inner Ear
Central to integrated navigation are Inertial Measurement Units (IMUs). An IMU is a micro-electronic device that measures a drone’s specific force, angular rate, and often magnetic field, using a combination of three key sensors:
- Accelerometers: Measure linear acceleration along three axes (X, Y, Z), indicating changes in speed and direction.
- Gyroscopes: Measure angular velocity (rotational speed) along three axes, providing information about the drone’s pitch, roll, and yaw rates.
- Magnetometers (Electronic Compass): Measure the Earth’s magnetic field, providing an absolute heading reference, similar to a compass.
By continuously processing data from these sensors, the IMU can estimate the drone’s orientation (attitude), velocity, and relative position through a process called dead reckoning. While highly accurate over short periods, IMU data suffers from cumulative errors (drift) over time because small measurement inaccuracies are integrated repeatedly. This makes IMUs excellent for high-frequency short-term measurements and stabilization but poor for long-term absolute positioning without external correction.
Sensor Fusion: Kalman Filtering and Optimal Estimation
The true power of integrated navigation lies in sensor fusion, where data from multiple disparate sensors are intelligently combined to produce a more accurate and reliable estimate of the drone’s state (position, velocity, orientation) than any single sensor could provide alone. The most common technique for this fusion is the Kalman filter or its variations.
A Kalman filter is a sophisticated mathematical algorithm that takes noisy and incomplete sensor measurements and produces an optimal estimate of the system’s state. It predicts the drone’s next state based on previous estimates and IMU data, then corrects this prediction using new, more absolute measurements from sensors like GPS, barometers (for altitude), and sometimes vision systems. This iterative process constantly refines the drone’s understanding of “what are my location coordinates” and its motion.
For example, GPS provides accurate absolute position but at a relatively low update rate and can be noisy. The IMU provides high-frequency, smooth data about relative motion but drifts. Sensor fusion uses the IMU’s high-frequency data to interpolate between GPS fixes and smooth out GPS noise, while GPS corrects the IMU’s drift over time. This creates a robust and continuously accurate navigation solution, enabling stable flight even when GPS signals briefly drop out.
The Importance of Redundancy and Reliability
The integration of multiple navigation systems and sensors is not just about accuracy; it’s also about redundancy and reliability. In critical drone operations, the failure or degradation of a single sensor should not lead to catastrophic loss of control. If GPS signals are lost (e.g., flying under a bridge or indoors), the IMU can continue to provide a navigation solution for a period, allowing the drone to maintain stability or return to an area with better signal reception. Barometers provide an independent altitude measurement, supplementing or backing up GPS altitude. Advanced drones may also incorporate multiple GPS receivers (multi-constellation GNSS) or even multiple IMUs for further redundancy. This multi-layered approach to flight technology ensures that drones can operate safely and effectively across a wider range of environments and conditions, continuously and reliably answering the critical question of their precise location.
Implementing Precision: Coordinates in Advanced Flight Operations
The ability to precisely answer “what are my location coordinates” is not just an academic exercise; it forms the backbone of nearly all advanced capabilities in modern drone flight technology. From automated flight paths to critical safety features, the application of accurate coordinate data translates directly into enhanced performance, efficiency, and operational safety for UAVs.
Autonomous Flight and Waypoint Navigation
One of the most powerful applications of precise location coordinates is autonomous flight, particularly through waypoint navigation. Instead of manually controlling the drone’s every movement, pilots can pre-program a series of geographic coordinates (waypoints) that define a specific flight path. The drone’s flight controller, using its integrated navigation system (GPS, IMU, etc.), then autonomously guides the UAV from one waypoint to the next, precisely maintaining altitude, speed, and heading according to the mission plan.
This capability allows for repeatable missions, critical for applications like surveying, precision agriculture, and infrastructure inspection. A drone can fly the exact same path multiple times over a period, ensuring consistent data collection for change detection or progress monitoring. Advanced waypoint systems also allow for defining parameters at each point, such as camera angle, gimbal pitch, and even specific actions like hovering for a set duration or triggering a sensor. The accuracy of the drone’s ability to reach and hold these coordinates directly impacts the quality and reliability of the data collected during these missions.
Geofencing and Safety Zones
Location coordinates are instrumental in establishing geofences, virtual boundaries that define permissible or prohibited operational areas for a drone. A geofence is essentially a digital perimeter defined by a set of latitude and longitude points. When a drone’s navigation system detects that it is approaching or attempting to cross a geofence boundary, the flight controller can automatically trigger programmed responses.
These responses can include:
- Warning alerts: Notifying the pilot that the drone is nearing a boundary.
- Speed reduction: Slowing the drone as it approaches a limit.
- Automatic return-to-home (RTH): Commanding the drone to return to its takeoff point.
- Hard stop: Preventing the drone from entering a restricted airspace (e.g., near airports, critical infrastructure, or designated no-fly zones).
Geofencing is a critical safety feature, ensuring regulatory compliance and preventing drones from inadvertently entering dangerous or sensitive areas. It enhances flight safety by providing an automated layer of protection, particularly important for new pilots or in complex operational environments. The reliability of geofencing is directly tied to the accuracy of the drone’s real-time coordinate determination.
Return-to-Home (RTH) Functionality
The Return-to-Home (RTH) function is a ubiquitous and vital safety feature in almost all modern drones, made possible by accurate location coordinates. When activated (either manually by the pilot, automatically due to low battery, or upon loss of control signal), the drone’s flight controller commands it to return to its initial takeoff location.
For RTH to function reliably, the drone must precisely record and remember its takeoff coordinates (latitude, longitude, and altitude) upon launch. During an RTH event, the drone ascends to a pre-defined safe altitude, navigates directly back to the stored takeoff coordinates, and then initiates an autonomous landing sequence. This capability is a cornerstone of safe drone operation, mitigating risks associated with unexpected issues during flight and ensuring that the drone can safely recover its position even under adverse conditions. The precision of the RTH landing is directly proportional to the accuracy with which the drone originally recorded its home coordinates and can re-navigate to them.
Navigating Tomorrow: Future Trends in Drone Positioning Technology
The relentless pursuit of greater accuracy, reliability, and autonomy in drone operations continues to drive innovation in positioning and navigation technology. As drones become more integrated into commercial airspace and take on increasingly complex tasks, the ability to pinpoint “what are my location coordinates” with ever-higher precision and robustness is paramount. The future of flight technology for UAVs will see a synergistic blend of enhanced existing systems and the integration of novel sensor modalities.
Visual Positioning Systems (VPS) and Optical Flow
One significant area of development is Visual Positioning Systems (VPS), which leverage onboard cameras to determine a drone’s position and velocity relative to its surroundings. Optical flow sensors, a simpler form of VPS, use a downward-facing camera to track movement across ground textures, providing highly accurate relative velocity estimates, especially useful for precise hovering and slow flight near the ground.
More advanced VPS utilize multiple cameras to create a real-time map of the environment, using algorithms like Visual Simultaneous Localization and Mapping (V-SLAM) to determine the drone’s absolute position within that map. This technology is particularly vital for indoor flight, under bridges, or in dense urban canyons where GPS signals are weak or nonexistent. By comparing live camera feeds to stored maps or creating new ones on the fly, drones can maintain precise positioning without relying on satellite signals, opening up new possibilities for autonomous inspection and navigation in GPS-denied environments.
Emerging Technologies for Enhanced Precision
Beyond optical systems, several other technologies are being explored and integrated to augment traditional navigation methods:
- Ultra-Wideband (UWB): UWB technology uses short, wide-bandwidth radio pulses to measure distance with extremely high precision (centimeter-level) over relatively short ranges. It’s ideal for indoor positioning, swarm drone operations, or highly precise industrial applications where GPS is not suitable. By deploying UWB anchor points, drones can accurately localize themselves within a defined space.
- Lidar (Light Detection and Ranging): While often used for 3D mapping, Lidar sensors can also contribute to navigation. By emitting laser pulses and measuring the time it takes for them to return, Lidar creates a detailed 3D point cloud of the environment. This data can be used for highly accurate obstacle avoidance, terrain-following, and even for localization by matching the real-time point cloud to a pre-existing 3D map.
- Enhanced Inertial Navigation Systems (INS): Advances in MEMS (Micro-Electro-Mechanical Systems) technology are leading to smaller, lighter, and more accurate IMUs. When coupled with advanced filtering algorithms, these INS units can maintain positional accuracy for longer durations even without GPS, providing a more robust backup for critical missions.

GNSS Evolution: Multi-Constellation and Modernized Signals
The GPS system itself is continually evolving, and other Global Navigation Satellite Systems (GNSS) like Russia’s GLONASS, Europe’s Galileo, and China’s BeiDou are expanding their capabilities. Modern drone receivers are increasingly multi-constellation GNSS receivers, meaning they can track signals from multiple satellite systems simultaneously. This significantly increases the number of available satellites, leading to:
- Improved Accuracy: More satellites generally mean better satellite geometry (lower DOP), reducing positional errors.
- Enhanced Availability: The drone is more likely to maintain a strong signal lock, even in challenging environments where some satellites might be obscured.
- Increased Robustness: Redundancy across different constellations provides a buffer against outages or signal degradation from a single system.
Furthermore, GPS and other GNSS systems are deploying modernized signals (e.g., GPS L5). These new signals offer improved accuracy, better resistance to interference, and enhanced reliability. The combination of multi-constellation reception and modernized signals promises to deliver unprecedented levels of global positioning accuracy and integrity for drone flight technology, making the answer to “what are my location coordinates” even more precise and dependable in the years to come.