
In the dynamic world of drone technology and innovation, where autonomous flight, artificial intelligence (AI) follow modes, sophisticated mapping, and remote sensing are rapidly evolving, the underlying principles are often rooted in mathematics. While the immediate focus might be on hardware advancements or groundbreaking software, the efficacy and elegance of these systems frequently hinge on fundamental algebraic concepts. Among these, the understanding of “like terms” stands out as a deceptively simple yet profoundly important cornerstone for efficient algorithmic design and robust system performance.
Like terms are the bedrock of algebraic simplification, allowing engineers and developers to distill complex mathematical expressions into their most manageable forms. In the context of cutting-edge drone technology, this isn’t merely an academic exercise; it directly translates to faster processing, more reliable computations, and ultimately, more intelligent and responsive drones.

The Algebraic Bedrock of Drone Intelligence
At its core, “like terms” is an algebraic concept that helps streamline mathematical expressions. For anyone delving into the algorithms that govern autonomous flight, sensor data interpretation, or AI decision-making in drones, a firm grasp of this principle is indispensable. It dictates how different parts of an equation can be combined, simplifying the mathematical “sentences” that instruct a drone’s every move and analysis.
Understanding Variables, Constants, and Exponents
Before defining like terms, it’s essential to clarify their components: variables, constants, and exponents.
- Variables: These are symbols, usually letters (like
x,y,z, ortfor time), that represent unknown or changing values. In drone technology, variables might represent a drone’s position coordinates (x,y,z), its velocity components (vx,vy,vz), flight duration (t), or sensor readings (e.g.,temp_sensor_A,pressure_B). - Constants: These are fixed numerical values that do not change. Examples include gravity’s acceleration (
9.8 m/s²), the drone’s mass, or a predefined threshold for obstacle detection. In equations, constants appear as plain numbers. - Exponents: An exponent indicates how many times a base number or variable is multiplied by itself. For instance,
x²meansxmultiplied byx. In drone dynamics, exponents frequently appear in equations describing energy, motion, or control response curves, such as1/2 * m * v²for kinetic energy, wherev²denotes velocity squared.
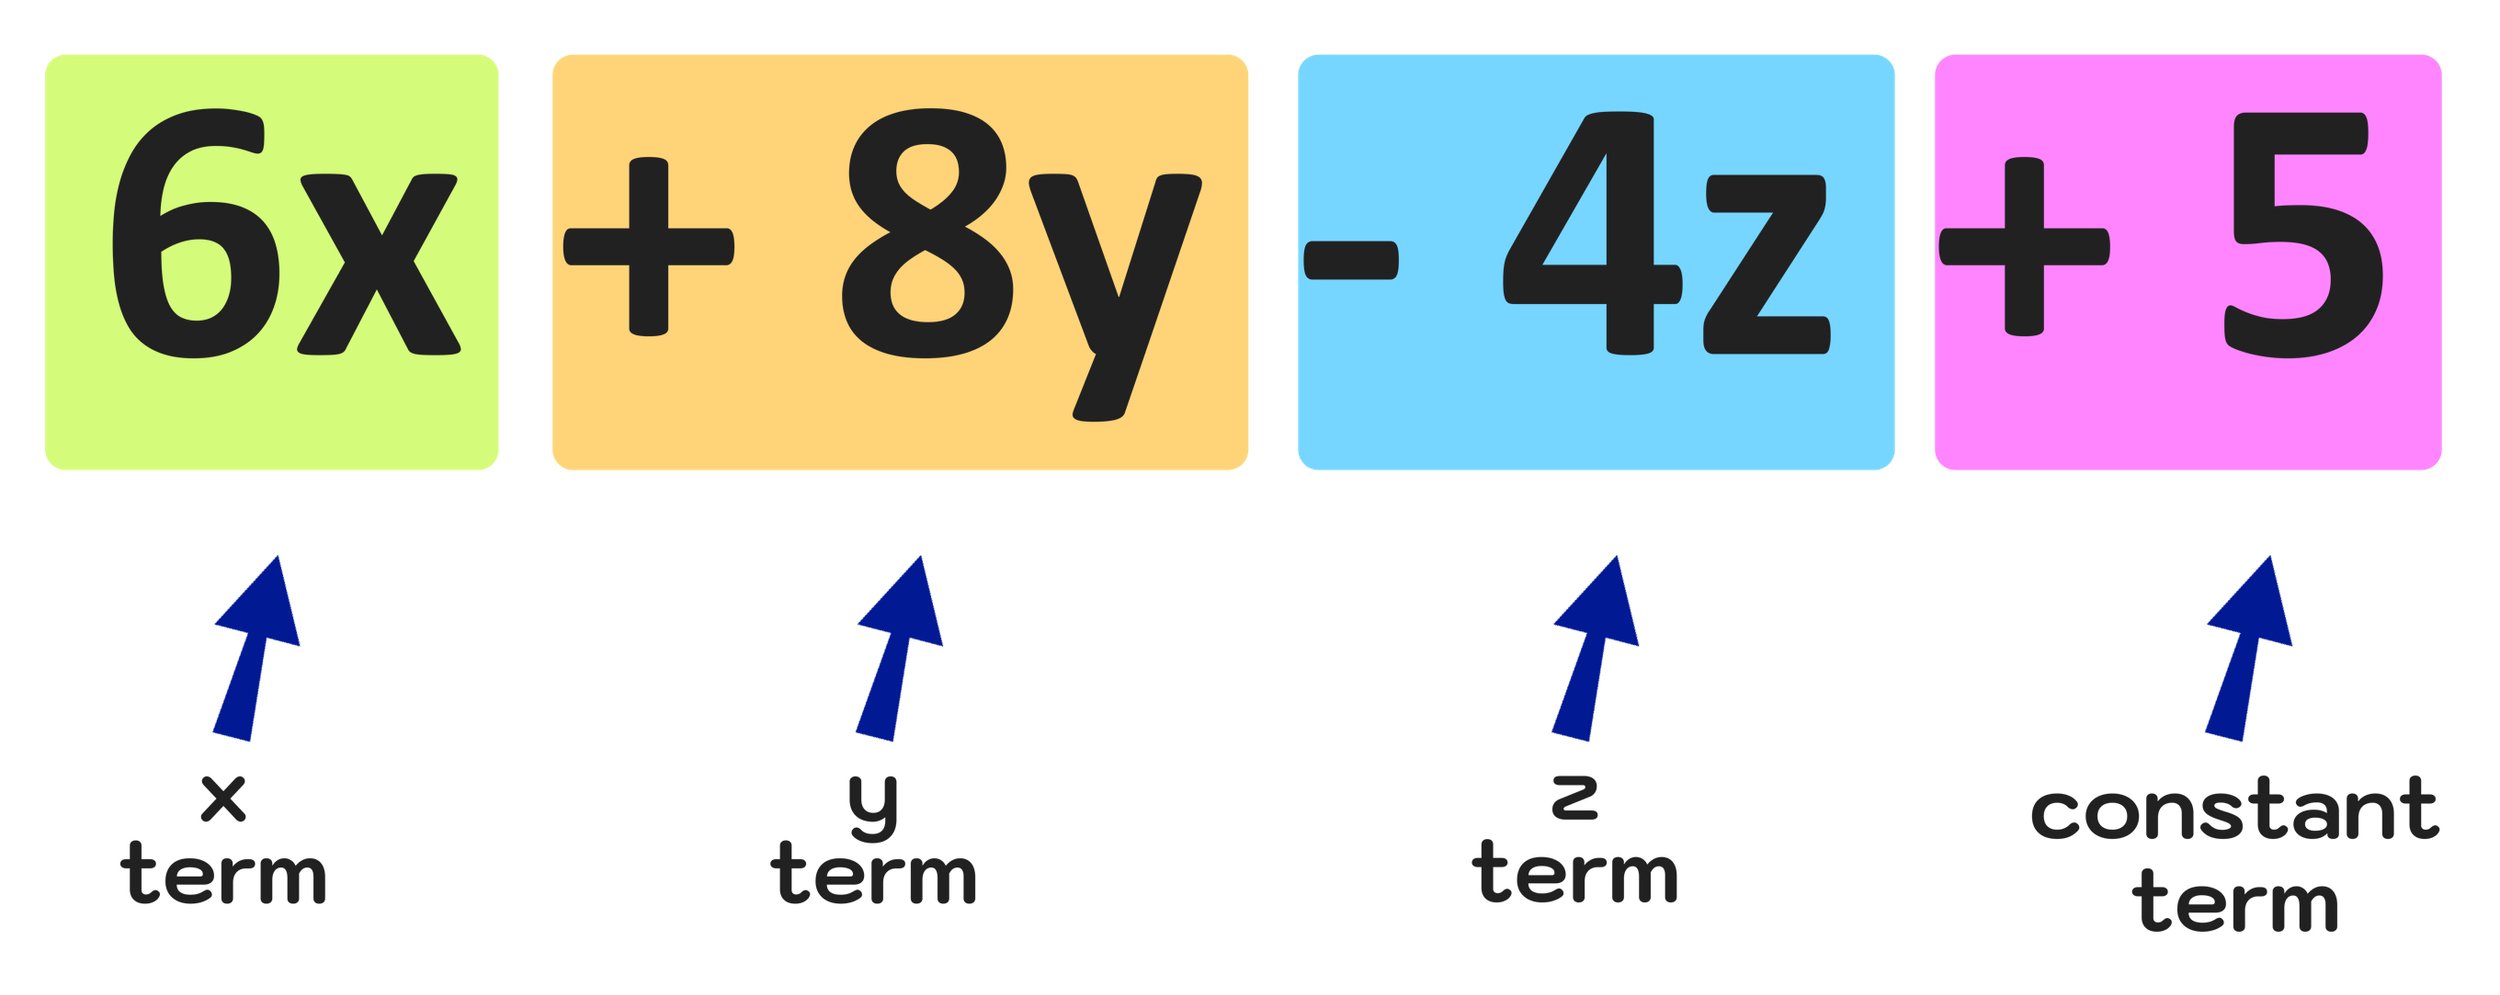
When these elements combine, they form “terms.” A term can be a single number (a constant), a single variable, or a product of numbers and variables with exponents (e.g., 5x, -2y², 7xy, 10).
The Core Principle of Like Terms
Two or more terms are considered “like terms” if and only if they have the exact same variables raised to the exact same powers. The numerical coefficients (the numbers multiplied by the variables) can be different; they are irrelevant to determining if terms are “like.”
Let’s illustrate with examples:
3xand7xare like terms because both have the variablexraised to the power of 1 (which is usually not written). They can be combined:3x + 7x = 10x.5y²and-2y²are like terms because both have the variableyraised to the power of 2. They can be combined:5y² - 2y² = 3y².4xyand-6xyare like terms because both have the variablesxandyeach raised to the power of 1. They combine to-2xy.9xand9yare not like terms because they have different variables (xvs.y).2xand2x²are not like terms because the variablexis raised to different powers (1 vs. 2).5and-12are like terms (they are both constants, which can be thought of as terms with no variables, or variables raised to the power of 0). They combine to-7.
The power of recognizing and combining like terms lies in its ability to simplify complex mathematical expressions. In the realm of drone technology, where every millisecond of processing time and every byte of memory can be critical, this simplification directly translates to enhanced performance and efficiency.
Streamlining Algorithms for Autonomous Flight
Autonomous flight is a marvel of engineering, relying on intricate algorithms to manage everything from takeoff and landing to complex aerial maneuvers and obstacle avoidance. The mathematical models describing a drone’s dynamics, its interaction with the environment, and its navigation are often complex. Identifying and combining like terms within these models is not just about making equations look tidier; it’s about optimizing the computational load.
Enhancing Control System Equations
Modern drones employ sophisticated control systems to maintain stability, execute precise movements, and adapt to changing conditions. These systems often utilize proportional-integral-derivative (PID) controllers or more advanced model predictive control (MPC) techniques, all expressed through differential equations and algebraic formulas.
Consider a simplified control loop equation for a drone’s attitude stabilization, where various sensor inputs and desired outputs contribute to the motor commands. An equation might look something like:
Motor_Power = (K_p * Error_pitch) + (K_i * Integral_pitch) + (K_d * Derivative_pitch) + (K_p * Error_roll) + (K_i * Integral_roll) + (K_d * Derivative_roll) + Bias_term
Here, K_p, K_i, K_d are proportional, integral, and derivative gains (constants), and Error, Integral, Derivative represent the respective components for pitch and roll (variables). If, through further mathematical manipulation or system design, terms with identical variable structures emerge, combining them simplifies the real-time calculation. For instance, if Error_pitch and Error_roll were somehow combined into a single Total_Angular_Error, or if intermediate calculations produced expressions like (A * Sensor_1) + (B * Sensor_1), recognizing these as like terms allows for (A+B) * Sensor_1, reducing computational steps.
In real-time flight control, where calculations must occur thousands of times per second, simplifying expressions by combining like terms can lead to:
- Reduced CPU Cycles: Fewer operations mean the flight controller has more capacity for other tasks or can run at lower power.
- Improved Responsiveness: Faster calculations lead to quicker adjustments, enhancing the drone’s stability and agility.
- Simplified Debugging: A more compact equation is easier for engineers to verify and troubleshoot.
Optimizing Navigation and Path Planning
Path planning algorithms, crucial for autonomous missions, often involve solving optimization problems. These problems might consider minimizing flight time, energy consumption, or deviations from a planned route, often represented by objective functions. These functions contain variables related to position, velocity, acceleration, and environmental factors.
For example, a drone navigating through a complex environment might have its cost function (to be minimized) expressed as a sum of various penalties:
Cost = C_time * t + C_dist * d + C_energy * E + C_obstacle * O + C_time * t_correction
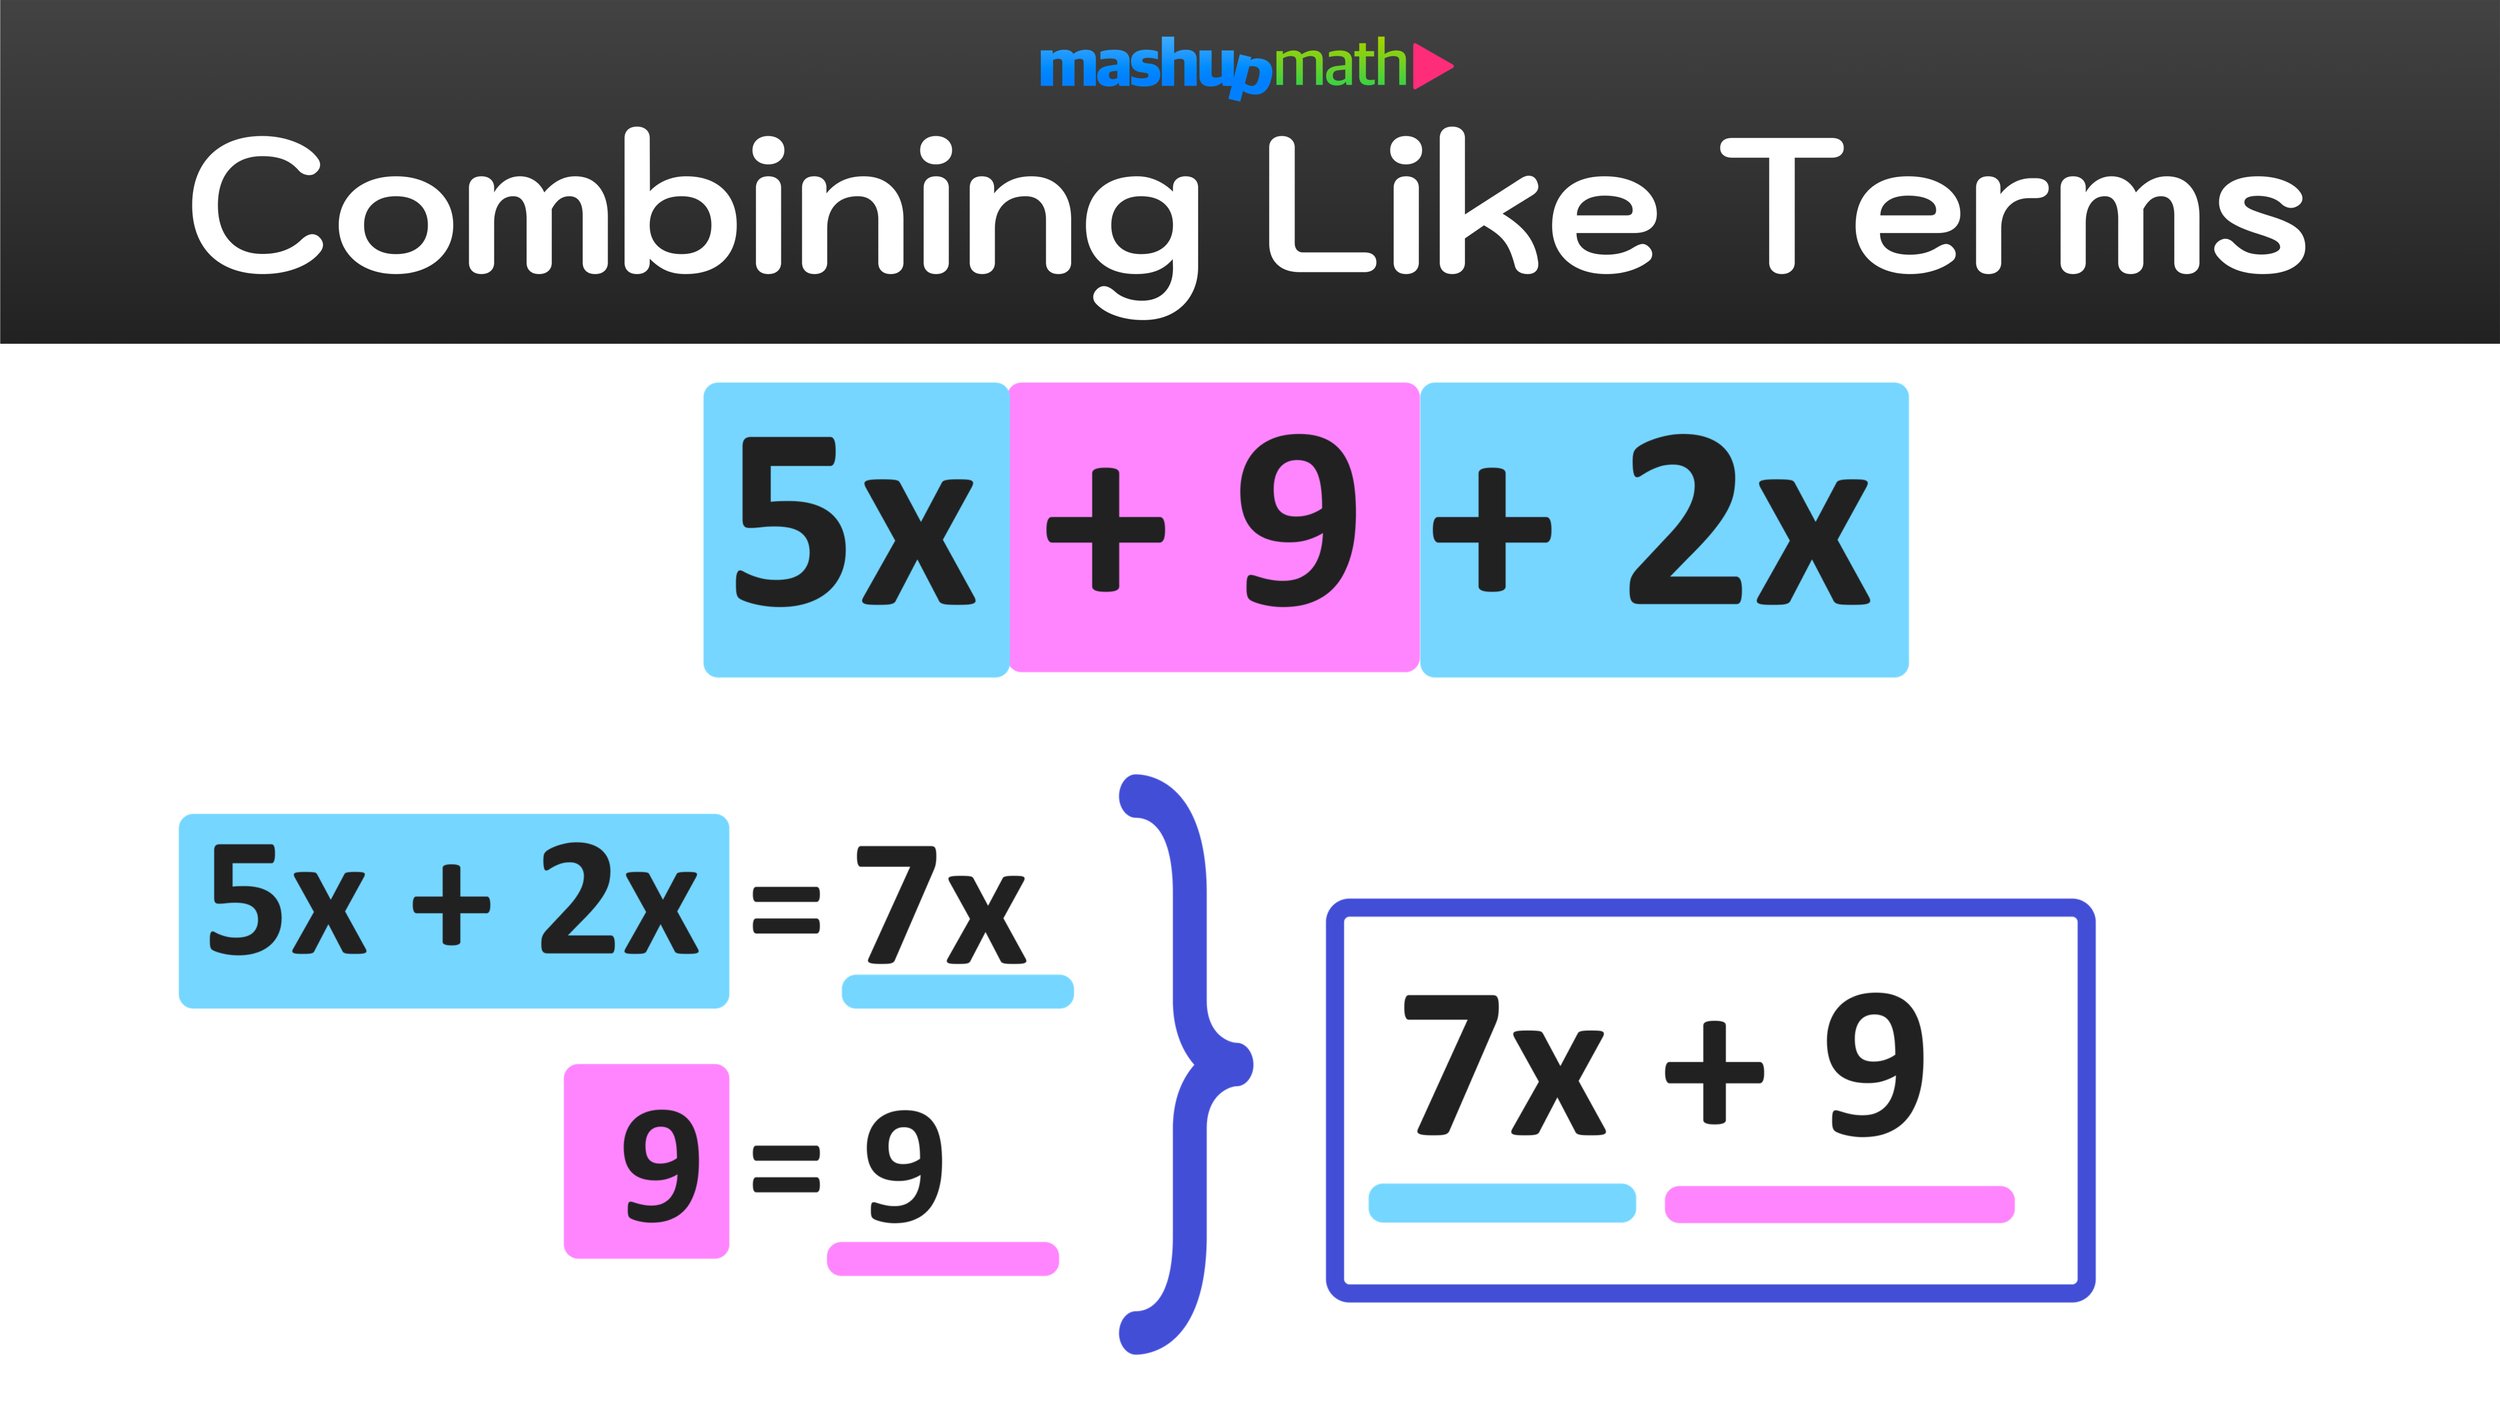
If C_time * t and C_time * t_correction are like terms, they can be combined into C_time * (t + t_correction). While this is a basic example, in highly complex path planning models involving hundreds or thousands of state variables and constraints, identifying and combining like terms is fundamental to making these large-scale optimization problems computationally tractable. Algorithms like Simultaneous Localization and Mapping (SLAM) or Visual Inertial Odometry (VIO) extensively rely on state estimation, often involving Jacobian matrices and Kalman filters, where the careful algebraic manipulation, including combining like terms, ensures efficient matrix operations and accurate real-time position updates.
Precision in Sensor Data Interpretation and AI Processing
Drones are increasingly equipped with an array of sophisticated sensors—LIDAR, radar, vision cameras, thermal cameras, IMUs, GPS—generating vast quantities of data. Making sense of this deluge of information for real-time decision-making, remote sensing, or AI-driven tasks requires robust and efficient data processing. Here again, like terms play an understated but vital role.
Simplifying Data Models for Remote Sensing
Remote sensing drones collect data for agriculture, environmental monitoring, infrastructure inspection, and more. This data often comes in the form of numerical arrays or matrices, where each element might correspond to a specific measurement (e.g., spectral reflectance, temperature, elevation). When developing models to interpret this data, mathematical expressions are formulated to extract meaningful insights.
Consider a model designed to assess crop health based on multiple spectral bands:
Health_Index = (Band_NIR * Weight_NIR) + (Band_Red * Weight_Red) + (Band_Green * Weight_Green) + (Band_NIR * Weight_NIR_Correction)
In this expression, Band_NIR, Band_Red, and Band_Green are variables representing the measured reflectance values, and Weight_NIR, Weight_Red, etc., are constants representing their importance. Immediately, (Band_NIR * Weight_NIR) and (Band_NIR * Weight_NIR_Correction) stand out as like terms because they both involve Band_NIR raised to the power of 1. These can be combined to Band_NIR * (Weight_NIR + Weight_NIR_Correction), simplifying the calculation and improving the model’s efficiency, especially when applied to millions of pixels in a high-resolution map.
This simplification is crucial for:
- Real-time Processing: Enabling on-board analysis rather than solely relying on post-processing.
- Reduced Computational Load: Less time spent on redundant operations, freeing up resources.
- Model Interpretability: Cleaner equations are easier to understand and validate.
Building More Efficient AI Follow Mode Logics
AI follow mode, a popular feature allowing drones to autonomously track a moving subject, relies on complex computer vision and prediction algorithms. These algorithms continuously calculate the subject’s position, velocity, and anticipated trajectory, translating these into drone flight commands. Mathematical models within these AI systems often involve numerous variables representing features of the target, environmental conditions, and drone state.
An AI model might evaluate multiple parameters to decide the optimal follow path, perhaps including:
Target_Score = (0.3 * Target_Size) + (0.2 * Target_Speed) + (0.1 * Target_Distance) + (0.05 * Obstacle_Proximity) + (0.15 * Target_Size)
Here, Target_Size, Target_Speed, Target_Distance, and Obstacle_Proximity are variables. Notice the terms (0.3 * Target_Size) and (0.15 * Target_Size). These are like terms. Combining them simplifies the equation to:
Target_Score = (0.45 * Target_Size) + (0.2 * Target_Speed) + (0.1 * Target_Distance) + (0.05 * Obstacle_Proximity)
This seemingly minor simplification aggregates the influence of “Target_Size” into a single coefficient. In a deep learning model or a complex neural network, while the underlying math is often handled by linear algebra libraries, the principles of combining like terms manifest in efficient matrix operations and reduced parameter counts, leading to faster inference times and smoother, more responsive AI behavior. For an AI follow mode, this means the drone can react more swiftly and accurately to the subject’s movements, providing a seamless tracking experience.
The Broader Impact on Drone Tech & Innovation
Beyond the immediate applications in autonomous flight and AI, the principle of like terms permeates various other innovative aspects of drone technology. From creating highly accurate 3D maps to enabling predictive maintenance, the foundation of algebraic simplification contributes to the overall efficiency and sophistication of these systems.
Accelerating Mapping and 3D Modeling
Drones are revolutionizing mapping and 3D modeling through photogrammetry and LIDAR. These processes involve collecting millions of data points and photos, which are then stitched together and processed to create precise digital models. The algorithms for aligning images, triangulating points in 3D space, and generating dense point clouds are computationally intensive.
Mathematical models used in bundle adjustment (a core photogrammetry technique) or point cloud registration often involve solving large systems of equations. When these equations are represented algebraically, combining like terms ensures that the underlying matrices are as sparse and manageable as possible. Efficient matrix operations are paramount for reducing the processing time of large datasets, allowing mapping professionals to generate 3D models more quickly and with fewer computational resources. This efficiency translates directly into faster project turnaround times and reduced operational costs for drone mapping services.
Foundations for Predictive Analytics and Diagnostics
Predictive analytics is an emerging frontier for drone technology, involving the use of collected data to forecast future events or potential equipment failures. Drones can monitor infrastructure, inspect machinery, or track environmental changes over time, accumulating vast datasets that can be analyzed to predict maintenance needs, crop yields, or environmental shifts.
Developing predictive models often involves fitting statistical equations to historical data. These equations can take various forms, including polynomial regressions or more complex multivariate models. When constructing such models, an expression might contain terms like (0.5 * Sensor_Temp_Avg) + (0.2 * Sensor_Humidity_Max) + (0.3 * Sensor_Temp_Avg). Recognizing (0.5 * Sensor_Temp_Avg) and (0.3 * Sensor_Temp_Avg) as like terms allows for their combination into (0.8 * Sensor_Temp_Avg), simplifying the predictive equation.
This simplification is crucial for:
- Model Accuracy and Robustness: Clearer models are often more accurate and less prone to overfitting.
- Real-time Diagnostics: For on-board health monitoring, efficient computation of diagnostic indicators is vital.
- Resource Management: Predicting component failure reduces downtime and optimizes maintenance schedules for drone fleets.
In essence, while “like terms in math” might seem like a basic concept learned in introductory algebra, its implications resonate throughout the most advanced aspects of drone technology and innovation. It underpins the efficiency, precision, and intelligence of the algorithms that power autonomous flight, sophisticated sensor interpretation, and cutting-edge AI features. A deep appreciation for these fundamental mathematical principles is, therefore, not just for mathematicians, but for every engineer and innovator pushing the boundaries of what drones can achieve.