
In the intricate world of drone flight technology, the seemingly abstract concept of “functions on a graph” transforms into an indispensable tool for understanding, monitoring, and optimizing aerial operations. Far from being a mere mathematical exercise, this framework provides a visual language to decode the complex interplay of forces, movements, and sensor data that govern a drone’s every maneuver. It allows engineers, pilots, and AI systems to visualize relationships between variables—such as altitude over time, battery life versus energy consumption, or GPS coordinates mapping a flight path—turning raw data into actionable insights crucial for navigation, stabilization, and overall system performance.
The Foundational Role of Data Visualization in Drone Systems
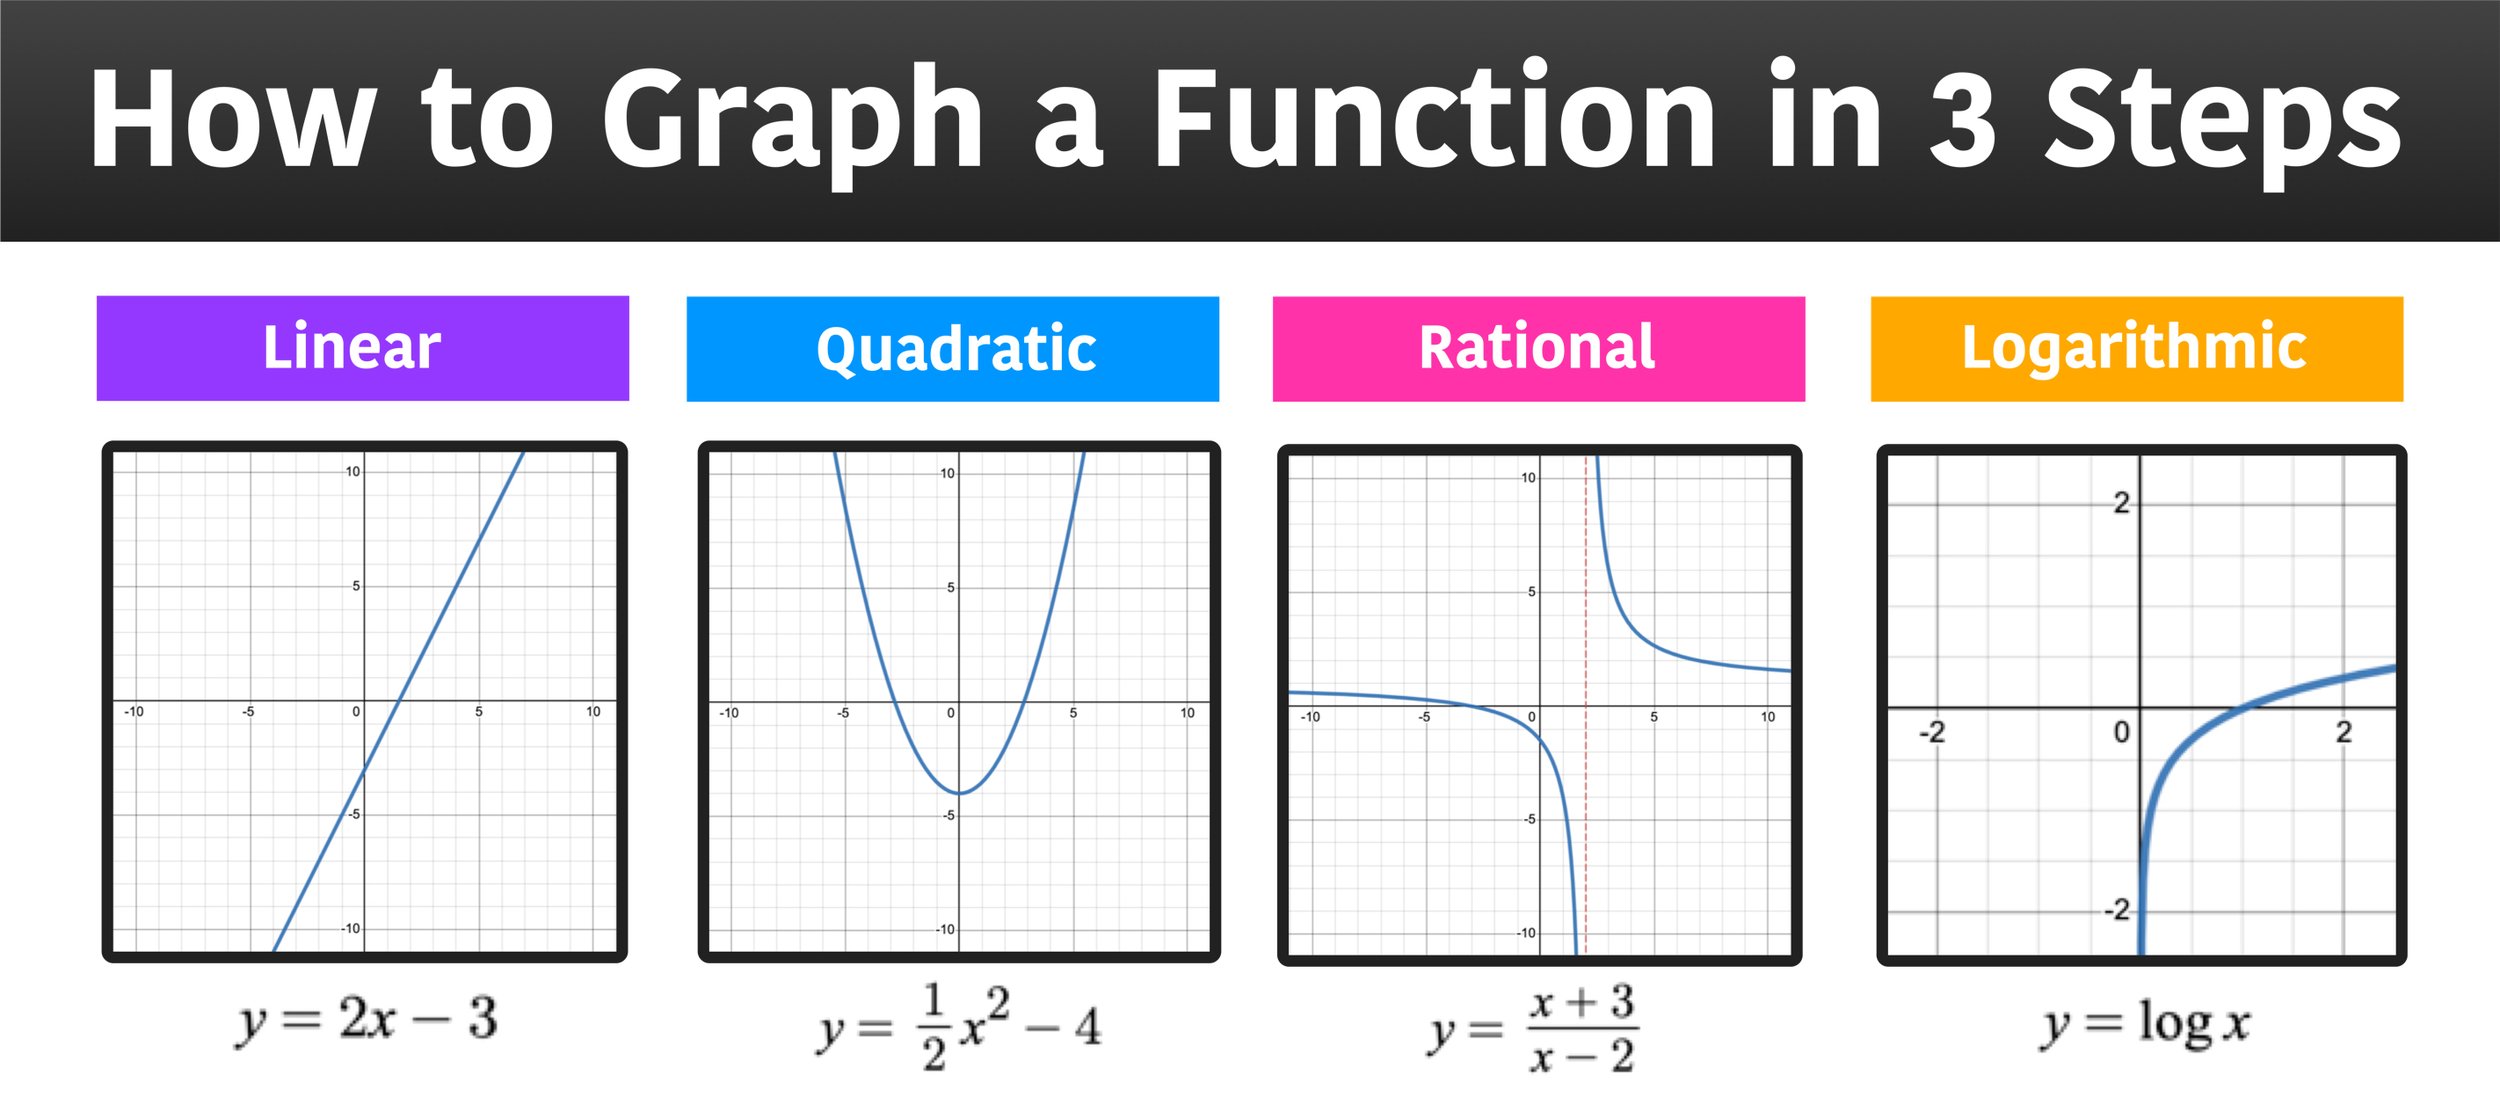
At its core, a function on a graph illustrates how one variable changes in response to another. In drone flight technology, this principle is fundamental to comprehending the dynamic environment in which these sophisticated machines operate. From the moment a drone lifts off, it generates a continuous stream of data points, each a crucial component of a larger functional relationship that can be plotted and analyzed.
Understanding Relationships in Flight Dynamics
Consider the simple act of a drone ascending. Its altitude is a dependent variable, directly influenced by the power output to its motors, which in turn is a function of the pilot’s input or an autonomous system’s command. When plotted against time, this forms a clear function on a graph, revealing ascent rates, stability during climb, and the efficiency of vertical motion. Similarly, speed as a function of power, or pitch as a function of control input, all become quantifiable and visualizable relationships. This graphical representation allows developers to fine-tune flight algorithms, ensuring smooth transitions, efficient power usage, and precise control across all axes of movement.
Bridging Raw Data to Actionable Insights
Without the ability to visualize these functions, the sheer volume of telemetry data would remain an unintelligible torrent of numbers. Graphs provide an intuitive means to identify trends, pinpoint anomalies, and evaluate performance against predefined parameters. For instance, a sudden dip in a motor’s RPM graph might indicate an impending failure, while erratic fluctuations in a GPS position graph could signal interference or a navigation error. By transforming complex datasets into accessible visual functions, drone operators and autonomous systems can make real-time decisions, from adjusting flight paths to initiating emergency landings, thereby enhancing safety and operational efficiency.
Telemetry and Performance as Graphed Functions
Telemetry data is the lifeblood of drone operation, providing a continuous feedback loop on the aircraft’s status and performance. Every piece of this data—from altitude to battery voltage—can be represented as a function on a graph, offering critical insights into the drone’s operational health and capabilities.
Altitude, Speed, and Ascent Rates Over Time
One of the most common applications of functions on a graph in drone telemetry involves charting altitude, speed, and ascent/descent rates against time. A smooth, consistent altitude graph indicates stable flight control, while jagged lines might suggest turbulence or control issues. Similarly, speed graphs demonstrate acceleration, cruising velocities, and deceleration phases, crucial for assessing flight efficiency and adherence to mission parameters. Ascent rate graphs, derived from altitude changes over time, help evaluate the drone’s vertical performance, a key metric for missions requiring rapid deployment or specific altitude profiles. These visual functions are invaluable for post-flight analysis, allowing operators to review mission execution and identify areas for improvement in piloting technique or autonomous system programming.
Battery Discharge Curves and Endurance Prediction
The battery is a drone’s power source, and its performance is critical. Battery discharge is a classic example of a functional relationship: voltage or remaining capacity as a function of flight time or power consumption. A typical discharge curve starts high and gradually declines, often with a steeper drop-off towards the end. Monitoring these functions on a graph allows pilots to accurately predict remaining flight time, optimize flight plans to maximize endurance, and understand how different flight profiles (e.g., high-speed vs. hovering) impact battery life. Anomalies in the discharge curve, such as sudden voltage drops, can signal battery degradation or faulty cells, prompting maintenance or replacement.
Motor Performance and Efficiency Metrics
The health and efficiency of a drone’s motors and propellers are paramount for stable flight. RPM (rotations per minute) of each motor, current draw, and temperature are all functions that can be graphed over time. Discrepancies between motor RPMs can indicate imbalanced propellers or motor issues, affecting stability and control. Current draw graphs illustrate power consumption, highlighting periods of high demand (like rapid ascent) and helping engineers optimize propulsion systems for greater efficiency. Analyzing these functions helps in preventive maintenance, ensuring reliable performance and extending the lifespan of critical components.
Navigational Pathways and Spatial Functions
Navigation is arguably the most critical aspect of drone flight, enabling precise movement from one point to another. Functions on a graph are central to mapping, planning, and executing these complex aerial journeys.
GPS Trajectories: Mapping the Drone’s Journey
Global Positioning System (GPS) data provides the drone’s precise latitude, longitude, and altitude at any given moment. When these coordinates are plotted over time, they form a functional graph representing the drone’s exact trajectory through 3D space. This visualization is essential for verifying flight path accuracy, analyzing deviations from planned routes, and reconstructing flights for accident investigation or performance review. By examining the slope and curvature of these functional graphs, operators can assess the smoothness and efficiency of turns, loitering patterns, and waypoint transitions.
Waypoint Navigation and Path Optimization
Autonomous drone missions often rely on waypoint navigation, where a series of predefined geographical points guides the drone along a programmed path. The trajectory between these waypoints can be modeled and optimized using functional graphs. Engineers can apply algorithms to generate the most efficient path—considering factors like wind, battery life, and obstacle avoidance—and then visualize this optimal function. During flight, the drone’s actual GPS trajectory can be continuously compared against this ideal functional graph, allowing the flight controller to make real-time adjustments to stay on course. This dynamic comparison is a core application of functions in autonomous flight, ensuring precision and reliability.
Relative Positioning and Obstacle Avoidance Mapping
Advanced flight technology incorporates sensors for relative positioning and obstacle avoidance. Lidar, radar, and vision systems generate data that can be mapped as functions to create a real-time understanding of the drone’s surroundings. For instance, distance to an obstacle as a function of the drone’s approach path can be graphed, indicating critical thresholds for evasive action. In dense environments, these functions enable the drone to build a 3D map of its surroundings, identifying clear pathways (represented as regions where the ‘obstacle distance’ function remains high) and potential collision points. This functional mapping is vital for safe autonomous operation, allowing drones to navigate complex terrains and avoid dynamic obstacles.
Sensor Data Interpretation Through Functional Graphs
Modern drones are equipped with an array of sensors that constantly feed data into the flight controller. Interpreting this torrent of information effectively often relies on viewing these sensor outputs as functions over time or space.
Inertial Measurement Unit (IMU) Data Analysis
The Inertial Measurement Unit (IMU), comprising accelerometers and gyroscopes, provides crucial data on the drone’s orientation, angular velocity, and linear acceleration. Each axis of acceleration (X, Y, Z) and angular rate (pitch, roll, yaw) can be plotted as a function of time. These graphs reveal the drone’s attitude and movement characteristics, helping to diagnose vibrations, stability issues, or control surface effectiveness. For example, a gyroscope reading that oscillates erratically might indicate excessive vibration, while a steady increase in acceleration on one axis without corresponding control input could signal a hardware malfunction. Analyzing these functional graphs is fundamental for calibrating IMUs and tuning PID (Proportional-Integral-Derivative) controllers for optimal stabilization.
Environmental Sensor Readings: Temperature, Wind, and Pressure
Environmental sensors provide data like ambient temperature, wind speed and direction, and barometric pressure. Plotting these as functions over time or location allows for contextual understanding of flight conditions. A graph of barometric pressure over time, combined with GPS altitude, can verify the accuracy of the altimeter, while significant fluctuations in wind speed graphs can explain deviations from planned trajectories or sudden power consumption spikes. For specialized missions, such as environmental monitoring, these functional graphs become the primary output, directly displaying the distribution or change of environmental parameters across a surveyed area.
Lidar and Sonar Data for Terrain Mapping and Proximity Sensing
Lidar (Light Detection and Ranging) and sonar sensors generate dense point cloud data or distance readings, which are inherently functional representations of the environment. Lidar scans produce a “distance from sensor” function across an angular sweep, effectively mapping terrain elevation or object surfaces. Plotting these distances creates a topographical graph or a detailed 3D model. Sonar, often used for precise altitude hold in close proximity to surfaces, generates a simple “distance to ground” function, critical for automated landings or precise low-altitude flights. These functional representations are vital for applications like precision agriculture, infrastructure inspection, and autonomous terrain following, where detailed environmental understanding is key.
Functions in Stabilization and Control Systems
The ability of a drone to maintain stable flight and execute precise maneuvers is a testament to sophisticated control systems. Functions on a graph are integral to designing, tuning, and monitoring these systems.
Feedback Loops and PID Controllers Visualized
Modern drone flight controllers heavily rely on feedback loops, often implemented through PID (Proportional-Integral-Derivative) controllers, to maintain stability. The desired state (setpoint) and the actual state (measured by sensors) are continuously compared. The error between these two is fed into the PID algorithm, which generates control outputs (e.g., motor speeds) to correct the deviation. When visualized on a graph, the setpoint and actual state become two distinct functions over time. The PID tuning process largely involves adjusting parameters to minimize the error function, ensuring the actual state function converges smoothly and rapidly to the setpoint function without overshooting or oscillation. This graphical feedback is crucial for achieving smooth, responsive, and stable flight characteristics.
Gyroscope and Accelerometer Data for Real-time Orientation
The data from gyroscopes and accelerometers, when integrated and filtered, provides the drone’s real-time orientation (pitch, roll, yaw). These orientation angles, plotted as functions over time, are the primary inputs for stabilization algorithms. Any deviation from a level flight attitude or a commanded turn is immediately detected and represented as a change in these functional graphs. The flight controller then uses these functions to calculate the necessary corrections, applying counter-forces to restore the desired orientation. The smoothness and responsiveness of these real-time functions are direct indicators of the effectiveness of the drone’s stabilization system.
Predictive Maintenance and Anomaly Detection
Beyond real-time control, the historical data represented as functions on a graph plays a crucial role in predictive maintenance and anomaly detection. By continuously monitoring and graphing parameters like motor temperature, current draw, vibration levels, and battery health, patterns can emerge. A gradual increase in motor temperature over successive flights, for example, forms a trend function that could predict impending motor failure. Sudden, uncharacteristic spikes or dips in otherwise stable functional graphs can flag anomalies requiring immediate attention. Leveraging machine learning algorithms to analyze these vast functional datasets, drone systems can learn “normal” operational functions and detect deviations, significantly improving reliability and safety through proactive intervention.
In conclusion, “functions on a graph” are not just abstract mathematical concepts in drone flight technology; they are the visual lexicon through which these complex machines communicate their status, navigate their environment, and execute their missions. From calibrating sensors and optimizing flight paths to ensuring stability and predicting maintenance needs, the ability to represent and interpret operational data as functions on a graph is fundamental to the evolution and successful deployment of modern drones across a myriad of applications.