
In the rapidly evolving landscape of drone technology, where autonomous flight, artificial intelligence (AI) integration, and sophisticated data processing are becoming standard, the underlying principles of software engineering play a pivotal role. Among these, data structures stand out as a fundamental cornerstone, often working behind the scenes to power the intricate systems that allow drones to navigate complex environments, perform intelligent tasks, and collect vast amounts of valuable data. At its core, a data structure is a particular way of organizing data in a computer so that it can be accessed and modified efficiently. For drones, especially those pushing the boundaries of innovation in areas like AI follow mode, autonomous mapping, and remote sensing, the choice and implementation of appropriate data structures are not merely academic exercises but critical determinants of performance, reliability, and capability. They dictate how quickly a drone can process sensor input, make decisions, plan trajectories, and communicate with its environment, directly impacting everything from battery life to mission success.
The Foundation of Intelligent Drone Systems
Every advanced feature in modern drones, from precise navigation to real-time object recognition, relies heavily on how data is managed and manipulated. Data structures provide the organizational framework that allows software engineers to design efficient algorithms for these complex tasks. Without well-chosen data structures, the sheer volume and velocity of information generated by a drone’s sensors would overwhelm its processing capabilities, leading to delays, errors, and ultimately, system failure.
Organizing Sensor Data
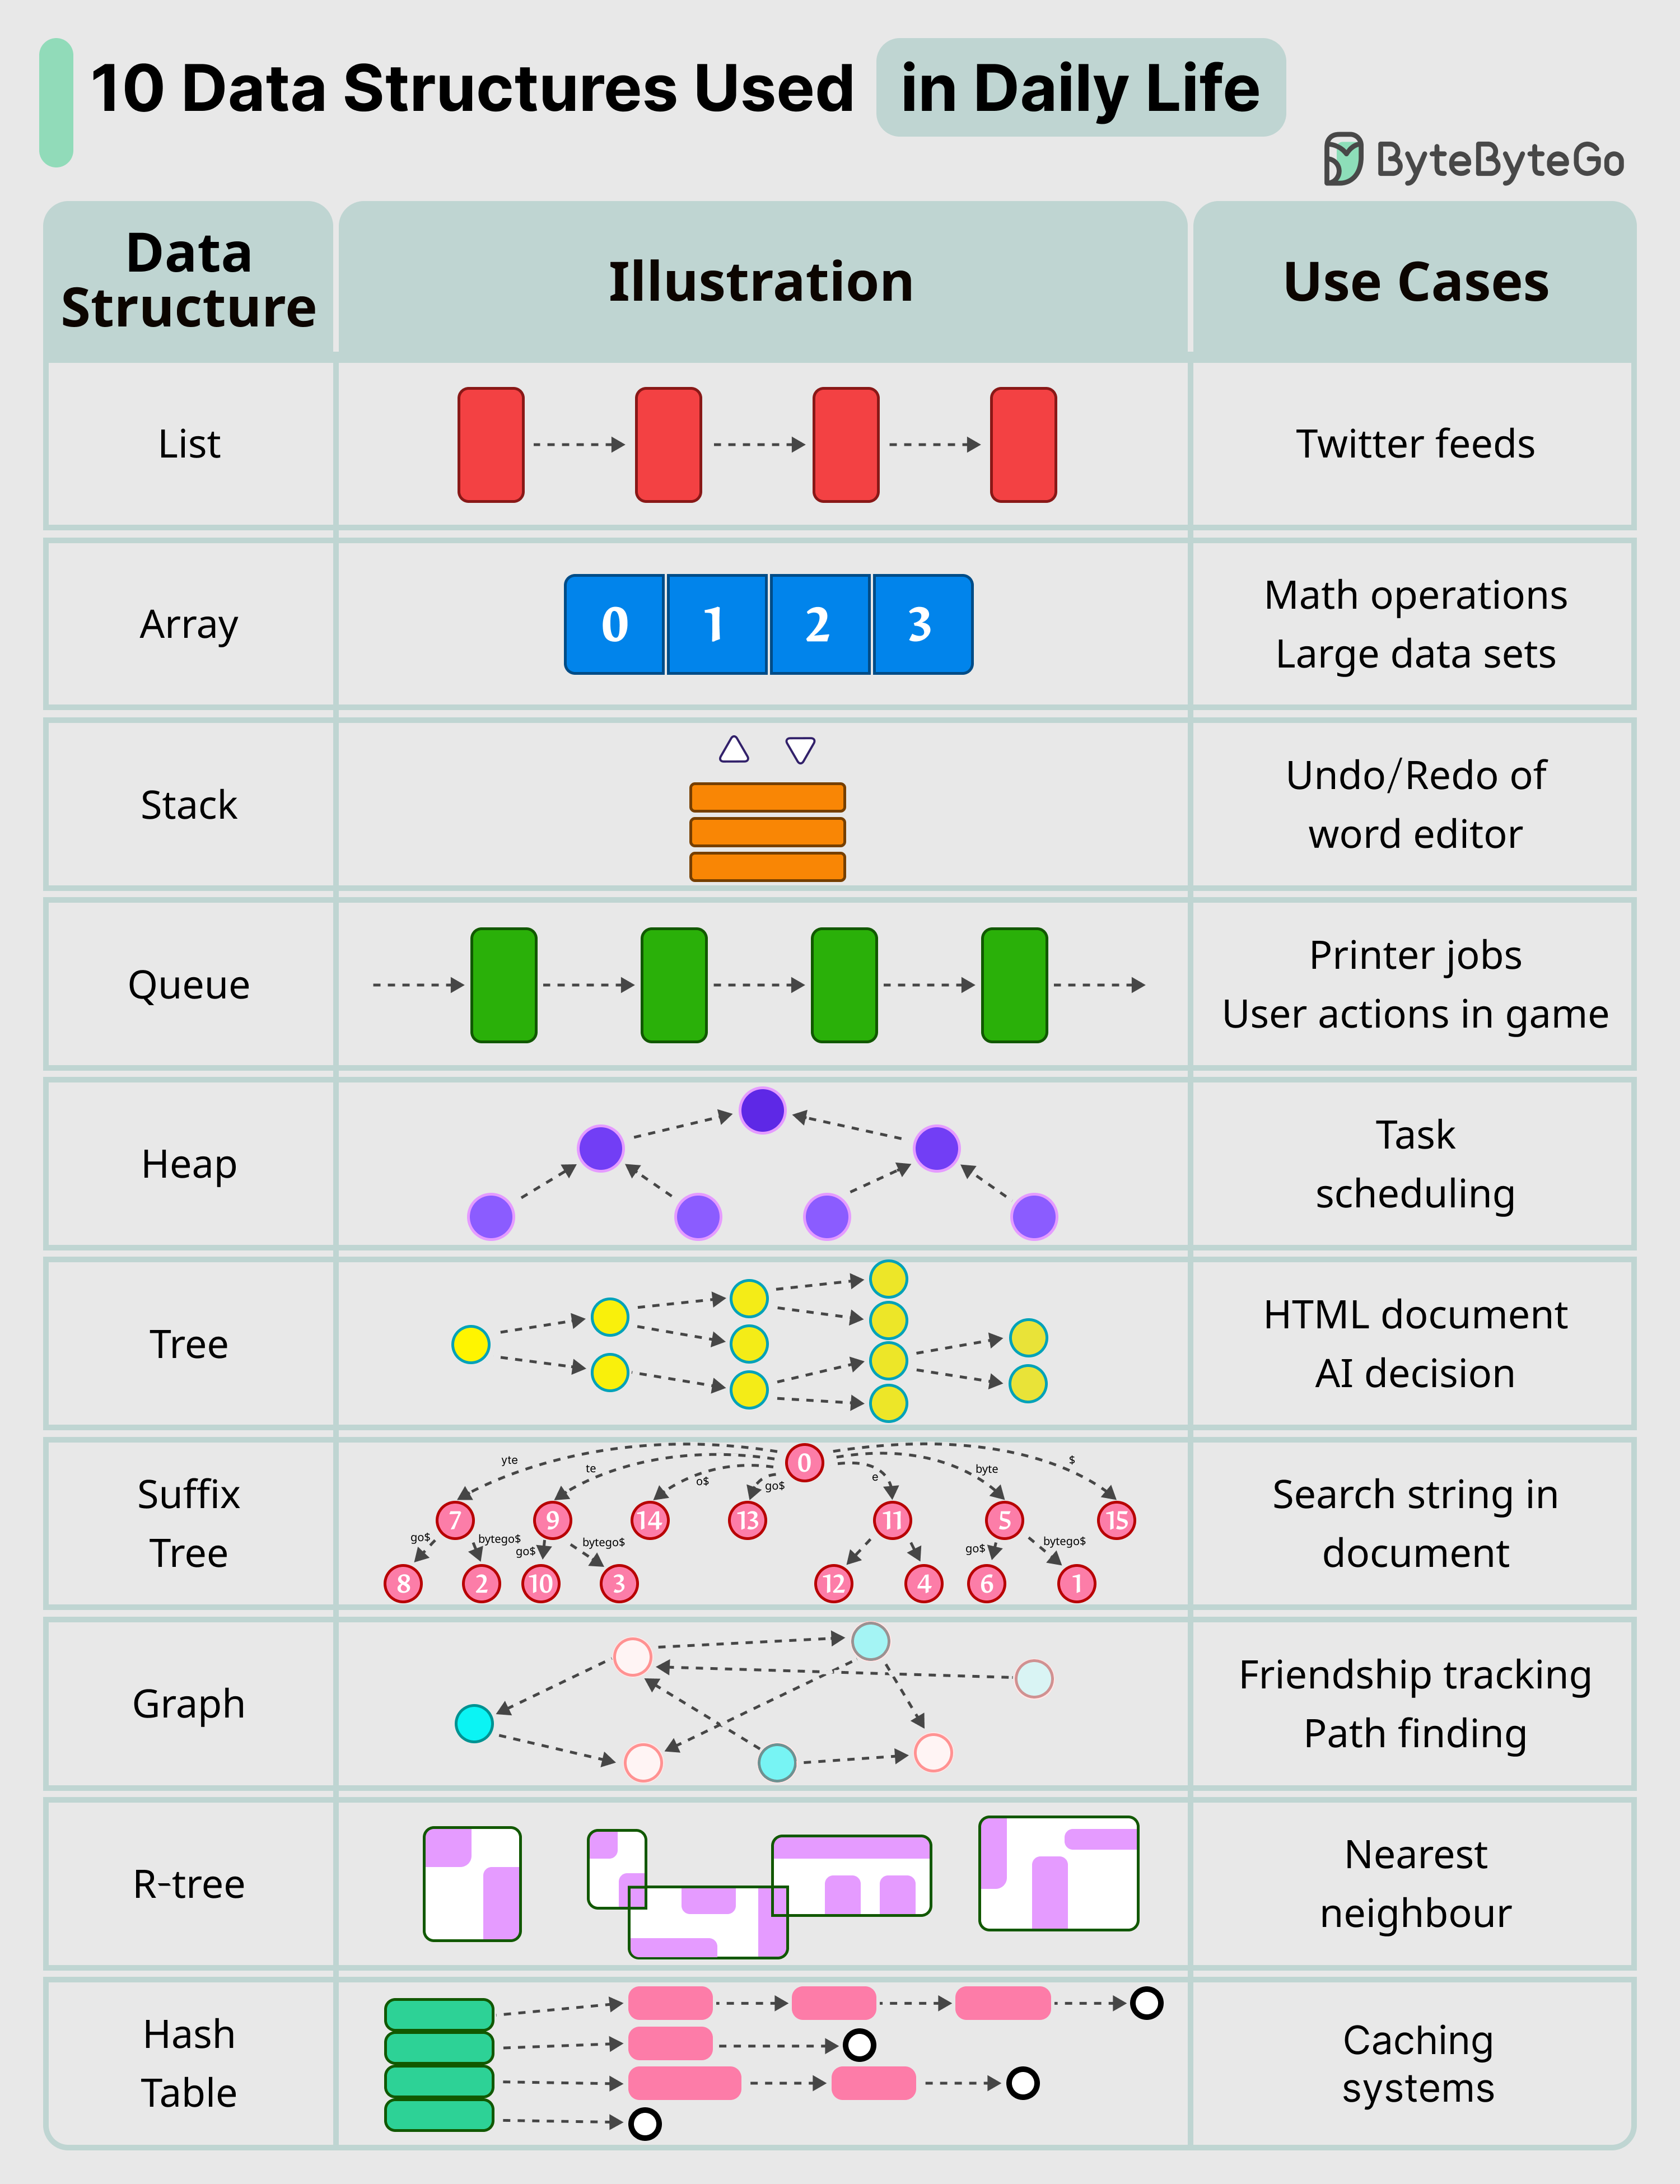
Drones are equipped with an array of sensors: Inertial Measurement Units (IMUs) providing acceleration and angular velocity, GPS receivers for positional data, vision cameras capturing images and video, LiDAR sensors generating point clouds, and more. Each sensor streams data continuously and at high rates. To make sense of this deluge of information, data structures are indispensable. For instance, simple arrays or dynamic vectors might be used to store a sequence of IMU readings over a short time window, enabling algorithms to estimate the drone’s attitude and velocity through sensor fusion. More complex structures like queues are often employed to buffer incoming sensor packets, ensuring that data is processed in the order it was received, even if temporary processing spikes occur.
When dealing with visual data, such as images from an optical camera, the raw pixel data itself is often represented as a multi-dimensional array. However, to extract meaningful features for object detection or tracking, specialized data structures are employed. For example, feature descriptors (like SIFT or SURF) can be stored and indexed using structures like k-d trees or R-trees to enable rapid searching and matching across frames, crucial for visual odometry and simultaneous localization and mapping (SLAM) algorithms. These structures allow the drone’s onboard computer to quickly identify and track points of interest in its environment, forming the basis for intelligent navigation and object interaction.
Path Planning and Navigation Efficiency
Autonomous flight is perhaps one of the most celebrated innovations in drone technology, and data structures are at its core. Planning a safe and efficient path from a starting point to a destination, while avoiding obstacles and adhering to mission objectives, is a computationally intensive task. Graphs are widely used to represent the drone’s operational environment, where nodes might represent locations or waypoints, and edges represent possible paths between them. Pathfinding algorithms like A* or Dijkstra’s, which are fundamental to drone navigation, heavily rely on efficient graph representations and often utilize priority queues (typically implemented using heaps) to explore the most promising paths first.
For navigating in 3D environments, especially when dealing with complex obstacles or unknown terrains, data structures like octrees or voxel grids are invaluable. An octree hierarchically subdivides space into eight child nodes, allowing for efficient representation of sparse 3D environments and rapid collision checking. This hierarchical organization enables the drone to quickly query whether a particular volume of space is free or occupied, which is critical for real-time obstacle avoidance and dynamic path replanning. Without such optimized spatial data structures, the drone would spend too much time processing environmental data, making real-time autonomous flight impractical.
Powering Autonomous Flight and AI Features
The advancements in AI for drones have transformed them from mere remote-controlled devices into intelligent agents capable of understanding their surroundings and making autonomous decisions. This intelligence is deeply intertwined with how data is organized and processed, with data structures providing the necessary framework for machine learning models and real-time decision-making systems.
Machine Learning and AI Follow Modes
AI follow mode, where a drone autonomously tracks a moving subject, exemplifies the integration of advanced algorithms and efficient data handling. Machine learning models, particularly deep neural networks, are at the heart of the object detection and tracking process. While the internal structure of neural networks themselves can be viewed as complex computational graphs, the input data (e.g., video frames) and the intermediate features extracted from them are managed using fundamental data structures. Large datasets for training these AI models are often stored in optimized formats that allow for quick access during the training phase. Onboard the drone, when the model is deployed for inference, efficient data structures facilitate the feeding of real-time camera data to the neural network and the subsequent processing of its outputs to generate tracking commands. For instance, a queue might buffer incoming video frames, ensuring a continuous stream for the object detection model, while bounding box detections might be stored in a dynamic array for further processing by the tracking algorithm.

Real-time Decision Making and Obstacle Avoidance
Autonomous decision-making is a cornerstone of advanced drone operations. Whether it’s selecting an optimal landing spot, deciding to reroute due to unexpected weather, or executing complex maneuvers to avoid an obstacle, these decisions must be made in real-time, often under strict latency constraints. Data structures like finite state machines (conceptually often implemented using graphs or switch-case statements with associated data) are used to model the drone’s operational modes and transitions between them. For sophisticated obstacle avoidance, point clouds from LiDAR or stereo cameras are frequently processed and organized into spatial data structures such as octrees or k-d trees. These structures allow for lightning-fast queries to determine the presence of obstacles within the drone’s projected flight path. When an obstacle is detected, path replanning algorithms, often leveraging graph-based representations of the navigable space, quickly compute an alternative trajectory. The efficiency of these underlying data structures directly dictates how rapidly the drone can perceive, react, and adapt to dynamic changes in its environment, ensuring mission safety and success.
Enhancing Mapping, Remote Sensing, and Data Management
Drones are invaluable tools for mapping large areas, conducting remote sensing operations, and collecting vast quantities of geospatial data. The effectiveness of these applications hinges on the drone’s ability to efficiently manage, process, and transmit this rich data, where data structures play an absolutely critical role.
Geospatial Data Handling
Mapping and remote sensing applications generate enormous datasets, including high-resolution imagery, multispectral data, LiDAR point clouds, and photogrammetry models. Organizing this spatially referenced data efficiently is paramount. Quadtrees are often used for 2D spatial indexing, particularly for ground mapping and aerial image stitching, allowing for quick retrieval of data pertaining to specific geographical regions. For 3D environments, as mentioned before, octrees are highly effective in representing point clouds and 3D models, enabling efficient storage, querying, and rendering of complex scenes. These hierarchical structures reduce the computational load for tasks like terrain analysis, volumetric calculations, and change detection by focusing processing power only on relevant areas. Without these specialized geospatial data structures, processing these large datasets would be prohibitively slow and memory-intensive, severely limiting the practical utility of drones in these fields.
Efficient Data Retrieval and Analysis
Beyond mere storage, data structures facilitate the rapid retrieval and sophisticated analysis of collected information. When a drone performs a remote sensing mission, it might collect data on vegetation health, thermal anomalies, or structural integrity. This data often needs to be correlated with location, time, and other parameters. Hash tables can be used for quick lookups of specific data points based on unique identifiers or keys, crucial for efficient data logging and post-mission analysis. For time-series data, such as environmental readings taken at regular intervals, specialized structures or simply well-indexed arrays allow for efficient querying over specific time ranges. The ability to quickly access, filter, and aggregate data points is essential for extracting actionable insights, whether it’s identifying areas of crop stress in precision agriculture or detecting anomalies in infrastructure inspections.
Optimizing Performance in Limited Environments
Drones operate under stringent constraints regarding processing power, memory, and energy. Unlike large servers or desktop computers, onboard drone systems must achieve high performance with minimal resources. This is where the judicious choice of data structures becomes absolutely critical, directly impacting the drone’s endurance, responsiveness, and overall capabilities.
Memory and Processing Constraints
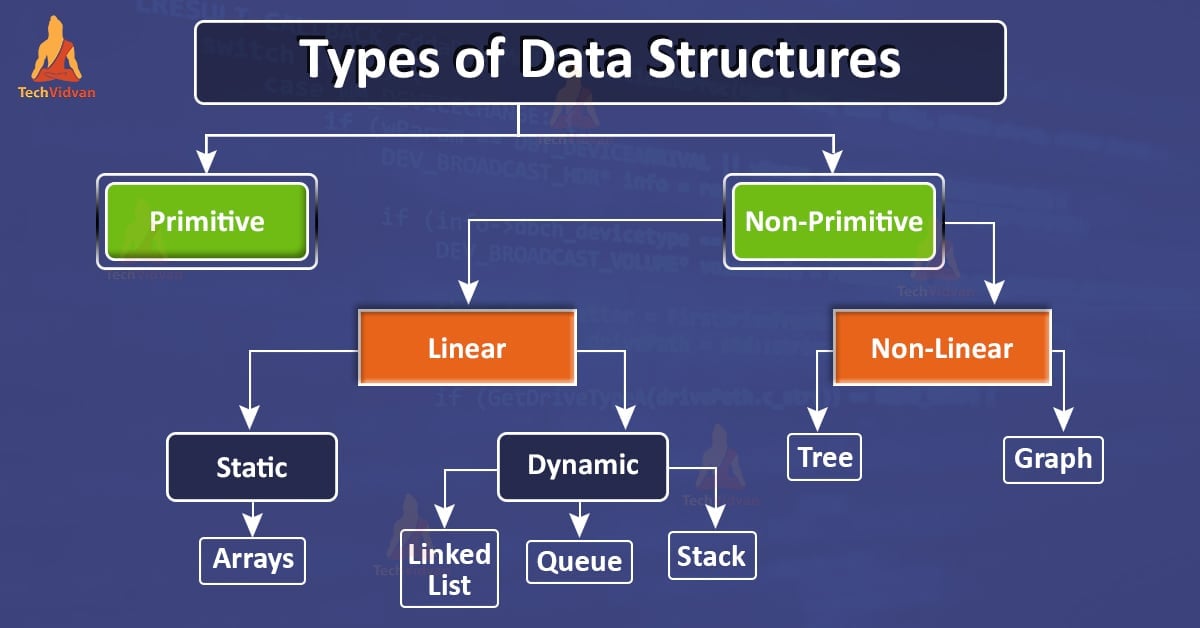
Every byte of memory and every clock cycle of the processor counts on a drone. Inefficient data structures can lead to excessive memory consumption, requiring larger and heavier memory modules, which in turn reduces flight time and payload capacity. They can also lead to higher computational loads, drawing more power and increasing heat generation, both detrimental to drone performance and longevity. For instance, choosing an array over a linked list for a fixed-size buffer can save memory overhead associated with pointers. Using a compressed spatial data structure like an octree instead of a dense voxel grid can dramatically reduce the memory footprint for representing environments, especially in sparsely populated areas. The goal is to select data structures that provide the best balance between space complexity (memory usage) and time complexity (processing speed) for the specific task at hand, always keeping the hardware limitations of the drone in mind.
Speed and Reliability
In drone operations, particularly autonomous flight and real-time control, speed and reliability are paramount. A delay of milliseconds in processing sensor data or executing a command can have significant consequences. Data structures are designed to optimize specific operations like insertion, deletion, searching, and traversal. For example, a binary search tree allows for efficient searching, while a heap facilitates quick extraction of the minimum or maximum element, crucial for priority queues in scheduling tasks or pathfinding. The reliability of a drone’s software also benefits from well-understood and robust data structures, which reduce the likelihood of memory leaks, buffer overflows, or other common programming errors that can lead to system crashes. By carefully selecting and implementing data structures, engineers can ensure that the drone’s onboard systems operate with the required speed, responsiveness, and stability to perform complex and critical missions, cementing their role as indispensable components in the next generation of drone technology and innovation.