
In the rapidly evolving world of drone technology, the term “cores” refers to the fundamental processing units that serve as the brain of these sophisticated aerial vehicles. Far from being a simple mechanical device, a modern drone is a highly complex computational platform, and its capabilities – from stable flight to advanced autonomous functions – are inextricably linked to the power and efficiency of its onboard cores. These cores, predominantly found within System-on-Chips (SoCs) embedded in flight controllers and dedicated processing boards, are responsible for executing millions, if not billions, of calculations per second, enabling the intelligent behaviors that define contemporary drone innovation.
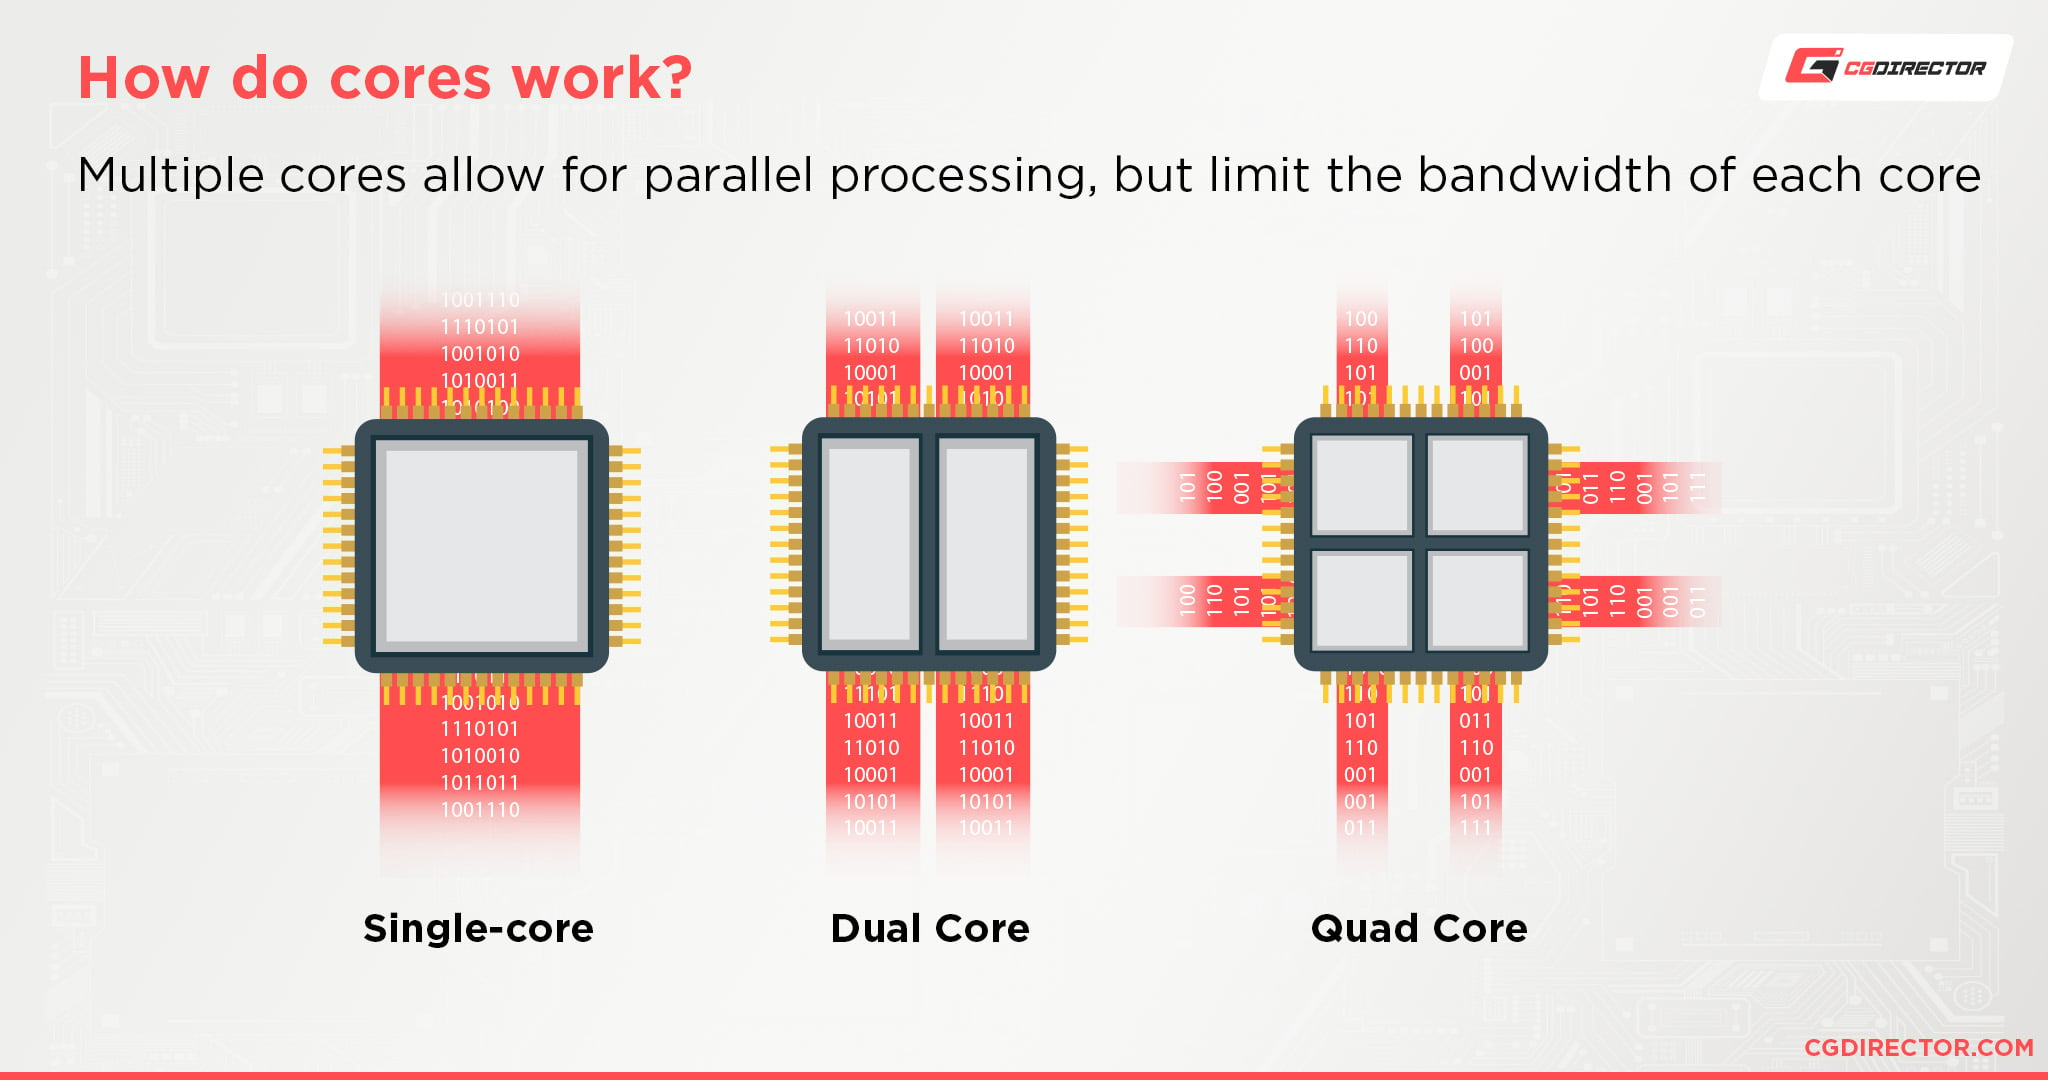
At its essence, a core is a processing unit capable of interpreting and executing program instructions. Historically, early drones relied on single, relatively simple microcontroller cores. However, as ambitions for drone functionality grew, necessitating real-time data analysis, complex decision-making, and sophisticated sensor fusion, the demand for more powerful, often multi-core, architectures skyrocketed. Today, “cores” in the drone context typically encompass a variety of specialized processing units working in concert: Central Processing Units (CPUs), Graphics Processing Units (GPUs), and increasingly, Neural Processing Units (NPUs) or dedicated AI accelerators. Understanding their interplay is crucial to appreciating the technological prowess behind the latest advancements in drone autonomy and intelligence.
The Centrality of Computational Cores in Drone Technology
Modern drones are not merely flying cameras; they are mobile data acquisition and processing hubs, making real-time decisions in dynamic environments. This level of sophistication demands robust computational power, which is delivered by an intricate network of specialized cores.
Beyond Basic Flight Control
The initial function of a drone’s onboard computing system was primarily flight stabilization and basic control. This involved interpreting sensor data from gyroscopes and accelerometers, executing PID (Proportional-Integral-Derivative) control loops, and sending commands to motor electronic speed controllers (ESCs). While crucial, these tasks are relatively simple compared to the demands of today’s intelligent drones. The paradigm shifted dramatically with the advent of features like GPS-guided navigation, waypoint following, and more recently, advanced autonomy. These capabilities require processing vast amounts of data from multiple sensors simultaneously, integrating diverse algorithms, and making complex decisions on the fly. This shift necessitated a move from basic microcontrollers to powerful SoCs featuring multiple, diverse cores.
Diverse Core Types and Their Roles
The “brain” of a modern drone is a heterogeneous computing environment, where different types of cores are optimized for specific tasks, working together to achieve overall system functionality.
-
CPU Cores: These are the general-purpose workhorses. CPU cores manage the drone’s operating system, handle high-level task scheduling, run flight control algorithms, and manage communication protocols. They are excellent at sequential processing and executing a wide variety of instructions. In a multicore CPU setup, different tasks can be assigned to different cores, improving overall responsiveness and allowing for concurrent operation of various drone subsystems. For example, one CPU core might handle sensor data acquisition, while another manages communication with the ground station, and a third executes high-level mission planning logic.
-
GPU Cores: Designed for parallel processing, GPUs excel at performing many similar computations simultaneously. In drones, GPUs are indispensable for computer vision tasks. This includes real-time processing of high-resolution video streams, object detection and tracking, visual simultaneous localization and mapping (VSLAM), and scene understanding. The ability of GPUs to rapidly process large matrices of data makes them ideal for the heavy computational lifting required for visual navigation and interpretation of the drone’s surroundings.
-
NPU/AI Accelerators: As drones become more intelligent, specialized cores for artificial intelligence (AI) and machine learning (ML) inference are becoming standard. NPUs are optimized for neural network computations, allowing drones to execute complex AI models efficiently at the edge. This enables real-time decision-making for features like autonomous obstacle avoidance, intelligent target recognition, predictive path planning, and advanced gesture control without relying on cloud processing, which can introduce latency. These accelerators are purpose-built for the mathematical operations common in neural networks, offering significant performance and power efficiency gains over general-purpose CPUs or even GPUs for specific AI workloads.
The orchestration of these diverse core types is what truly unlocks the advanced capabilities we see in contemporary drone technology, allowing for a seamless integration of flight control, perception, and intelligent decision-making.
Multicore Architectures: Powering Advanced Drone Functionalities
The evolution from single-core processors to sophisticated multicore and heterogeneous architectures has been pivotal in advancing drone capabilities. This shift addresses the inherent complexity and simultaneous demands of modern unmanned aerial vehicles.
The Need for Parallel Processing
A single core, no matter how fast, can only execute one instruction at a time. While it can context-switch rapidly between tasks, this sequential execution becomes a bottleneck when a drone needs to perform several critical, compute-intensive operations concurrently. Imagine a drone simultaneously needing to: maintain stable flight, process a 4K video stream for object detection, run a SLAM algorithm to map its environment, avoid dynamic obstacles, and communicate its telemetry to a ground station. Each of these tasks requires significant computational resources. A single core would struggle to keep up, leading to latency, errors, or a complete system failure. Multicore architectures overcome this limitation by allowing different tasks, or different parts of a single complex task, to be processed in parallel across multiple cores.
Advantages of Multicore Systems
Implementing multicore systems in drones offers several distinct advantages:
- Improved Throughput and Responsiveness: By distributing workloads across multiple cores, a drone can process more data and execute more instructions per unit of time. This directly translates to faster response times for flight controls, more fluid real-time video analysis, and quicker decision-making for autonomous functions.
- Enhanced Reliability and Redundancy: In some critical systems, tasks can be duplicated across cores or fall-back logic can be implemented, offering a degree of redundancy. While not true fault tolerance in all cases, the ability to isolate and manage tasks across cores can prevent a single computational bottleneck from crippling the entire system.
- Power Efficiency (in specific scenarios): Counter-intuitively, sometimes running multiple tasks on several lower-clocked, more power-efficient cores can consume less power than pushing a single high-frequency core to its limit. By distributing the load, cores can operate in more efficient power states, which is critical for extending drone flight times.
- Scalability: Multicore designs offer a path for future expansion. As new features and more complex algorithms are developed, adding more specialized cores or upgrading existing multicore SoCs allows for seamless integration of these advancements without a complete redesign of the underlying computational paradigm.
Heterogeneous Computing
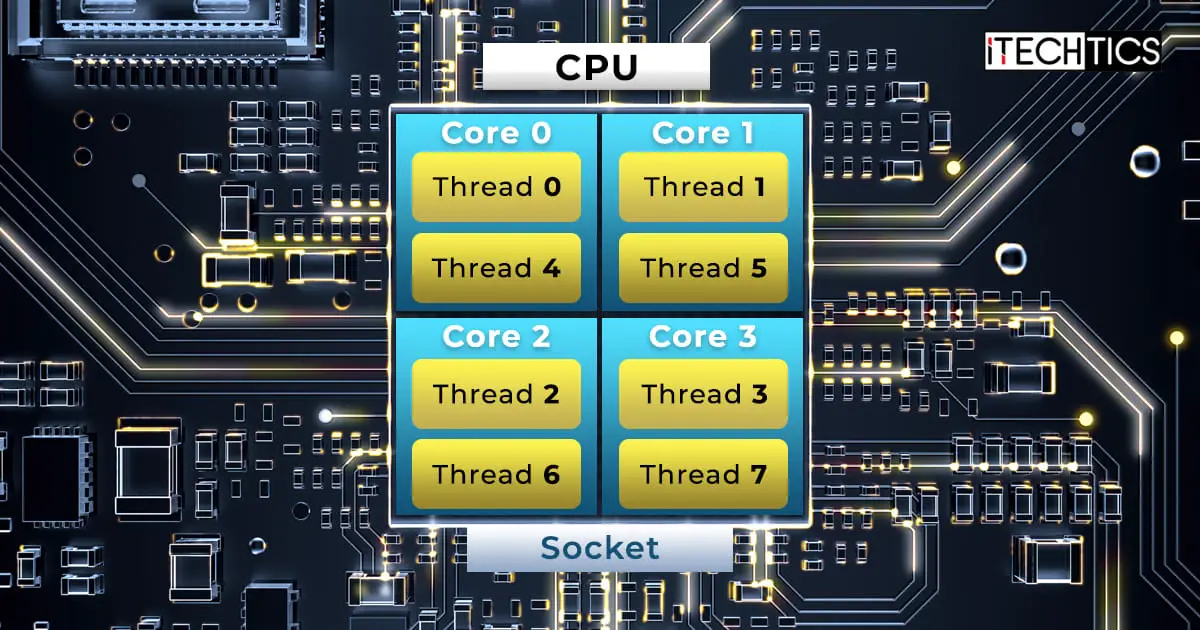
The latest trend in drone processing units is heterogeneous computing, where different types of cores (CPUs, GPUs, NPUs) are integrated onto a single chip. This approach capitalizes on the strengths of each core type: CPUs for general-purpose logic, GPUs for highly parallel data processing, and NPUs for AI inference. This synergistic model allows for unprecedented efficiency and power in a compact form factor. For example, a drone performing autonomous inspection might use its CPU cores for overall system management and flight stability, its GPU cores to process incoming video frames and identify anomalies, and its NPU cores to run a deep learning model that classifies the type of anomaly in real-time and determines the best course of action without human intervention. This specialized division of labor is crucial for achieving the sophisticated, real-time intelligence demanded by modern drone applications.
Cores in Action: Enabling AI, Autonomy, and Data Processing
The true impact of sophisticated core architectures is most evident in the advanced functionalities they enable, pushing the boundaries of what drones can achieve. These capabilities are central to the “Tech & Innovation” category, showcasing how computational power transforms drone operation.
AI Follow Mode and Object Tracking
Features like “AI Follow Mode” and sophisticated object tracking are prime examples of cores working in concert. When a drone is tasked to follow a subject, its camera stream is continuously fed to GPU and NPU cores. The NPU might run a lightweight neural network to detect and classify the target (e.g., a person, a car). Simultaneously, GPU cores can process optical flow or feature tracking algorithms to keep the target centered in the frame, even if the AI model briefly loses track. CPU cores then interpret these visual cues and translate them into precise flight commands, adjusting the drone’s position, altitude, and gimbal angle in real-time. The computational demand here is immense: real-time video decoding, object detection, position estimation, and flight command generation all happening concurrently, requiring high throughput and low latency from the core system.
Autonomous Flight and Navigation
True autonomous flight goes far beyond pre-programmed waypoints. It involves a drone making intelligent decisions about its path, speed, and actions based on its immediate environment. This relies heavily on cores processing data from an array of sensors: Lidar, sonar, visual cameras, IMUs (Inertial Measurement Units), and GPS.
- SLAM (Simultaneous Localization and Mapping): GPU cores rapidly process visual or Lidar data to build a 3D map of the environment while simultaneously determining the drone’s precise location within that map.
- Path Planning and Obstacle Avoidance: CPU cores, often assisted by NPUs for predictive analysis, use this environmental map to calculate optimal, collision-free flight paths. For dynamic obstacles, NPU cores can quickly identify potential threats and trigger evasive maneuvers, ensuring safety without human intervention.
- Decision-Making Under Uncertainty: Advanced autonomous drones must cope with unforeseen circumstances. Here, CPU cores manage complex state machines, while NPUs can process sensor data to infer environmental changes and adapt mission parameters dynamically.
Mapping and Remote Sensing
Drones equipped with high-resolution cameras, multispectral sensors, or thermal imagers are invaluable tools for mapping and remote sensing in fields like agriculture, construction, and environmental monitoring. The data collected can be vast, often consisting of thousands of high-resolution images or gigabytes of sensor readings.
- Onboard Processing: While much of this data is traditionally processed post-flight on powerful ground stations, an increasing trend is to perform significant processing onboard, at the “edge.” GPU cores are essential for stitching together hundreds of images into orthomosaics, generating digital elevation models (DEMs), or even performing initial analysis like identifying crop health anomalies using multispectral data.
- Real-time Analysis: For critical applications, like identifying a hot spot in a wildfire or a structural defect during an inspection, NPU cores can run AI models to analyze thermal or visual data in real-time, immediately alerting operators to urgent situations. This reduces the time-to-insight and can be crucial for rapid response.
Edge Computing and Real-time Decision Making
The ability to perform complex computations directly on the drone – known as edge computing – is a cornerstone of modern drone innovation. Relying solely on ground control or cloud processing for mission-critical tasks introduces latency that can be unacceptable for autonomous flight, collision avoidance, or immediate data analysis. Cores, particularly specialized NPUs, enable drones to:
- Process data locally: Reducing the need to transmit large datasets, thus conserving bandwidth and improving privacy.
- Make instantaneous decisions: Essential for reactive behaviors like evasive maneuvers or precise object manipulation.
- Operate in communication-denied environments: Allowing drones to maintain full autonomy even when GPS signals are jammed or network connectivity is lost.
The distributed intelligence across these sophisticated core architectures allows drones to operate with unprecedented levels of autonomy, precision, and efficiency, transforming their utility across a multitude of industries.
Optimizing Core Performance for Enhanced Drone Capabilities
The relentless pursuit of greater drone intelligence and capability continuously drives innovation in core design and optimization. Balancing raw processing power with practical constraints is a perpetual challenge.
Power Efficiency vs. Performance
One of the most significant trade-offs in drone core design is the delicate balance between computational performance and power consumption. More powerful cores typically consume more energy, directly impacting battery life and, consequently, flight duration. Engineers constantly strive to design architectures that maximize computational output per watt. This involves:
- Optimized instruction sets: Designing cores to perform specific drone-related tasks more efficiently.
- Dynamic voltage and frequency scaling (DVFS): Allowing cores to adjust their operating speed and voltage based on the current workload, saving power during less demanding phases.
- Low-power sleep states: Enabling individual cores or entire processing units to enter low-power modes when idle.
- Heterogeneous integration: As discussed, assigning tasks to the most power-efficient core type (e.g., NPU for AI, CPU for general tasks) is key to overall system efficiency. The goal is to deliver “just enough” processing power for the task at hand without overspending on energy.
Software Optimization and Middleware
Hardware is only half the equation; efficient software is equally critical for unlocking a drone’s full potential. The operating system, drivers, and middleware must be meticulously optimized to effectively utilize multicore architectures.
- Real-time Operating Systems (RTOS): Many drones run RTOS to ensure predictable and timely execution of critical flight control tasks. These operating systems are designed to manage processor time precisely across multiple cores.
- Parallel Programming Frameworks: Developers leverage frameworks like OpenCL or CUDA (for GPUs) to write code that can effectively utilize the parallel processing capabilities of multicore systems, ensuring tasks are efficiently distributed.
- Middleware like ROS (Robot Operating System): ROS provides a flexible framework for building complex robot applications, including drones. It facilitates communication between different processes (nodes), which can run on different cores, enabling modular and scalable software architectures that exploit the underlying hardware.
- Firmware and Driver Efficiency: Low-level firmware and hardware drivers must be highly optimized to minimize overhead and ensure that cores can communicate with sensors and actuators with minimal latency.
Future Trends: Specialized Cores and Edge AI Hardware
The future of drone core technology promises even greater specialization and integration.
- More Specialized AI Accelerators: Expect to see even more efficient and powerful NPUs, potentially with novel architectures optimized for specific types of neural networks or machine learning tasks relevant to drone operations (e.g., sparse neural networks for low-power visual processing).
- Neuromorphic Chips: Inspired by the human brain, these chips could offer extremely low-power, event-driven processing, ideal for always-on perception and ultra-fast, adaptive decision-making on drones. While still largely in research, they hold immense promise for true cognitive autonomy.
- Custom SoC Design: As drone capabilities become more diverse, there will be a continued trend towards highly customized SoCs designed specifically for drone applications, integrating a precise mix of CPU, GPU, NPU, and even application-specific integrated circuits (ASICs) onto a single die for maximum efficiency and performance.
- Quantum Computing Influence (Long-term): While not directly integrating quantum cores into drones in the near future, advancements in quantum computing could eventually influence ground-based drone mission planning, optimization, and complex data analysis, pushing the boundaries of what autonomous systems can achieve.
The continuous evolution of computational cores and their software ecosystems is not just about making drones faster; it’s about making them smarter, safer, and more capable, unlocking new applications and expanding their utility across an ever-growing array of industries. The core, in every sense of the word, remains at the heart of this transformative technological journey.