
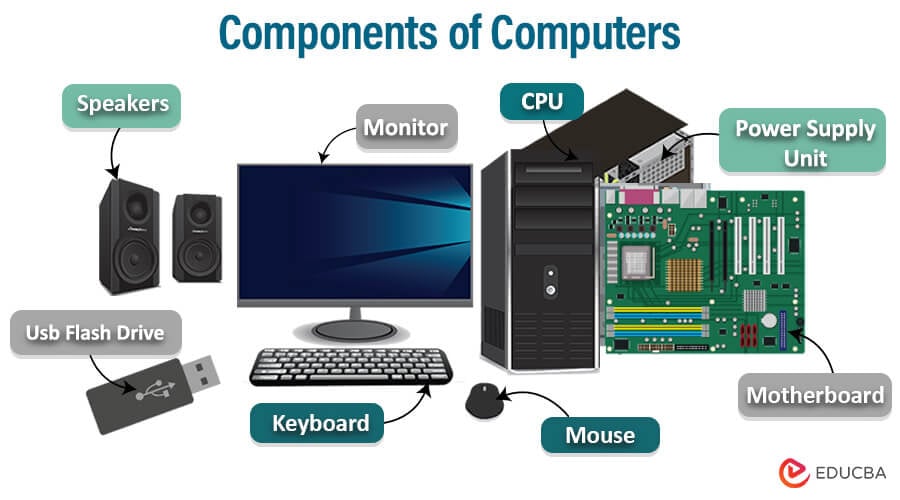
The fascinating world of modern aviation, particularly in the realm of unmanned aerial vehicles (UAVs) and drones, is underpinned by an intricate array of computer components working in concert. Far from being mere electromechanical devices, these flying machines are sophisticated mobile computing platforms. Understanding “what is a computer components” in this context involves delving into the specialized hardware and software that enable flight, navigation, stability, and intelligent operation. These components are meticulously designed to withstand the unique challenges of aerial environments, from vibration and temperature fluctuations to power efficiency and real-time processing demands, fundamentally defining the capabilities of modern flight technology.
The Central Command: Flight Controllers
At the core of any drone’s flight technology lies the flight controller (FC), often referred to as the brain of the operation. This complex circuit board is a specialized embedded computer system designed to interpret pilot commands, process sensor data, and execute precise instructions to maintain stable flight. The efficiency and responsiveness of the flight controller are paramount, dictating everything from a drone’s agility to its ability to hover precisely in adverse conditions.
Microcontrollers and Processors
The heart of the flight controller is its microcontroller unit (MCU) or a more powerful microprocessor. These tiny but mighty computing elements are responsible for executing the flight control algorithms. For simpler drones, an 8-bit or 32-bit MCU (such as those based on ARM Cortex-M architecture) might suffice, handling basic sensor input and motor control loops. However, advanced drones, especially those designed for autonomous flight, complex acrobatics, or heavy payloads, often employ more robust processors with higher clock speeds and greater processing capabilities. These powerful processors can manage multiple data streams simultaneously, perform complex calculations for advanced navigation and obstacle avoidance, and even run AI algorithms for intelligent flight modes. The choice of processor directly impacts the flight controller’s ability to handle sophisticated tasks and process data with minimal latency, a critical factor for stable and responsive flight.
Firmware and Operating Systems
Complementing the hardware, specialized firmware and sometimes a real-time operating system (RTOS) are integral “computer components” within the flight controller. Firmware, such as Betaflight, ArduPilot, or PX4, is the software program that dictates how the microcontroller interprets commands and manages flight. It contains complex algorithms for PID (Proportional-Integral-Derivative) control, which continuously adjust motor speeds to correct deviations from the desired flight path or attitude. An RTOS ensures that critical flight tasks, like reading sensor data and sending commands to motors, are executed within strict time constraints, preventing delays that could lead to instability or crashes. The open-source nature of much of this firmware allows for extensive community development, pushing the boundaries of drone capabilities through continuous innovation and optimization of these vital software components.
Sensing the World: Inertial Measurement Units (IMUs) and Navigation
For a drone to fly autonomously or even maintain stable manual flight, it must accurately perceive its own orientation, position, and movement in three-dimensional space. This sensory input is provided by a suite of “computer components” collectively known as the Inertial Measurement Unit (IMU) and other navigational sensors. These components are critical for real-time data acquisition, feeding continuous streams of information to the flight controller for processing and decision-making.
Accelerometers and Gyroscopes
The core of any IMU consists of accelerometers and gyroscopes. Accelerometers measure linear acceleration along three axes (X, Y, Z), providing data on the drone’s translational movement and helping to determine its orientation relative to gravity. Gyroscopes, on the other hand, measure angular velocity, detecting the rate of rotation around each of the three axes (roll, pitch, yaw). By integrating the data from these sensors over time, the flight controller can determine the drone’s current attitude (orientation) and how it’s changing. Advanced IMUs often incorporate robust kalman filters or complementary filters within their hardware or firmware to fuse accelerometer and gyroscope data, reducing noise and drift to provide a highly accurate estimate of the drone’s orientation, which is crucial for precise stabilization.
Barometers and Magnetometers
To achieve stable altitude holding and understand its heading, a drone relies on barometers and magnetometers. A barometer is a pressure sensor that measures atmospheric pressure, which decreases predictably with altitude. This allows the flight controller to estimate the drone’s height above the ground or sea level. Precise barometric data is essential for accurate altitude hold modes and for preventing unwanted vertical drift. A magnetometer, often referred to as an electronic compass, measures the strength and direction of magnetic fields. By detecting the Earth’s magnetic field, the magnetometer helps the flight controller determine the drone’s absolute heading (which way it’s pointing) relative to magnetic North. This is vital for consistent navigation, especially in GPS-denied environments or when GPS signals are weak, ensuring the drone can maintain a desired flight path or orientation.
GPS Modules
Global Positioning System (GPS) modules are indispensable “computer components” for outdoor flight technology, providing highly accurate positional data. A GPS receiver processes signals from orbiting satellites to triangulate the drone’s precise latitude, longitude, and altitude. This information is critical for navigation features such such as “Return-to-Home,” waypoint navigation, and autonomous flight paths. Modern GPS modules often incorporate additional satellite navigation systems like GLONASS, Galileo, and BeiDou (collectively GNSS) to improve accuracy and reliability, especially in challenging environments where line-of-sight to satellites may be partially obstructed. Some advanced systems also integrate RTK (Real-Time Kinematic) or PPK (Post-Processed Kinematic) technology, which use ground-based reference stations to achieve centimeter-level positioning accuracy, essential for professional mapping, surveying, and precise autonomous operations.
Powering and Directing Movement: Electronic Speed Controllers (ESCs) and Servos
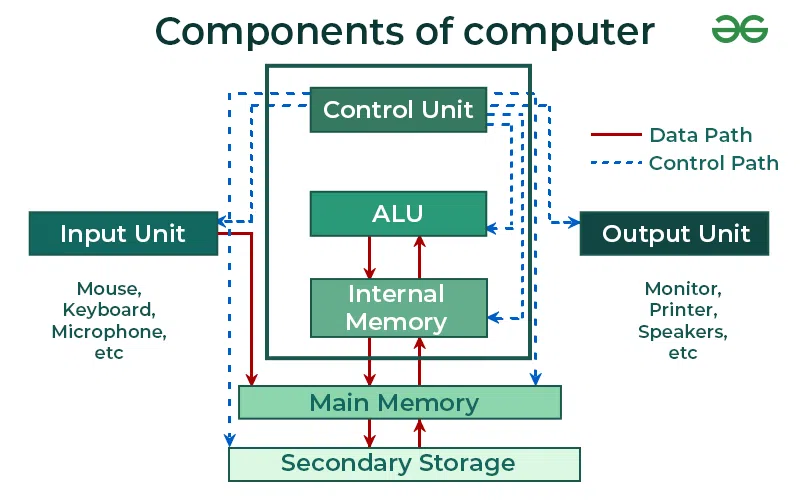
While the flight controller is the brain, the Electronic Speed Controllers (ESCs) and various servos act as the nervous system and muscles, translating the flight controller’s commands into physical action. These components are critical for regulating the power delivered to the motors and controlling other movable parts, directly dictating the drone’s thrust and maneuverability.
Motor Control Principles
ESCs are sophisticated microcontrollers themselves, specifically designed to convert the low-power control signals from the flight controller into the high-power electrical pulses required to spin brushless DC motors at precise speeds. In a multirotor drone, each motor has its own ESC, allowing the flight controller to independently adjust the thrust of each propeller. This precise and rapid control over individual motor speeds is fundamental to how a drone hovers, moves, and turns. The ESCs handle the commutation of the motor windings, manage current flow, and provide feedback on motor RPM, ensuring efficient and responsive thrust generation. Advanced ESCs incorporate their own firmware (e.g., BLHeli, AM32, KISS) which can be tuned to optimize motor response, efficiency, and safety features like overcurrent protection.
Actuators and Gimbal Control
Beyond basic motor control, various other actuators, often powered by servos, are crucial “computer components” in more complex flight systems. Servos are small, geared DC motors that can be precisely positioned to a specific angle. They are commonly used in fixed-wing drones to move control surfaces like ailerons, elevators, and rudders, enabling directional flight. In camera drones, servos are integral to gimbal systems, stabilizing the camera platform and allowing for precise control over its pan, tilt, and roll axes. This stabilization isolates the camera from the drone’s movements, ensuring smooth, cinematic footage regardless of flight dynamics. The control signals for these servos originate from the flight controller, which interprets pilot commands or executes autonomous algorithms to achieve desired camera angles or flight paths.
Communication and Connectivity: Telemetry and Data Links
Effective communication is another critical aspect of modern flight technology, allowing for real-time control, monitoring, and data transmission between the drone, its pilot, and potentially other ground systems. The “computer components” facilitating this include sophisticated radio transceivers and data processing units.
Radio Transceivers
Radio transceivers are the primary means by which pilot commands are transmitted to the drone and telemetry data is sent back to the ground station. These modules operate on various radio frequencies (e.g., 2.4 GHz, 5.8 GHz, 900 MHz) and utilize complex modulation and demodulation techniques to ensure reliable, low-latency communication. For control, the pilot’s remote controller contains a transmitter, while the drone houses a receiver connected to the flight controller. For video transmission (especially in FPV systems), separate video transmitters (VTX) and receivers (VRX) are used, often employing digital protocols for higher quality and range. Long-range systems may use frequency hopping spread spectrum (FHSS) or direct sequence spread spectrum (DSSS) technologies to enhance signal robustness and resistance to interference, critical for maintaining command links over greater distances.
Data Processing Units for Telemetry
Telemetry refers to the automated communication processes by which measurements and other data are collected at remote or inaccessible points and transmitted to receiving equipment for monitoring. Onboard data processing units, often integrated into the flight controller itself or as separate companion computers, compile critical flight information such as altitude, speed, GPS coordinates, battery voltage, and sensor readings. This processed data is then transmitted back to the ground station via the radio transceiver. At the ground station, dedicated software applications display this telemetry data in real-time, providing the pilot with crucial situational awareness and allowing for informed decision-making. Advanced telemetry systems can also facilitate two-way communication, enabling the drone to receive complex mission parameters or software updates remotely, blurring the lines between a simple remote-controlled aircraft and a networked, intelligent aerial platform.
Memory and Storage: Recording and Processing Data Onboard
Just like any computer, drones require various forms of memory and storage to operate efficiently, store mission-critical data, and log flight parameters. These “computer components” are crucial for both real-time operations and post-flight analysis.
Flash Memory and SD Cards
Flash memory, often integrated directly into the microcontroller of the flight controller, serves as firmware storage, holding the operating instructions and configuration settings that define the drone’s behavior. This non-volatile memory ensures that the drone retains its programming even when powered off. Additionally, many drones, especially those used for mapping, surveying, or professional cinematography, incorporate removable SD cards or other forms of solid-state storage. These external storage components are vital for recording high-resolution sensor data, such as images from an onboard camera, lidar scans, or detailed flight logs. The speed and capacity of these storage solutions directly impact the drone’s ability to capture and retain vast amounts of data during missions, enabling sophisticated post-processing and analysis.
RAM for Real-time Operations
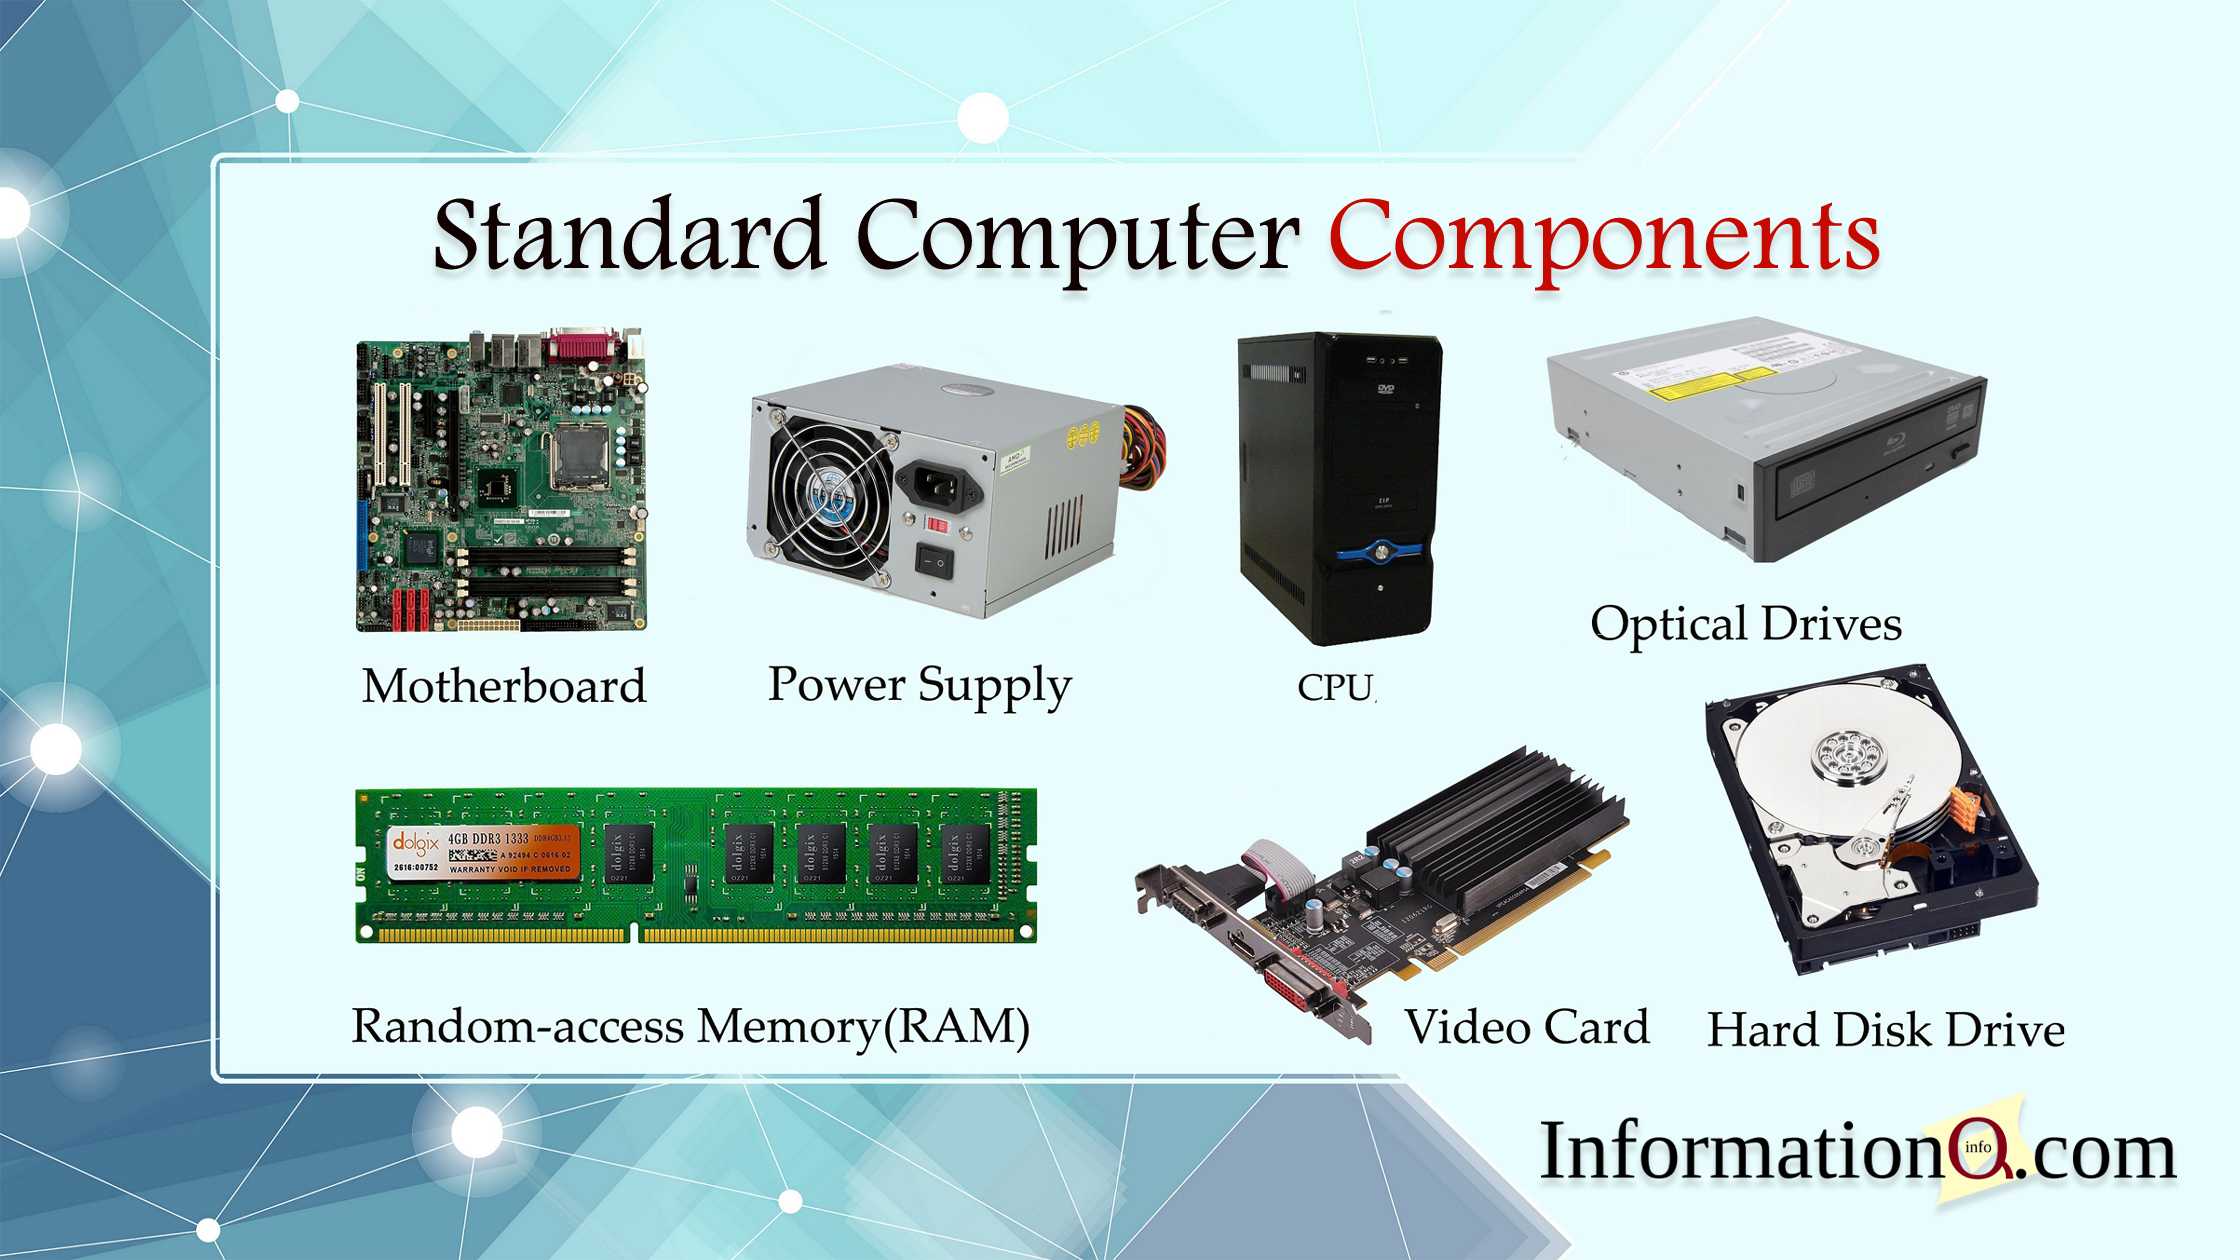
Random Access Memory (RAM) is another indispensable “computer component” for the flight controller and any onboard companion computers. Unlike flash storage, RAM is volatile memory used for active data processing during flight. It temporarily stores the flight controller’s active instructions, sensor readings, and calculated parameters that are constantly being updated by the firmware. The amount and speed of RAM directly influence the flight controller’s ability to perform complex calculations in real-time, manage multiple simultaneous processes (such as stabilization, navigation, and obstacle avoidance), and maintain system responsiveness. Sufficient and fast RAM is critical for ensuring that the drone can react instantaneously to environmental changes and pilot commands, maintaining stable and predictable flight performance.