
In the relentless pursuit of innovation, engineers and designers frequently turn to nature for inspiration. This practice, known as biomimicry, harnesses millions of years of evolutionary optimization to solve complex technological challenges. While the term “cloven hooves” might conjure images of wildlife roaming diverse landscapes, their ingenious biological design offers profound lessons for the advancement of unmanned aerial vehicles (UAVs) and ground robotics, particularly within the realm of Tech & Innovation, focusing on how drones interact with unpredictable environments.
Biomimicry in Unmanned Systems Design
The sophistication of animal locomotion, perfected over eons, presents a rich catalog of solutions for problems encountered in robotics and autonomous systems. For drones, while mastery of the skies is rapidly advancing, the challenge of stable, reliable interaction with the ground remains a significant frontier. Traditional drone designs often feature simplistic landing skids or rigid landing gear, which are adequate for flat, prepared surfaces but fall short in complex, uneven, or unstable terrain. This limitation restricts their operational versatility and safety, especially when missions require precision landing, perching, or transitioning to ground-based mobility.

The Stability Challenge in Diverse Terrains
Drones are increasingly deployed for tasks demanding deployment in environments far from manicured runways. Consider infrastructure inspection of remote bridges, power lines spanning rugged mountains, or environmental monitoring in dense forests or marshlands. These scenarios necessitate a drone that can not only navigate challenging airspace but also interact safely and effectively with highly irregular ground surfaces. Current landing solutions struggle with:
- Uneven Ground: Rocks, inclines, roots, and debris can cause conventional landing gear to tip, snag, or suffer damage.
- Soft or Muddy Surfaces: Skids or small wheels can sink, destabilizing the drone or trapping it.
- Slippery Conditions: Ice, wet rock, or loose gravel offer poor traction, risking uncontrolled movement post-landing.
- Shock Absorption: Hard landings on rigid gear can transmit damaging forces to sensitive onboard electronics or payloads.
The ability to land stably, perch securely, and potentially transition to ground locomotion in such varied conditions is a critical bottleneck for many advanced drone applications. This is where the wisdom of natural design, such as that found in cloven hooves, offers a compelling blueprint for innovation.
Inspired by Nature: Grip and Adaptability
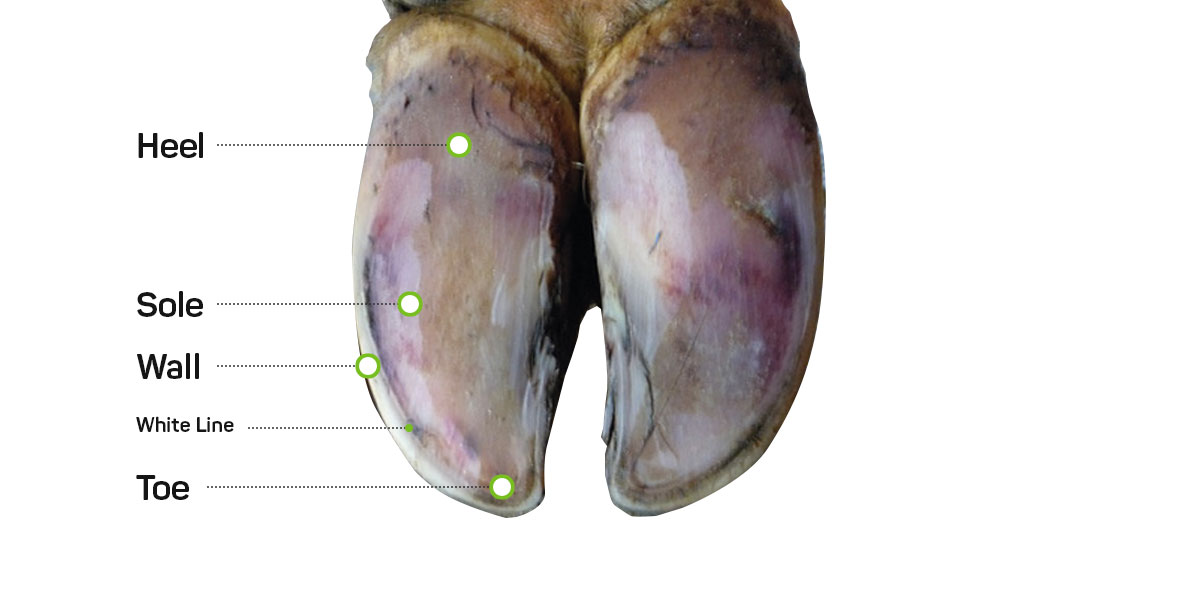
A cloven hoof, found in animals like deer, goats, and cattle, is a marvel of natural engineering. Its primary characteristic is the split into two distinct, flexible digits (cleaves), each encased in a tough, keratinous material. This seemingly simple design provides an extraordinary array of advantages:
- Enhanced Grip: The two cleaves can spread apart or come together, allowing the hoof to conform to irregular surfaces. On rocky terrain, they can ‘pinch’ around obstacles for superior grip. On soft ground, they spread to distribute weight more broadly, preventing sinking.
- Stability on Slopes: The ability to articulate independently allows the animal to maintain a stable stance even on steep or uneven inclines, with each cleave adjusting to the local contours.
- Shock Absorption: The inherent flexibility and natural padding within the hoof structure provide excellent shock absorption, protecting the animal’s limbs from the impact of movement.
- Adaptability to Terrain: Whether traversing rocky inclines, muddy plains, or snowy paths, the cloven hoof demonstrates remarkable versatility.
By studying these biomechanical principles, drone engineers can envision novel landing and ground interaction systems that move beyond rigid, one-size-fits-all solutions. The goal is to imbue drones with a similar level of adaptive stability and robust ground interaction.
From Biology to Robotics: Applying Principles
Translating the elegant biology of cloven hooves into functional drone technology requires a multidisciplinary approach, combining advanced materials science, precise robotics, and sophisticated control algorithms. The challenge lies in creating systems that are lightweight, energy-efficient, and capable of dynamic responses mirroring natural adaptability.
Hoof-Inspired Landing Gear Concepts
The most direct application of cloven hoof principles to drone technology involves designing multi-articulated landing gear. Imagine drone “feet” composed of two or more segments that can independently flex, spread, and grip. These conceptual designs might feature:
- Articulated Segments: Instead of a single skid or leg, multiple smaller ‘toes’ or ‘cleaves’ that can move relative to each other. These could be actuated by miniature motors, micro-servos, or even smart materials like shape memory alloys (SMAs) that change form in response to electrical current or temperature.
- Conforming Materials: The outer surfaces could incorporate compliant materials with high friction coefficients, mimicking the rubbery pads found in animal paws, or textured surfaces similar to hoof material for enhanced grip on various substrates.
- Passive Flexibility with Active Control: Some designs might prioritize passive flexibility for shock absorption and initial terrain conformity, supplemented by active control for fine-tuning grip and stability once ground contact is made.
- Perching Capabilities: An advanced version could allow drones not just to land, but to ‘perch’ on narrow ledges, branches, or power lines, using a similar clamping or gripping action inspired by the hoof’s ability to encircle irregular shapes.
These hoof-inspired landing gear concepts aim to provide drones with unprecedented stability, reduce the risk of damage during landing, and expand the range of environments where they can safely operate.
Dynamic Stabilization in Uneven Landscapes
Beyond the physical design of the landing gear, implementing the full potential of biomimicry requires sophisticated dynamic control systems. This involves enabling the drone to sense its environment, predict ground interaction, and actively adjust its ‘hooves’ and attitude for optimal stability.
- Sensor Integration: Lidar, stereo vision cameras, and tactile sensors embedded in the landing gear would provide real-time data about terrain topography, surface texture, and contact forces.
- Predictive Algorithms: Machine learning algorithms could analyze sensor data during descent to anticipate the optimal landing strategy, determining where to place each ‘cleave’ and how much to spread or grip.
- Active Post-Landing Adjustment: Once initial ground contact is made, the drone’s flight controller, in conjunction with its actuated landing gear, could actively adjust its balance, pitch, and roll to maintain stability on uneven ground, much like an animal subtly shifting its weight. This could involve small thrust adjustments or fine movements of the articulated ‘hooves’.
- Integrated Flight and Ground Control: A seamless transition from aerial maneuvering to ground stabilization would be crucial, requiring a unified control architecture that manages both flight surfaces/propellers and landing gear actuators.
These dynamic stabilization systems represent a significant leap from current passive landing approaches, enabling drones to become truly adaptive to their physical surroundings.
Future Innovations: Autonomous Ground Interaction
The ultimate vision for integrating biomimicry into drone technology is the creation of fully autonomous, multi-modal systems capable of seamlessly transitioning between flight and ground interaction, mimicking the natural world’s agility and resilience.
AI and Adaptive Mobility Systems
Artificial intelligence will be the cornerstone of enabling drones to interpret complex environmental cues and make intelligent, real-time decisions about ground interaction.
- Terrain Understanding: Advanced AI models, trained on vast datasets of varied terrains, can enable drones to not just see, but understand the ground, identifying safe landing zones, potential obstacles, and optimal grip points.
- Autonomous Planning: AI can generate optimal landing and ground movement paths, taking into account wind, payload, terrain stability, and mission objectives.
- Learning from Experience: Through reinforcement learning, drones could improve their ground interaction strategies over time, accumulating experience from diverse landings and ground maneuvers.
- Robotic-Aerial Hybrids: This extends to the development of drone-robot hybrids that can land, detach their flying module, and then use integrated ground mobility (e.g., small wheels or legs built into the landing gear) to traverse terrain for inspection or data collection, reconnect, and fly away.
This level of autonomy would enable drones to operate in environments previously deemed inaccessible or too hazardous for human operators.
Multi-Modal Locomotion for Drones
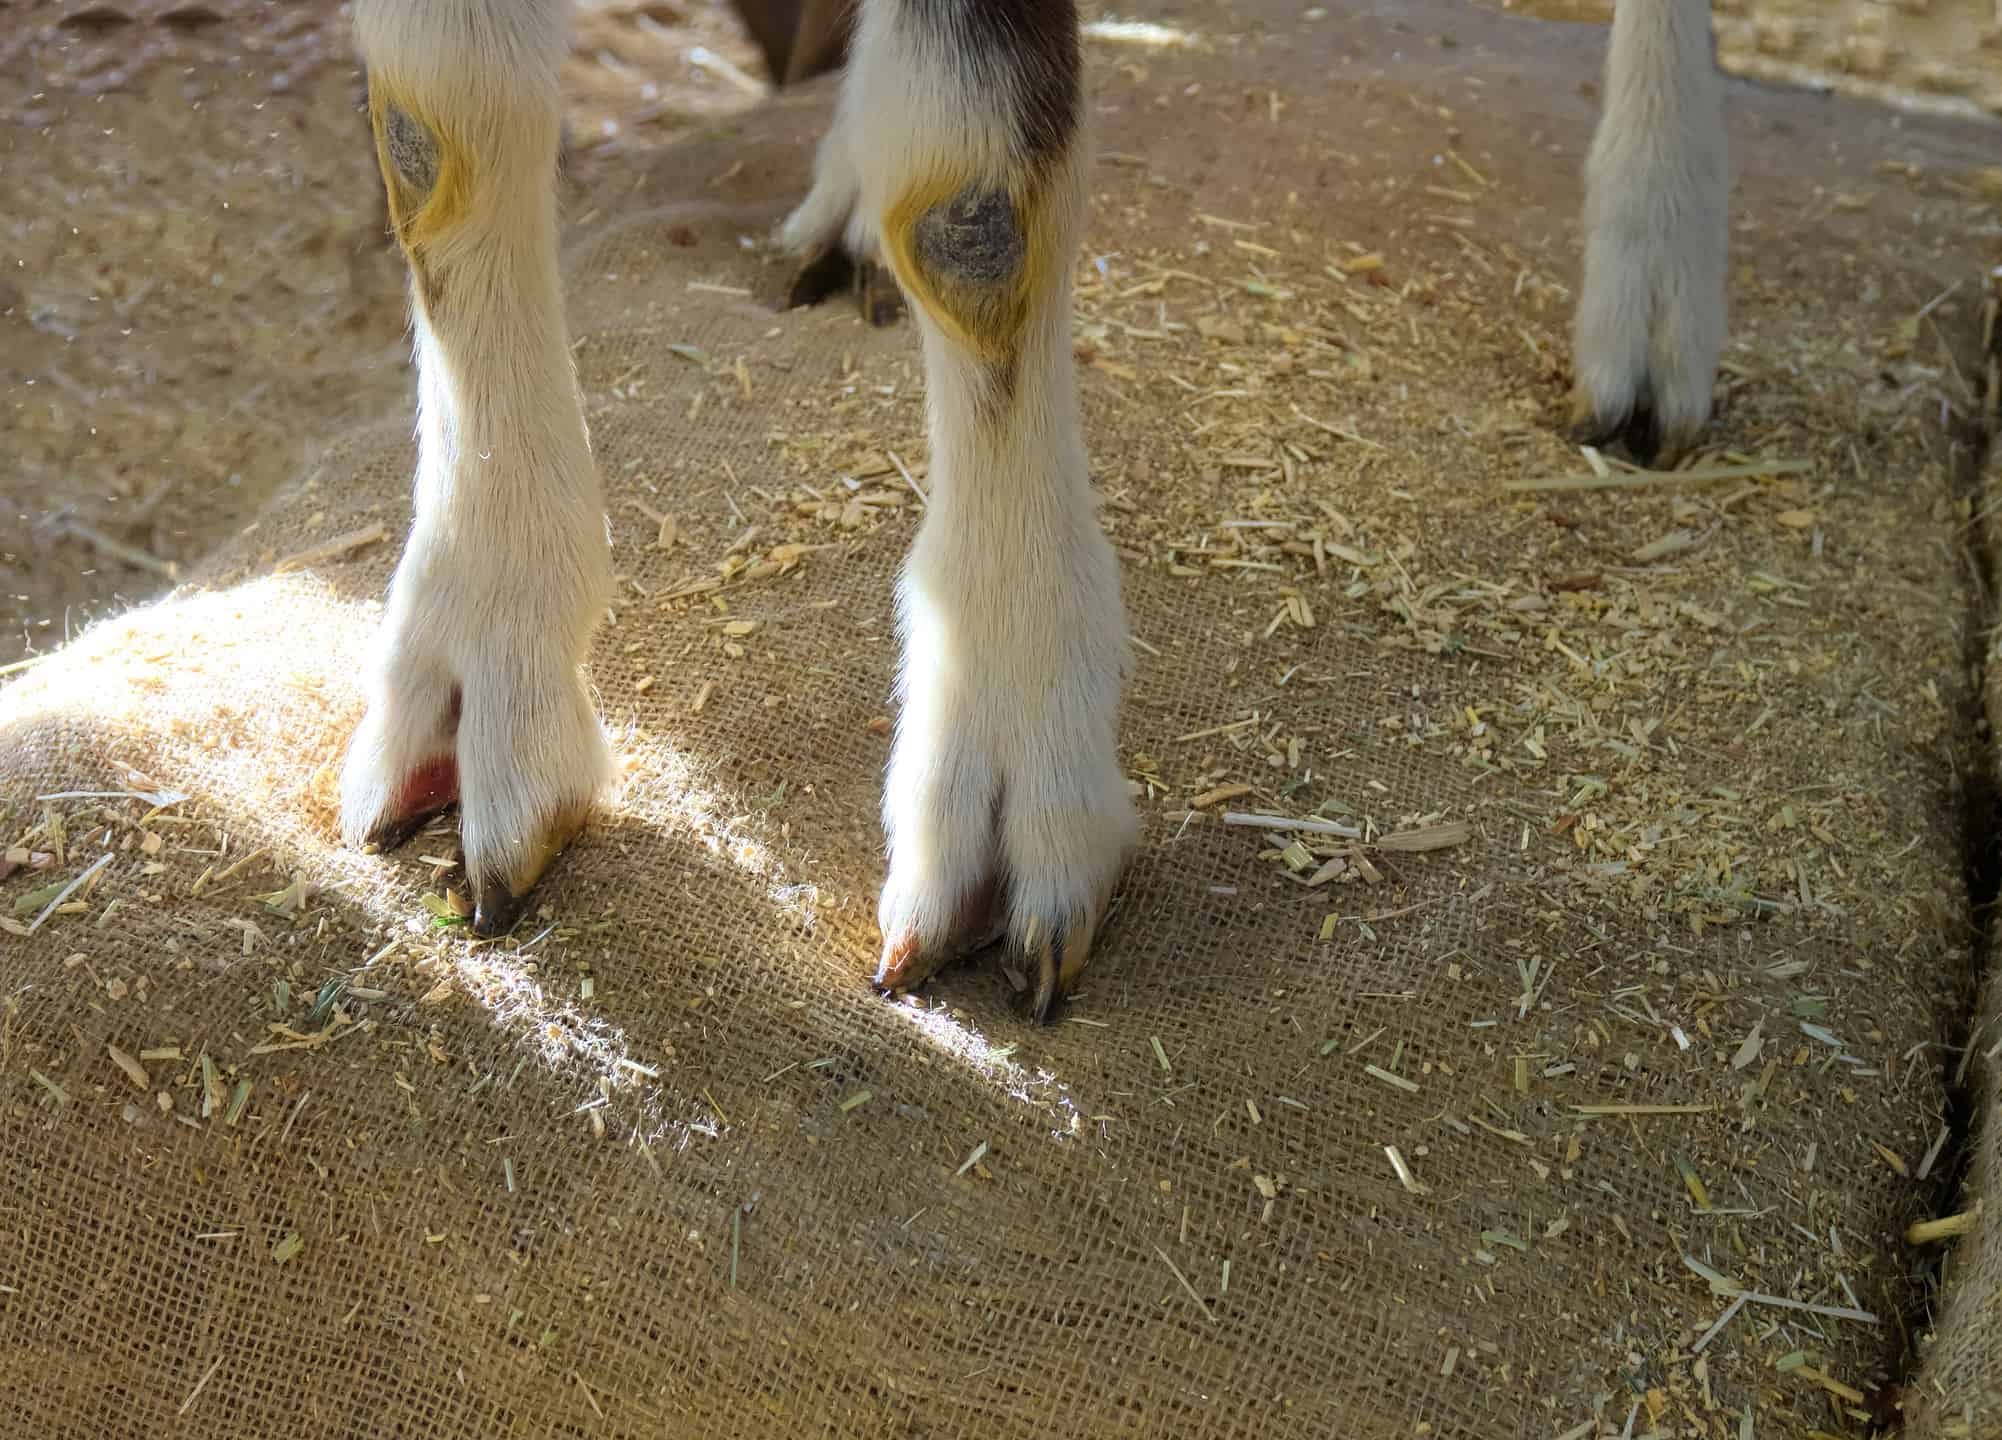
The aspiration is to develop drones that are not merely flying machines but fully integrated air-ground platforms. The cloven hoof, in its elegant simplicity, embodies the concept of robust mobility across diverse and unpredictable landscapes. This biological inspiration directly translates into the engineering goal of multi-modal locomotion for UAVs.
Imagine a drone that can fly hundreds of miles to a remote disaster site, land with pinpoint accuracy on a pile of rubble using its adaptive, hoof-like landing gear, then reconfigure itself to crawl through tight spaces for victim search, and finally take off again to relay information. Or a delivery drone that can navigate complex urban environments, landing on an uneven rooftop or navigating a cluttered backyard to drop off a package precisely.
The integration of advanced sensing, AI-driven decision-making, and bio-inspired mechanical designs will unlock new operational capabilities for drones in fields ranging from environmental monitoring and infrastructure inspection to search and rescue and defense. The journey from observing the adaptive grip of a cloven hoof to engineering complex, intelligent robotic systems represents a pinnacle of technological innovation, bridging the gap between nature’s wisdom and human ingenuity to create truly robust and versatile unmanned systems.