
The “Pikachu” Module: A Foundation for Agile Autonomy
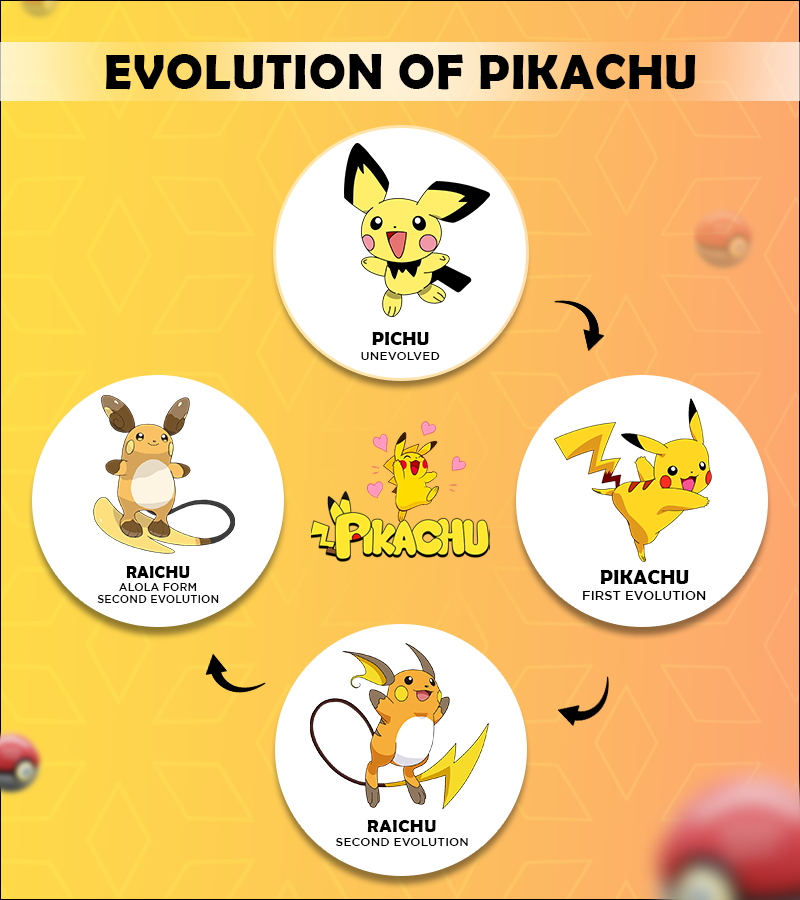
In the rapidly accelerating world of autonomous systems and intelligent robotics, the foundational components that drive decision-making and real-time adaptation are paramount. Within advanced development circles, a particular, highly efficient AI processing unit, often internally codenamed “Pikachu” due to its energetic operational profile and compact design, has emerged as a crucial element. This module represents a paradigm shift in edge computing, offering a potent blend of low power consumption and robust processing capabilities. At its inception, the “Pikachu” unit was designed with an inherent capacity for scalability, intended to serve as the brain for sophisticated aerial platforms and ground-based autonomous vehicles alike. Its initial “level” of operation focused on core data ingestion, basic pattern recognition, and the execution of pre-programmed flight paths or movement sequences.
Defining the Core Autonomous Intelligence
The “Pikachu” module’s architecture is rooted in a highly optimized neural network, specifically tailored for rapid inference at the edge. Unlike larger, cloud-dependent AI systems, “Pikachu” is built for immediate, on-device computation, minimizing latency and enhancing responsiveness in dynamic environments. Its core intelligence revolves around efficient sensor data fusion – integrating inputs from optical, thermal, lidar, and inertial measurement units – to construct a coherent understanding of its surroundings. This initial capability level provides robust environmental awareness, crucial for basic navigation and obstacle detection, laying the groundwork for more complex interactions.
Early Stage Capabilities and Baseline Performance
At its baseline, the “Pikachu” module excels in executing deterministic tasks. This includes maintaining stable flight dynamics, performing precise waypoint navigation, and identifying common environmental features. Its energy-efficient design, drawing inspiration from high-performance embedded systems, allows for extended operational durations, making it suitable for long-duration surveillance, infrastructure inspection, and preliminary mapping missions. However, this initial level, while competent, represents a reactive form of autonomy, primarily responding to immediate sensor inputs rather than anticipating future states or learning from novel experiences. The true potential of “Pikachu” lies in its capacity for “evolution,” a process unlocked by exposing it to increasingly complex operational demands.
Catalysts for Evolution: The “Fire Red” Operational Imperative
The concept of “evolution” for the “Pikachu” module is not a natural biological process but a deliberate and intensive technological advancement driven by specific, high-stakes operational requirements. This is where the “Fire Red” imperative comes into play. “Fire Red” is a project designation within our advanced R&D initiatives, signifying a suite of demanding, mission-critical scenarios characterized by extreme environmental variability, dynamic threat landscapes, and an urgent need for adaptive intelligence. These scenarios, often involving rapid response, disaster management, or complex urban reconnaissance, push the boundaries of current autonomous capabilities.
High-Demand Environments and Data Overload
The “Fire Red” environments are a crucible for advanced autonomy. They often involve situations where sensor data is incomplete or corrupted, communication links are intermittent, and real-time decision-making under uncertainty is paramount. Imagine a drone navigating a smoke-filled building during an emergency, identifying structural weaknesses, or a UAV performing search and rescue in a heavily forested, unmapped region. In such contexts, the sheer volume and complexity of data, combined with the criticality of the mission, necessitate an AI system that can not only process information rapidly but also prioritize, filter noise, and make educated inferences from partial datasets. This data overload, coupled with the need for immediate action, acts as a primary catalyst for the “Pikachu” module’s forced evolution.
Strategic Objectives Driving Advanced Capabilities
The strategic objectives within the “Fire Red” project are ambitious: to develop autonomous systems capable of operating reliably and effectively where human intervention is risky, impractical, or impossible. This includes goals such as achieving resilient navigation in GPS-denied environments, performing sophisticated object classification and tracking under camouflage, and executing collaborative tasks with other autonomous agents in dynamic formations. These objectives demand more than just robust baseline performance; they require a leap into genuine cognitive autonomy. The “Fire Red” initiative sets the benchmarks for these advanced capabilities, dictating the “levels” to which the “Pikachu” module must evolve to meet these unparalleled challenges. It’s an operational mandate that transforms a capable AI unit into an indispensable decision-support system.

Reaching New Thresholds: Evolutionary Levels in “Fire Red”
The “Pikachu” module’s evolution within the “Fire Red” framework is meticulously structured into distinct levels, each signifying a quantum leap in cognitive capability and operational proficiency. These levels are not merely software updates but represent profound architectural enhancements and a deepening of its autonomous intelligence.
Level 1: Enhanced Data Fusion and Real-time Adaptation
The first significant evolution of “Pikachu” in the “Fire Red” context centers on mastering enhanced data fusion and real-time adaptation. Beyond merely combining sensor inputs, this level involves sophisticated contextual interpretation of fused data. For instance, the system learns to differentiate between persistent environmental features and transient obstacles, or to infer material properties from combined optical and thermal signatures. Real-time adaptation extends to dynamically adjusting flight parameters or movement patterns based on immediate environmental changes – navigating sudden wind gusts in urban canyons or instantly re-routing around newly collapsed debris. This level significantly boosts the system’s resilience and navigational robustness in unpredictable “Fire Red” scenarios, moving beyond simple reactive collision avoidance to more nuanced environmental interaction.
Level 2: Predictive Analytics and Proactive Decision-Making
Achieving Level 2 marks a pivotal shift for “Pikachu” from a purely adaptive system to one capable of predictive analytics and proactive decision-making. At this stage, the module begins to build complex environmental models in real-time, leveraging accumulated data and machine learning algorithms to anticipate future states. For example, in search and rescue missions, it can predict likely areas where survivors might be based on heat signatures, structural integrity data, and typical human behavior patterns in emergencies. Proactive decision-making manifests as the ability to generate optimal mission strategies several steps ahead, considering potential risks and resource allocation. This means, instead of just avoiding an identified hazard, “Pikachu” can, at Level 2, predict where future hazards might emerge and plan a route or action that circumvents them entirely, minimizing exposure and maximizing efficiency within the “Fire Red” operational window.
Level 3: Self-Optimization and Adaptive Learning Architectures
The pinnacle of “Pikachu’s” evolution under “Fire Red” is Level 3, characterized by advanced self-optimization and truly adaptive learning architectures. At this level, the module is no longer merely processing and predicting; it is actively learning and refining its own algorithms and parameters in an unsupervised manner. This includes continuous self-evaluation of its performance, identification of suboptimal strategies, and subsequent modification of its internal models. Imagine a “Pikachu” unit deployed in a new, unmapped disaster zone: at Level 3, it would not only navigate and map but also dynamically optimize its sensor usage, communication protocols, and energy consumption based on observed environmental conditions and mission progress. This adaptive learning allows the system to improve its capabilities autonomously over time, even adapting to unforeseen challenges or changes in the “Fire Red” mission parameters. This represents a significant step towards true cognitive autonomy, where the system is a dynamic, self-improving entity rather than a static piece of software.
The Impact of “Fire Red” Evolution on System Autonomy
The progressive evolution of the “Pikachu” module through the demanding “Fire Red” program fundamentally transforms the capabilities of autonomous systems. It is not merely an incremental improvement but a redefinition of what intelligent robotics can achieve in the most challenging operational contexts.
From Reactive to Anticipatory Systems
The journey from a baseline “Pikachu” to its Level 3 iteration within “Fire Red” signifies a profound shift from reactive to anticipatory autonomy. Early autonomous systems primarily responded to immediate environmental stimuli, often leading to delays or suboptimal decision paths in rapidly changing scenarios. With the “Fire Red” evolution, the “Pikachu” module equips systems with the capacity to understand context, predict outcomes, and plan proactively. This anticipatory capability is critical in dynamic environments where split-second decisions can mean the difference between mission success and failure, enabling autonomous platforms to operate with a level of foresight previously confined to human operators. It allows for more graceful navigation, efficient resource utilization, and ultimately, safer and more effective mission execution.
Scalability and Future Implications
The modular and scalable nature of the “Pikachu” module’s design, combined with its “Fire Red”-driven evolution, holds immense implications for the future of autonomous technology. The advanced learning architectures developed at Level 3 allow the core intelligence to be transferred and adapted across different hardware platforms and operational domains with relative ease. This means the insights gained from an aerial “Pikachu” operating in a “Fire Red” urban search scenario can inform the autonomy of a ground robot navigating a collapsed building, or even a submersible exploring deep-sea environments. Furthermore, the continuous self-optimization capabilities lay the groundwork for truly persistent autonomy, where systems can operate for extended periods, learning and improving without constant human oversight. This evolutionary path ensures that “Pikachu” remains at the forefront of AI innovation, driving the next generation of intelligent, resilient, and highly adaptable autonomous systems capable of tackling the most complex challenges humanity faces.