
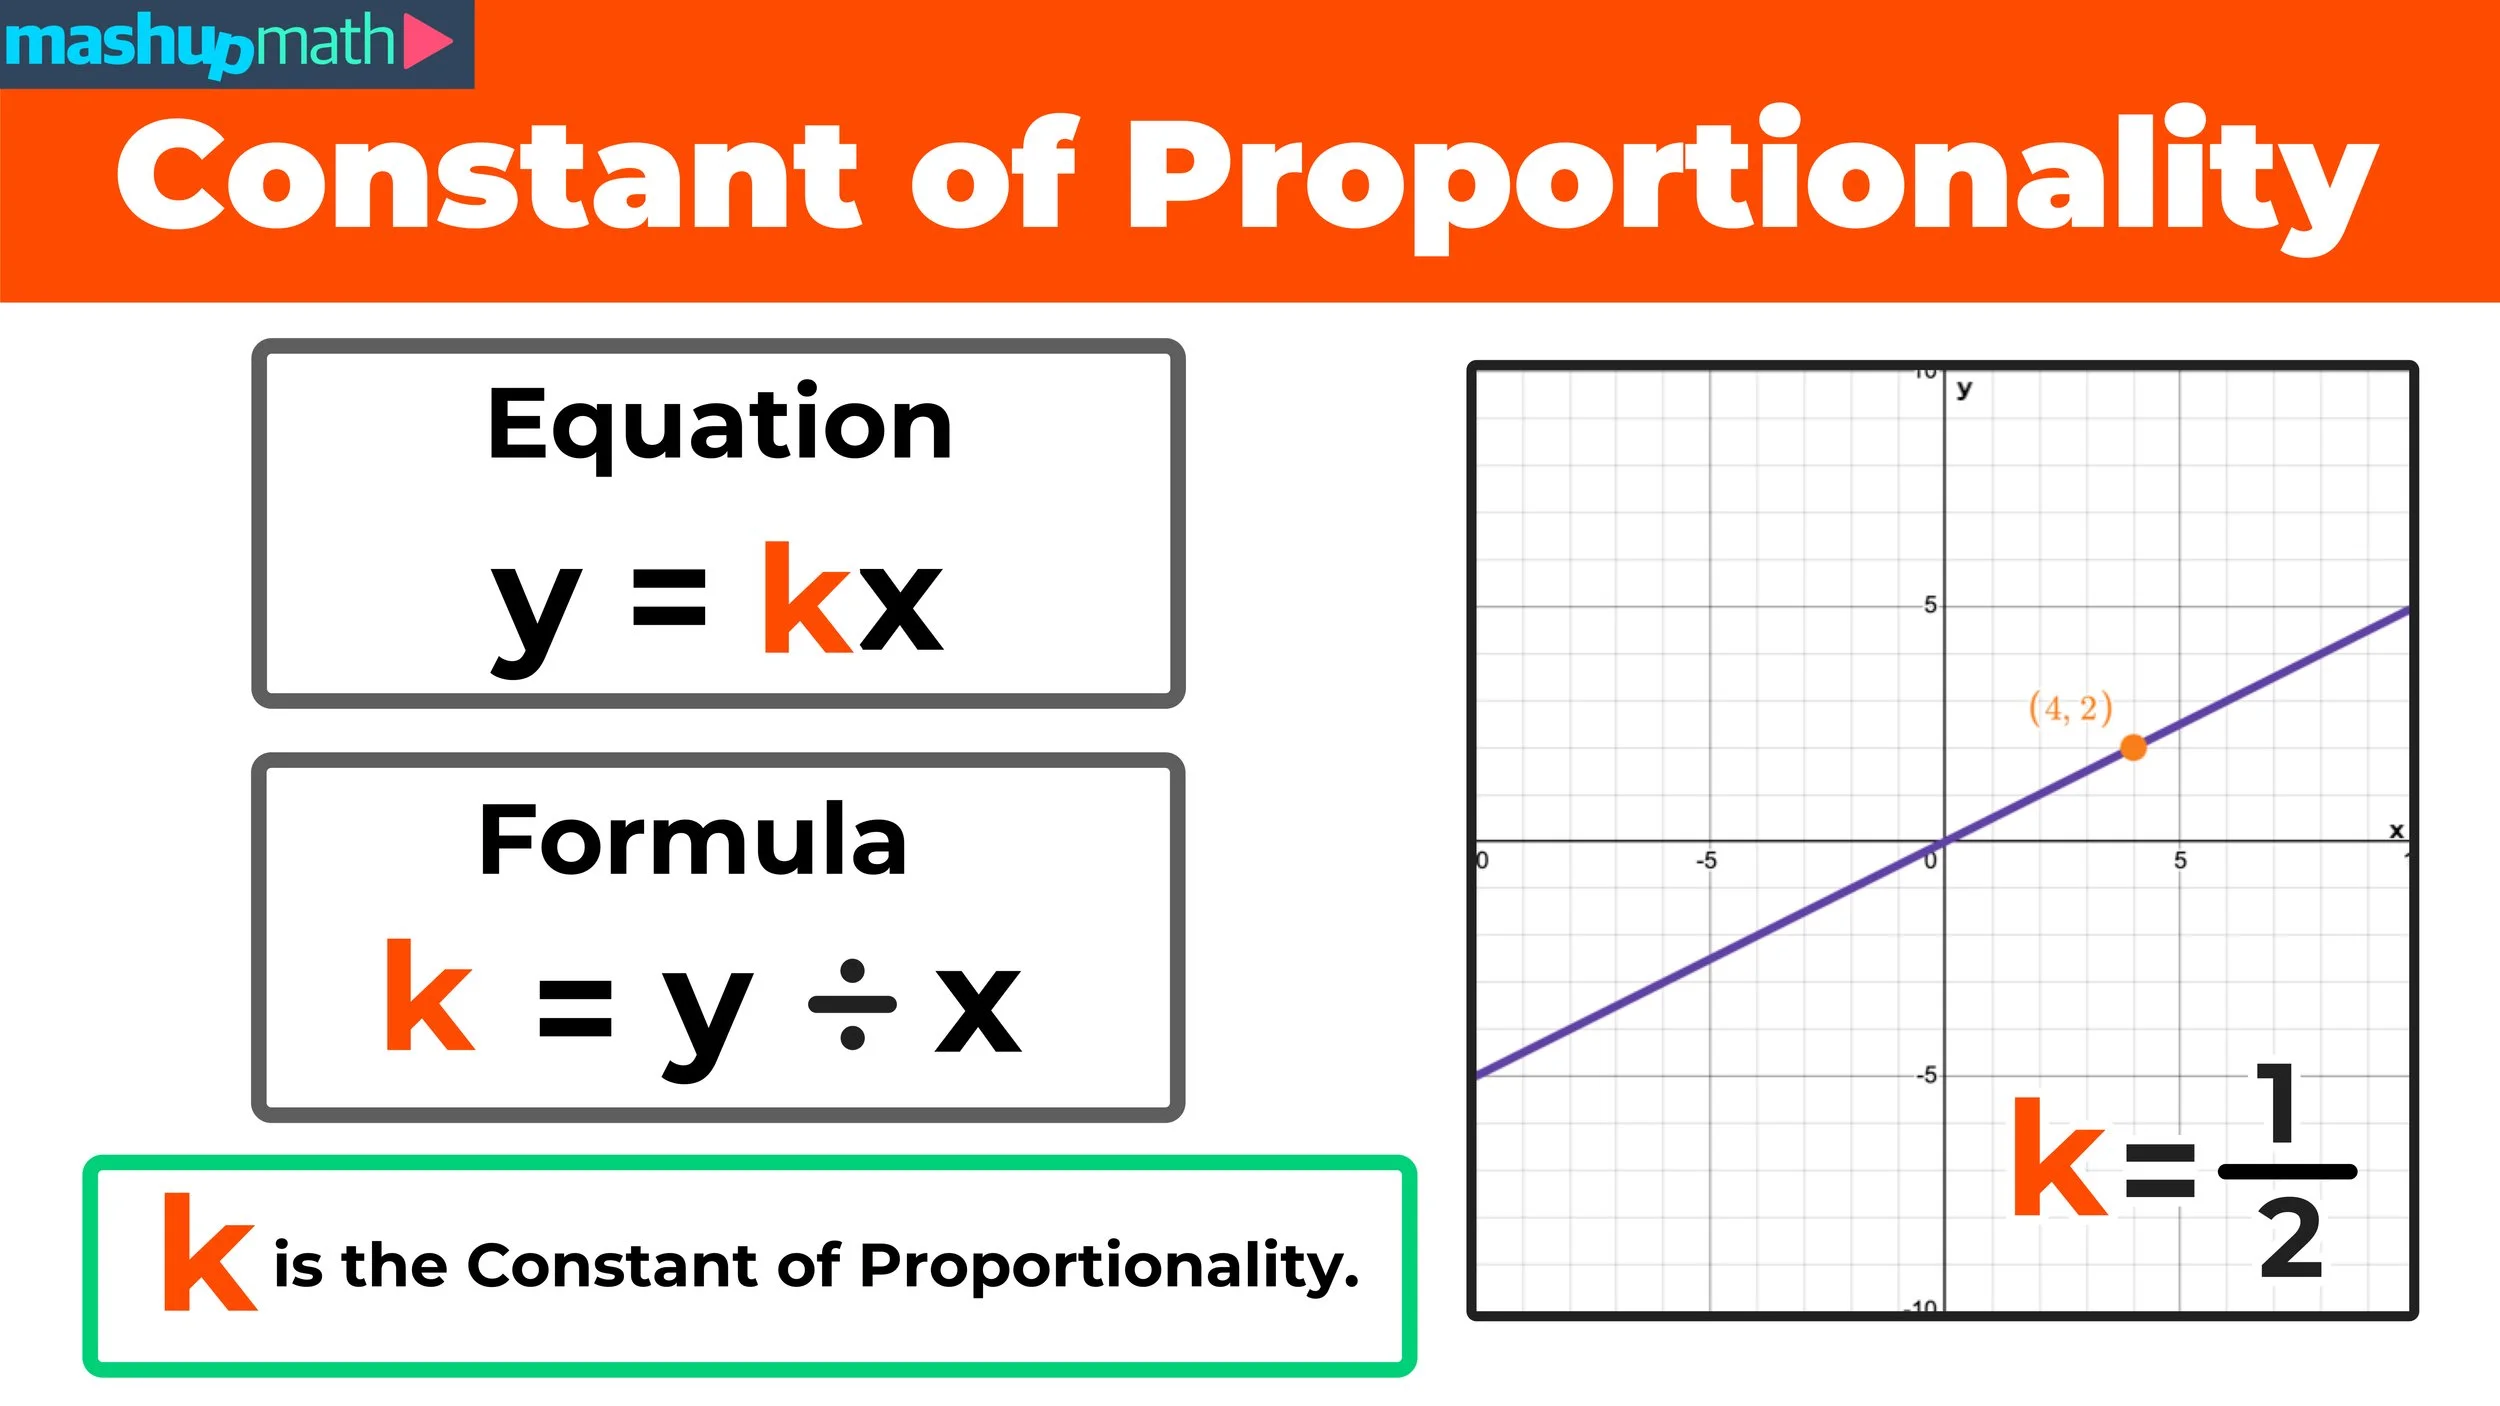
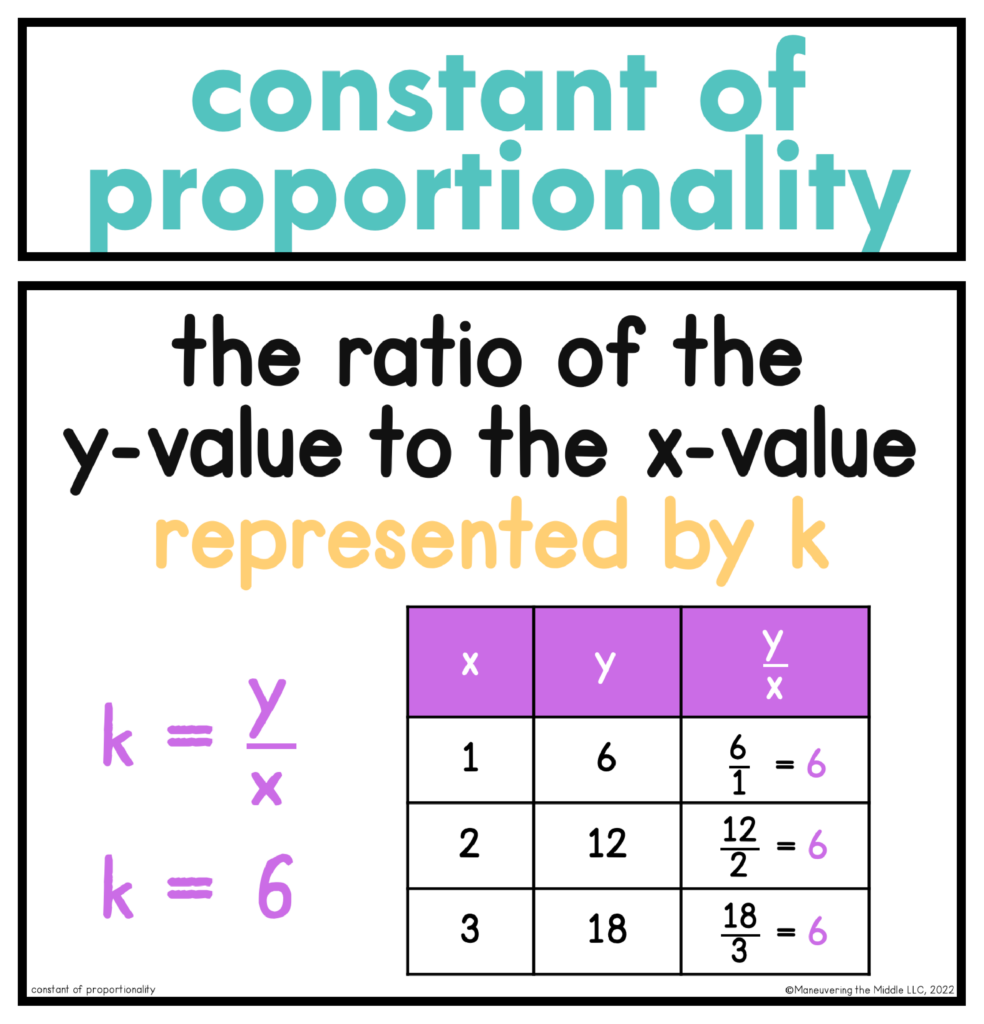
The constant of proportionality is a fundamental mathematical concept that underpins much of our modern technological landscape, particularly within the realms of Tech & Innovation. At its core, it describes a consistent relationship between two quantities where one is a multiple of the other. When two variables, let’s call them ‘x’ and ‘y’, are directly proportional, it means that as ‘x’ changes, ‘y’ changes in a predictable and consistent manner. This relationship can be expressed by the simple equation y = kx, where ‘k’ is the constant of proportionality. This ‘k’ value tells us exactly how much ‘y’ changes for every unit change in ‘x’, maintaining a steady ratio between the two variables.
This seemingly simple idea is incredibly powerful. It allows engineers, data scientists, and developers to model, predict, and control complex systems with precision. From the calibration of sensors on autonomous drones to the algorithmic responses in AI-powered navigation, understanding and applying the constant of proportionality is crucial for translating raw data into meaningful actions and insights. Without this bedrock concept, much of the sophisticated automation and intelligent behavior we see in advanced tech, such as autonomous flight or remote sensing, would be impossible to achieve with the necessary accuracy and reliability.
The Foundational Concept in Technological Innovation
In the dynamic world of Tech & Innovation, where systems are designed to interact with complex environments and execute precise tasks, the constant of proportionality serves as a core analytical and design tool. It’s not just an abstract mathematical concept but a practical constant that defines the behavior and response of various components and algorithms. Whether we’re discussing the thrust generated by a drone’s motor in relation to its RPM, the output voltage of a sensor corresponding to a physical phenomenon, or the correctional force applied by an autonomous flight controller, a proportional relationship is often at play.
The significance of ‘k’ lies in its ability to quantify and standardize these relationships. If we know ‘k’, we can predict an output given an input, or infer an input given an output. This predictability is paramount for building robust and reliable technological solutions. For instance, in an AI-driven system, understanding these proportional constants helps in fine-tuning algorithms that dictate how an autonomous vehicle responds to changes in its environment, or how a mapping system scales real-world data onto a digital representation. It moves technological design from guesswork to precise engineering, enabling consistent performance across various operational conditions.
Proportionality in Autonomous Flight Systems
Autonomous flight, a cornerstone of modern drone technology, heavily relies on precise control and accurate data interpretation. The constant of proportionality is an indispensable element in achieving the stability, responsiveness, and accuracy required for uncrewed aerial vehicles (UAVs) to navigate, maintain position, and execute complex maneuvers without direct human intervention.
PID Control and Stability
One of the most pervasive applications of proportionality in autonomous flight is within Proportional-Integral-Derivative (PID) controllers. These algorithms are the brains behind a drone’s ability to maintain a stable flight attitude and desired trajectory. The ‘P’ in PID stands for the Proportional term, which directly incorporates a constant of proportionality, often referred to as the ‘P-gain’.
The P-gain dictates how strongly the control system responds to an error. An error is the difference between the drone’s current state (e.g., its pitch angle, roll angle, or altitude) and its desired state. The proportional term calculates a correctional output that is directly proportional to this error. For example, if a drone is tilted by 5 degrees and the desired pitch is 0 degrees, the P-term will generate a motor adjustment force that is ‘k’ times 5 degrees. A larger P-gain (a larger ‘k’) means a more aggressive correction, making the drone respond quickly to deviations. However, too high a P-gain can lead to overshoots and oscillations, making the drone unstable. Conversely, too low a P-gain results in sluggish responses, meaning the drone might not correct itself fast enough, leading to drifting or slow recovery from disturbances. Thus, tuning this constant of proportionality (‘k’) is a critical aspect of ensuring stable and responsive autonomous flight.
Sensor Calibration and Data Interpretation
For a drone to fly autonomously, it must accurately perceive its environment. This is achieved through an array of sensors—accelerometers, gyroscopes, magnetometers, barometers, GPS, LiDAR, and vision sensors. Each of these sensors translates a physical phenomenon into an electrical signal or digital value. The relationship between the physical quantity being measured and the sensor’s output is often proportional, defined by a specific constant of proportionality, which is determined during sensor calibration.
For instance, a barometer measures atmospheric pressure, outputting a voltage or a digital count. To convert this raw output into an accurate altitude measurement, a calibration constant (the constant of proportionality) is applied. Similarly, a LiDAR sensor might output a voltage that is directly proportional to the distance of an object from the sensor. Without this constant, the raw sensor data would be meaningless in terms of real-world units. Precise calibration, which involves establishing this constant, ensures that the drone’s flight controller receives accurate information about its orientation, velocity, position, and surrounding obstacles, enabling reliable autonomous decision-making and obstacle avoidance.
Scaling and Precision in Mapping and Remote Sensing
Drone-based mapping and remote sensing are revolutionary applications that allow for the collection of vast amounts of geospatial data. The constant of proportionality plays a crucial role in accurately transforming this raw data into usable maps, 3D models, and insightful environmental analyses.
Photogrammetry and Map Scale
In photogrammetry, the science of making measurements from photographs, drones capture overlapping images of an area. These images are then processed to create orthomosaic maps, digital elevation models (DEMs), and 3D point clouds. A critical aspect of these outputs is their scale, which is essentially a constant of proportionality. Map scale defines the ratio between a distance on the map and the corresponding distance on the ground. For example, a map scale of 1:5000 means that 1 unit on the map represents 5000 units in the real world. This ‘1:5000’ is the constant of proportionality.
Establishing and maintaining an accurate scale is vital for any meaningful measurement or analysis derived from drone-generated maps. Surveyors, urban planners, and agriculturalists rely on these proportional constants to calculate areas, distances, and volumes with high precision. Errors in defining this constant can lead to significant discrepancies between the digital model and the physical reality, undermining the utility of the collected data. Advanced algorithms in photogrammetry software meticulously calculate and apply these scale factors, often adjusting for factors like camera focal length, flight altitude, and terrain variations, to produce geometrically accurate representations of the environment.
Interpreting Remote Sensor Data
Remote sensing involves collecting information about an object or area from a distance, typically from drone-mounted sensors like multispectral, hyperspectral, or thermal cameras. These sensors capture data across various electromagnetic spectrums, which can then be used to infer properties of the earth’s surface, vegetation health, water quality, or thermal profiles.
The raw data from these sensors often needs to be converted into physically meaningful units. For example, a multispectral sensor might measure reflected light as a digital number (DN). To understand the actual reflectance of a plant (which correlates with its health), these DNs must be converted. This conversion often involves a radiometric calibration, where a constant of proportionality is applied. This constant translates the sensor’s raw output into radiance or reflectance values, allowing for comparison across different times, sensors, or environmental conditions. Without these calibration constants, it would be impossible to accurately compare plant health indices (like NDVI) or identify thermal anomalies over time, rendering remote sensing data less valuable for critical decision-making in agriculture, environmental monitoring, and disaster response.
AI and Adaptive Systems
The constant of proportionality also finds its way into the sophisticated algorithms that power AI and adaptive systems, particularly those enabling autonomous drone functions like AI Follow Mode or smart navigation. While AI often employs complex neural networks that learn intricate, non-linear relationships, simpler proportional relationships still form foundational components within these larger intelligent systems, especially in their control loops and decision-making processes.
In an AI Follow Mode, for instance, a drone uses computer vision and object tracking to maintain a specific distance and relative position to a moving subject. The drone’s control system needs to continuously adjust its speed and direction. The rate at which the drone makes these adjustments is often proportional to the error in its position relative to the target. If the target speeds up, the drone’s AI might increase its forward thrust by an amount proportional to the detected speed difference. This proportional response, guided by an implicit or explicit constant, ensures smooth tracking without overshooting or lagging excessively. Similarly, in autonomous navigation, path correction algorithms may apply steering adjustments proportional to the deviation from the planned route. Even within machine learning models, certain linear layers or activation functions can embody proportional transformations of data, contributing to the model’s overall learned behavior. The constant of proportionality, therefore, remains a vital concept, acting as a direct lever in the design and tuning of responsive and intelligent drone behaviors.