
Skeletal muscles, the intricate biological machinery responsible for voluntary movement in vertebrates, represent one of nature’s most sophisticated examples of actuation. Far from being merely bundles of tissue, they are highly organized, adaptable, and energy-efficient systems that enable everything from the subtle twitch of an eyelid to the powerful leap of a predator. Understanding their fundamental architecture and operational principles offers profound insights not just into biology, but also serves as a potent source of inspiration for advancements in robotics, advanced materials, and autonomous systems within the realm of Tech & Innovation.
Nature’s Master Actuators: An Overview
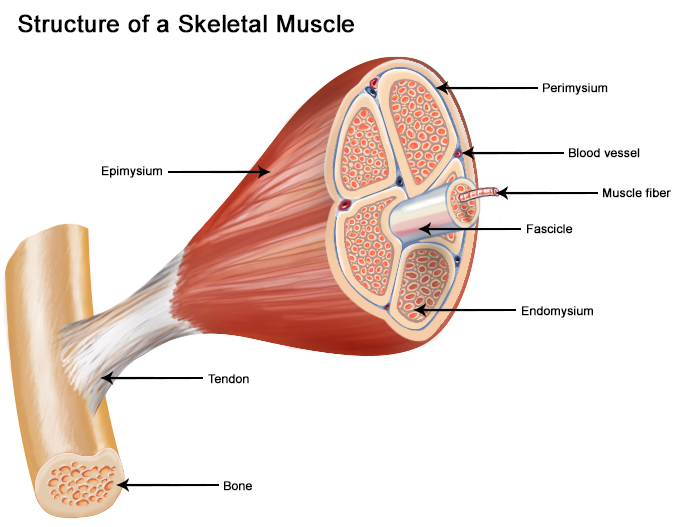
At its core, a skeletal muscle is a complex organ composed primarily of muscle fibers, connective tissue, blood vessels, and nerves. These muscles are characterized by their striated appearance under a microscope, a result of the highly organized arrangement of contractile proteins within their cells. Each muscle is attached to bones via tendons, facilitating movement across joints through contraction.
The Fundamental Architecture of Movement
The basic contractile unit of a skeletal muscle fiber is the sarcomere, which is repeated linearly along the length of the fiber. Sarcomeres consist of overlapping thick (myosin) and thin (actin) protein filaments. Muscle contraction occurs when these filaments slide past one another, a process known as the sliding filament theory. This action is triggered by a nerve impulse from the central nervous system, which releases a neurotransmitter (acetylcholine) at the neuromuscular junction. This initiates an action potential that propagates along the muscle fiber membrane, leading to the release of calcium ions from the sarcoplasmic reticulum. Calcium then binds to regulatory proteins on the actin filaments, exposing binding sites for myosin heads, which then attach, pivot, and detach in a cyclical fashion, effectively pulling the actin filaments toward the center of the sarcomere and shortening the muscle.
This microscopic dance of proteins translates into macroscopic force generation. The precise control over muscle contraction, from subtle adjustments to maximal exertion, is achieved through varying the number of motor units (a motor neuron and all the muscle fibers it innervates) recruited and the frequency of nerve impulses.
Key Properties: Strength, Efficiency, and Adaptability
Skeletal muscles possess a remarkable suite of properties that make them an engineering marvel. They exhibit an incredible strength-to-weight ratio, capable of generating significant force with relatively low mass. Their energy efficiency is another hallmark; while not perfectly efficient, the biochemical processes underpinning contraction are highly optimized, utilizing ATP (adenosine triphosphate) effectively.
Perhaps most notably, skeletal muscles are inherently adaptable. They can grow in size (hypertrophy) and strength in response to increased demand, and conversely, atrophy when inactive. They also possess a degree of self-repair capability, allowing for recovery from minor damage. Furthermore, their inherent flexibility and compliance allow for complex, multi-axis movements, absorbing shocks and distributing forces effectively. This combination of strength, efficiency, adaptability, and inherent compliance presents a grand challenge and a rich design space for engineers seeking to push the boundaries of robotic actuation and material science.
Bio-Inspiration: Skeletal Muscles as a Paradigm for Robotic Actuation
The exceptional capabilities of natural skeletal muscles have long captivated engineers and roboticists. The quest to develop synthetic systems that can emulate the strength, agility, energy efficiency, and compliance of biological muscles is a driving force in the field of Tech & Innovation, particularly in areas like soft robotics, advanced prosthetics, and next-generation autonomous systems, including drones.
From Biological Contraction to Synthetic Systems
Engineers look to skeletal muscles for inspiration in designing advanced actuators—devices that convert energy into mechanical motion. Traditional robotic actuators, often based on electric motors, hydraulics, or pneumatics, excel in precision and power but frequently lack the inherent flexibility, compliance, and energy density of biological muscles. They can be heavy, rigid, and prone to damage from impacts, and their power-to-weight ratio often pales in comparison to their biological counterparts.
The goal is to move beyond these conventional rigid systems towards “muscle-like” actuators that can seamlessly integrate into soft robotic bodies, enabling new forms of interaction, manipulation, and locomotion. This pursuit involves interdisciplinary research, blending principles of biomechanics, material science, electrical engineering, and artificial intelligence.
Challenges in Mimicking Natural Motion
Replicating the complexity of skeletal muscle function is an enormous challenge. Natural muscles operate through intricate biochemical reactions, harnessing chemical energy directly into mechanical work at a molecular level. Synthetic muscles, such as dielectric elastomer actuators (DEAs), shape memory alloys (SMAs), electroactive polymers (EAPs), and pneumatic artificial muscles (PAMs), attempt to mimic this by converting electrical, thermal, or pressure energy into mechanical deformation.
The challenges are manifold:
- Energy Density and Efficiency: Achieving the same power output per unit mass with comparable energy efficiency as biological muscles remains difficult.
- Self-Healing and Durability: Natural muscles can repair themselves and adapt to wear and tear. Synthetic materials often lack this robust self-healing capability, leading to fatigue and failure over time.
- Compliance and Force Control: Precisely controlling stiffness and generating graded forces across a wide range, while maintaining inherent compliance, is complex to implement in synthetic systems.
- Integration and Scalability: Integrating numerous small, muscle-like units into a larger, functional system while managing power, control, and heat dissipation is a significant engineering hurdle.
Despite these challenges, ongoing research is yielding promising results, leading to materials and designs that are inching closer to the performance of their biological inspirations.
Soft Robotics and Advanced Materials: The Future of Drone and Robotic Design
The insights gained from studying skeletal muscles are directly fueling advancements in soft robotics and advanced materials, which are poised to revolutionize various aspects of technology, including the design and capabilities of drones.
Flexible Robotics: Beyond Rigid Structures
Soft robotics focuses on creating robots from compliant materials, allowing them to deform, adapt, and interact more safely with unstructured environments and humans. This contrasts sharply with traditional rigid robots, which are typically designed for precise, repetitive tasks in controlled industrial settings. Muscle-like actuators are central to soft robotics, enabling movements that are fluid, natural, and highly adaptive.
Imagine robots that can squeeze through tight spaces, grasp delicate objects without damage, or absorb impacts without structural failure. This vision is being realized through novel materials and actuation mechanisms inspired by biological muscles, moving beyond the limitations of traditional rigid joints and links.
Novel Actuators and Morphing Structures
The pursuit of artificial muscles has led to the development of various innovative actuators. Dielectric Elastomer Actuators (DEAs), for instance, are essentially capacitors that deform when an electric field is applied, mimicking muscle contraction. These can be lightweight, highly flexible, and capable of significant strain, making them ideal candidates for morphing structures.
In the context of drones, this translates into possibilities for:
- Morphing Wings: Aircraft wings, or even drone propellers, could dynamically change their shape, camber, or twist in real-time to optimize aerodynamic performance for different flight conditions (e.g., increased lift for slow flight, reduced drag for high speed, or enhanced maneuverability). This would allow drones to operate more efficiently and adaptively than current fixed-wing or fixed-propeller designs.
- Articulated Control Surfaces: Instead of conventional flaps and ailerons, future drones might employ soft, muscle-like materials for control surfaces that can continuously deform, offering finer and more responsive control.
- Adaptive Grippers and Manipulators: Drones equipped with soft, muscle-inspired manipulators could perform more delicate tasks, such as handling fragile packages, inspecting sensitive equipment, or even interacting with vegetation for environmental monitoring without causing damage.
Self-Healing and Energy Efficiency in Bio-Inspired Systems
Beyond mere actuation, the concepts of self-healing and high energy efficiency, inherent to biological muscles, are critical for the next generation of autonomous systems. Researchers are exploring self-healing polymers and composites that can autonomously repair minor damage, significantly extending the operational lifespan and reliability of robotic components, including those on drones. This would be invaluable for drones operating in harsh or remote environments, reducing maintenance requirements and improving mission success rates.
Furthermore, integrating energy-harvesting capabilities or developing actuators with drastically improved energy conversion efficiency, inspired by the biochemical pathways of muscles, could lead to drones with significantly extended flight times and reduced reliance on frequent battery recharges.
The Intersection with Drone Technology: Enhancing Agility and Autonomy
The application of skeletal muscle-inspired technology within drone design represents a significant leap forward for Tech & Innovation, promising to unlock unprecedented levels of agility, adaptability, and autonomous capability.
Adaptive Flight Surfaces and Articulated Components
Current drone designs, whether fixed-wing or multi-rotor, rely on rigid structures and predefined aerodynamic profiles or propeller geometries. Integrating bio-inspired, muscle-like actuators could revolutionize their flight dynamics. Imagine a drone with wings that can ripple like a bird’s, dynamically adjusting their shape to respond to wind gusts or to execute incredibly tight turns. This level of adaptability would make drones far more resilient to environmental disturbances and capable of navigating complex, confined spaces with greater ease and efficiency.
Beyond wings, articulated components driven by synthetic muscles could lead to drones with morphing fuselages or landing gear that can actively adapt to uneven terrain, enhancing their ability to operate in diverse environments.
Next-Generation Grippers and Manipulators
For drones tasked with inspection, delivery, or interaction with their environment, muscle-inspired soft grippers and manipulators are transformative. Current drone manipulators are often rigid and limited in their dexterity, making precise or delicate tasks challenging. Soft robotic grippers, designed with the compliance and distributed force application reminiscent of human hands, could enable drones to:
- Handle Delicate Items: Safely pick up and transport fragile packages without crushing them.
- Perform Complex Inspections: Gently interact with infrastructure, such as bridges or wind turbines, to gather data without causing damage.
- Environmental Sampling: Collect sensitive biological or geological samples with minimal disturbance.
- Rescue Operations: Grasp and stabilize objects or even provide assistance in search and rescue scenarios with reduced risk of injury.
These capabilities would expand the utility of drones far beyond simple surveillance or photography, opening up new frontiers in service, logistics, and scientific research.

AI and Biomimicry: Smarter Autonomous Systems
The intricate control and adaptability inherent in skeletal muscle systems also inform advancements in Artificial Intelligence (AI) and control algorithms for autonomous flight. As synthetic muscles become more sophisticated, managing their complex, non-linear dynamics will require advanced AI. Machine learning techniques can be trained on biological movement patterns to develop control systems that allow drones to leverage the full potential of these compliant, muscle-like structures.
This fusion of bio-inspired hardware and AI-driven software would lead to drones that are not only physically more agile and adaptable but also intelligently aware of their capabilities, able to make nuanced decisions about movement, interaction, and task execution—emulating the instinctive and efficient movements observed in nature. The ultimate goal is to create truly autonomous systems that move with the fluidity, efficiency, and robustness characteristic of biological organisms, revolutionizing everything from urban air mobility to exploration in hazardous environments.