
The fundamental world of drone technology, from autonomous flight to sophisticated sensor arrays and data processing, is deeply rooted in mathematical principles. While often hidden beneath layers of code and hardware, concepts like the geometric sequence play a crucial, albeit often indirect, role in understanding, modeling, and optimizing various aspects of drone innovation. At the heart of any geometric sequence lies ‘r’, the common ratio—a deceptively simple value that dictates patterns of growth, decay, and scaling across numerous technological domains.
Understanding the Common Ratio ‘r’ in Geometric Sequences
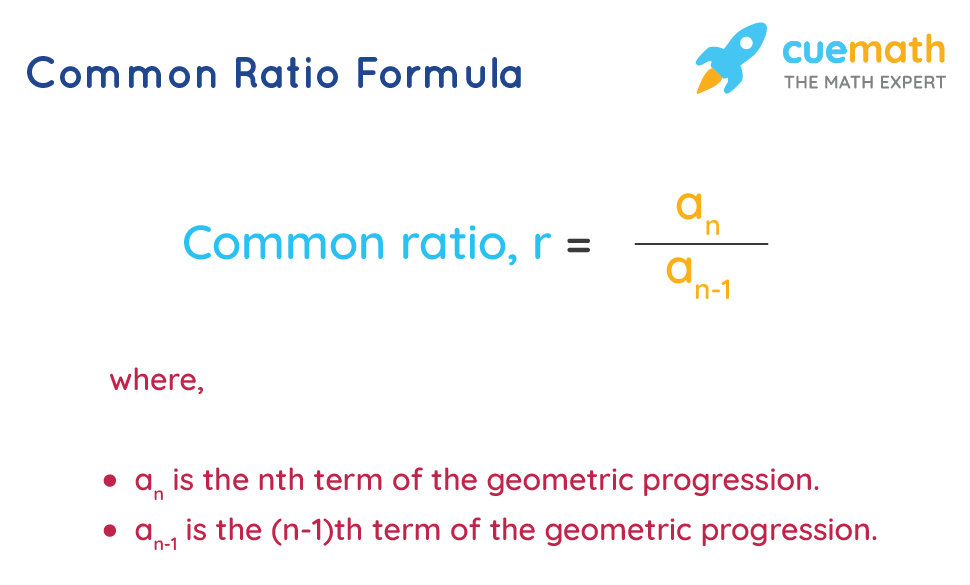
A geometric sequence is a sequence of non-zero numbers where each term after the first is found by multiplying the previous one by a fixed, non-zero number called the common ratio. This ‘r’ is the essence of the sequence’s progression. For example, in the sequence 2, 6, 18, 54, … the common ratio ‘r’ is 3, because each term is three times the previous one (6/2 = 3, 18/6 = 3, etc.). The general form of a geometric sequence can be expressed as $a, ar, ar^2, ar^3, dots, ar^{(n-1)}$, where ‘a’ is the first term and ‘r’ is the common ratio.

The value of ‘r’ dictates the behavior of the sequence:
- If r > 1: The sequence exhibits exponential growth. Terms become progressively larger, moving away from zero. This can model, for instance, the accumulation of errors in certain systems or the scaling of computational demand.
- If 0 < r < 1: The sequence exhibits exponential decay. Terms become progressively smaller, approaching zero. This behavior is critical for understanding signal attenuation, error reduction in iterative algorithms, or the diminishing returns of a resource.
- If r = 1: The sequence remains constant (e.g., 5, 5, 5, …). While seemingly trivial, this signifies a state of equilibrium or non-change, which can be a target in system stabilization.
- If r < 0: The sequence alternates in sign (e.g., 2, -4, 8, -16, …). This pattern can sometimes emerge in oscillatory systems or control loops, though its direct application as a pure geometric sequence in drone tech is less common than the growth/decay scenarios.
In the context of drone tech, ‘r’ isn’t just an abstract mathematical concept; it’s a quantitative descriptor for how a specific parameter changes over discrete steps, cycles, or iterations, offering valuable insights into system design, performance prediction, and optimization.
‘r’ in Sensor Data Processing and Signal Integrity
The robustness and reliability of drone operations heavily depend on the data gleaned from an array of sensors—GPS, IMUs, LiDAR, radar, and optical cameras. The common ratio ‘r’ provides a framework for understanding how signal strength and data quality evolve through various processing stages or environmental interactions.
Signal Attenuation and Amplification
When a drone engages in remote sensing, signals (e.g., radio waves for communication, laser pulses for LiDAR, electromagnetic waves for radar) are transmitted and received. These signals rarely maintain their original strength. As a signal travels through the atmosphere, interacts with objects, or traverses different media, its intensity often diminishes. This phenomenon, known as attenuation, can frequently be modeled using principles akin to a geometric sequence where the common ratio ‘r’ is less than 1 (0 < r < 1).
Consider a LiDAR system mapping terrain. Each interaction with atmospheric particles or a partially reflective surface reduces the laser pulse’s energy. If, for instance, each meter of travel reduces signal strength by a fixed percentage, then over several meters, the signal strength follows a geometric decay. Understanding this ‘r’ allows engineers to design more powerful transmitters, sensitive receivers, or implement error correction algorithms to compensate for expected signal loss, thereby extending the drone’s effective sensing range or improving data fidelity. Conversely, some active sensing techniques or communication boosters might aim for a geometric amplification (r > 1) in specific signal processing steps.
Iterative Algorithm Convergence
Many advanced drone functionalities, such as precise navigation, object tracking, and image stabilization, rely on iterative algorithms. These algorithms refine an estimate or solution over successive steps. For these algorithms to be effective, they must converge towards an accurate solution. The speed and stability of this convergence can often be characterized by a factor that behaves like ‘r’.
For instance, in a Kalman filter, widely used in drone navigation and state estimation, the estimation error is ideally reduced with each measurement update. If the filter is well-tuned, the uncertainty in the drone’s position or velocity estimate might decrease by a certain factor (an effective ‘r’ < 1) with each subsequent iteration or data fusion step. Similarly, in photogrammetry, iterative bundle adjustment algorithms refine the camera positions and 3D scene structure. The reduction in reprojection error during each iteration, if consistent, can be thought of as a geometric progression towards an optimal solution. An ‘r’ value close to 1 would indicate slow convergence, while an ‘r’ close to 0 (but positive) would signify rapid convergence, guiding algorithm developers in optimizing performance.
Modeling System Performance and Resource Dynamics
The ‘r’ value is also valuable in predictive modeling for the longevity, efficiency, and resource demands of drone systems and fleets. From predicting component lifespan to understanding data storage growth, geometric sequences offer a framework for foresight.
Battery Degradation Over Cycles
Drone batteries, primarily lithium-polymer (LiPo), are a critical component, and their performance degrades over time and charge cycles. While battery degradation is a complex phenomenon influenced by numerous factors, certain aspects of capacity fade or internal resistance increase can, under specific conditions, be approximated by a geometric decay model (0 < r < 1) over a series of charge-discharge cycles. For example, if a battery loses a fixed percentage of its maximum capacity with each full cycle after a certain initial period, the remaining capacity can be seen as terms in a geometric sequence.
Understanding this ‘r’ allows drone operators and manufacturers to:
- Predict the useful lifespan of a battery pack more accurately.
- Optimize charging strategies to slow down degradation (by influencing ‘r’).
- Schedule proactive battery replacements, ensuring operational safety and efficiency.
- Design power management systems that account for diminishing returns.
Fleet Scaling and Data Storage Needs
As drone operations scale from single units to large fleets, the management of resources and data becomes a significant challenge. The concept of ‘r’ can help model growth patterns in these areas.
Consider data storage: if each drone mission generates a certain amount of data, and the number of missions or the complexity (and thus data volume) of missions increases by a consistent factor over time, the total data storage required could grow geometrically (r > 1). For example, if a drone mapping company’s data generation grows by 10% each month (an ‘r’ of 1.1), understanding this rate allows for proactive infrastructure scaling, preventing bottlenecks in data processing and storage.
Similarly, in predictive maintenance for a large drone fleet, if the probability of a critical component failure (e.g., a motor bearing) increases by a certain factor with each increment of flight hours beyond a threshold, this could inform maintenance scheduling. A calculated ‘r’ can help identify when proactive maintenance becomes exponentially more cost-effective than reactive repairs, minimizing downtime and operational costs.
‘r’ in AI and Autonomous Flight Algorithms
The cutting edge of drone technology lies in its increasing autonomy and intelligence. Here, too, the principles of geometric sequences—particularly the concept of iterative scaling or progression embodied by ‘r’—are woven into the fabric of advanced algorithms.
Path Planning Optimization
Autonomous drones must compute optimal flight paths to achieve mission objectives while avoiding obstacles and minimizing energy consumption. Many path planning and re-planning algorithms are iterative, refining a provisional path with each step. In certain optimization methods, the adjustment made to the path at each iteration might be scaled by a factor that behaves like ‘r’. For example, an algorithm might explore potential waypoints, and the ‘jump’ or ‘step size’ towards a better solution could geometrically decrease (0 < r < 1) as the algorithm gets closer to the optimal path, ensuring fine-grained adjustments. This allows for efficient convergence to the most energy-efficient or shortest path.
In reinforcement learning for autonomous navigation, where drones learn to navigate through trial and error, future rewards are often “discounted” by a factor ‘gamma’ (γ), which acts precisely like ‘r’ (0 < γ < 1). This ensures that immediate rewards are valued more highly than distant future rewards, guiding the drone’s learning process towards more immediate and tangible improvements in its behavior.

Learning Rate in Machine Learning Models
Machine learning (ML) models are integral to AI-powered drone features like object recognition, autonomous navigation, and intelligent control. During the training of these models, parameters are updated iteratively to minimize an error function. A critical hyperparameter in this process is the “learning rate.” While not always a fixed ‘r’ in the purest geometric sense, the concept of a learning rate schedule often involves reducing the learning rate over time, sometimes geometrically.
For example, a common practice is to decrease the learning rate by a certain factor (e.g., 0.9 or 0.99) after a fixed number of training epochs or when performance plateaus. This decaying learning rate helps the model converge more stably to an optimal solution by taking larger steps initially and then progressively smaller, more precise steps. This geometric reduction (an effective ‘r’ < 1) prevents oscillations around the minimum and allows the model to fine-tune its parameters for higher accuracy in tasks like identifying specific features in aerial imagery or recognizing targets for follow-me modes.
In essence, ‘r’ from a geometric sequence provides a powerful conceptual tool for understanding and engineering systems where quantities change multiplicatively over discrete steps. From managing signal integrity and predicting component longevity to optimizing complex AI algorithms, the silent influence of the common ratio is a testament to the foundational role of mathematical principles in pushing the boundaries of drone technology and innovation.