
For advanced flight technology, understanding three-dimensional (3D) space is not merely an abstract concept; it is the fundamental framework within which every operation, from basic navigation to complex autonomous maneuvers, is executed. It defines the environment, dictates movement, and enables interaction. In essence, 3D space is the observable universe around an aircraft, characterized by three primary axes that allow for movement in height, width, and depth. For drones and other aerial vehicles, mastering this spatial understanding is the bedrock of their utility and precision.
The Operational Canvas: Defining 3D Space for Flight
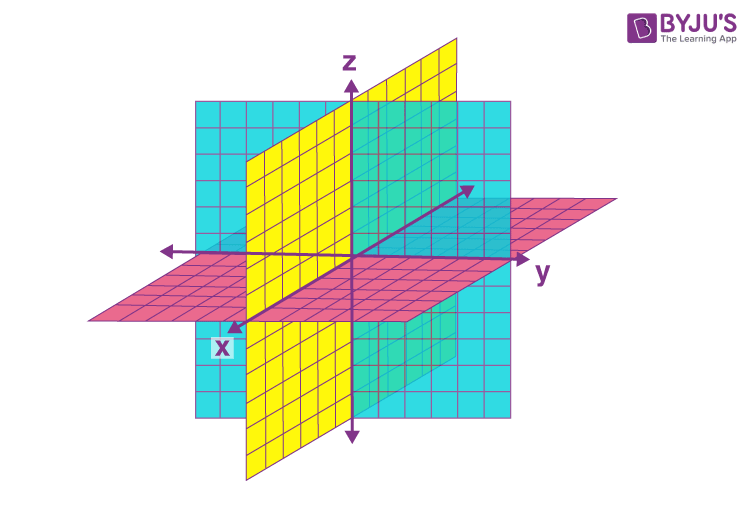
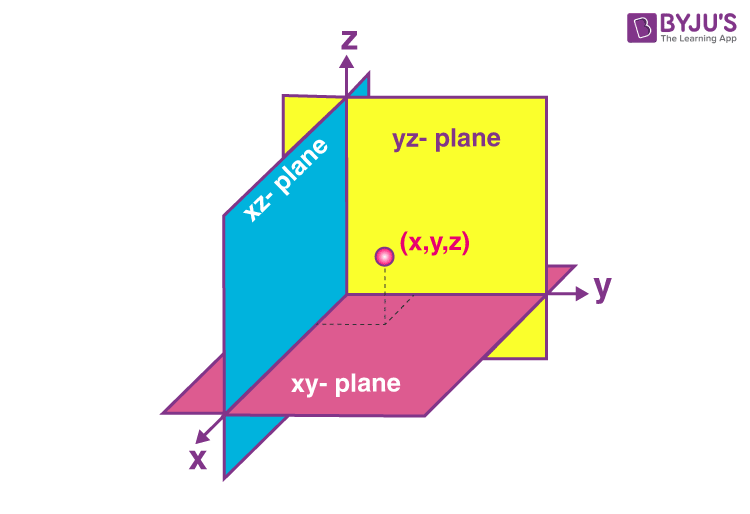
At its core, three-dimensional space, for flight technology, is a volumetric realm where objects can occupy a specific position and orientation. Mathematically, this is often represented using a Cartesian coordinate system, which assigns three orthogonal axes: X, Y, and Z. The X-axis typically denotes movement left or right, the Y-axis forward or backward, and the Z-axis up or down. Every point in this space can be uniquely identified by its (x, y, z) coordinates.
Beyond simple position, objects in 3D space also possess orientation, often described by three rotational degrees of freedom: roll, pitch, and yaw. Roll is rotation around the forward-backward axis (like tilting wings), pitch is rotation around the left-right axis (like nose up/down), and yaw is rotation around the vertical axis (like turning left or right horizontally). For flight technology, precisely controlling these six degrees of freedom (three translational, three rotational) is paramount for stable flight, accurate navigation, and mission accomplishment. Without a robust understanding and computational model of this 3D environment, an aircraft would be adrift, unable to navigate, stabilize, or interact meaningfully with its surroundings.
Precision Positioning: Navigating 3D Space
The ability of flight technology to pinpoint its location and chart a course within 3D space is a cornerstone of its functionality. This demands sophisticated systems that can accurately determine coordinates and maintain situational awareness.
Global Positioning Systems (GPS) and GNSS
The most ubiquitous tool for 3D positioning in outdoor environments is the Global Positioning System (GPS), part of a larger family of Global Navigation Satellite Systems (GNSS) that includes GLONASS, Galileo, and BeiDou. These systems operate by receiving signals from a constellation of satellites orbiting Earth. Each satellite broadcasts its precise orbital position and the exact time the signal was sent. By receiving signals from at least four satellites, a drone’s flight controller can calculate the time difference of arrival for each signal. This time difference is then used to triangulate the drone’s precise three-dimensional coordinates—latitude, longitude, and altitude—relative to the Earth’s surface. Latitude and longitude define horizontal position, while altitude provides the critical vertical dimension, together painting a complete picture of the drone’s global location in 3D space. The accuracy of these systems is crucial for defining flight paths, executing waypoint missions, and ensuring drones stay within designated airspace.
Inertial Measurement Units (IMUs)
While GPS provides absolute positioning, Inertial Measurement Units (IMUs) offer vital relative positioning and orientation data within 3D space. An IMU typically comprises accelerometers, gyroscopes, and sometimes magnetometers. Accelerometers measure linear acceleration along the X, Y, and Z axes, indicating changes in velocity. Gyroscopes measure angular velocity around these same three axes, indicating rotational movement (roll, pitch, and yaw rates). Magnetometers provide heading information by sensing the Earth’s magnetic field.
By fusing data from these sensors, the IMU can continuously track the drone’s movement and orientation in 3D space, even for short periods when GPS signals are weak or unavailable. This dead reckoning capability is essential for high-frequency control loops that require instantaneous feedback on the drone’s attitude and trajectory. Flight controllers heavily rely on IMU data to maintain stability, execute precise maneuvers, and smooth out environmental disturbances.
Visual Odometry and Simultaneous Localization and Mapping (SLAM)
For environments where GPS is unreliable or unavailable, such as indoors or under dense canopy, advanced flight technology leverages visual odometry and Simultaneous Localization and Mapping (SLAM). Visual odometry uses camera imagery to track the drone’s movement by analyzing how features in the environment shift between successive frames. By identifying and matching points in the visual scene, algorithms can estimate the drone’s translational and rotational movement within 3D space.
SLAM takes this a step further by simultaneously building a 3D map of the unknown environment while localizing the drone within that newly constructed map. This means the drone not only understands its own 3D position and orientation but also begins to comprehend the 3D structure of its surroundings. Using depth sensors like LiDAR or stereo cameras, SLAM algorithms create point clouds or volumetric representations of the environment, allowing the drone to navigate complex 3D spaces without relying on external positioning systems. This technology is critical for autonomous inspection, exploration of confined spaces, and safe operation in urban canyons.
Stability and Control: Mastering 3D Dynamics
Maintaining stable flight and executing precise movements within three-dimensional space is a testament to sophisticated control systems. These technologies continuously process data to ensure the aircraft adheres to its intended trajectory and orientation.
Flight Controllers and PID Loops
The brain of any modern drone is its flight controller, a sophisticated computer that constantly interprets sensor data and issues commands to the motors. At its heart lies the Proportional-Integral-Derivative (PID) control loop, a ubiquitous algorithm for maintaining stability and achieving desired states in 3D space. The PID controller works by comparing the drone’s current state (e.g., actual roll angle from the IMU) with its desired state (e.g., target roll angle from the pilot’s input or autonomous mission).
- Proportional (P): Responds to the current error (how far off the drone is from its target). A larger error prompts a larger corrective action.
- Integral (I): Accounts for accumulated past errors, helping to eliminate steady-state errors and ensure the drone reaches and holds its target precisely.
- Derivative (D): Predicts future errors based on the rate of change of the current error, dampening oscillations and improving responsiveness.
These PID loops operate independently for each of the rotational axes (roll, pitch, yaw) and for vertical control (altitude), constantly adjusting motor speeds to counter disturbances and maintain the drone’s desired attitude and position in 3D space.
Dynamic Thrust Vectoring
The physical interaction of the drone with 3D space is primarily managed through dynamic thrust vectoring. Multi-rotor drones, for instance, achieve movement and stability by varying the speed of individual motors, which in turn changes the thrust produced by each propeller. To move forward, the rear motors might spin faster, tilting the drone forward (pitching) and directing the collective thrust vector slightly forward. To ascend, all motors increase speed uniformly. To yaw, motors on opposite sides might increase speed while others decrease, creating a torque.
The precise manipulation of these thrust vectors allows the flight controller to exert forces and torques in all six degrees of freedom, enabling the drone to translate and rotate within 3D space with remarkable agility and precision. This dynamic control over forces is what truly allows the flight technology to navigate and perform intricate maneuvers in the three-dimensional environment.
Environmental Compensation
Operating in real-world 3D space means confronting environmental variables that constantly challenge stability. Wind, changes in air pressure, and even temperature gradients can affect a drone’s flight characteristics. Modern flight technology incorporates advanced sensors and algorithms to compensate for these disturbances. Barometric altimeters provide precise air pressure readings, allowing the flight controller to maintain a stable altitude even when atmospheric pressure changes. Accelerometers and gyroscopes continuously feed data on external forces, enabling the PID loops to apply counter-thrusts instantaneously, ensuring the drone holds its position and attitude despite gusts of wind. This continuous interplay between sensing the 3D environment and dynamically adjusting thrust vectors is vital for reliable and safe operation.
Sensing and Interacting with the 3D Environment
Beyond simply existing and moving within 3D space, advanced flight technology actively perceives and interacts with it. This capability transforms drones from simple flying platforms into intelligent, responsive systems.
Obstacle Avoidance Systems
One of the most critical aspects of interacting with 3D space is obstacle avoidance. Drones are equipped with an array of sensors—including ultrasonic, infrared, optical vision systems (stereo cameras or monocular with depth estimation), and LiDAR (Light Detection and Ranging)—to detect objects in their immediate 3D surroundings. These sensors create a temporary, dynamic 3D map of the environment, identifying potential collision threats.
- Ultrasonic sensors emit sound waves and measure the time it takes for them to return, calculating distance to objects, typically effective for close-range detection.
- Vision systems process image data to identify objects, estimate their distance, and even track their movement, building a visual representation of the 3D world. Stereo cameras, for example, mimic human binocular vision to calculate depth.
- LiDAR systems emit pulsed lasers and measure the return time, generating highly accurate 3D point clouds of the environment, ideal for complex obstacle mapping.
By integrating data from these sensors, the flight controller can identify clear flight paths, automatically reroute to avoid obstacles, or even bring the drone to a hover, ensuring safe operation within crowded or complex 3D environments like dense forests or urban infrastructure.
Terrain Following and Contour Mapping
Flight technology can also actively shape its flight path to conform to the 3D contours of terrain. Using altimeters (barometric and radar/laser), drones can maintain a consistent height above ground level (AGL), rather than a fixed height above sea level (ASL). This “terrain following” capability is crucial for applications like precision agriculture, pipeline inspection, or search and rescue over undulating landscapes. Advanced systems can even utilize pre-loaded 3D digital elevation models (DEMs) or real-time sensor data to dynamically adjust their altitude, ensuring they precisely trace the 3D shape of the terrain below. This active adaptation to the vertical dimension of 3D space allows for more efficient and safer operations.
Remote Sensing for 3D Data Acquisition
Drones are invaluable platforms for remote sensing, a process of collecting information about an object or area without making physical contact. When equipped with specialized cameras (RGB, multispectral, hyperspectral), LiDAR scanners, or thermal sensors, drones can gather vast amounts of data to construct highly detailed 3D models of real-world environments. Photogrammetry, for instance, uses overlapping 2D images captured from multiple angles to create dense 3D point clouds and textured mesh models of structures, landscapes, or archaeological sites. LiDAR systems directly capture millions of 3D points, creating highly accurate representations of topography, vegetation, and buildings. This capability transforms a drone’s perception of 3D space from mere avoidance to active, precise data collection, enabling applications like urban planning, construction progress monitoring, geological surveying, and environmental mapping.

The Future of 3D Flight Dynamics
As flight technology continues to evolve, our understanding and utilization of three-dimensional space become even more sophisticated. Future advancements will see drones navigating increasingly complex and dynamic 3D environments with greater autonomy and precision. Sensor fusion, integrating data from a wider array of sensors and modalities, will create more robust and comprehensive real-time 3D models of the operating environment. Artificial intelligence and machine learning will enable drones to not only perceive 3D space but also to understand its context, predict changes, and adapt their flight paths accordingly, leading to truly intelligent autonomous flight.
Applications like urban air mobility, where drones will share highly congested 3D airspace with other aerial vehicles, will demand hyper-precise 3D navigation and collision avoidance systems. Swarm intelligence will allow multiple drones to collaboratively map, inspect, or operate within 3D space, communicating and coordinating their movements to achieve complex tasks that are beyond the capability of a single unit. Ultimately, the continuous advancement in flight technology’s ability to interpret, interact with, and master three-dimensional space will unlock unprecedented possibilities for efficiency, safety, and innovation across countless industries.