
While the term “CMOS” (Complementary Metal-Oxide-Semiconductor) is most commonly associated with the small battery-backed memory chip on a PC motherboard that stores BIOS settings, date, and time, the underlying concept of resetting core system configurations to a factory default state is profoundly relevant and critical in the realm of drone technology. In drone flight controllers, which are essentially specialized miniature computers, this process involves wiping out user-defined parameters and calibrations from non-volatile memory, effectively “clearing” the custom setup to resolve issues, restore stability, or prepare the system for a new configuration. This fundamental technical operation falls squarely under the broader category of Tech & Innovation, representing a vital aspect of system maintenance, troubleshooting, and ensuring optimal performance for sophisticated aerial platforms.

The Concept of “CMOS Reset” in Flight Controllers
To fully grasp the implications of “clearing the CMOS” within drone technology, it’s essential to understand its functional equivalent in flight controller (FC) systems. Unlike traditional PCs with a dedicated CMOS chip, drone FCs utilize various forms of non-volatile memory (e.g., flash memory, EEPROM) to store critical operational data.
Analogy to PC Motherboards
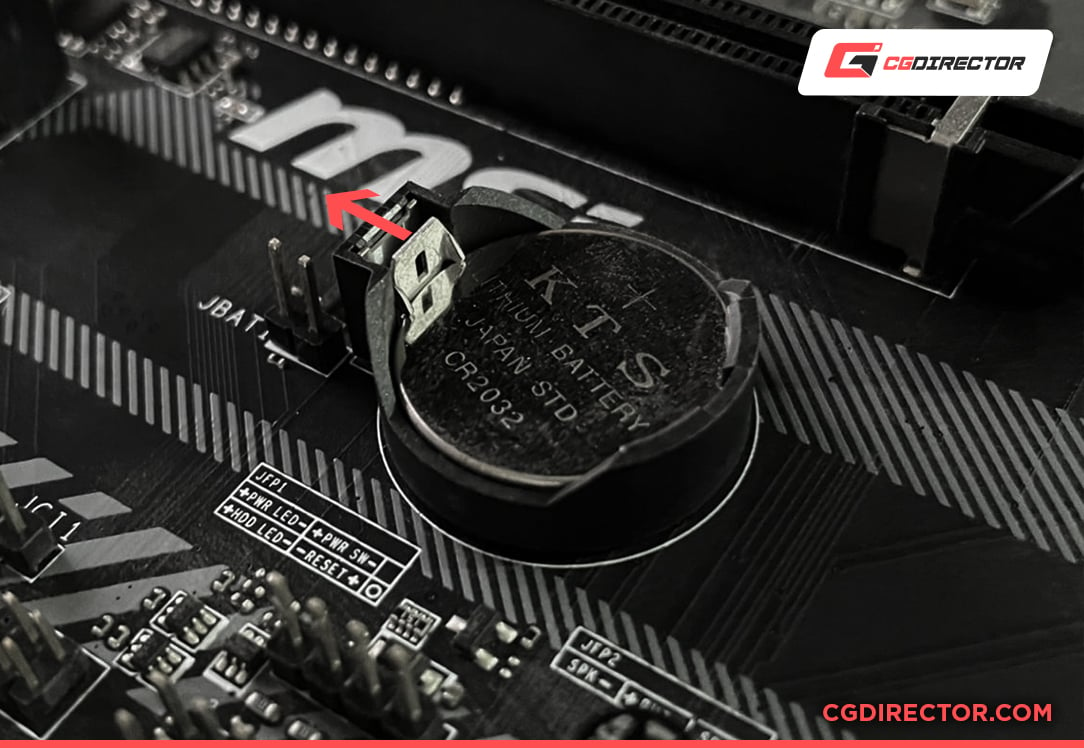
On a desktop computer, clearing the CMOS typically involves removing a small coin cell battery or using a jumper/button on the motherboard. This action erases the BIOS/UEFI settings, including boot order, hardware configurations, and system clock, reverting them to their manufacturer defaults. This is often done to resolve boot issues, fix incorrect overclocking settings, or troubleshoot hardware compatibility problems.
In the drone world, flight controllers perform analogous functions. They are the “brain” of the drone, responsible for interpreting pilot commands, stabilizing the aircraft, managing sensor data (accelerometers, gyroscopes, magnetometers, barometers, GPS), and controlling the electronic speed controllers (ESCs) that drive the motors. All the intricate parameters governing these functions – from PID (Proportional-Integral-Derivative) loop tunings that dictate flight characteristics, to port configurations for peripherals like GPS, telemetry, and FPV systems, to calibration data for sensors – are stored in the flight controller’s persistent memory. When these settings become corrupted, misconfigured, or lead to instability, a “reset” to defaults becomes the drone’s equivalent of clearing the CMOS.
Why Flight Controllers Need Configuration Memory
Flight controllers manage an immense array of settings crucial for autonomous and manual flight. These include:
- PID Gains: These are the coefficients that determine how the flight controller responds to errors in pitch, roll, and yaw, crucial for stable and responsive flight.
- Sensor Calibrations: Accurate calibration of accelerometers, gyroscopes, and magnetometers is vital for the FC to understand its orientation and movement in space.
- Port Assignments: Defining which UART (Universal Asynchronous Receiver/Transmitter) ports are used for GPS, telemetry, receiver input, VTX (video transmitter) control, etc.
- Mode Switches: Mapping specific flight modes (e.g., Angle, Acro, Altitude Hold, GPS Hold) to transmitter switches.
- ESC Protocols: Configuring communication protocols with the ESCs (e.g., DShot, OneShot, MultiShot).
- Failsafe Settings: Defining the drone’s behavior in case of signal loss (e.g., land, return to home, disarm).
- OSD (On-Screen Display) Layouts: Customizing the information displayed on the FPV feed.
All these parameters are stored in non-volatile memory so that the drone retains its configuration even after power is removed. Any issue with this stored data can manifest as erratic flight, unresponsive controls, sensor errors, or complete system failure.
Common Scenarios Requiring a Configuration Reset
Resetting a drone’s flight controller configuration to its default state is a powerful troubleshooting and maintenance tool employed in several critical situations.
Resolving Software Glitches and Unstable Behavior
Like any complex electronic system, flight controllers can experience software glitches or corrupted settings. This might manifest as:
- Erratic Flight Characteristics: Uncommanded movements, unexpected flips, or general instability that cannot be attributed to physical damage.
- Sensor Malfunctions: Inconsistent readings from gyros or accelerometers, leading to drift or incorrect orientation.
- Communication Errors: Problems with telemetry, receiver binding, or peripheral communication.
- Boot Loops or Failure to Arm: The drone might fail to properly initialize or allow arming, indicating a core configuration problem.
In such cases, a complete reset often provides a clean slate, allowing the user to reconfigure the system systematically and identify if the issue was indeed rooted in a software setting rather than hardware.
Recovering from Bad Configurations
One of the most common reasons to perform a “CMOS reset” on a drone is to recover from a “bad tune” or an incorrect configuration change. Experimenting with PID values, filter settings, or obscure features can inadvertently lead to an unflyable drone. Sometimes, a series of small, incremental changes accumulate to an unstable state, making it difficult to pinpoint the exact culprit. A full reset bypasses the need to manually undo each change, offering a quick return to a known, stable baseline provided by the firmware developers.
Facilitating Hardware Changes or Upgrades
When a drone undergoes significant hardware changes—such as replacing the flight controller itself, upgrading motors, ESCs, or adding new peripherals like a GPS module or a long-range radio system—it’s often advisable to start with a fresh configuration. While some settings can be migrated, a full reset ensures that the FC isn’t trying to operate with obsolete or incompatible settings from the previous hardware setup. This minimizes potential conflicts and streamlines the integration of new components.
Preparing for a Fresh Start or Resale
For enthusiasts building a new drone from scratch or taking over a used one, a configuration reset is standard practice. It ensures that the system is free of any previous owner’s customizations or potential issues, allowing the new builder/owner to configure it precisely to their preferences and components. Similarly, if selling a drone, resetting the FC to defaults is akin to factory resetting a smartphone, ensuring privacy and ease of setup for the next user.
How a “CMOS Reset” is Performed in Drone Systems
The methods for performing a configuration reset on a drone flight controller are typically software-driven, reflecting the sophisticated nature of these embedded systems.
Software-Based Reset via Configurator
The primary method for clearing a flight controller’s configuration is through its associated software configurator. Popular firmware like Betaflight, iNav, and ArduPilot each have desktop applications (e.g., Betaflight Configurator, iNav Configurator, Mission Planner) that allow users to connect to the FC via USB. Within these configurators, specific commands or buttons facilitate a reset:
- Betaflight/iNav: In the CLI (Command Line Interface) tab, the command
defaultsfollowed bysavewill reset all settings to the firmware’s default values. Alternatively, in newer versions, there might be a “Reset Settings” button in the “Setup” tab. - ArduPilot (Mission Planner/QGroundControl): Users can load firmware and choose to erase all settings during the flashing process. Alternatively, within the full parameter list, there’s often an option to “Reset to Default Params.”
These software-based resets are powerful because they interact directly with the non-volatile memory to clear or overwrite existing settings.
Physical Button or Jumper Method (Less Common for Full Reset)
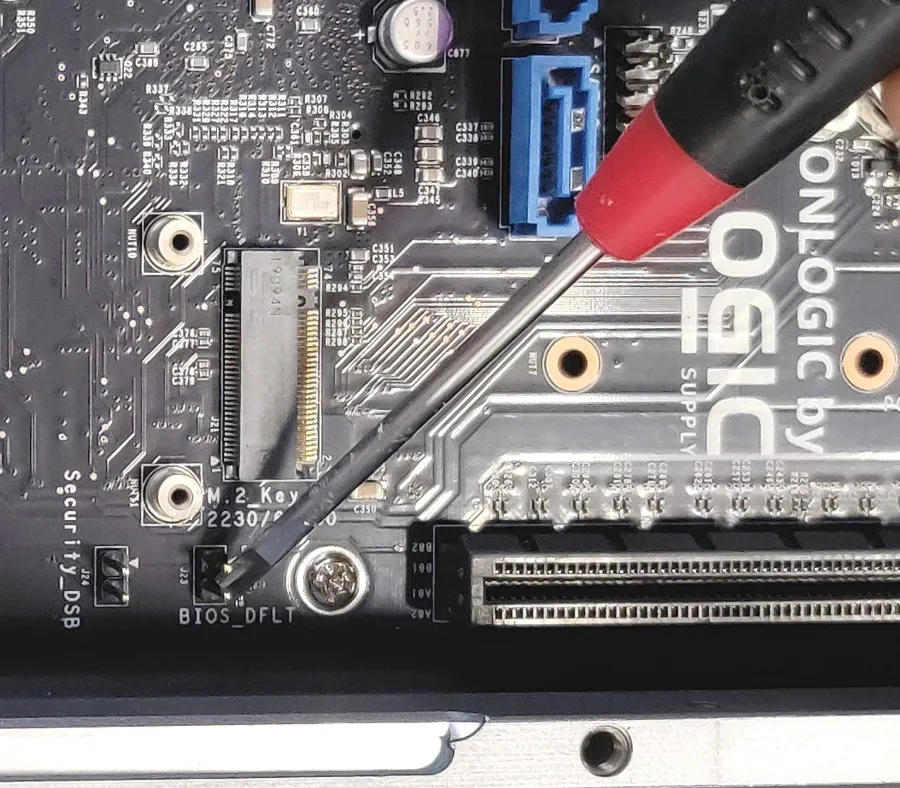
Unlike PCs, where a physical jumper or battery removal directly clears the CMOS, drone flight controllers rarely have an equivalent physical mechanism for a full configuration wipe. Instead, physical buttons or jumpers are more commonly used for:
- Bootloader Mode: Putting the FC into DFU (Device Firmware Update) or bootloader mode for flashing new firmware. This process often does erase current settings as part of flashing, but the button itself doesn’t just “clear settings” in isolation.
- Buzzer or LED Control: Some boards have physical buttons for specific functions, but not typically for a comprehensive configuration reset without a firmware reflash.
Therefore, the vast majority of “CMOS-like” resets in drones are initiated through the software configurators.
The Role of Firmware Flashing
Often, a configuration reset is performed in conjunction with, or as a consequence of, flashing new firmware. When new firmware is loaded onto the flight controller, users typically have the option to “Full Chip Erase” or “No reboot sequence” which effectively wipes all existing settings. This is a robust way to ensure a completely clean slate, as it not only resets parameters but also updates the underlying operating system of the FC. This method is particularly useful when upgrading to a new major firmware version or when dealing with deeply entrenched software issues.
Implications and Best Practices
While performing a configuration reset is a valuable tool, it’s a significant action with specific implications and requires careful consideration.
Data Loss and Backup Procedures
The most immediate consequence of a configuration reset is the loss of all custom settings, calibrations, and tunings. This includes carefully dialed-in PIDs, custom OSD layouts, specific port assignments, and receiver configurations. To mitigate this data loss, it is crucial to:
- Backup CLI Dumps: Before performing any major changes or a reset, always connect to your flight controller via the configurator and save a full CLI dump (a text file containing all current settings). This file can then be used to restore settings quickly after a reset or new firmware flash by simply pasting the commands back into the CLI.
- Save Parameter Files: For ArduPilot-based systems, saving a full parameter file through Mission Planner or QGroundControl achieves the same goal.
- Document Unique Settings: Some settings might be specific to your build and not easily captured in a dump, such as physical mounting angles of components. Document these separately.
Re-calibration and Re-configuration Post-Reset
After a reset, the drone effectively becomes an unconfigured blank slate. This necessitates a complete re-setup process:
- Sensor Calibration: Accelerometers and gyroscopes must be re-calibrated. For multirotors, this typically involves leveling the drone and following the calibration wizard in the configurator.
- Receiver Setup: Binding the receiver to the transmitter and configuring channel mapping and endpoints.
- Motor/ESC Configuration: Ensuring correct motor direction and ESC protocol.
- PID Tuning: For performance-oriented drones, the entire PID tuning process may need to be repeated from scratch to achieve optimal flight characteristics. This is often the most time-consuming part.
- Peripheral Configuration: Re-enabling and configuring GPS, telemetry, OSD, VTX, and any other connected devices on their respective UARTs or soft serial ports.
- Failsafe Setup: Critically, the failsafe behavior must be re-established to ensure the drone acts safely in case of signal loss.
Preventing Future Issues
While resets are useful for recovery, proactive measures can reduce their necessity:
- Incremental Changes: Make one change at a time and test it thoroughly. This makes it easier to pinpoint the cause if an issue arises.
- Regular Backups: Make backing up your configuration a routine practice, especially after a successful tune or significant setup change.
- Stay Informed: Keep up-to-date with firmware release notes and best practices for your specific flight controller and components.
- Understand Settings: Avoid randomly changing parameters without understanding their function. Consult documentation and community resources.
In conclusion, “clearing the CMOS” in drone technology translates to resetting the flight controller’s configuration to its factory defaults. This process is an indispensable tool within Tech & Innovation for troubleshooting, recovering from misconfigurations, accommodating hardware changes, and preparing a drone for new ownership. By understanding its purpose, execution, and implications, drone operators and builders can maintain the reliability and performance of their advanced aerial systems.