
In the intricate world of Flight Technology, understanding fundamental physics principles is paramount for the design, operation, and safety of aerial vehicles, particularly drones. Among these foundational concepts, the “normal force” plays a surprisingly critical, yet often overlooked, role. While commonly associated with static objects resting on surfaces, its implications extend deeply into how drone components are integrated, how landing systems absorb impact, and how stabilization systems maintain equilibrium. Far from being a mere academic curiosity, mastering the concept of normal forces enables engineers to craft more robust, reliable, and efficient flight platforms.
The Physics Behind Support and Contact in Flight Systems
At its core, a normal force is a contact force exerted by a surface on an object that is perpendicular to that surface. This force prevents the object from passing through the surface, providing essential support. In the context of flight technology, particularly drones, this interaction is fundamental to virtually every aspect of the system, from the ground up.

Defining Normal Force in an Aerospace Context
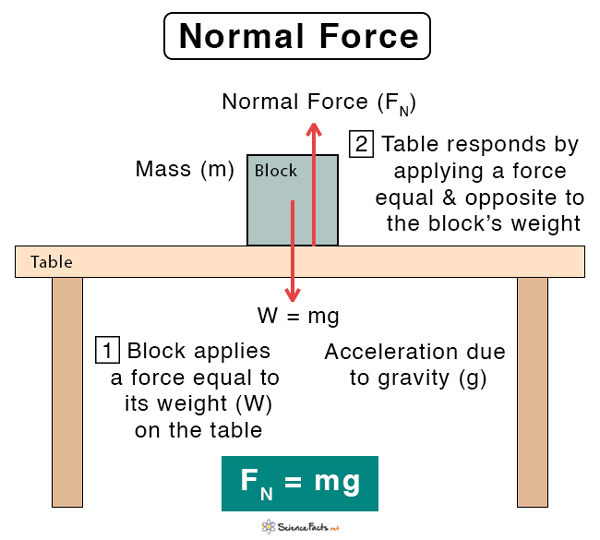
The normal force ($F_N$) is a reaction force. When a drone or any of its components makes contact with a surface, it exerts a force on that surface. According to Newton’s Third Law of Motion, the surface simultaneously exerts an equal and opposite force back on the drone, perpendicular to the surface of contact. This reaction force is what we define as the normal force.
Consider a drone resting on a launch pad. The drone’s weight (a force exerted downwards due to gravity) acts on the pad. The pad, in turn, exerts an upward normal force on the drone, preventing it from falling through. The magnitude of this normal force is equal to the drone’s weight in this static scenario. However, the dynamics change significantly during landing, impact, or when components within the drone are subjected to acceleration.
The origin of the normal force lies in the electromagnetic repulsion between the atoms of the two surfaces in contact. As objects attempt to occupy the same space, the electron clouds of their atoms resist, creating a repulsive force. This microscopic interaction manifests macroscopically as the normal force we calculate and design around. For flight engineers, recognizing that every component housed within a drone — from the flight controller board to the battery pack — is supported by a normal force from its mounting structure is crucial.
Newton’s Third Law in Action Across Drone Subsystems
Newton’s Third Law, which states that for every action, there is an equal and opposite reaction, is the cornerstone of understanding normal forces. This law is not just an abstract principle; it dictates how stresses are managed, how energy is dissipated, and how stability is achieved in a drone system.
For instance, during a hard landing, the drone’s landing gear exerts a significant downward force on the ground upon impact. Simultaneously, the ground exerts an equally significant upward normal force on the landing gear. The design of the landing gear, including its material properties and geometry, is optimized to manage and distribute this normal force, absorbing kinetic energy and preventing damage to the drone’s delicate internal components. Without an effective mechanism to manage these reaction forces, the drone would suffer structural failure or experience damaging shock loads.
Furthermore, within the drone itself, every sensor, motor, camera, and battery module is held in place by mounts, screws, or adhesive interfaces. These interfaces exert normal forces on the components, counteracting gravitational forces, acceleration forces during maneuvers, and vibrational forces from propellers. The integrity of these normal force interactions is critical for the reliable operation of the entire flight system. A loose mounting point means inconsistent normal forces, leading to vibrations, data inaccuracies, or even catastrophic failure.
Normal Forces in Drone Design and Operation
The practical application of understanding normal forces permeates numerous aspects of drone design and operational strategy, directly impacting performance, safety, and longevity.
Landing Gear and Impact Management
The most overt application of normal forces in flight technology is seen in landing gear design. Whether fixed skids, retractable wheels, or shock-absorbing struts, the primary function of landing gear is to manage the normal force generated upon contact with a landing surface.
Engineers meticulously calculate the maximum anticipated normal force during various landing scenarios, including emergency landings or accidental drops. The materials chosen for landing gear, such as carbon fiber composites or specialized plastics, possess specific elastic moduli and yield strengths to withstand and distribute these forces. The geometry of the gear often incorporates dampening mechanisms, like springs or elastomers, which compress upon impact. This compression effectively increases the time over which the normal force acts, thereby reducing the peak force experienced by the drone’s airframe and internal components (as force = impulse / time). This critical design consideration prevents structural damage, protects sensitive electronics, and ensures the drone remains operational after landing.
Securing Internal Components
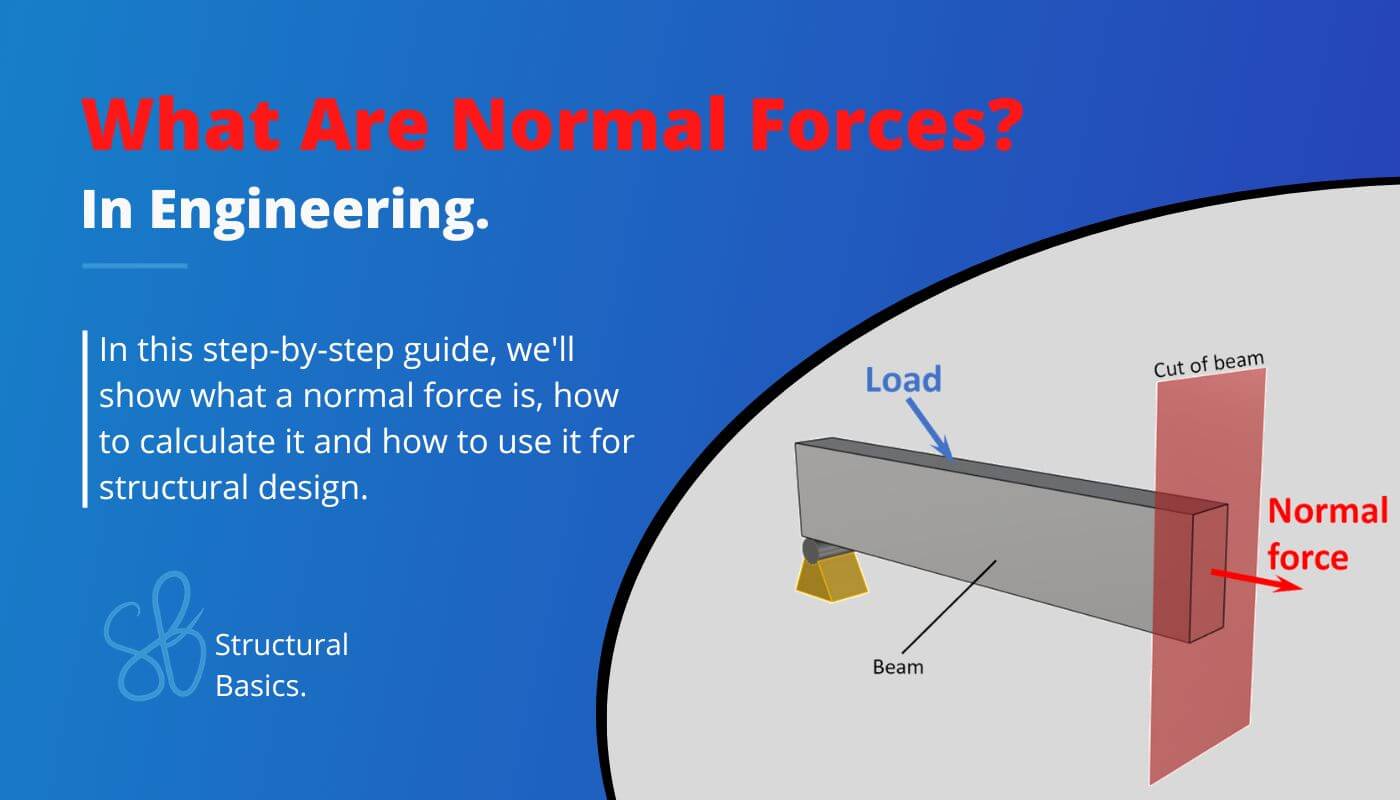
Beyond external interactions, normal forces are continuously at play within the drone’s internal architecture. Every circuit board, battery, GPS module, and camera system is secured to the drone’s frame. The screws, clips, mounts, and dampeners that hold these components in place exert normal forces to counteract gravity, vibrations, and the inertial forces generated during rapid acceleration, deceleration, or turns.
Inadequate normal forces from mounting hardware can lead to components becoming loose, vibrating excessively, or even detaching. This can cause:
- Signal Interference: Vibrating sensors might produce noisy or inaccurate data, compromising navigation or stabilization.
- Electrical Shorts: Loose components could short-circuit delicate electronics.
- Structural Fatigue: Constant small impacts from rattling components can lead to material fatigue in the drone’s frame over time.
Therefore, aerospace engineers pay close attention to fastening techniques, torque specifications for screws, and the design of custom mounts that provide consistent and adequate normal force distribution, often incorporating vibration-dampening materials to isolate sensitive components from the drone’s primary frame.
Material Science and Structural Durability
The structural integrity of a drone relies heavily on its ability to manage and withstand normal forces throughout its lifespan. The choice of materials for the drone’s frame – whether aluminum, carbon fiber, or various polymers – is determined by their strength-to-weight ratio and their resistance to deformation under stress, including stresses arising from normal forces.
For example, the arms supporting the motors and propellers are subjected to normal forces from the weight of the motor and propeller assembly, as well as dynamic forces during flight. The design must ensure these sections do not buckle or crack under these loads. Similarly, the shell enclosing the drone’s electronics must be robust enough to withstand incidental impacts, which generate localized normal forces, without compromising the internal components. Material properties such as compressive strength and stiffness directly relate to a material’s ability to resist deformation when a normal force is applied.
Beyond Static Support: Dynamic Implications
While normal forces are intuitively understood in static contexts, their dynamic implications are just as vital for advanced flight technology, influencing sensor accuracy and the effectiveness of stabilization systems.
Sensors and Measurement Accuracy
Sensors are the eyes and ears of a drone, providing critical data for navigation, control, and mission execution. Many sensors, such as accelerometers and gyroscopes (part of the Inertial Measurement Unit, or IMU), are susceptible to external forces and vibrations. While the normal force itself isn’t directly measured, the integrity of the normal forces holding the sensor in place significantly impacts its ability to provide accurate data.
If a sensor is improperly mounted, experiencing inconsistent normal forces, it can vibrate excessively. These vibrations introduce erroneous acceleration values, known as noise, into the sensor readings. A noisy IMU will lead to drift in position estimation, unstable flight characteristics, and impaired autonomous capabilities. Therefore, securing sensors with consistent and appropriate normal forces, often coupled with vibration isolation systems, is paramount to maintaining data fidelity and, consequently, flight stability and navigational precision.
The Role in Stabilization Systems
Drone stabilization systems work by continuously adjusting motor thrusts based on sensor feedback (primarily from the IMU) to counteract external disturbances like wind or internal imbalances. While these systems primarily deal with aerodynamic forces, moments, and torques, the reliable operation of the sensors that feed these systems is underpinned by normal forces.
A stable platform for the IMU, ensured by appropriate normal forces holding it rigidly, allows the stabilization algorithms to receive clean, accurate data about the drone’s orientation and motion. Without this foundation, the control loops would be attempting to stabilize a system based on faulty information, leading to erratic behavior, loss of control, or inefficient power consumption as motors overcompensate for perceived (but not real) movements. Essentially, precise normal force management contributes to the overall structural rigidity, which in turn allows the delicate feedback control systems to operate optimally.
Optimizing for Performance and Longevity
The comprehensive understanding and application of normal force principles are critical for optimizing drone performance and ensuring longevity. From the initial design phase to routine maintenance, every decision involving structural components, mounting hardware, and material selection indirectly or directly leverages these physics concepts.
Engineers employ finite element analysis (FEA) to simulate how normal forces (along with shear and tensile forces) are distributed across a drone’s airframe and components under various operational loads. This allows for proactive design adjustments, reinforcing stress points and optimizing material use to achieve a balance between strength and weight. Lightweighting, a perennial goal in aerospace, must always be balanced against the need to withstand critical normal forces without compromising structural integrity.
Furthermore, proper assembly techniques and regular inspection of mounting hardware are essential for maintaining the intended normal forces throughout a drone’s operational life. Loose screws or worn-out dampeners can compromise the system, leading to performance degradation or premature failure. Thus, understanding “what are normal forces” is not just about academic knowledge but about practical application in crafting reliable, high-performance flight technology that can withstand the rigors of aerial operation.