
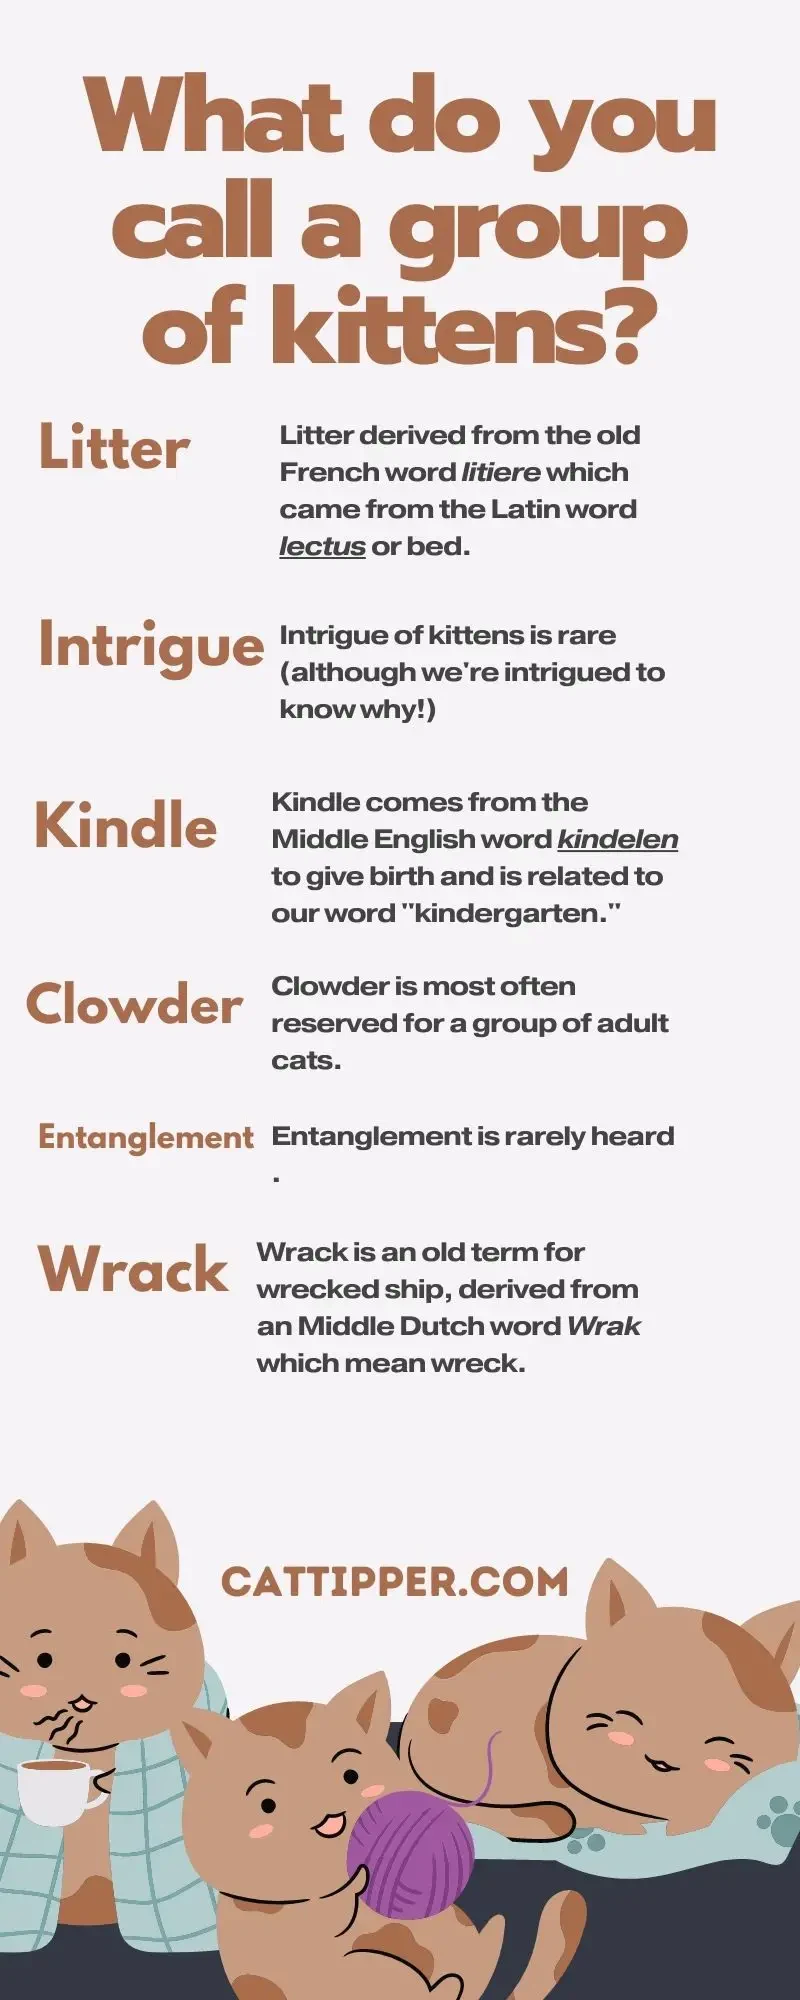
In the rapidly evolving landscape of Tech & Innovation, the nomenclature we use to describe emerging technologies often borrows from the natural world to convey complex behaviors. When discussing the coordination of multiple autonomous units—specifically Coordinated Autonomous Technologies (CAT)—the question of what these groups are called transcends mere semantics. In the world of high-level robotics, AI-driven flight, and remote sensing, a group of these “CAT” units is most accurately defined as a “swarm,” a “fleet,” or a “multi-agent system.”
Understanding the architecture of these groupings is essential for grasping the future of autonomous flight. Unlike traditional drone operations where a single pilot controls a single craft, Tech & Innovation has moved toward a decentralized model. In this paradigm, groups of autonomous agents work in concert, mimicking the biological efficiency of animal clusters to perform tasks that would be impossible for a solitary unit.
Beyond the Fleet: The Technical Nomenclature of Autonomous Groups
In the early stages of drone development, a collection of unmanned aerial vehicles (UAVs) was simply referred to as a “fleet.” This term, borrowed from maritime and aviation history, implied a centralized command structure where each unit was individually directed or followed a pre-programmed, static path. However, as AI Follow Mode and autonomous flight algorithms have matured, the terminology has shifted to reflect the increasing “intelligence” of the group.
The Rise of the Swarm
A “swarm” is perhaps the most significant term in modern drone innovation. Unlike a fleet, a swarm operates on the principle of decentralization. There is no single “leader” drone; instead, each unit in the group makes real-time decisions based on the behavior of its neighbors and the data gathered by its own sensors. This is achieved through sophisticated algorithms that allow for emergent behavior, where the group functions as a single, cohesive organism. This technical leap is what allows dozens or even thousands of units to navigate complex environments without colliding.
Multi-Agent Systems (MAS)
In academic and high-level engineering circles, groups of autonomous drones are referred to as Multi-Agent Systems. This term highlights the individual processing power of each unit. Each “agent” in the system has its own goals, sensors, and decision-making capabilities, but they share a common communication protocol. This allows them to negotiate tasks, such as dividing a large-scale mapping area into smaller, more manageable sectors, ensuring maximum efficiency and redundancy.
Constellations and Meshes
When groups of drones are used specifically for remote sensing or persistent surveillance, they are often referred to as “constellations.” This term, borrowed from satellite technology, emphasizes the spatial distribution of the units. Similarly, when the focus is on the communication network established between the units, the group is described as a “mesh.” In a mesh network, each drone acts as a relay point, allowing data to travel across vast distances by hopping from one unit to the next.
The AI Architecture Behind Collective Flight
The transition from individual drones to coordinated groups is driven by breakthroughs in Artificial Intelligence. To understand how these groups function, one must look at the underlying software frameworks that govern their interaction.
Swarm Intelligence and Boids Theory
At the heart of autonomous group flight is the concept of “Swarm Intelligence.” This is modeled after biological phenomena such as bird flocking or fish schooling. The foundational algorithm used in this field is known as “Boids,” developed by Craig Reynolds. It relies on three simple rules for each unit:
- Separation: Avoid crowding local flockmates.
- Alignment: Steer toward the average heading of local flockmates.
- Cohesion: Steer toward the average position of local flockmates.
In a technical “CAT” system, these rules are enhanced with AI-driven obstacle avoidance and real-time path planning. This allows a group of drones to flow through a forest or an urban canyon as a single unit, dynamically adjusting their shape to fit the environment.
Distributed Sensing and Edge Computing
For a group of drones to function autonomously, they cannot rely on a distant ground control station to process their data. This would create a latency bottleneck that would lead to mid-air collisions. Instead, Tech & Innovation has focused on “Edge Computing.” Each drone in the group possesses enough onboard processing power to analyze its surroundings in real-time.
When one unit detects an obstacle or a point of interest, it broadcasts that information to the rest of the group via a low-latency mesh network. This distributed sensing capability means the group’s “vision” is the sum of all its parts, providing a 360-degree, multi-angle view of the operational theater that no single drone could ever achieve.
Mapping and Remote Sensing: The Power of Synchronized Units
One of the most practical applications for groups of autonomous drones is in the field of mapping and remote sensing. The innovation here lies in the “divide and conquer” approach enabled by collective intelligence.
Collaborative SLAM (Simultaneous Localization and Mapping)
SLAM is the process by which a robot builds a map of an unknown environment while simultaneously keeping track of its own location within that map. In a group setting, this becomes “Collaborative SLAM.” Multiple drones fly through a structure—such as a collapsed building or a subterranean mine—and share their mapping data in real-time. The AI merges these individual data streams into a single, high-fidelity 3D model. This significantly reduces the time required to map large areas and provides a level of detail that is essential for search and rescue or industrial inspection.
Temporal and Spatial Resolution
Using a group of drones allows for a massive increase in both temporal and spatial resolution. For instance, in agricultural remote sensing, a single drone might take hours to scan a thousand-acre farm. A coordinated group can deploy across the entire field simultaneously, capturing a “snapshot” of the entire area at a single moment in time. This eliminates variables like changing light conditions or moving shadows, resulting in much more accurate data for AI analysis.
Hardware Innovation: Supporting the Group Dynamic
While software and AI are the brains of the operation, the physical hardware must also evolve to support grouped flight. Innovation in this sector focuses on communication, power management, and modularity.
Mesh Radio Systems
Traditional radio links are point-to-point (controller to drone). For a group of “CAT” units to work, they require mesh radio systems. These specialized transceivers allow drones to talk to each other directly. If one drone moves out of range of the ground station, it can still receive commands by “hopping” the signal through other drones in the group. This creates a self-healing network that is incredibly resilient to interference or signal loss.
Decentralized Power and Charging
A significant challenge in operating drone groups is logistics. Innovation in “drone-in-a-box” technology and automated charging pads allows groups to operate semi-permanently. When one unit’s battery runs low, it can autonomously peel away from the group to recharge, while a fresh unit takes its place in the formation. This “hot-swapping” of units ensures continuous coverage for mapping or surveillance missions.
Modular Sensor Suites
To maximize the utility of a group, not every drone needs to carry the same sensor. Tech & Innovation has led to the development of modular units where one drone might carry a high-resolution LiDAR scanner, another an infrared thermal camera, and a third a multi-spectral sensor. The AI integrates these diverse data types into a “fused” data product, providing a comprehensive understanding of the environment that would be physically impossible to capture with a single aircraft.
The Future of Autonomous Coordination: The Self-Organizing Fleet
As we look toward the future of Tech & Innovation, the goal is to achieve true self-organization. This represents the pinnacle of autonomous flight, where a group of drones is given a high-level objective—such as “search this 50-mile radius for signs of erosion”—and the units decide among themselves how to best execute the mission.
Heterogeneous Swarms
The next frontier is the development of heterogeneous swarms—groups consisting of different types of autonomous vehicles. This could include aerial drones working with ground-based rovers and sub-surface submersibles. In this scenario, the “CAT” system becomes a multi-domain network. The aerial units provide high-level reconnaissance and relay communication, while the ground units perform close-up inspections.

Predictive Maintenance and Self-Diagnostics
Future iterations of autonomous groups will feature integrated AI that monitors the “health” of the entire swarm. If the system detects that a specific motor on one unit is vibrating outside of normal parameters, the group’s collective intelligence will re-route the mission parameters to compensate for the failing unit or autonomously schedule it for maintenance. This level of self-awareness is critical for the long-term deployment of drone groups in remote or hazardous environments.
In conclusion, while the title “what are groups of cats called” might evoke images of a “clowder” in a biological sense, in the high-stakes world of Tech & Innovation, these groups are the backbone of a new era of efficiency. Whether we call them swarms, fleets, or multi-agent systems, the coordinated movement of autonomous technologies represents a fundamental shift in how we interact with and perceive our world. Through the integration of AI Follow Mode, collaborative mapping, and mesh networking, these groups are transforming from a collection of individual tools into a single, powerful, and intelligent entity.