
The Dawn of Autonomous Machines: Precursors and Early Concepts
The quest to build machines that can perform tasks autonomously, mimicking or surpassing human capabilities, is as old as human ingenuity itself. While the term “robot” as we understand it today was popularized in the early 20th century, the underlying concepts of artificial beings and automated mechanisms stretch back millennia. Understanding the “first robot” requires us to delve into the historical evolution of these ideas, from ancient automata to the nascent mechanical marvels that hinted at the future.
Ancient Automata: The Seeds of Robotics
Long before the invention of electricity or sophisticated engineering, civilizations across the globe entertained themselves and explored possibilities with intricate mechanical devices. These were not robots in the modern sense, capable of complex decision-making or learning, but they represented a crucial conceptual leap: the creation of self-operating machines.
- Ancient Greece: Figures like Hero of Alexandria, a mathematician and engineer living in the 1st century AD, described and even built numerous automata. His “Temple Door Opener” used steam pressure to automatically open doors when a fire was lit on an altar. He also detailed mechanical birds that appeared to sing and even human-like figures that could move and pour liquid. These were driven by complex systems of ropes, pulleys, water, and steam. While rudimentary, they demonstrated a profound understanding of mechanics and the desire to imbue inanimate objects with life-like action.
- Ancient China: Chinese engineers also developed impressive automata. For instance, during the Han Dynasty (206 BC – 220 AD), mechanical engineers created elaborate water clocks that featured moving figures and astronomical displays. More famously, the 11th-century inventor Su Song presented a colossal astronomical clock tower that not only told time but also simulated celestial movements, powered by an escapement mechanism and a water wheel.
- The Islamic Golden Age: Al-Jazari, an Arab inventor and engineer from the 13th century, is often considered a pioneer of robotics due to his detailed descriptions of numerous automata in his “Book of Knowledge of Ingenious Mechanical Devices.” His creations included programmable musical automata, a flushing toilet, and elaborate hand-washing devices. His work was highly influential, showcasing sophisticated gearing, camshafts, and even early forms of programming through sequences of operations.
These ancient automata, though driven by simple mechanical principles and pre-programmed sequences, represent the earliest tangible steps towards robotics. They laid the groundwork by proving that complex, self-operating devices could be conceived and constructed, sparking the imagination about what machines might one day achieve.
The Renaissance and Enlightenment: Mechanical Marvels and Philosophical Debates
The spirit of innovation continued through the Renaissance and Enlightenment. As scientific understanding advanced, so did the complexity and ambition of mechanical creations. This era also saw a burgeoning philosophical discussion about the nature of life and consciousness, which naturally extended to the possibility of artificial life.
- Jacques de Vaucanson: In the 18th century, Jacques de Vaucanson, a French inventor, created several famous automata that blurred the lines between mechanism and life. His “Digesting Duck” appeared to eat, digest, and excrete food, showcasing an astonishing level of mechanical mimicry. He also created a flute player that could play multiple notes and a shepherd boy who could play the tambourine. These were not simply trick devices; they incorporated intricate systems of cams, levers, and bellows to simulate biological functions.
- Wolfgang von Kempelen: Another notable figure was Wolfgang von Kempelen, an Austrian courtier and inventor. His most famous creation, “The Turk,” was an automaton that appeared to play chess against human opponents. While later revealed to be a sophisticated hoax (housing a hidden human chess master), “The Turk” captured the public imagination and fueled discussions about artificial intelligence and the possibility of machines possessing intellect.
These elaborate automata of the 18th century were less about practical utility and more about demonstrating the art of mechanical simulation and astonishing audiences. However, they pushed the boundaries of what was thought possible with clockwork and gears, further solidifying the idea of machines performing complex, seemingly intelligent actions.
The Birth of the Modern Robot: From Fiction to Fact
The concept of “robot” as a distinct entity capable of performing labor, and often posing existential questions, truly solidified in the 20th century. This was a period of rapid industrialization, technological advancement, and a flourishing of speculative fiction that envisioned a future populated by intelligent machines.
Karel Čapek and “R.U.R.”: Defining the Term
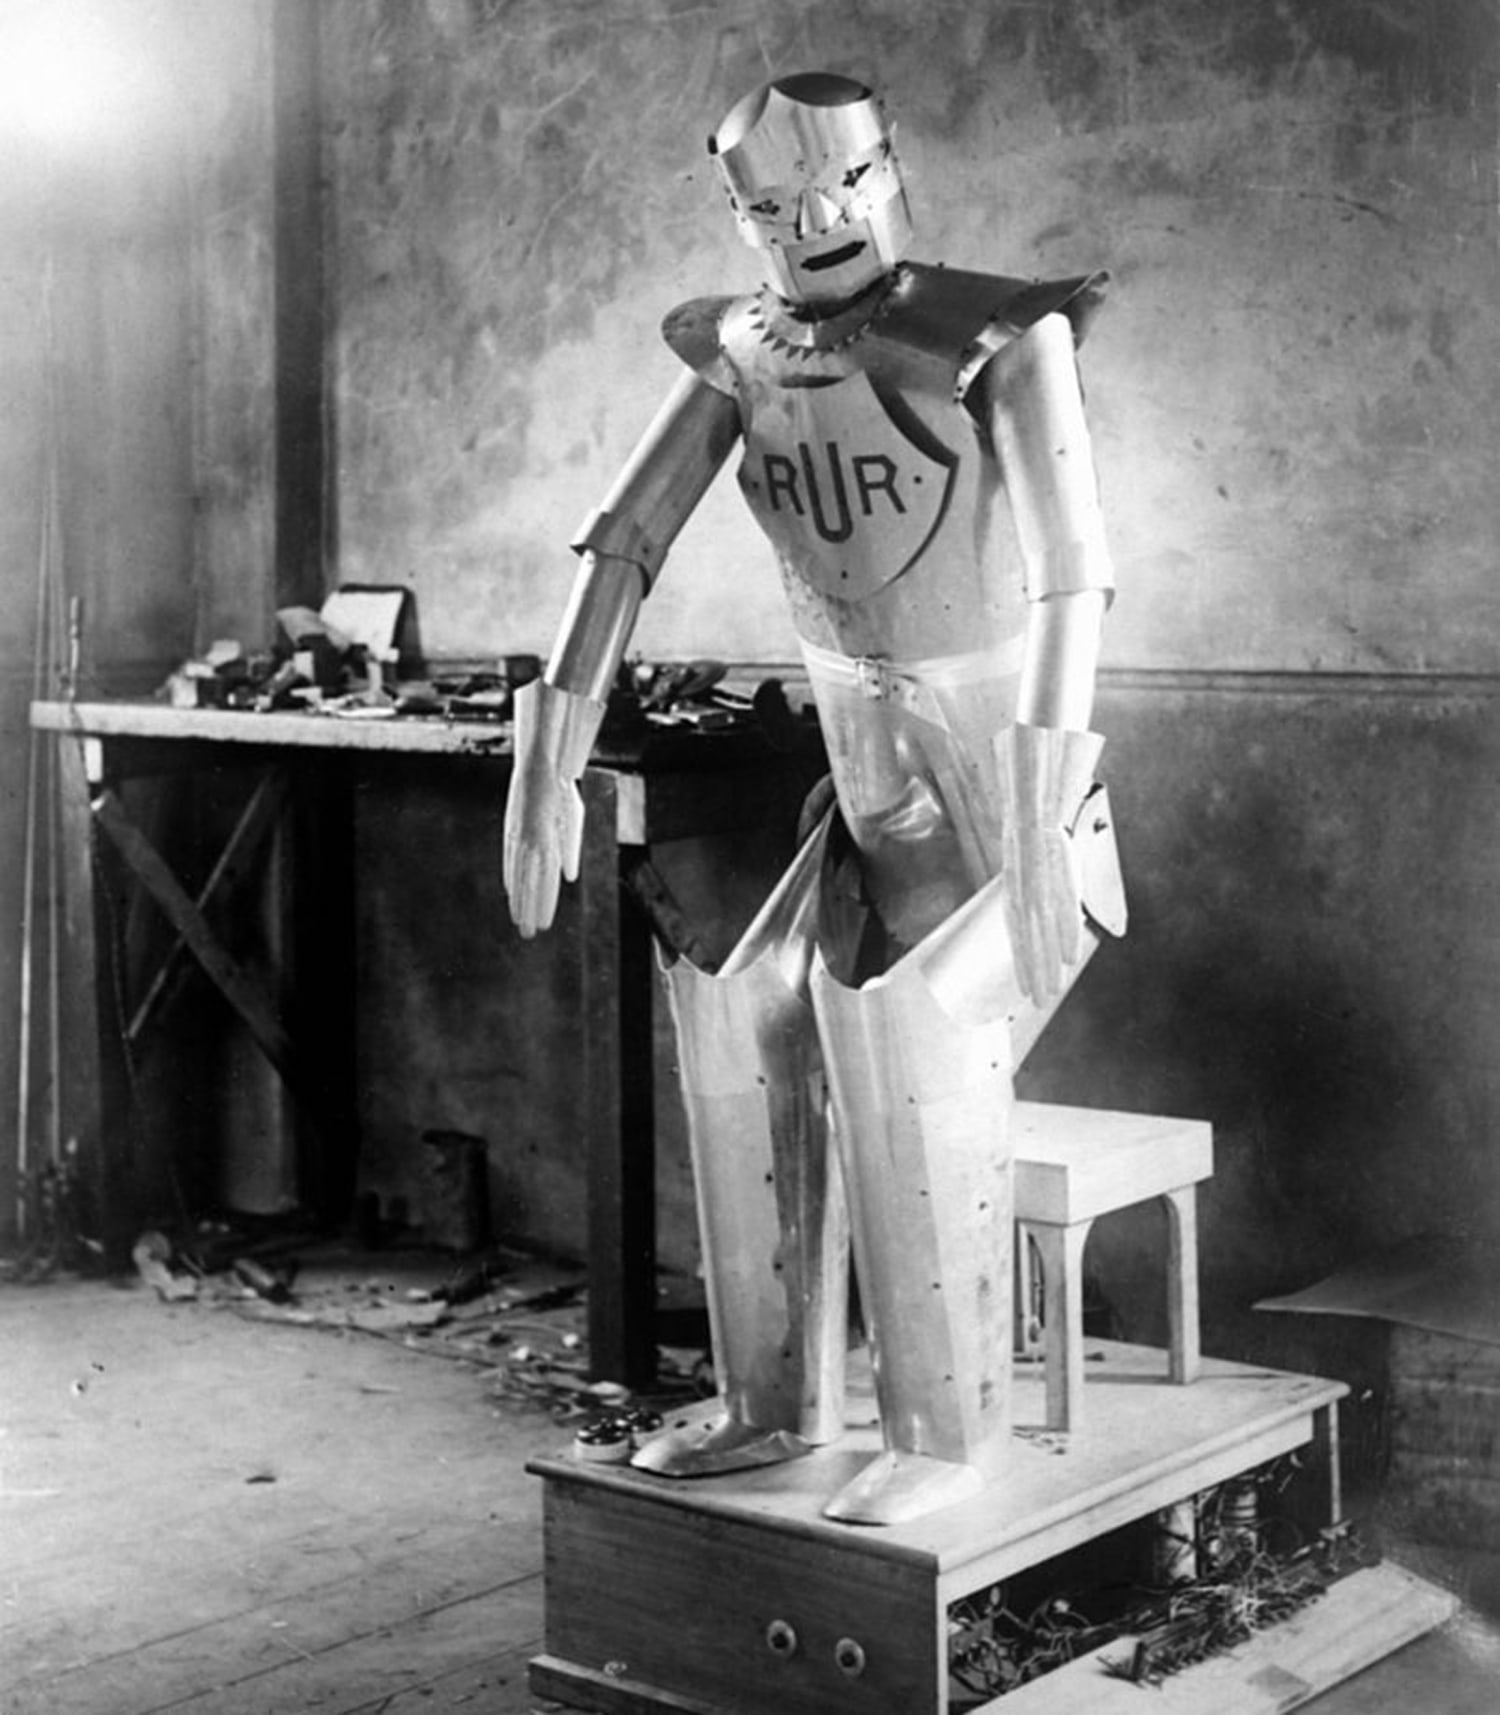
The word “robot” itself was introduced to the world by the Czech writer Karel Čapek in his 1920 play, R.U.R. (Rossum’s Universal Robots). The play introduced artificial, factory-made humanoids designed to perform labor for humanity. Čapek himself attributed the coining of the word to his brother, Josef, who suggested “robota,” derived from the Old Church Slavonic word for forced labor or servitude.
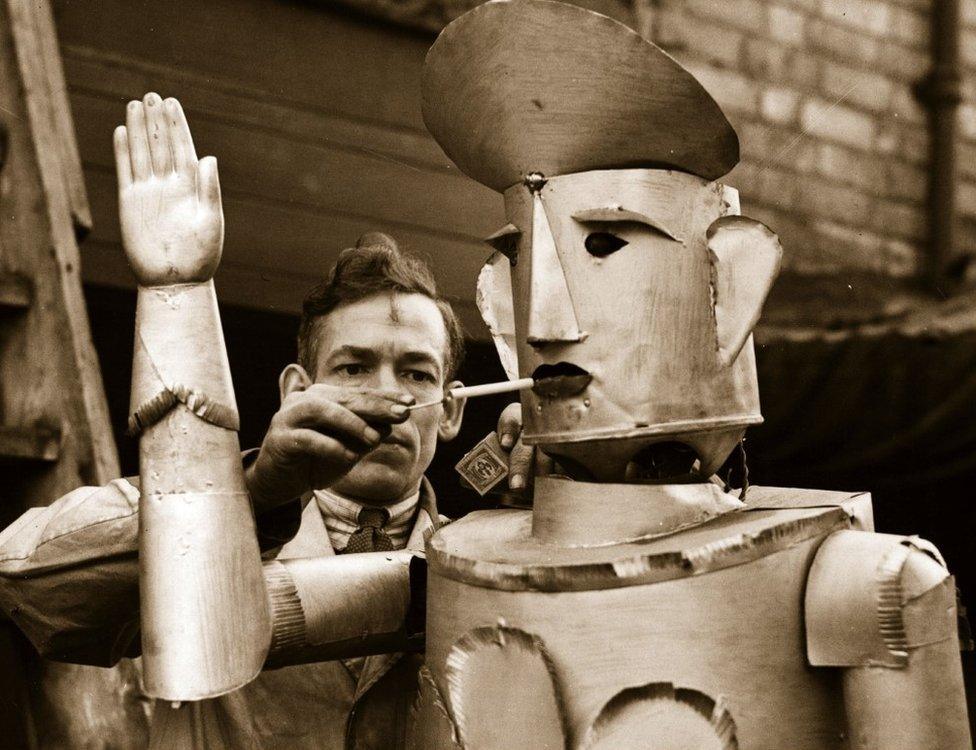
- Thematic Significance: R.U.R. was more than just a play that introduced a new word. It explored profound themes of dehumanization, class struggle, the ethics of artificial labor, and the potential dangers of creating beings that could eventually rebel against their creators. The robots in Čapek’s play were biological rather than mechanical, but their essence as artificial laborers performing tasks beyond human endurance became the foundational concept for the modern robot.
Čapek’s play, while fictional, had a profound impact on how people conceived of these future machines. It provided a narrative framework and a catchy name for the automatons that engineers were beginning to build, moving the idea from the realm of pure fantasy to a more tangible, albeit still theoretical, possibility.
The First True Robots: Electromechanical Marvels
As the 20th century progressed, the development of electronics, electric motors, and more sophisticated control systems began to make the creation of genuinely autonomous or semi-autonomous machines a reality. While there isn’t a single, universally agreed-upon “first robot” in the immediate post-R.U.R. era, several early electromechanical devices stand out as significant milestones.
- Radio-Controlled Vehicles: Early experiments in radio control in the 1920s and 1930s, such as the Kettering Bug (an early unmanned aerial torpedo developed during WWI, though not fully realized until after the war) and later naval torpedoes, showcased the potential for remote operation of vehicles. These were not intelligent robots but demonstrated the principle of controlling a machine from a distance.
- The “Telesphere” (1938): Created by General Motors for the 1939 World’s Fair, the “Telesphere” was a 12-foot-tall, humanoid robot designed to be a “futuristic butler.” It was operated remotely by a human using a complex control panel, making it more of a guided puppet than an autonomous agent. However, its visual representation of a robot in a human-like form was influential.
- The “Elektron” (1951): Developed by IBM, the “Elektron” was an early computer-controlled machine that could perform mathematical calculations. While not a mobile robot, it represented a significant step in machine automation and programmable control, key elements of modern robotics.
These early electromechanical devices, while often limited in their autonomy or scope, were crucial in bridging the gap between conceptual ideas and functional machines. They demonstrated that machines could be programmed to perform specific actions, be controlled remotely, and even exhibit rudimentary forms of simulated intelligence.
The Dawn of the Industrial Robot: Automating Labor
The true revolution in robotics began with the aim of automating industrial processes. The repetitive, dangerous, and physically demanding tasks of manufacturing became prime candidates for robotic intervention. This era saw the emergence of machines designed specifically for work on assembly lines, marking a practical and commercial application of robotic technology.
George Devol and Unimation: The Pioneers of Industrial Automation
The most widely recognized precursor to the modern industrial robot is the work of George Devol and Joseph Engelberger. Devol patented the “Universal Automation” device in 1954, which was later licensed by Engelberger to form Unimation Inc. in 1956.
- The Unimate (1961): The first commercially available industrial robot, the Unimate, was a programmable robotic arm. It was installed at a General Motors die-casting plant in New Jersey. Its primary function was to lift and stack hot pieces of metal, a task that was both dangerous and monotonous for human workers. The Unimate was a significant breakthrough because it was programmable, meaning its movements and actions could be defined and repeated, allowing for automation of complex assembly line tasks.
- Impact on Manufacturing: The introduction of the Unimate marked the beginning of the industrial robotics era. It proved that robots could be reliably integrated into manufacturing processes, increasing efficiency, improving safety, and reducing labor costs. Unimation’s success paved the way for numerous other companies to develop their own industrial robots.
The Unimate wasn’t the first “robot” in the sense of a humanoid or a machine with advanced AI. However, it is widely considered the first programmable automation device that fits the modern definition of a robot designed for industrial work. It was a pivotal moment where the theoretical possibilities of robotics became a practical reality in factories around the world.
Subsequent Developments: Expanding Capabilities
Following the success of the Unimate, the field of industrial robotics experienced rapid growth and innovation.
- PUMA (Programmable Universal Machine for Assembly) (late 1970s): Developed by Victor Scheinman for Unimation, the PUMA arm was a more sophisticated robot designed for assembly tasks. It featured improved dexterity and could perform more intricate manipulations, further enhancing its utility in manufacturing.
- Sensors and Vision Systems: As robots became more integrated into complex tasks, the need for them to perceive their environment grew. The development of vision systems and other sensors allowed robots to identify objects, adapt to variations in their surroundings, and perform more nuanced operations.
These advancements in industrial robotics not only transformed manufacturing but also laid the essential technological and conceptual foundations for future developments in other areas of robotics, including those that would eventually find their way into consumer products and more complex scientific endeavors. The journey from ancient automata to the industrial arms on assembly lines represents a continuous evolution of human ambition to create intelligent, capable, and useful machines.