
The Foundational Math of Flight Precision
The seemingly simple question, “what is a half of a third?”, belies a fundamental mathematical principle that underpins much of our technological advancement, particularly within the realm of flight technology. While the answer, one-sixth, is easily grasped, its implications resonate deeply within the intricate systems that enable modern aircraft, from commercial airliners to sophisticated unmanned aerial vehicles (UAVs). This article will explore how this basic fractional relationship translates into critical concepts within flight technology, focusing on navigation, sensor interpretation, and the very essence of controlled movement.
Understanding the Fraction: A Building Block for Control
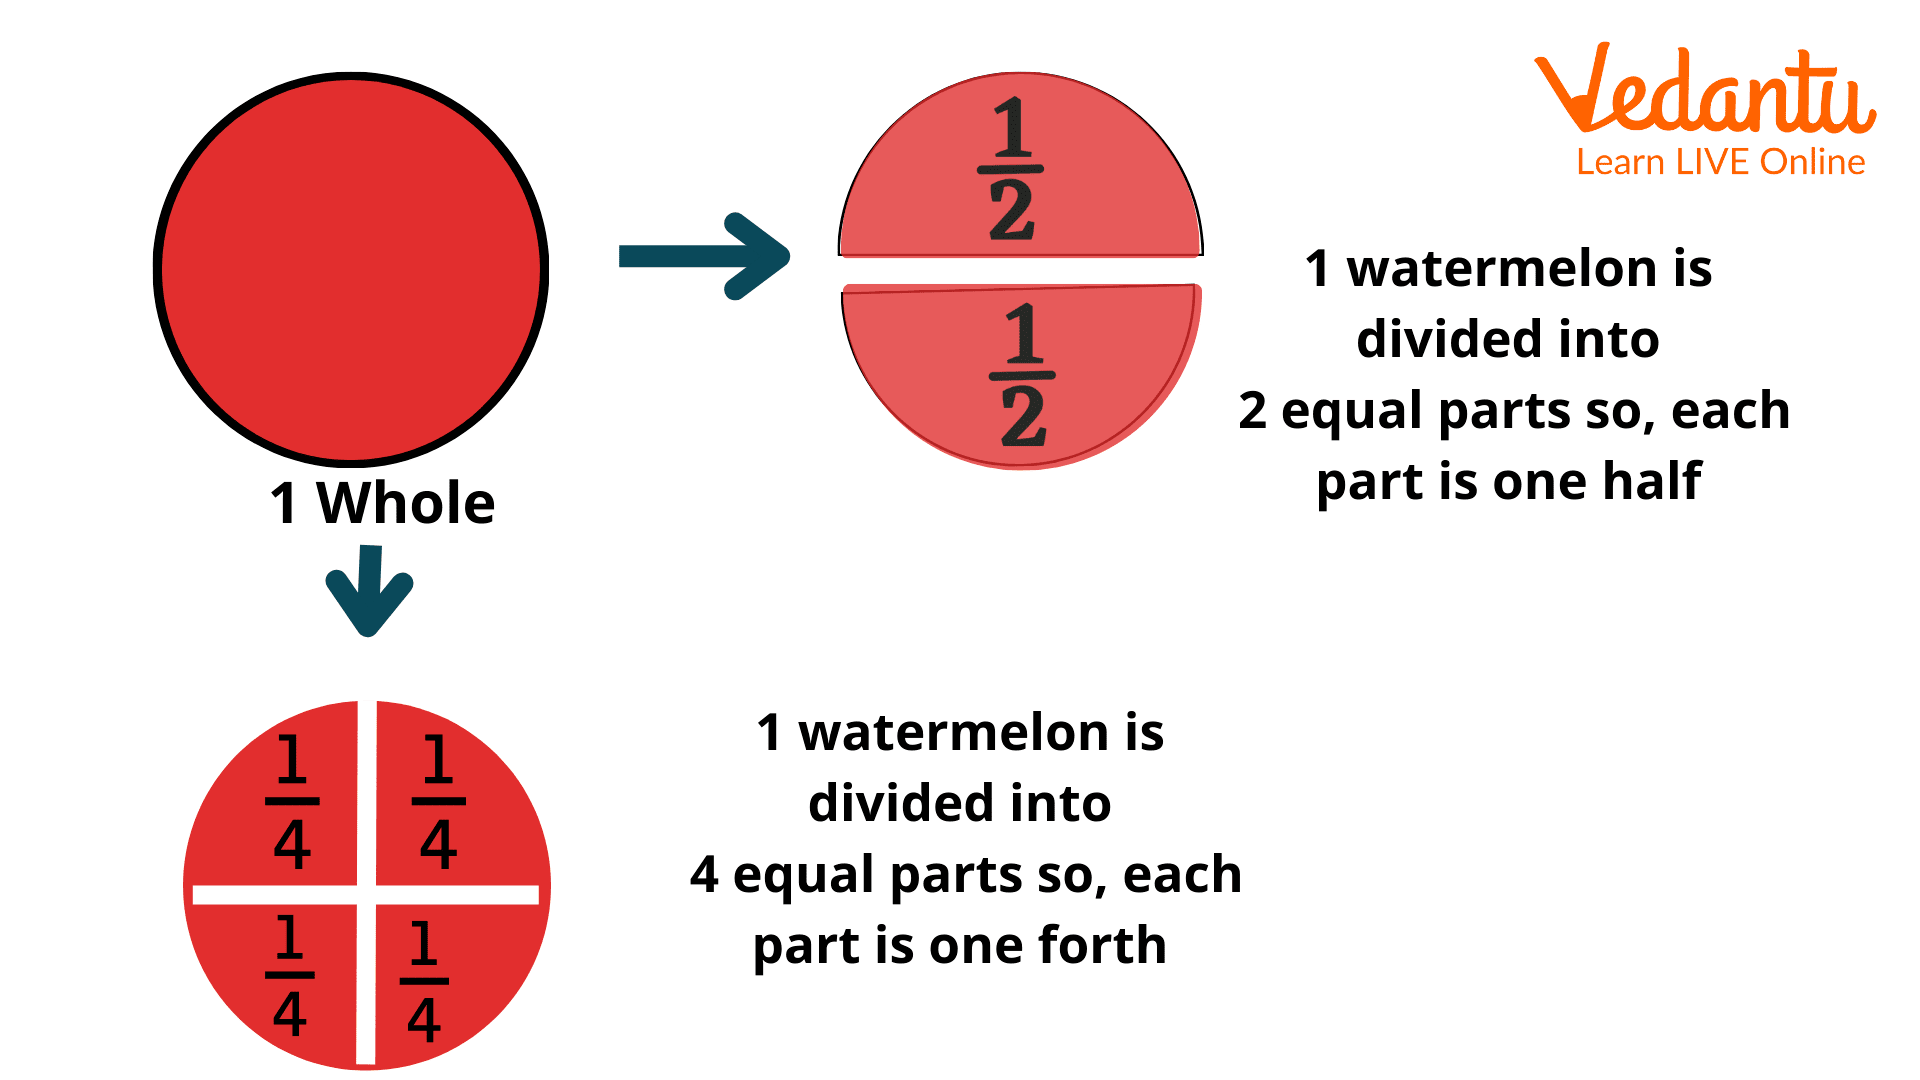
At its core, the question is about division and proportion. A “third” represents one part out of three equal divisions of a whole. When we ask for “a half of” that third, we are effectively dividing that existing fraction by two. Mathematically, this is represented as (1/3) ÷ 2, which is equivalent to (1/3) * (1/2) = 1/6. This simple calculation forms the bedrock for understanding how complex systems process information and execute commands.
Within flight technology, this principle is not just an abstract concept; it’s a practical necessity. Consider the precision required for autopilots. These systems constantly receive data from various sensors and must make minute adjustments to maintain a desired trajectory or altitude. Each sensor reading, each adjustment, is a discrete piece of information or action. The overall system, therefore, relies on the ability to precisely divide and proportion these inputs and outputs to achieve the desired outcome. If a navigation system needs to make an adjustment of a certain magnitude, and its current corrective action is “one third” of what’s needed, then the next step in the sequence might involve implementing “half of that” corrective action, leading to a precise 1/6 adjustment.
Navigation and the Art of Interpolation
The concept of “a half of a third” is intricately woven into the fabric of navigation systems, particularly when dealing with real-time data processing and interpolation. GPS, inertial navigation systems (INS), and other sensor arrays provide a stream of data points that represent the aircraft’s state – its position, velocity, and attitude. However, these data points are not continuous. They are discrete measurements taken at specific intervals.
H3: Bridging the Gaps with Interpolation
To create a smooth and accurate representation of the aircraft’s movement, navigation systems employ interpolation techniques. Interpolation is the process of estimating values between known data points. Imagine an aircraft moving in a straight line. Its GPS might provide its position at time T1 and again at time T2. The navigation system needs to know its position at T1.5. This is where the idea of dividing segments comes into play. If the overall displacement between T1 and T2 is “one third” of the intended total displacement for that leg of the journey, the system might need to adjust its course by “half of that initial corrective third.” This is a direct application of the 1/6 principle, albeit in a more dynamic and iterative fashion.
H3: The Role of Kalman Filters
Sophisticated navigation systems, like those employing Kalman filters, are designed to fuse data from multiple, potentially noisy, sensors. A Kalman filter works by recursively estimating the state of a dynamic system. It predicts the next state based on a model of the system’s dynamics and then updates this prediction using new sensor measurements. The “update” step involves a weighting factor that determines how much the prediction is influenced by the new measurement. This weighting factor is often derived from statistical probabilities and can be conceptualized as a proportion. In certain scenarios, the update might involve adjusting the predicted position by a fraction that is effectively “a half of a third” of the perceived error, thereby refining the accuracy of the estimated position.
Sensor Fusion and Data Interpretation
The accuracy of any flight system, whether it’s a simple drone or a complex aircraft, is heavily reliant on the quality and interpretation of data from its sensors. These sensors – accelerometers, gyroscopes, magnetometers, barometers, and more – provide raw information about the environment and the aircraft’s own motion. The challenge lies in processing this raw data into actionable intelligence.
H3: Calibrating and Correcting Sensor Readings
Sensors are rarely perfect. They can drift, be subject to interference, and have inherent biases. Calibration processes are essential to correct these inaccuracies. Imagine a sensor that consistently overestimates a particular reading by a value equivalent to “one third” of the full scale. To correct this, the system might apply a correction factor. If the initial correction applied is too large, perhaps representing a full “third” of the estimated bias, subsequent iterations of the calibration might apply “half of that correction,” effectively bringing the adjustment closer to the true bias by a 1/6 margin of the initial overcorrection.
H3: Understanding Angular Rates and Linear Velocities
In flight dynamics, angular rates (how fast an aircraft is rotating) and linear velocities (how fast it is moving in a straight line) are critical. These are often measured by gyroscopes and accelerometers, respectively. The relationship between these measurements and the aircraft’s actual movement can be complex. For instance, when an aircraft banks, its acceleration is influenced by gravity. To accurately determine the aircraft’s true linear acceleration, the effects of gravity must be accounted for. This involves vector decomposition and trigonometric calculations, where fractions and proportions are fundamental. If a calculation of the gravitational component is estimated to be “one third” of the total acceleration reading, and the system needs to isolate the non-gravitational component, it might consider the remaining “two thirds.” Further refinements, perhaps to account for minor sensor drifts, could involve adjusting this value by “half of a third” of the perceived drift, leading to a 1/6 adjustment in the final computed linear acceleration.
Control Surface Actuation and Response
The final output of a flight control system is the manipulation of control surfaces – ailerons, elevators, rudders, and throttles – to influence the aircraft’s movement. The magnitude and timing of these adjustments are critical for stable and precise flight.
H3: Proportional, Integral, Derivative (PID) Control
A common control strategy in flight technology is Proportional-Integral-Derivative (PID) control. A PID controller calculates an error value as the difference between a desired setpoint and a measured process variable. It then attempts to minimize the error by adjusting the control output. The “Proportional” term is directly proportional to the current error. The “Integral” term accumulates past errors, helping to eliminate steady-state errors. The “Derivative” term anticipates future errors based on the current rate of change of the error.
The tuning of a PID controller involves adjusting three gain parameters (Kp, Ki, Kd). These parameters dictate how strongly the controller responds to proportional, integral, and derivative components of the error. Imagine a scenario where the derivative gain (Kd) has been initially set too high, causing oscillations. A common tuning approach might involve reducing Kd. If the initial reduction was too aggressive, perhaps reducing it by a full “third” of its original value, a subsequent adjustment might be to reduce it by “half of that amount,” effectively reducing Kd by a total of 1/2 * (1/3) = 1/6 of its initial setting. This iterative fine-tuning, often described in terms of fractional adjustments, ensures that the control surfaces respond appropriately without overshooting or causing instability.
H3: Minimizing Control Surface Deflection
Efficient flight also requires minimizing unnecessary control surface deflections, which can increase drag and fuel consumption. Systems are designed to only apply the precise amount of control input necessary. If a small corrective input is needed, it will be a fraction of the maximum possible deflection. This fractional control is fundamental. When a system needs to execute a correction, it might determine that a certain deflection is required, say “one third” of the total available range. If the system then decides to hold that deflection for a period, and during that period the error slightly reduces, it might then reduce the deflection by “half of that initial corrective third,” a precise 1/6 reduction, demonstrating a nuanced and efficient application of control.

Conclusion: The Ubiquitous Nature of Fractions
The question, “what is a half of a third?”, leads us to the fundamental answer of one-sixth. However, within the intricate and demanding field of flight technology, this simple fraction represents a sophisticated principle of division, proportion, and precision. From the navigation systems that guide aircraft across vast distances to the sensor fusion that interprets environmental data, and the control algorithms that ensure stable flight, the ability to accurately understand and implement fractional relationships is not merely academic; it is essential for the safe, efficient, and reliable operation of all flying machines. The constant processing of discrete data points and the fine-tuning of control systems all rely on the fundamental understanding that a half of a third is a precisely quantifiable segment, a building block for the complex computations that keep us aloft.