
In the rapidly evolving landscape of drone technology and innovation, the concept of sampling frequency underpins nearly every advanced capability, from precise mapping to autonomous navigation. Far more than a mere technical specification, sampling frequency dictates the resolution, accuracy, and ultimately the utility of data collected by a drone’s myriad sensors, directly impacting the sophistication and reliability of its innovative applications. For anyone delving into remote sensing, 3D modeling, AI-powered flight, or sophisticated environmental monitoring, understanding sampling frequency is not just beneficial—it is fundamental.
The Digital Bridge: Understanding Sampling Frequency
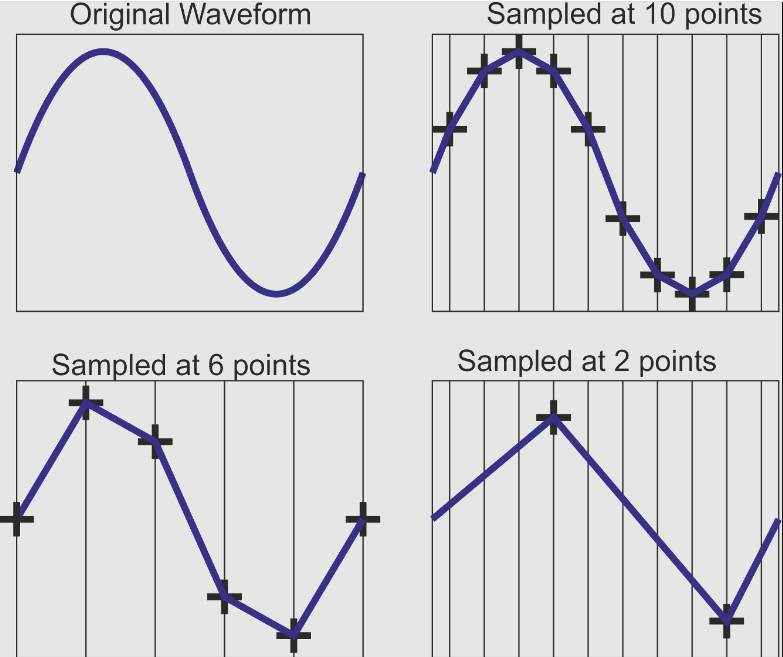
At its core, sampling frequency is the rate at which an analog signal is converted into a digital signal. Most real-world phenomena—light intensity, acceleration, magnetic fields, atmospheric pressure, or sound waves—are analog; they vary continuously over time. However, computers and digital systems, including those aboard modern drones, operate with discrete digital data. The process of sampling bridges this gap, taking discrete “snapshots” of the continuous analog signal at regular intervals. The number of these snapshots taken per second is the sampling frequency, typically measured in Hertz (Hz). A sampling frequency of 100 Hz, for example, means the sensor takes 100 measurements every second.
From Analog to Digital: The Conversion Process
Every sensor on a drone, be it an Inertial Measurement Unit (IMU), a GPS receiver, a LiDAR scanner, or a thermal camera, works by detecting a physical phenomenon and converting it into an electrical signal. This electrical signal is initially analog. An Analog-to-Digital Converter (ADC) then discretizes this continuous signal both in time (sampling) and in amplitude (quantization). The sampling rate determines how often the signal’s amplitude is measured, while quantization determines the precision of each measurement (how many bits are used to represent the amplitude).
A higher sampling frequency means more data points are captured per unit of time, providing a more faithful digital representation of the original analog signal. Conversely, a low sampling frequency can lead to a loss of information, as subtle changes or rapid fluctuations in the analog signal might occur between sampling points and thus be missed entirely. This concept is crucial for drones, where dynamic environments and fast-changing conditions necessitate high-fidelity data capture for accurate perception and decision-making.
The Nyquist-Shannon Theorem: A Fundamental Principle
Central to understanding the implications of sampling frequency is the Nyquist-Shannon sampling theorem. This critical theorem states that to perfectly reconstruct a continuous analog signal from its sampled discrete version, the sampling frequency must be at least twice the highest frequency component present in the original analog signal. This minimum sampling rate is known as the Nyquist rate. If the sampling frequency falls below this rate, a phenomenon called aliasing occurs. Aliasing introduces false low-frequency components into the sampled signal, distorting the digital representation and making it impossible to accurately reconstruct the original signal.
In drone innovation, aliasing can have severe consequences. For instance, if an IMU tracking rapid drone movements samples at too low a frequency, the recorded motion data might falsely indicate slower or different movements than what is actually happening. This can lead to erroneous navigation commands, unstable flight, or inaccurate mapping data. Therefore, engineers designing drone systems must carefully select sampling frequencies that exceed the Nyquist rate for the signals they intend to measure, ensuring data integrity and reliable performance across all innovative applications.
Sampling Frequency in Drone Tech & Innovation
The impact of sampling frequency is profoundly felt across the most advanced and innovative applications of drone technology. From creating highly detailed 3D models to enabling fully autonomous flight paths, the rate at which sensor data is acquired is a cornerstone of performance and reliability.
High-Resolution Mapping and Remote Sensing
For applications like photogrammetry, LiDAR-based 3D mapping, and multispectral/hyperspectral remote sensing, the quality and density of collected data are directly proportional to the sampling frequency of the sensors involved. In photogrammetry, the “sampling frequency” can be thought of as the rate at which images are captured along a flight path. A higher image capture rate, coupled with sufficient overlap, ensures comprehensive ground coverage and allows for the reconstruction of highly detailed 3D models and digital elevation models (DEMs) crucial for urban planning, construction, and environmental analysis.
Similarly, LiDAR (Light Detection and Ranging) systems, fundamental for precise terrain mapping and obstacle avoidance, have a “pulse repetition frequency” (PRF) which is essentially their sampling frequency. A higher PRF means more laser pulses are emitted per second, resulting in a denser point cloud. This density is critical for differentiating fine details, accurately measuring volumes, and identifying subtle changes in topography, which is vital for applications like precision agriculture, forestry management, and geological surveying. In remote sensing with multispectral or hyperspectral cameras, the frame rate (a form of sampling frequency) dictates how frequently spectral data is collected, allowing for more timely monitoring of crop health, water quality, or environmental pollutants across dynamic landscapes.
Powering Autonomous Flight and AI Capabilities
Autonomous flight, AI follow mode, and complex navigation tasks are heavily reliant on real-time data from a suite of sensors including IMUs (accelerometers and gyroscopes), GPS, and ultrasonic or visual obstacle avoidance sensors. The sampling frequency of these sensors is paramount for the drone’s ability to perceive its environment, maintain stability, and make intelligent decisions.
For autonomous drones, IMUs are often sampled at frequencies ranging from hundreds to thousands of Hertz. This high rate is necessary to detect rapid changes in pitch, roll, yaw, and linear acceleration, enabling the flight controller to make instantaneous adjustments to maintain stability and execute precise maneuvers. If IMU data is sampled too slowly, the control system might react belatedly to disturbances, leading to instability or even crashes.
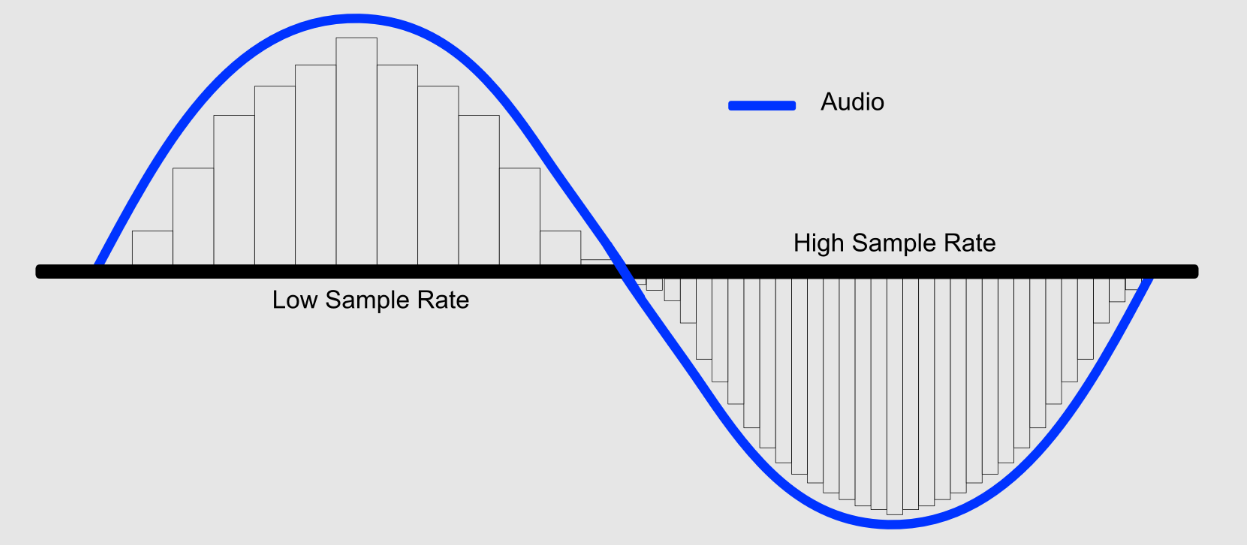
GPS receivers, while typically operating at lower sampling rates (e.g., 1 Hz to 10 Hz for standard receivers, up to 20 Hz or more for RTK/PPK systems), also benefit from higher frequencies for more accurate velocity estimation and smoother trajectory tracking. For AI-powered features like object tracking or sense-and-avoid systems, visual sensors (cameras) and other ranging sensors need high frame rates and sampling frequencies, respectively, to accurately track moving targets or detect rapidly approaching obstacles. This constant stream of high-frequency data allows AI algorithms to process information efficiently, learn from environmental cues, and execute complex, adaptive behaviors in real-time.
LiDAR, IMUs, and GPS: Sensor Specifics
- LiDAR: As mentioned, the pulse repetition frequency (PRF) directly impacts point cloud density. Modern drone-mounted LiDAR units can have PRFs in the hundreds of thousands of Hz, producing millions of data points per second. This enables extremely detailed 3D representations, critical for high-fidelity mapping, obstacle avoidance in complex environments, and even ground classification for autonomous landing.
- IMUs (Inertial Measurement Units): Comprising accelerometers and gyroscopes, IMUs are the backbone of drone stabilization and motion tracking. Sampling rates of 200 Hz to 1000 Hz are common for consumer drones, while high-performance industrial or research-grade drones might push beyond 2000 Hz for ultra-precise attitude estimation and vibration analysis. This high-frequency data is fused with GPS for robust navigation, especially in GPS-denied environments.
- GPS (Global Positioning System): While the inherent refresh rate of satellite signals is relatively slow, GPS receivers on drones sample the incoming signals to update position, velocity, and time. Higher update rates (e.g., 10 Hz vs. 1 Hz) provide smoother position tracks and more accurate velocity data, which is essential for dynamic drone operations and robust integration with IMU data for precise localization. Advanced Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK) GPS systems leverage sophisticated algorithms to achieve centimeter-level accuracy, often benefiting from faster sampling to resolve ambiguities more quickly.
The Critical Balance: Trade-offs and Considerations
While the benefits of high sampling frequency are clear for advanced drone applications, it is not a universally applicable “more is always better” scenario. Drone designers and operators must navigate a complex set of trade-offs and considerations to optimize performance without sacrificing other critical aspects of drone operation.
Data Volume and Processing Load
A direct consequence of higher sampling frequency is a dramatic increase in the volume of raw data generated. A sensor sampling at 1000 Hz produces ten times more data than one sampling at 100 Hz. This surge in data places significant demands on the drone’s onboard processing unit (FCU, companion computer), storage capacity, and data transmission bandwidth. Processing vast amounts of data in real-time requires powerful, energy-intensive processors. If the processing capabilities are insufficient, the system might suffer from latency, dropped frames, or an inability to keep up, negating the benefits of high-frequency sampling. Furthermore, transmitting this data to ground stations for real-time analysis can overwhelm wireless communication links, leading to delays or data loss. For mapping missions, higher data volumes also translate to longer post-processing times on ground-based systems.
Power Consumption and Flight Time
High-frequency sampling and the subsequent processing of large data volumes are energy-intensive. Sensors themselves, especially high-performance ones operating at higher frequencies, consume more power. The powerful processors required to handle the data load also draw considerable current. For battery-powered drones, this directly translates into reduced flight time. A drone optimized for capturing extremely high-frequency data for a specific, short-duration task might only have a fraction of the flight endurance of a drone designed for longer, less data-intensive missions. Finding the optimal sampling frequency involves balancing the need for data fidelity with the practical limitations of battery technology and mission duration.
Hardware Limitations and Cost Implications
The ability to achieve high sampling frequencies is inherently linked to the quality and sophistication of the sensor hardware and its accompanying electronics (e.g., ADCs). High-performance sensors capable of delivering clean, accurate data at very high rates are typically more expensive. For instance, a high-refresh-rate LiDAR system or a research-grade IMU will cost significantly more than their lower-frequency counterparts. Integrating these advanced components also requires robust engineering to minimize noise, ensure data synchronization, and manage thermal loads. The decision to employ high sampling frequencies must therefore align with the project budget and the specific performance requirements of the innovative application.
Optimizing for Performance: Ensuring Data Integrity
Achieving the full potential of high sampling frequency in drone innovation extends beyond simply choosing a fast sensor. It involves careful system design, data management strategies, and advanced processing techniques.
Synching Multi-Sensor Systems
Modern drones for advanced applications rarely rely on a single sensor. They integrate data from multiple sources: IMUs, GPS, LiDAR, cameras, magnetometers, barometers, etc. For this multi-sensor data fusion to be effective, especially for real-time applications like autonomous navigation or precise mapping, the data from different sensors must be accurately time-synchronized. Even small timing discrepancies between sensors sampled at high frequencies can lead to significant errors in position, orientation, or environmental mapping. Techniques like hardware-level time-stamping, PTP (Precision Time Protocol), or precise PPS (Pulse Per Second) signals from GPS are employed to ensure all sensor data aligns perfectly in time, enabling robust data fusion and accurate perception.
Post-Processing and Data Fusion
While real-time processing is crucial for flight control and immediate decision-making, many innovative drone applications heavily rely on sophisticated post-processing. Data collected at high sampling frequencies often undergoes advanced filtering, calibration, and fusion algorithms offline. For instance, combining high-frequency IMU data with lower-frequency GPS data through Extended Kalman Filters (EKF) or Particle Filters can yield highly accurate position and orientation estimates, far surpassing what either sensor could provide independently. Similarly, fusing LiDAR point clouds with high-resolution imagery allows for the creation of richly textured 3D models. The integrity of this post-processed data fundamentally depends on the quality and temporal density provided by the initial high-frequency sampling.

Future Trends in High-Frequency Sensing
The relentless pursuit of greater autonomy, precision, and intelligence in drone technology continues to drive advancements in sampling frequency. We can anticipate even higher sampling rates from micro-IMUs for enhanced stability, faster LiDAR scanners for real-time dense mapping in dynamic environments, and high-frame-rate cameras for improved visual odometry and AI perception. Developments in edge computing and specialized AI accelerators onboard drones will enable more complex, real-time processing of this high-frequency data, pushing the boundaries of what autonomous drones can achieve. Furthermore, the integration of new sensor types (e.g., 4D radar, event cameras) with inherently high temporal resolution will further complicate and enrich the landscape of data acquisition, making the principles of sampling frequency more relevant than ever for pushing the frontiers of drone innovation.