
The term “Pitman arm” resonates deeply within the mechanical lexicon, primarily associated with the intricate steering systems of automobiles. It refers to a crucial lever arm that plays a fundamental role in translating the rotational motion of a steering gearbox into the linear or angular motion required to steer the vehicle’s wheels. While its traditional domain is terrestrial, the underlying mechanical principle it embodies – the precise translation and amplification of motion – is profoundly relevant to advanced flight technology, particularly in the sophisticated realm of Unmanned Aerial Vehicles (UAVs) and complex aerial systems. In the context of flight technology, while the exact component bearing the name “Pitman arm” may not be a standard fixture in every drone, its functional essence—a mechanical linkage designed for robust, precise motion translation—is increasingly vital in pushing the boundaries of aerial capabilities, from advanced stabilization systems to novel propulsion mechanisms.

Understanding Mechanical Translation in Advanced UAV Systems
At its core, a Pitman arm serves as a mechanical intermediary, converting one type of motion into another, often with a change in leverage or direction. This principle of controlled motion translation is indispensable in the design and operation of cutting-edge flight technology. Modern UAVs are far more than simple flying platforms; they are sophisticated machines capable of intricate maneuvers, carrying complex payloads, and operating in dynamic environments. Such capabilities demand mechanical systems that can precisely control movement, whether for stabilizing a high-resolution camera, adjusting the angle of a multi-directional thrust vector, or deploying a robotic manipulator.
The Fundamental Role of Linkages
In drone technology, mechanical linkages are the unsung heroes that enable a wide array of functions. Unlike the direct electronic control of rotor speeds in a typical quadcopter, some advanced UAV designs incorporate physical linkages to achieve specific mechanical advantages or complex movement patterns. For instance, in fixed-wing drones with traditional control surfaces (ailerons, elevators, rudders), servo motors translate electrical signals into rotational motion, which is then converted by pushrods and bellcranks (types of linkages) into the precise angular deflection of the control surfaces. This is functionally analogous to the Pitman arm’s role in a steering system, where a small input rotation yields a controlled output movement.
For more complex platforms, such as tilt-rotor VTOL (Vertical Take-off and Landing) aircraft, the ability to seamlessly transition between vertical lift and horizontal flight depends on sophisticated mechanical linkages that can accurately adjust the angle of the rotors. These systems often involve multiple pivot points and lever arms working in concert to achieve smooth, synchronized tilting. The design principles here borrow heavily from robust mechanical engineering traditions, where components must withstand significant forces while maintaining extreme precision – a testament to the enduring value of well-engineered mechanical translation.
Beyond Simple Actuators
While electric motors and servos are the primary actuators in most drones, the way their power is harnessed and directed often involves mechanical linkages. Consider a specialized payload that requires multi-axis movement – for instance, a laser scanner that needs to sweep across a target area or a high-gain antenna that must maintain precise alignment with a ground station. The motor drives a gear, but a linkage system might be employed to achieve a non-linear motion path, amplify a small rotation into a larger sweep, or provide a mechanical advantage for precise fine-tuning.
In some experimental or heavy-lift drone designs, active vibration dampening systems might employ mechanical linkages to counteract resonance or structural flex. These systems could involve sensors detecting unwanted motion, feeding data to a control unit that then actuates small, highly precise linkages to introduce counter-movements. The robustness and predictable mechanical behavior of such linkages are critical for maintaining system integrity and performance, especially under stress.
Precision and Stabilization: Where a ‘Pitman-esque’ Linkage Excels
The core value of a Pitman arm-like linkage in flight technology lies in its capacity for precision and contribution to stabilization. Achieving stable flight, accurate sensor pointing, and reliable payload operation requires meticulously engineered interfaces between electronic commands and physical movements.
Mitigating Vibrations and External Forces
Drones are inherently subject to vibrations generated by their propulsion systems and external forces like wind gusts. These disturbances can severely impact the performance of onboard sensors, cameras, and delicate instruments. While electronic stabilization (via flight controllers and IMUs) handles much of this, mechanical linkages can play a critical role in secondary or specialized stabilization layers.
For example, an advanced gimbal system for a large cinema camera might incorporate complex mechanical linkages designed not just to point the camera, but also to passively or actively absorb specific frequencies of vibration before they reach the sensitive camera assembly. These linkages, akin to the load-bearing and motion-translating characteristics of a Pitman arm, would be engineered to provide mechanical isolation or specific damping characteristics, ensuring that the sensor platform remains incredibly stable, even when the drone itself is experiencing turbulence. Such designs move beyond simple pivots, introducing lever arms that optimize the response to specific inputs, effectively “filtering” unwanted motion.
Enhancing Gimbal and Payload Performance
Gimbal systems are perhaps the most direct application of precise mechanical translation in UAVs. While many gimbals rely on direct motor-to-axis drives, higher-end or specialized gimbals might incorporate linkages to achieve particular kinematic properties. For instance, a complex 5-axis stabilization system might use a series of interconnected arms and pivots to achieve a wider range of motion, finer granular control, or to maintain a specific center of gravity for the payload throughout its movement.
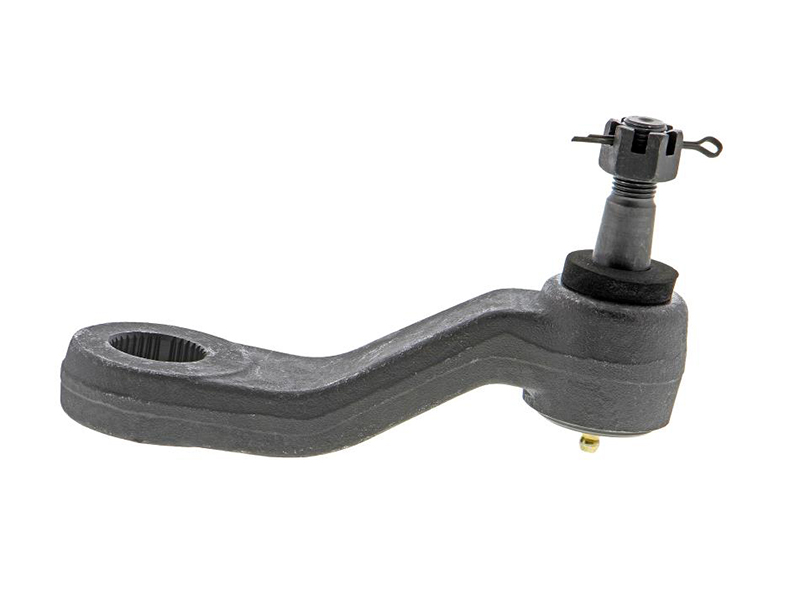
Imagine a sophisticated multi-spectral sensor package that needs to be rotated and tilted with sub-degree accuracy while also being extended or retracted. The motors would provide the initial drive, but a carefully designed mechanical linkage system, applying the principles of leverage and motion translation inherent in a Pitman arm, would convert this raw power into the exact, synchronized movements required. This allows for superior image quality, more accurate data collection, and greater operational flexibility for the drone. The rigidity and precise machining of these “Pitman-esque” components are paramount, as any backlash or play can compromise the entire system’s accuracy.
Innovative Applications in Future Flight Technology
As drone technology continues to evolve, the demand for more complex, versatile, and adaptive aerial platforms grows. This drives innovation in mechanical design, where the principles of robust motion translation, epitomized by components like the Pitman arm, find new and exciting applications.
Variable Geometry and Morphing Drones
The concept of variable geometry drones – aircraft that can change their physical shape or wing configuration in flight – is a frontier in flight technology. These drones might adapt their wingspan for efficiency, tilt their entire propulsion system for different flight regimes, or even fold appendages for storage or maneuverability in confined spaces. Such transformations require intricate, reliable mechanical linkages that can smoothly and precisely alter the drone’s aerodynamics or structural layout mid-flight.
A “Pitman-esque” linkage could be a core component in these morphing structures, converting the output of an actuator into the synchronized movement of multiple segments. For example, a single motor might drive a linkage system that simultaneously adjusts the angle of multiple wing sections, allowing for an optimized aerodynamic profile for varying speeds or atmospheric conditions. The challenges here involve ensuring high strength-to-weight ratios, minimizing friction, and integrating these mechanical systems seamlessly with advanced flight control algorithms.
Robotics and Manipulation from the Air
Drones equipped with robotic arms or manipulation tools open up vast possibilities for inspection, repair, construction, and intervention in hazardous environments. For these aerial robots, the precision of movement in their appendages is as critical as their flight stability. A robotic arm needs not only to be strong but also capable of delicate, precise manipulation.
Here, the concept of a Pitman arm comes into its own as a design principle for robust and accurate joint mechanisms. A drone-mounted robotic arm might use a series of internal linkages to provide specific ranges of motion, mechanical advantages for lifting or gripping, and to ensure that the end-effector maintains a desired orientation or trajectory. These linkages would translate the rotational input from internal motors into the complex, multi-axis movements needed to perform tasks like turning a valve, collecting a sample, or performing a detailed inspection. The mechanical integrity and zero-backlash design of such internal linkages are paramount for achieving the necessary control fidelity.
Design Considerations for Robust Aerial Systems
Implementing mechanical translation systems akin to the Pitman arm in drone technology demands rigorous engineering and careful consideration of several factors unique to aerial platforms.
Materials Science and Durability
The extreme weight sensitivity of UAVs means that any mechanical component must be exceptionally light yet incredibly strong and durable. Advanced materials like aerospace-grade aluminum alloys, titanium, and carbon fiber composites are essential for fabricating Pitman-arm-like linkages. These materials offer high strength-to-weight ratios, excellent fatigue resistance, and resistance to environmental factors like corrosion and temperature fluctuations. The choice of material directly impacts the drone’s payload capacity, flight endurance, and overall reliability, making material selection a critical design decision for any mechanical component.
Furthermore, the operating environment of a drone often involves vibrations, shocks, and varying aerodynamic loads. The linkages must be designed to withstand these stresses without deforming or experiencing premature wear. Bearing surfaces, pivot points, and attachment hardware must be engineered for long-term performance, often incorporating self-lubricating materials or sealed bearings to minimize maintenance and maximize operational lifespan.

Integration with Flight Control Algorithms
Perhaps the most challenging aspect of incorporating complex mechanical linkages into drones is their seamless integration with the flight control algorithms. Unlike purely electronic control surfaces or motors, mechanical linkages introduce non-linearities, inertia, and potential for backlash that must be accounted for by the flight controller. Sensors embedded within or around the linkages provide real-time feedback on their position, velocity, and applied forces.
The flight control system must interpret this data and generate precise commands to the actuators to achieve the desired mechanical response. This often involves advanced control techniques such as inverse kinematics for robotic arms or predictive control for dynamic morphing structures. The goal is to ensure that the mechanical system acts as an extension of the flight intelligence, executing commands with precision and stability, rather than introducing unwanted dynamics. This tight coupling of mechanical engineering with sophisticated software algorithms is where the true potential of “Pitman-esque” linkages in future flight technology will be unlocked, enabling drones to perform tasks that are currently beyond their capabilities.