
The Core of Flight Dynamics: Unpacking the ‘Colon’ Concept
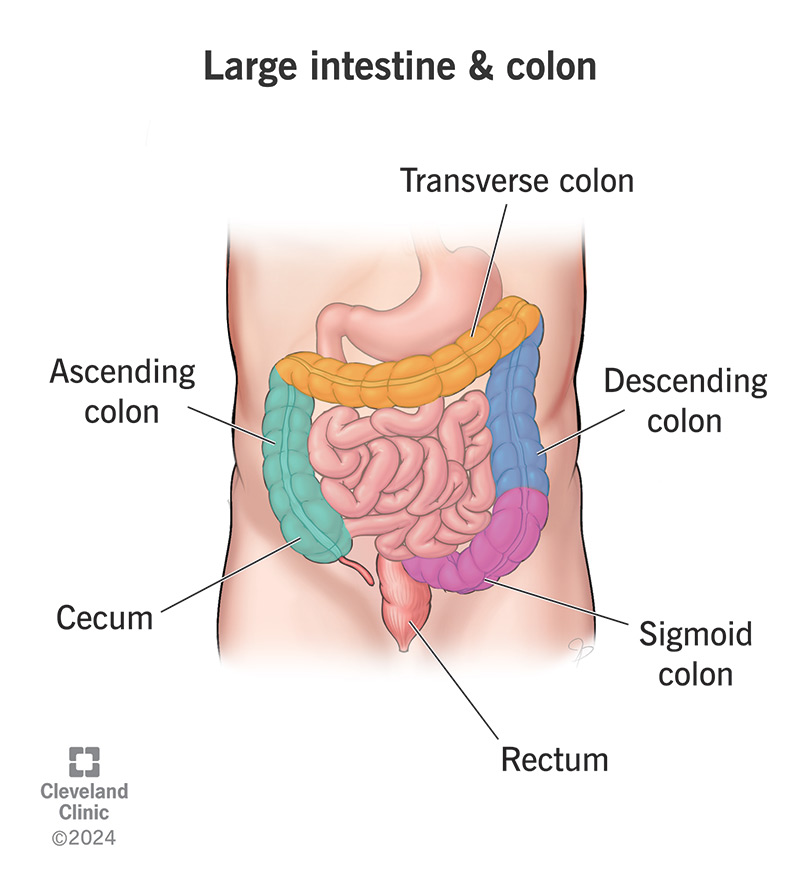
Within the intricate tapestry of modern drone technology, the term “colon” refers not to a singular, physical component, but rather to the centralized, integrated functional architecture that serves as the nexus for all critical flight operations. It embodies the distributed intelligence and processing capabilities essential for a drone to achieve autonomous, stable, and precise flight. This conceptual “colon” represents the consolidated sum of algorithms, sensor data processing units, and control loops that together dictate the drone’s behavior, trajectory, and interaction with its environment. Its function is foundational, acting as the primary interpreter of operator commands and environmental feedback, translating them into actionable flight maneuvers. Without a robust and highly efficient “colon,” a drone would be incapable of navigating complex airspace, maintaining stability against external forces, or executing advanced tasks with reliability.
This sophisticated functional core is responsible for sifting through vast amounts of real-time data, making instantaneous decisions, and issuing precise commands to the drone’s propulsion and control surfaces. It’s the brain, the central nervous system, and the primary decision-maker rolled into one cohesive system, continuously learning and adapting to ensure optimal performance. The ‘colon’ concept underpins the very essence of flight technology, enabling everything from basic hover to complex autonomous missions. Its design and implementation are paramount, directly influencing a drone’s agility, responsiveness, safety, and overall operational effectiveness. Understanding the multi-faceted function of this conceptual “colon” is key to appreciating the sophistication embedded within contemporary unmanned aerial vehicles.
The Algorithmic Engine: Processing and Decision-Making
At the heart of the “colon’s” function lies its algorithmic engine. This complex suite of software and hardware processes incoming data from a myriad of sensors at incredibly high refresh rates. It performs calculations related to the drone’s position, velocity, acceleration, attitude, and environmental conditions. This processing isn’t merely data aggregation; it involves sophisticated filtering, estimation, and prediction algorithms, such as Kalman filters, to derive accurate and reliable state information despite sensor noise and uncertainties. The decision-making algorithms then take this processed information and, based on predefined parameters, mission objectives, and real-time inputs, determine the necessary control outputs. This might involve adjusting motor speeds, altering propeller pitches, or engaging specific actuators. The efficiency and robustness of this algorithmic engine directly correlate with the drone’s ability to react swiftly and accurately to dynamic situations, ensuring mission success and operational safety. This continuous loop of sensing, processing, deciding, and acting defines the essential role of the “colon” in modern flight technology.
The Interconnected Network: Bridging Subsystems
Beyond mere processing, the “colon” also functions as the interconnected network that seamlessly bridges various drone subsystems. From the propulsion system and flight controllers to navigation modules, communication links, and payload interfaces, the “colon” ensures that each component operates in harmony. It manages the flow of data and commands between these diverse elements, orchestrating their combined efforts to achieve the desired flight objectives. This includes managing power distribution to critical systems, prioritizing data transmission, and monitoring the health and status of each subsystem. The efficacy of this interconnected network is crucial for maintaining system integrity and redundancy, allowing the drone to continue operations even if minor component failures occur, or to initiate fail-safe procedures if critical issues arise. This holistic integration capability elevates the “colon” from a simple control unit to a comprehensive operational manager, ensuring synchronized performance across the entire aerial platform.
Precision Navigation and Path Execution
A fundamental aspect of the “colon’s” function is its indispensable role in precision navigation and meticulous path execution. Modern drones are not simply fly-by-wire aircraft; they are intelligent navigators capable of understanding their position in three-dimensional space with remarkable accuracy and following complex flight paths with minimal deviation. This capability is entirely dependent on the “colon’s” advanced processing and control mechanisms, which integrate data from multiple sources to paint a comprehensive picture of the drone’s whereabouts and intended trajectory. From GPS coordinates to inertial measurements and visual odometry, the “colon” synthesizes all available information to guide the drone with unparalleled precision, enabling a vast array of applications from automated surveying to complex cinematic maneuvers.
Global Positioning System (GPS) Integration and Augmentation
The “colon” acts as the master integrator for GPS data, transforming raw satellite signals into precise location information. It doesn’t merely read GPS coordinates; it augments them. Through sophisticated algorithms, it combines GPS data with inputs from other sensors like accelerometers, gyroscopes, and barometers (Inertial Measurement Units – IMUs) to counteract GPS signal inaccuracies, drift, and temporary signal loss. This technique, often involving Kalman filters, provides a highly accurate and stable estimate of the drone’s position and velocity, even in challenging environments like urban canyons or under dense foliage where GPS alone might falter. Furthermore, advanced “colons” incorporate Real-Time Kinematic (RTK) or Post-Processed Kinematic (PPK) systems, leveraging ground-based reference stations to achieve centimetre-level positioning accuracy, critical for high-precision mapping and inspection tasks. The “colon’s” ability to flawlessly integrate and refine this navigational data ensures that the drone always knows exactly where it is.
Waypoint Navigation and Trajectory Optimization
Beyond simply knowing its position, the “colon” enables sophisticated waypoint navigation. Operators can pre-program a series of geographical points, and the “colon” meticulously calculates the optimal flight path to connect these points, considering factors such as terrain, wind conditions, and energy efficiency. It generates a smooth, continuous trajectory that minimizes power consumption while adhering to speed and altitude constraints. During execution, the “colon” continuously monitors the drone’s progress against the planned trajectory, making real-time adjustments to motor thrust and control surface angles to keep the drone precisely on course. This involves complex predictive control algorithms that anticipate future states and apply corrective actions before significant deviations occur. Whether it’s following a linear path for surveying or executing intricate curvilinear movements for aerial cinematography, the “colon’s” command over trajectory optimization ensures reliable, repeatable, and precise flight performance, making complex aerial operations accessible and automated.
Stabilisation and Attitude Control Architectures
Perhaps one of the most remarkable functions of the drone’s conceptual “colon” is its capacity for advanced stabilisation and precise attitude control. The ability of a multirotor drone to hover motionless in a turbulent gust, or to execute a precise bank and turn, is not intuitive; it’s the result of continuous, rapid calculations and adjustments performed by this central functional core. Without a highly responsive and accurate “colon,” a drone would be inherently unstable, unable to maintain a desired orientation or resist external disturbances. This segment of its function is paramount for both flight safety and operational efficacy, allowing for stable sensor platforms and predictable flight behavior.
Inertial Measurement Unit (IMU) Processing
The IMU is the cornerstone of drone stabilization, and the “colon” is its primary interpreter. Consisting typically of three-axis accelerometers and gyroscopes, and often magnetometers, the IMU provides raw data on the drone’s angular velocity (rate of rotation), linear acceleration, and magnetic heading. The “colon” continuously processes this noisy, high-frequency data. It employs sophisticated sensor fusion algorithms, often complementary filters or extended Kalman filters, to combine these inputs and generate an accurate, drift-free estimate of the drone’s attitude (pitch, roll, and yaw) and orientation in space. This filtering is crucial to differentiate between actual drone movement and sensor noise, providing a clean and reliable state estimate for the flight controller. The speed and accuracy of this IMU processing dictate the drone’s responsiveness and stability, particularly in dynamic flight conditions.
PID Control Loops and Flight Stability
Once the “colon” has an accurate understanding of the drone’s current attitude, it activates its Proportional-Integral-Derivative (PID) control loops – the workhorse of flight stability. For each axis of rotation (pitch, roll, yaw), and often for altitude, independent PID controllers are at work. The “colon” continuously compares the drone’s current attitude (the “process variable”) with the desired attitude (the “setpoint”).
- Proportional (P) component reacts to the current error.
- Integral (I) component accounts for past errors, helping to eliminate steady-state offset.
- Derivative (D) component predicts future errors based on the rate of change of the current error, providing damping and preventing overshoot.
The “colon” calculates the necessary corrections and translates these into adjustments for the individual motor speeds (or servo positions for fixed-wing drones). This happens hundreds, if not thousands, of times per second, ensuring that the drone instantly compensates for wind gusts, payload shifts, or operator commands to maintain its desired stability and attitude. This intricate interplay of sensing and corrective action by the “colon” is what makes stable and controlled flight possible for all types of unmanned aerial vehicles.
Sensor Fusion and Environmental Interpretation
Another critical function of the drone’s conceptual “colon” is its advanced capability in sensor fusion and environmental interpretation. For a drone to operate intelligently and safely, especially in complex or dynamic environments, it needs to perceive its surroundings accurately and build a coherent, real-time understanding of obstacles, terrain, and other relevant features. The “colon” acts as the central hub where data from diverse sensor modalities are brought together, synchronized, and processed to create a holistic environmental model. This function is not merely about collecting data; it’s about making sense of it, extracting actionable insights that inform navigation, obstacle avoidance, and mission-specific tasks.
Multi-Sensor Data Integration
The “colon” excels at integrating data from a wide array of onboard sensors, each providing a unique perspective on the drone’s environment. This typically includes:
- Optical Sensors (Cameras): Providing visual information for object recognition, mapping (photogrammetry), visual odometry, and tracking. The “colon” processes live video feeds and still images to identify features, estimate depth, and track movement.
- Lidar and Radar: Offering precise distance measurements to objects and terrain, regardless of lighting conditions. Lidar provides high-resolution 3D point clouds, while radar is effective in adverse weather (fog, rain). The “colon” fuses these distance maps to construct detailed environmental models.
- Ultrasonic Sensors: Used for short-range obstacle detection and precise altitude hold, particularly close to the ground.
- Thermal Cameras: Capturing infrared radiation, enabling the detection of heat signatures, useful for search and rescue, surveillance, and industrial inspections.
The “colon” synchronizes these disparate data streams, corrects for sensor biases, and aligns them in a common reference frame. This multi-sensor approach overcomes the limitations of any single sensor, providing a more robust and reliable environmental perception.
Real-time Obstacle Avoidance and Mapping
With the fused sensor data, the “colon” performs real-time environmental interpretation essential for functions like obstacle avoidance and mapping.
- Obstacle Avoidance: The “colon” continuously scans the drone’s projected flight path for potential collisions. Using algorithms that identify obstacles from the 3D environmental model, it calculates evasion maneuvers, such as adjusting the flight path, altitude, or speed, to safely navigate around detected objects. This dynamic collision avoidance capability is crucial for autonomous flight in cluttered environments and enhances operational safety.
- Mapping and 3D Reconstruction: For applications like surveying, agriculture, or construction, the “colon” processes geo-referenced imagery and lidar data to generate highly accurate 2D maps (orthomosaics) and 3D models (point clouds, digital surface models). It uses techniques like Simultaneous Localization and Mapping (SLAM) to build a map of an unknown environment while simultaneously tracking the drone’s position within that map. This sophisticated environmental interpretation by the “colon” transforms raw sensor data into actionable spatial intelligence.
Enabling Autonomous Flight and Intelligent Operations
The ultimate expression of the “colon’s” function lies in its ability to enable truly autonomous flight and a suite of intelligent operations. While basic flight stability and navigation are impressive, it is the higher-level cognitive functions – decision-making without constant human intervention, adaptive learning, and complex mission execution – that define modern drone capabilities. The “colon” provides the computational horsepower and algorithmic sophistication to transition drones from remote-controlled vehicles to intelligent, self-sufficient aerial robots.
AI-Driven Decision Making and Path Planning
The “colon” integrates advanced Artificial Intelligence (AI) and machine learning algorithms to elevate a drone’s decision-making capabilities. This allows for:
- Dynamic Path Planning: Beyond pre-programmed waypoints, the “colon” can intelligently re-plan its trajectory in real-time based on environmental changes, newly detected obstacles, or updated mission objectives. AI algorithms enable it to find optimal paths that balance efficiency, safety, and mission goals.
- Object Recognition and Tracking: Using deep learning models, the “colon” can identify specific objects (e.g., people, vehicles, power lines) within its visual or thermal feeds and autonomously track them, adjusting its position and orientation to maintain a lock. This is invaluable for surveillance, search and rescue, and inspection tasks.
- Adaptive Control: The “colon” can learn from its own flight performance and adapt its control parameters to optimize stability and efficiency, even accommodating changes in payload or slight damage to components. This self-optimization enhances reliability and extends operational lifespan.
These AI-driven capabilities allow the drone to make complex decisions autonomously, freeing the operator to focus on strategic oversight rather than continuous manual control.

Autonomous Mission Execution and Swarm Intelligence
The “colon” is the linchpin for fully autonomous mission execution. Once a mission is defined, whether it’s surveying a vast agricultural field, inspecting a complex industrial facility, or delivering a package, the “colon” takes full command. It manages all phases of the flight, from automated take-off and navigation through the planned trajectory, to executing specific tasks (e.g., capturing images at defined intervals, deploying a payload), and finally, performing an autonomous landing. Its comprehensive understanding of its environment, coupled with robust error handling and fail-safe protocols, ensures mission completion even in unforeseen circumstances.
Furthermore, the “colon’s” architectural design supports the emerging field of swarm intelligence. In multi-drone operations, the “colon” of each individual drone can communicate and coordinate with its peers. This distributed intelligence allows a group of drones to act as a single, cohesive unit, sharing information, dividing tasks, and executing complex, collaborative missions that would be impossible for a single drone. This includes synchronized mapping, cooperative surveillance, or even synchronized aerial displays. The collective function of these interconnected “colons” represents a paradigm shift in aerial robotics, unlocking capabilities for unprecedented scale and complexity in unmanned operations.