
In the realm of sophisticated flight technology, understanding the underlying mathematical principles is crucial for innovation and optimization. One such fundamental concept, vital for the precise control and navigation of aerial vehicles, is the gradient. While seemingly abstract, the gradient plays a pivotal role in how our drones and UAVs perceive their environment, adjust their trajectories, and maintain stable flight. This article delves into the mathematical definition of a gradient and, more importantly, illuminates its practical applications within flight technology.
Understanding the Mathematical Gradient
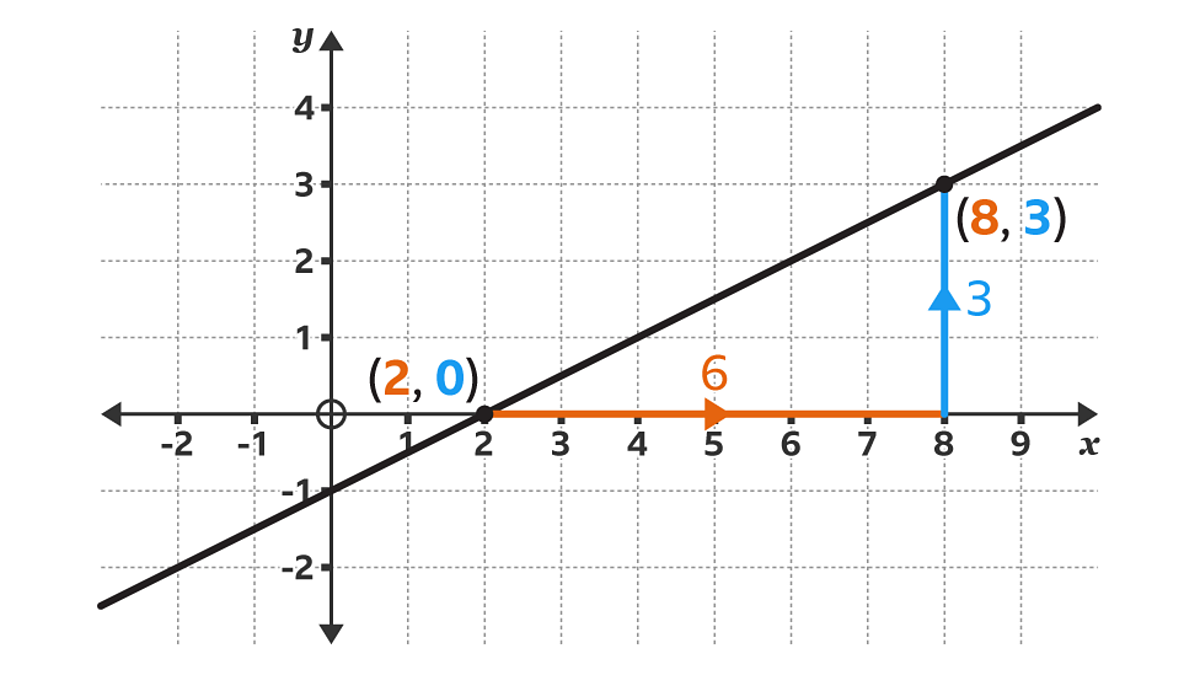
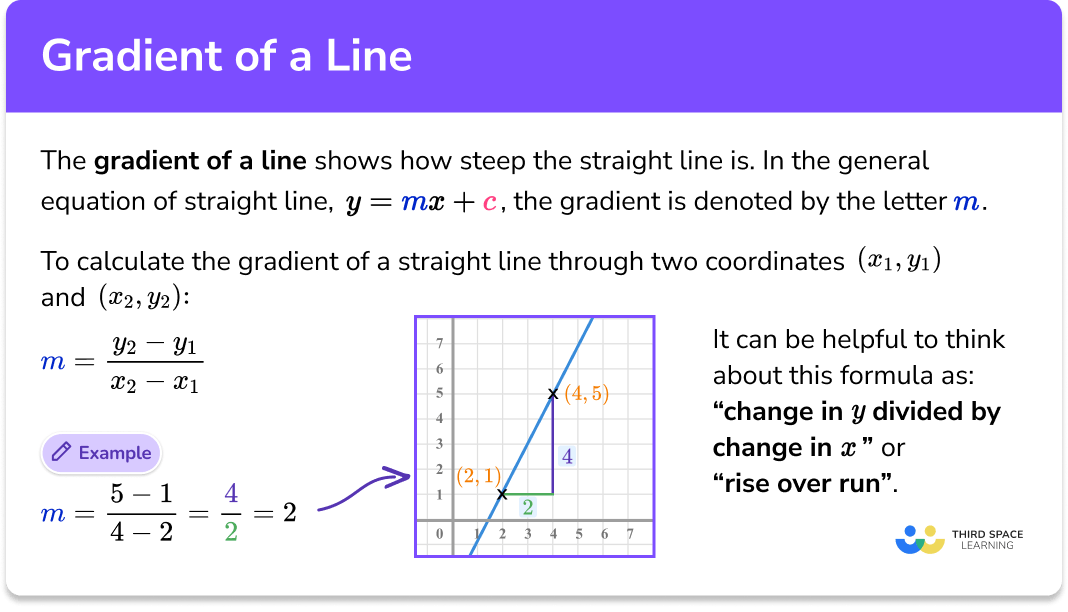
At its core, a gradient is a vector that points in the direction of the steepest ascent of a scalar function. Imagine a topographical map where elevation is represented by a function. The gradient at any given point on this map would be a vector indicating the direction you’d need to walk to climb the steepest hill from that spot.
Scalar Fields and Functions
Before defining the gradient, we must first understand what a scalar function is in this context. A scalar function assigns a single numerical value (a scalar) to every point in space. In flight technology, these scalar functions can represent various environmental factors or internal states. For example:
- Altitude: At any (x, y) coordinate on the ground, there’s an altitude. The function $f(x, y)$ would give this altitude.
- Temperature: In a specific atmospheric region, temperature can vary. A function $T(x, y, z)$ could map a 3D point to its temperature.
- Signal Strength: The strength of a GPS or communication signal can be modeled as a scalar field across an area.
Partial Derivatives
The gradient is built upon the concept of partial derivatives. A partial derivative of a multivariable function with respect to one of its variables measures the rate of change of the function as that single variable changes, while all other variables are held constant.
For a function of two variables, $f(x, y)$, the partial derivative with respect to $x$ is denoted as $frac{partial f}{partial x}$ or $fx$. It tells us how $f$ changes as we move purely in the $x$-direction. Similarly, $frac{partial f}{partial y}$ or $fy$ tells us how $f$ changes as we move purely in the $y$-direction.
For a function of three variables, $f(x, y, z)$, we would have partial derivatives $frac{partial f}{partial x}$, $frac{partial f}{partial y}$, and $frac{partial f}{partial z}$.
The Gradient Operator and Vector
The gradient of a scalar function $f$ is denoted by the nabla symbol, $nabla$, acting on the function: $nabla f$. It is a vector whose components are the partial derivatives of the function with respect to each independent variable.
For a scalar function $f(x, y)$ in two dimensions, the gradient is:
$$ nabla f(x, y) = leftlangle frac{partial f}{partial x}, frac{partial f}{partial y} rightrangle $$
For a scalar function $f(x, y, z)$ in three dimensions, the gradient is:
$$ nabla f(x, y, z) = leftlangle frac{partial f}{partial x}, frac{partial f}{partial y}, frac{partial f}{partial z} rightrangle $$
The direction of the gradient vector at a point indicates the direction of the greatest rate of increase of the function at that point. The magnitude of the gradient vector represents the magnitude of that rate of increase.
Gradient Descent and Ascent in Flight Control
The concepts of gradient descent and gradient ascent are direct applications of the gradient. They are iterative optimization algorithms used to find the minimum or maximum of a function.
Gradient Descent: Finding the Lowest Point
Gradient descent is used to find the minimum of a function. In essence, at each step, you move in the direction opposite to the gradient, as this direction points towards the steepest decrease. The update rule for moving towards a minimum of a function $f$ is:
$ text{new position} = text{current position} – alpha nabla f(text{current position}) $
Here, $alpha$ (alpha) is the learning rate, a small positive number that controls the size of the steps taken. A smaller learning rate leads to slower but potentially more precise convergence, while a larger learning rate can speed up convergence but risks overshooting the minimum or even diverging.
Gradient Ascent: Reaching the Peak
Conversely, gradient ascent is used to find the maximum of a function. In this case, you move in the same direction as the gradient, as this direction points towards the steepest increase. The update rule for moving towards a maximum is:
$ text{new position} = text{current position} + alpha nabla f(text{current position}) $
The choice between descent and ascent depends entirely on whether we aim to minimize or maximize the scalar function.
Practical Applications in Flight Technology
The mathematical elegance of the gradient translates into tangible advancements in flight technology, enabling more intelligent and robust aerial systems.
Navigation and Pathfinding
One of the most significant applications of gradients lies in navigation. Imagine a drone needing to reach a target location while avoiding obstacles and navigating complex terrain.
Potential Fields Method
The potential fields method is a prime example. It conceptualizes the environment as a landscape of potential energy. The goal is to navigate towards the target (a region of low potential energy) while being repelled by obstacles (regions of high potential energy).
- Attractive Potential: A function that creates a “pull” towards the target. The gradient of this function would point towards the target.
- Repulsive Potential: A function that creates a “push” away from obstacles. The gradient of this function would point away from obstacles.
The drone’s desired movement vector can be derived by summing the gradients of these potential fields. The drone then moves in a direction that balances the attraction to the goal and the repulsion from obstacles. The gradient calculation provides the direction and magnitude of these forces, guiding the drone efficiently and safely.
Terrain Following
For drones operating at low altitudes, like agricultural or inspection drones, precise terrain following is crucial. Altitude data can be represented as a scalar function of horizontal position, $h(x, y)$. The gradient of this function, $nabla h$, tells the drone the direction of the steepest incline of the terrain. By controlling its vertical velocity to counteract this gradient (i.e., descending when going uphill, ascending when going downhill, but with adjustments for desired altitude relative to the terrain), the drone can maintain a consistent height above the ground.
Sensor Data Interpretation and Fusion
Modern drones are equipped with a multitude of sensors, each providing data that can be interpreted as scalar fields or used to construct them.
Signal Strength Mapping
When a drone operates in an area with varying communication or GPS signal strength, it can map this signal strength as a scalar function. The gradient of this function can then be used to identify areas of strong or weak signal. This is invaluable for:
- Optimizing flight paths: To ensure continuous communication or accurate positioning.
- Autonomous return-to-home: If signal strength drops critically, the drone can use gradient information to steer towards areas with better reception.
Thermal Imaging Analysis
In search and rescue or industrial inspection applications, thermal cameras are used. Temperature distributions across an area form scalar fields. Identifying anomalies (e.g., a person, a heat leak) often involves finding local maxima or minima in the temperature distribution. Gradient ascent can be used to “walk” towards the hottest point, while gradient descent can identify the coldest. Sophisticated algorithms can use the gradient of the temperature field to pinpoint heat sources more precisely.
Stabilization and Attitude Control
While often implemented using simpler control loops, the underlying principles of maintaining stability can be viewed through the lens of optimizing a stability metric.
Minimizing Error
The drone’s flight control system constantly works to minimize errors between its current state (position, velocity, attitude) and its desired state. These errors can be conceptualized as a scalar “cost” function. The goal is to minimize this cost function. The gradient of this cost function with respect to control inputs (e.g., motor speeds, control surface deflections) would indicate how to adjust those inputs to most effectively reduce the error. While not always explicitly calculated as a continuous gradient in real-time for every minor adjustment, the principles guide the design of robust controllers.
Autonomous Flight and AI Integration
As drones become more autonomous, the gradient becomes an even more integral part of their decision-making processes.
Reinforcement Learning for Flight Control
In reinforcement learning, an AI agent learns to perform tasks by trial and error, receiving rewards or penalties. The “policy” an agent learns can be thought of as a function that maps states to actions. Optimizing this policy to maximize cumulative reward often involves gradient-based optimization techniques to update the policy’s parameters. This allows drones to learn complex flight maneuvers, adapt to changing conditions, or perform tasks with a high degree of autonomy.
Obstacle Avoidance with Machine Learning
Machine learning models trained for obstacle avoidance often process sensor data (e.g., LiDAR, camera images) to predict the presence and proximity of obstacles. These models can output probability maps or distance estimates, which are effectively scalar fields. The gradient of these fields can then inform steering decisions to steer the drone away from predicted collision zones.
Conclusion
The gradient, a fundamental concept in multivariable calculus, provides a powerful mathematical framework for understanding and quantifying change. In the domain of flight technology, its applications are far-reaching. From guiding drones through complex environments using potential fields to interpreting sensor data for precise navigation and enabling advanced autonomous capabilities, the gradient is an indispensable tool. As aerial vehicles continue to evolve, becoming more intelligent and capable, a solid grasp of mathematical principles like the gradient will remain at the forefront of innovation, pushing the boundaries of what is possible in the skies.