
The Interquartile Range (IQR) is a fundamental statistical measure that provides valuable insights into the spread and variability of a dataset. In the context of drone technology, understanding the IQR is crucial for analyzing performance metrics, assessing system stability, and ensuring predictable operation. It helps us move beyond simple averages to grasp the true nature of a drone’s behavior, particularly in critical areas like flight control, sensor data, and payload consistency.
Understanding the IQR in Drone Performance Metrics
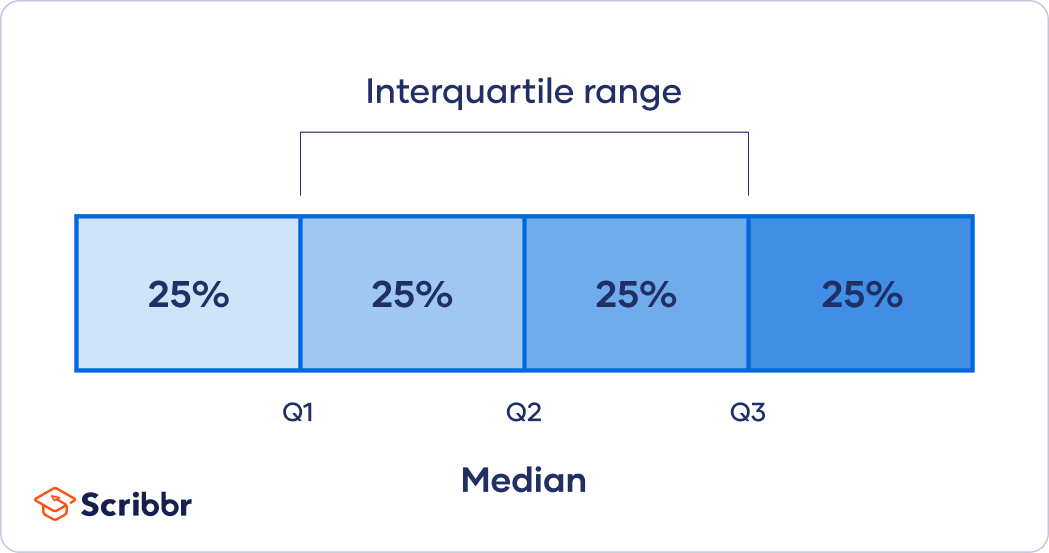
At its core, the IQR represents the range of the middle 50% of a dataset. It is calculated by subtracting the first quartile (Q1) from the third quartile (Q3). Q1 is the value below which 25% of the data falls, and Q3 is the value below which 75% of the data falls. The IQR, therefore, effectively filters out extreme outliers, giving us a more robust understanding of the typical performance characteristics of a drone.

Analyzing Flight Stability and Control
One of the most critical applications of the IQR in drone technology is the analysis of flight stability and control. When we consider metrics like altitude hold accuracy, pitch and roll stability, or yaw rate consistency, a high IQR would indicate significant variability in these parameters. This means that even if the average altitude is well-maintained, the drone might be experiencing substantial fluctuations around that average.
For instance, imagine analyzing a dataset of altitude readings from a drone during a hover. A low average altitude might be achieved, but if the IQR is large, it implies that the drone’s altitude frequently deviates significantly upwards and downwards from this average. This variability can be caused by a multitude of factors, including wind gusts, inaccuracies in the barometric sensor, or responsiveness issues in the flight controller’s PID (Proportional-Integral-Derivative) tuning.
A tight IQR in these stability metrics suggests a well-tuned and stable flight system. This is particularly important for professional applications such as aerial surveying, cinematography, and inspection, where precise and consistent flight is paramount. For a drone used in 4K aerial filmmaking, maintaining a stable platform is non-negotiable for smooth footage. A large IQR in pitch or roll stability would translate directly into shaky and unusable video.
Evaluating Sensor Data Reliability
Drones are equipped with a sophisticated array of sensors, from GPS and inertial measurement units (IMUs) to lidar and thermal cameras. The reliability and consistency of the data generated by these sensors are vital for navigation, mapping, and object detection. The IQR can be instrumental in assessing this reliability.
Consider GPS data. While the average GPS coordinate might appear accurate, a large IQR for the latitude or longitude readings could indicate intermittent signal loss or interference. This variability makes precise navigation and waypoint following challenging, especially in urban canyons or under dense foliage. Analyzing the IQR of GPS coordinates over a period of flight can reveal the extent of this unreliability, prompting engineers to investigate potential signal degradation or explore more robust navigation solutions.
Similarly, for specialized sensors like thermal cameras, the IQR can highlight the consistency of temperature readings. If a drone is used for infrastructure inspection, detecting hotspots in electrical components, a wide IQR in temperature readings from a specific area might suggest sensor noise or fluctuations that could lead to misdiagnosis. A narrow IQR, conversely, would indicate more trustworthy and repeatable temperature measurements, increasing confidence in the inspection results.
Assessing Payload Performance
For drones designed to carry and operate payloads, such as cameras, sensors, or delivery mechanisms, the IQR can shed light on the consistency of their performance.
In the realm of cameras and imaging, if a drone is equipped with a gimbal, analyzing the IQR of its stabilization angles can be insightful. A low IQR for pitch, roll, and yaw stabilization would indicate a consistently smooth camera platform, essential for high-quality aerial photography and videography. Conversely, a large IQR might point to gimbal motor issues, calibration problems, or external vibrations affecting its performance, leading to jerky or unstable footage.
For drones involved in precision agriculture or delivery, the accuracy and consistency of payload deployment are critical. If a drone is designed to dispense fertilizer or deliver small packages, the IQR of the dispensed amount or the landing precision can be analyzed. A large IQR in these metrics would suggest a lack of uniformity, potentially leading to inefficient application or failed deliveries.
The IQR as a Tool for Outlier Detection and Data Cleaning
Beyond simply describing data spread, the IQR is a powerful tool for identifying and handling outliers, which are data points that deviate significantly from the rest of the dataset. In drone operations, outliers can arise from temporary system malfunctions, unexpected environmental conditions, or sensor errors. Identifying these outliers is crucial for maintaining the integrity of collected data and ensuring the safety and effectiveness of drone operations.
Identifying Anomalous Flight Behaviors
During flight, a drone might encounter sudden and extreme deviations from its intended path or behavior. These anomalies can be indicative of critical issues that require immediate attention. By calculating the IQR of various flight parameters like velocity, acceleration, or angular rates, engineers can establish a baseline of normal operation.
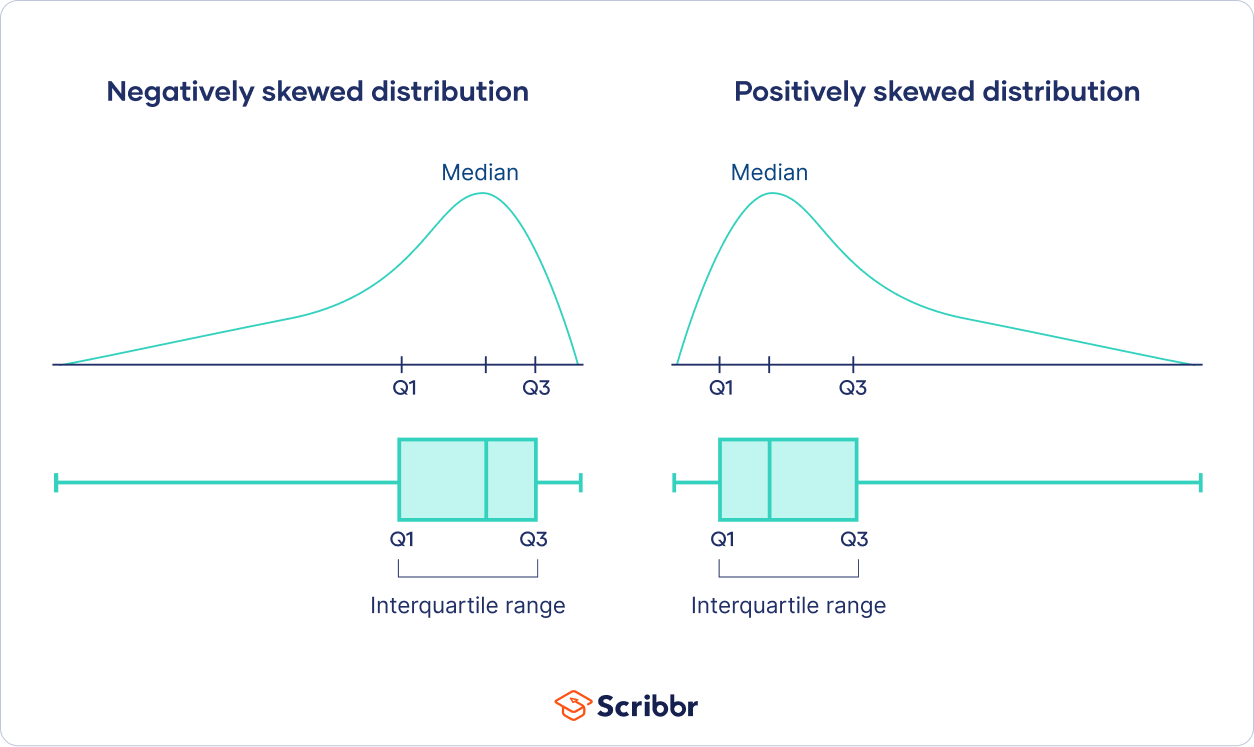
Any data points falling significantly outside the typical range (often defined as 1.5 times the IQR below Q1 or above Q3, forming the boundaries of the “whiskers” in a box plot) can be flagged as potential outliers. For example, a sudden spike in vertical velocity far beyond the expected range could indicate a motor failure or an unexpected downdraft. Detecting such outliers quickly allows for prompt intervention, such as initiating an emergency landing or returning to home, thus preventing potential accidents.
Improving Data Quality for Mapping and Modeling
In applications like aerial mapping and 3D modeling, the quality and consistency of the collected data are paramount. Outliers in sensor readings, such as altitude, GPS coordinates, or camera exposure, can introduce significant errors into the final maps and models, leading to inaccuracies and misinterpretations.
The IQR can be used as a robust method for data cleaning. By identifying and removing or correcting data points that fall far outside the IQR-defined range, the overall quality of the dataset can be significantly improved. This is particularly important for autonomous flight and AI-driven analysis, where biased or erroneous data can lead to flawed decision-making. For instance, in remote sensing applications, a consistent and clean dataset, validated by IQR analysis of sensor readings, ensures more accurate environmental monitoring and resource assessment.
Diagnosing Sensor and System Malfunctions
When a drone system is not performing as expected, the IQR can be a valuable diagnostic tool. By examining the IQR of various sensor readings over time, engineers can pinpoint components or systems that are exhibiting excessive variability.
For example, if the IQR of data from a specific IMU axis is consistently larger than that of other axes or other drones of the same model, it might suggest a calibration issue or a hardware problem with that particular sensor. Similarly, a widening IQR in control surface deviations during a test flight could indicate wear and tear on actuators or linkages. This data-driven approach to diagnostics allows for more targeted and efficient troubleshooting, reducing downtime and improving the overall reliability of the drone fleet.
Applications of IQR in Drone Development and Testing
The insights provided by the IQR extend to the very core of drone development and testing. During the design, prototyping, and validation phases, understanding the variability of system performance is crucial for refining designs and ensuring that the final product meets stringent quality standards.
Refining Flight Controller Tuning
Flight controllers are the brains of a drone, managing its stability and response to pilot inputs or autonomous commands. Tuning the PID parameters of a flight controller is an iterative process aimed at achieving optimal performance – stability without excessive oscillations. The IQR is an excellent metric for evaluating the success of this tuning process.
After a test flight with a particular set of PID gains, the IQR of pitch, roll, and yaw rates can be analyzed. A very low IQR might indicate an over-damped system, where the drone is stable but sluggish. Conversely, a high IQR suggests an under-damped or unstable system, prone to oscillations. The goal is to find a balance, where the IQR is minimized while maintaining responsiveness, indicating a well-tuned and predictable flight experience. This iterative refinement, informed by IQR analysis, is essential for drones intended for complex maneuvers or precise payload operations.
Benchmarking and Comparative Analysis
When developing new drone models or evaluating different flight technologies, benchmarking performance against established standards or competing products is essential. The IQR provides a robust way to compare the variability of key performance indicators across different systems.
For instance, if comparing two different GPS modules for their positional accuracy, simply looking at the average error might be misleading. Analyzing the IQR of the positional errors can reveal which module offers more consistent and reliable positioning over time, even if their average errors are similar. This comparative analysis, utilizing IQR, is crucial for selecting the best components and technologies that contribute to overall drone reliability and performance, particularly in areas like autonomous flight and navigation systems.
Validating Autonomy and AI Features
As drones become more autonomous, the reliability and predictability of their AI-driven features are paramount. The IQR can be used to validate the performance of these advanced systems, such as AI Follow Mode or autonomous obstacle avoidance.
When testing an AI Follow Mode, for example, the IQR of the distance and relative position between the drone and the subject can be analyzed. A tight IQR indicates that the drone maintains a consistent distance and position relative to the subject, even during complex movements. A large IQR might suggest that the AI struggles to maintain a stable tracking path, leading to erratic behavior. Similarly, in obstacle avoidance systems, analyzing the IQR of the minimum distance maintained from detected obstacles can reveal the system’s consistency in providing a safety buffer. This rigorous testing, informed by statistical measures like the IQR, builds confidence in the safety and effectiveness of autonomous drone capabilities.
In conclusion, the Interquartile Range is a powerful statistical tool that offers a nuanced perspective on the variability within drone performance data. By moving beyond simple averages and examining the spread of the central 50% of the data, we gain deeper insights into flight stability, sensor reliability, payload consistency, and overall system integrity. Its application in outlier detection, data cleaning, and the refinement of drone development processes underscores its importance in advancing the capabilities and trustworthiness of drone technology.