
The evolution of drone technology from simple remote-controlled toys to sophisticated autonomous aerial platforms has been nothing short of revolutionary. At the heart of this transformation lies an intricate dance of hardware, software, and fundamental mathematical principles. Among these foundational elements, the “floor function” might seem like an obscure mathematical concept, yet its discreet application is vital in the precise, real-time calculations that empower modern drone capabilities, particularly within the realm of Tech & Innovation encompassing autonomous flight, mapping, and AI-driven features. Understanding this function demystifies a crucial aspect of how drones interpret and interact with their complex environments.
The Mathematical Foundation: Understanding the Floor Function
At its core, the floor function is a fundamental mathematical operation that plays a critical role in converting continuous numerical values into discrete integer representations. This transition from the continuous to the discrete is paramount in digital systems, where all computations ultimately rely on integers.
Definition and Basic Examples
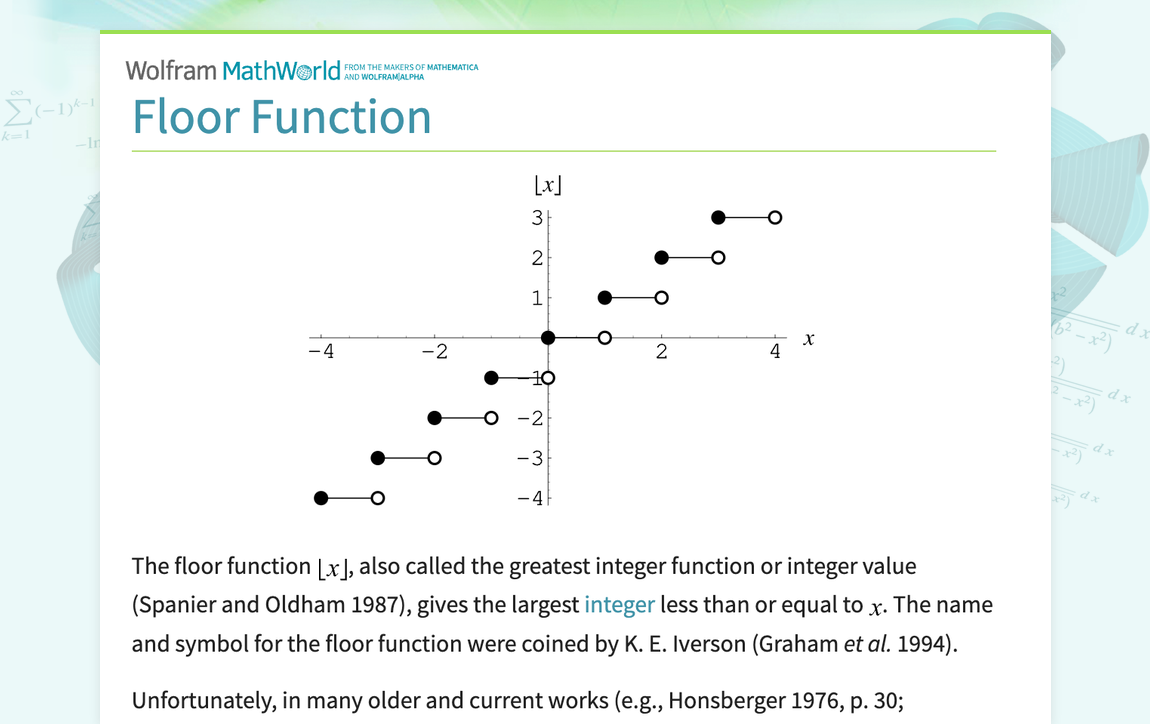
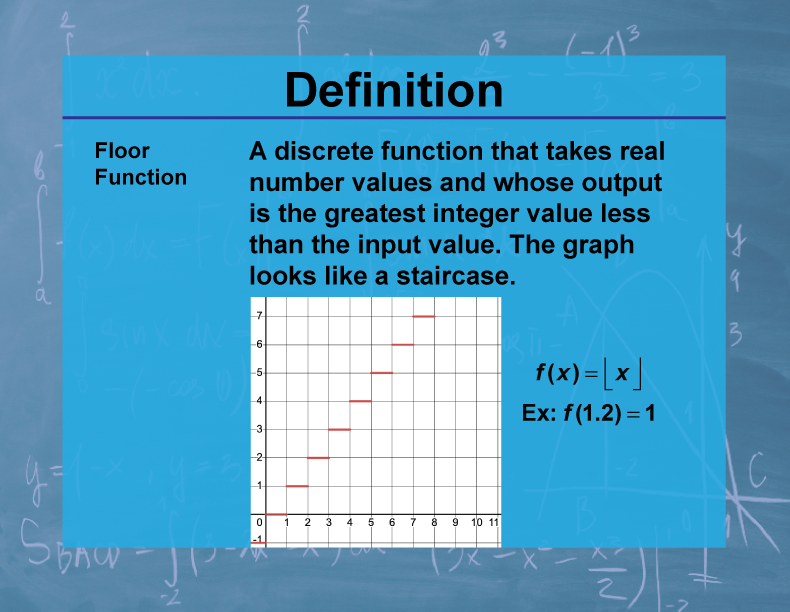
Mathematically denoted as $lfloor x rfloor$ or floor(x), the floor function takes any real number x and returns the greatest integer less than or equal to x. In simpler terms, it effectively “rounds down” a number to the nearest integer below or at its current value.
For instance:
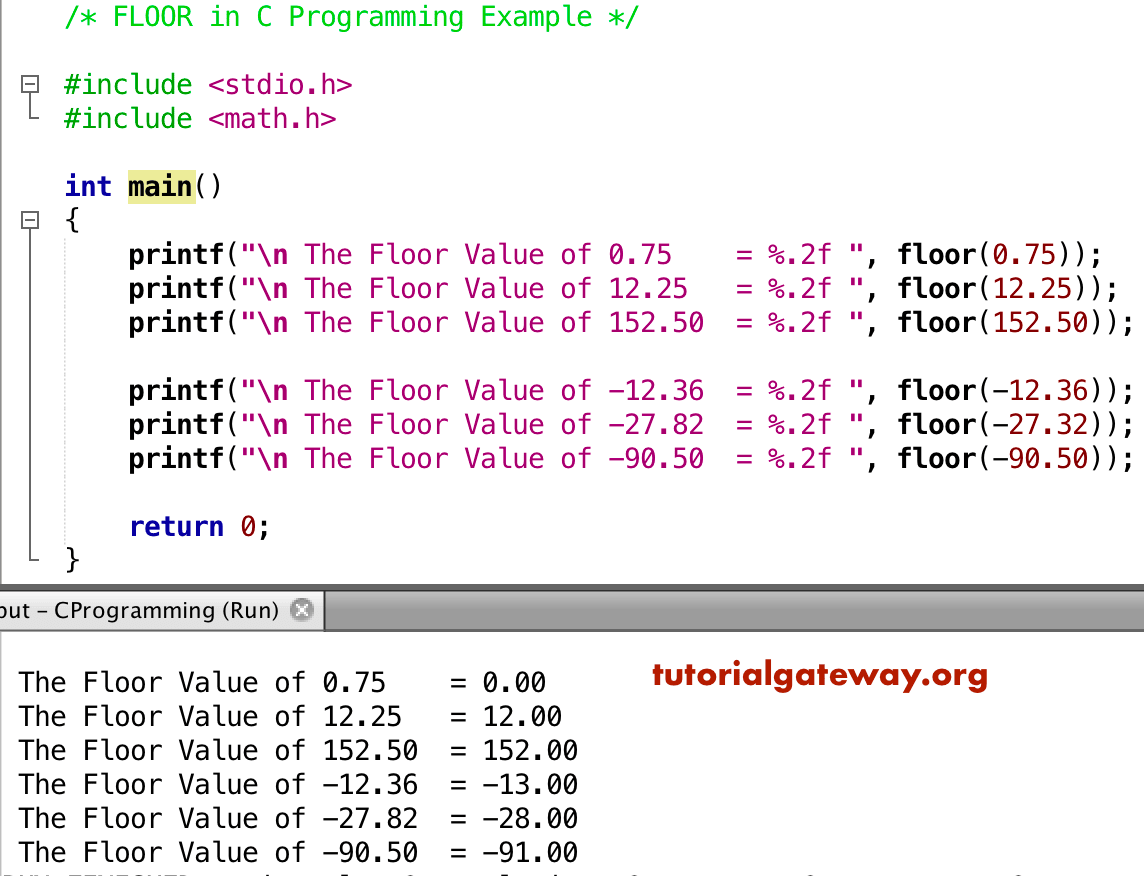
floor(3.14)equals3.floor(5.99)equals5.floor(7)equals7(when the number is already an integer, it remains unchanged).floor(-2.5)equals-3(as -3 is the greatest integer less than or equal to -2.5).
This consistent “rounding down” characteristic is what distinguishes it and makes it indispensable for specific computational tasks where any fractional part must be discarded while preserving the lower bound integer value.
Contrast with Ceiling and Round Functions
To fully appreciate the floor function, it’s helpful to briefly contrast it with its mathematical siblings: the ceiling function and the standard round function.
The ceiling function, denoted ceil(x) or $lceil x rceil$, returns the smallest integer greater than or equal to x. It “rounds up.” For example, ceil(3.14) is 4, and ceil(-2.5) is -2.
The round function typically rounds to the nearest integer. Most implementations round .5 cases away from zero (e.g., round(3.5) is 4, round(-3.5) is -4). This differs from the floor function’s unwavering downward direction.
The distinct behavior of the floor function – always moving towards negative infinity – makes it uniquely suited for scenarios where a definite lower integer bound is required, ensuring that operations always reference a valid, non-exceeding integer index or state.
Importance in Discrete Mathematics
The digital world operates on discrete values. Analog signals from sensors are converted into digital data, and continuous physical spaces are modeled as grids or discrete points. The floor function is a cornerstone of this conversion process. It allows systems to map a potentially infinite range of continuous values onto a finite set of integers, which is essential for indexing arrays, allocating memory, iterating through loops, and managing states in control systems. In essence, it provides the mathematical bridge from the continuous reality drones navigate to the discrete computations their processors perform.
Precision and Discretization in Autonomous Flight Systems
Autonomous drones rely heavily on precise calculations to understand their position, plan routes, and avoid obstacles. The floor function is subtly yet crucially involved in converting the continuous data from sensors into discrete information that the drone’s computational systems can efficiently process and act upon.
Spatial Gridding for Navigation and Path Planning
One of the most profound applications of the floor function in autonomous flight is in spatial gridding. Drones operate in a three-dimensional continuous space, but for efficient navigation, path planning, and obstacle avoidance, this space is often simplified into a discrete grid. Algorithms like A* (A-star) or Dijkstra’s, commonly used for optimal pathfinding, require a grid-based representation of the environment.
When a drone receives continuous coordinates from its Global Positioning System (GPS) or Inertial Measurement Unit (IMU), these floating-point values need to be mapped onto integer grid cell indices. The floor function facilitates this mapping. For instance, if a drone is at (real_x, real_y) in meters, and the grid cells are cell_size meters wide, the corresponding grid cell coordinates (grid_x, grid_y) can be calculated as:
grid_x = floor(real_x / cell_size)
grid_y = floor(real_y / cell_size)
This ensures that any point within a given cell_size square always maps to the same unique integer grid cell, allowing the drone to maintain a consistent discrete representation of its surroundings, crucial for constructing occupancy maps and planning collision-free trajectories.
Quantizing Sensor Data for Robust Decision-Making
Drones are equipped with a plethora of sensors—LiDAR, ultrasonic, altimeters, airspeed sensors—all generating continuous streams of data. For autonomous decision-making, it is often more efficient and robust to convert these continuous readings into discrete categories or “bins.” This process, known as quantization, simplifies the logic required for the drone’s control system.
For example, a drone might need to interpret its distance from an obstacle not as an exact floating-point number, but as “very close,” “moderately close,” or “safe distance.” The floor function can be used to define the boundaries for these categories. If an ultrasonic sensor reports a distance d in meters, and a threshold T defines a “very close” zone:
if (floor(d / T) == 0) then “very close”.
This allows the flight controller to make rapid, rule-based decisions without processing complex floating-point comparisons, improving response times and system stability. Similarly, altitude data could be quantized for discrete altitude layers in multi-layered airspace management.
Time Slicing and Task Scheduling
Real-time operating systems (RTOS) are standard in drone flight controllers, managing numerous concurrent tasks from sensor readings to motor control. These tasks are executed in discrete time slices or intervals to ensure predictable performance. The floor function can be crucial in managing these temporal discretizations.
For instance, if a specific task needs to execute every N milliseconds, and the system’s internal clock provides continuous time t (e.g., in microseconds), the floor function can help determine the current N-millisecond interval:
current_interval_index = floor(t / (N * 1000))
This allows the RTOS to accurately schedule periodic tasks, ensure time synchronization across different modules, and manage system resources efficiently, all critical for the stable and reliable operation of an autonomous drone.
Enhancing Mapping and Remote Sensing Applications
Beyond immediate flight control, the floor function significantly contributes to the sophisticated data processing required for drone-based mapping and remote sensing, transforming raw sensor data into actionable geographic intelligence.
Building Digital Elevation Models (DEMs) and Point Clouds
Drones equipped with LiDAR or photogrammetry payloads are routinely used to generate detailed 3D models of terrain and structures, known as Digital Elevation Models (DEMs) or point clouds. These involve collecting millions of data points, each with continuous X, Y, and Z coordinates. To create a structured DEM, where elevation is represented on a regular grid, these continuous points must be mapped to discrete grid cells.
The floor function is indispensable here. For each data point (x, y, z), its horizontal coordinates (x, y) are used to determine which grid cell it belongs to, much like in spatial gridding for navigation. If the DEM grid has a resolution of R meters per pixel, then:
grid_x_index = floor(x / R)
grid_y_index = floor(y / R)
Multiple points falling into the same grid cell are then typically averaged or processed to determine the cell’s final elevation value. This ensures an organized, computationally manageable representation of the terrain.
Data Aggregation and Analysis in Remote Sensing
Remote sensing involves collecting data about an area from a distance, often using multispectral or hyperspectral cameras on drones. The resulting imagery and data streams are vast and require aggregation for meaningful analysis. Whether analyzing vegetation health, soil composition, or urban development, data points are often grouped into discrete regions or pixels for consistent processing.
When interpreting sensor readings across an area, the floor function helps assign continuous geographic coordinates or sensor read-out positions to specific discrete analysis units (e.g., a pixel in an aggregated image, a segment of a field). This standardization is crucial for applying statistical methods, classification algorithms, and change detection analyses, providing a uniform framework for interpreting diverse datasets.
Creating Orthomosaic Maps
Orthomosaic maps are high-resolution, georeferenced aerial images composed of hundreds or thousands of individual drone photos stitched together. These maps are “orthorectified,” meaning they are geometrically corrected to remove distortion and represent true ground distances, much like a traditional map.
During the process of projecting individual drone images onto a single, continuous ground plane and then discretizing it into a final pixel grid for the orthomosaic, the floor function plays a critical role. When transforming real-world coordinates (X_world, Y_world) to pixel coordinates (pixel_col, pixel_row) on the orthomosaic, the floor function ensures that each real-world coordinate maps to a unique, consistent integer pixel:
pixel_col = floor(X_world / pixel_resolution_x)
pixel_row = floor(Y_world / pixel_resolution_y)
This precise mapping is essential for creating seamless, accurate, and georeferenced maps vital for applications in agriculture, construction, and environmental monitoring.
The Floor Function in AI and Machine Learning for Drones
The advent of AI and machine learning has dramatically expanded drone capabilities, enabling features like AI Follow Mode, autonomous inspection, and intelligent object recognition. The floor function, by enabling efficient discretization, becomes an unsung hero in many of these advanced algorithms.
Discretizing Continuous States for Reinforcement Learning
Reinforcement Learning (RL) is a paradigm where an AI agent learns to make decisions by interacting with an environment, receiving rewards or penalties. While some RL algorithms can handle continuous state spaces, it is often more computationally efficient and stable to discretize continuous observations for the agent.
In an AI Follow Mode, for instance, a drone’s relative distance to a target, its angle, or its speed are continuous values. An RL agent might convert these into discrete states. For example, “distance to target” could be binned into “very close,” “close,” “medium,” “far,” using the floor function to define the boundaries of these bins based on continuous sensor readings. This simplifies the state space the AI needs to learn, making training faster and potentially more robust, particularly in resource-constrained drone environments.
Feature Engineering and Binning
In various machine learning tasks employed by drones (e.g., classifying objects, predicting battery life, identifying anomalies), continuous features from sensor data often benefit from being binned or quantized. This process, known as feature engineering, can improve model performance, reduce overfitting, and make models more interpretable.
For example, a continuous “wind speed” reading might be binned into discrete categories like “calm,” “moderate,” “strong,” using the floor function to assign the appropriate bin. This transforms a potentially noisy continuous input into a stable categorical feature that machine learning models can process more effectively, enhancing the drone’s ability to adapt to environmental conditions or identify critical events.
Indexing Look-up Tables and Arrays
Many AI algorithms, especially those running on embedded systems like drone flight controllers, rely on efficient data retrieval from pre-computed look-up tables or arrays. When an algorithm needs to access a specific value based on a continuous input, the floor function helps translate that continuous input into a valid integer index.
Consider a drone’s vision system using a pre-trained model. If an input value (e.g., a normalized pixel intensity or a calculated feature score) falls within a continuous range, the floor function can map it to an array index to fetch a corresponding weight, threshold, or decision rule. This ensures rapid data access without the overhead of complex floating-point comparisons, critical for real-time AI processing.
Challenges and Best Practices in Implementation
While the floor function is a powerful tool, its effective implementation in drone technology requires careful consideration of trade-offs, edge cases, and interactions with floating-point arithmetic.
Precision vs. Performance Trade-offs
Quantization using the floor function inherently reduces the precision of data. For a drone, this means sacrificing some granularity in its understanding of the environment for improved computational speed and efficiency. The challenge lies in finding the optimal balance: quantize too aggressively, and the drone might lose critical details (e.g., misidentifying a small obstacle); retain too much precision, and the computational load might overwhelm the flight controller, leading to latency or instability. Engineers must meticulously evaluate the impact of quantization levels on mission-critical functions.
Edge Cases and Boundary Conditions
The behavior of the floor function at integer boundaries, especially with negative numbers, demands careful attention. For instance, floor(-2.0) is -2, but floor(-2.0000000001) is -3. These subtle differences can lead to off-by-one errors in grid indexing or state transitions if not properly handled. Developers must account for these edge cases in their algorithms to prevent unexpected drone behavior or system crashes. Robust code often includes explicit checks or uses functions designed to handle boundary conditions gracefully.
Integration with Floating-Point Arithmetic
The floor function typically operates on floating-point numbers. However, floating-point arithmetic itself is prone to precision issues due to the way numbers are represented in binary. A value that mathematically should be, for example, 3.0, might be stored as 2.9999999999999996 or 3.0000000000000004 due to representation errors. Applying the floor function to such values can yield unintended results (floor(2.999...) is 2, not 3). Best practices often involve adding a small epsilon (1e-9 or similar) before applying the floor function for positive numbers to counteract these tiny negative deviations, or using specific libraries that guarantee robust floating-point comparisons and conversions. Understanding the nuances of floating-point arithmetic is paramount for reliable floor function implementation in embedded drone systems.