
Within the rapidly evolving landscape of drone technology and innovation, one can observe contrasting philosophies guiding development, deployment, and access. While the terms “communism” and “socialism” are deeply rooted in political and economic ideologies, their core tenets of centralization versus distribution, proprietary control versus collective ownership, and exclusive access versus shared benefit offer a compelling, albeit metaphorical, framework to understand divergent paths in the tech world. This exploration delves into how these conceptual differences manifest in the practicalities of drone systems, from AI follow modes and autonomous flight to mapping and remote sensing.
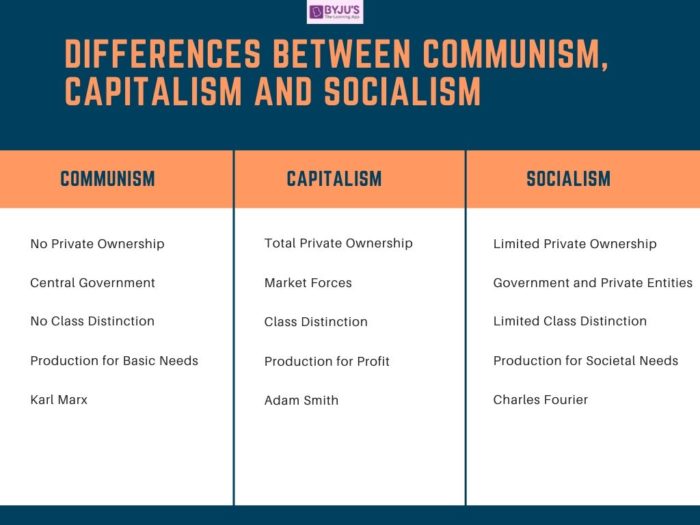
Centralized Development vs. Distributed Innovation in Drone Systems
The genesis and evolution of drone technology often follow two distinct trajectories, echoing the centralized and distributed models. One path emphasizes stringent control, proprietary systems, and a top-down approach, while the other champions open collaboration, shared resources, and community-driven progress.
The “Communist” Paradigm: Proprietary Ecosystems and State Control
In this metaphorical “communist” approach to drone tech, innovation is often concentrated within powerful corporations or government entities. Research and development are conducted in highly controlled environments, leading to the creation of proprietary hardware, software, and algorithms. These systems are typically closed-source, meaning their internal workings, code, and design specifications are not publicly accessible. Manufacturers retain exclusive rights to modify, improve, and distribute their products, often creating tightly integrated ecosystems where components from other brands are incompatible.
For instance, certain high-end autonomous flight systems or advanced AI follow modes might be developed entirely in-house, guarded by intellectual property rights. Access to these cutting-edge features might be restricted, requiring specific licensing, expensive subscriptions, or exclusive partnerships. Governments might also lean towards this model for sensitive applications, developing bespoke drone fleets for surveillance, defense, or critical infrastructure monitoring, where control, security, and standardization are paramount. Data generated by these systems often remains within the originating entity, creating large, exclusive data silos. This approach prioritizes security, performance optimization within a controlled environment, and the protection of investment through monopolistic advantages, but can stifle broader innovation and limit accessibility for the wider tech community.
The “Socialist” Approach: Open-Source Platforms and Collaborative Endeavors
Conversely, the “socialist” model for drone innovation thrives on decentralization and collaboration. This philosophy underpins the vast and vibrant open-source drone community, where developers, hobbyists, and researchers worldwide contribute to shared projects. Platforms like ArduPilot or PX4, which provide open-source autopilot software, exemplify this approach. Their codebases are publicly accessible, allowing anyone to inspect, modify, and improve the software. This collaborative environment fosters rapid innovation, as a diverse group of minds can identify bugs, develop new features, and adapt the technology for myriad applications.
Hardware designs, too, can follow this model, with schematics and 3D print files openly shared, enabling individuals and small businesses to build and customize drones without needing to start from scratch. This democratizes access to advanced drone technology, significantly lowering barriers to entry for aspiring innovators. Community forums and online repositories become critical hubs for knowledge sharing, troubleshooting, and collective problem-solving. The focus here shifts from exclusive ownership to collective improvement and widespread utility. Enhancements to AI capabilities, obstacle avoidance algorithms, or remote sensing techniques are often contributed back to the community, benefiting everyone using the platform. This model accelerates the pace of innovation by leveraging global talent and promotes a more inclusive and accessible drone ecosystem.
Data Ownership and Resource Allocation: Exclusive vs. Shared Access
The way data generated by drones is owned, managed, and utilized presents another key differentiator between these two philosophical approaches, particularly relevant in mapping and remote sensing applications.
Closed Data Silos and Monopolistic Platforms
Under the “communist” model, data generated by drone operations, especially for mapping, surveying, or environmental monitoring, is often seen as a proprietary asset. Large corporations or state agencies that deploy extensive drone fleets for remote sensing gather vast amounts of data, which they then process, analyze, and often monetize exclusively. This can lead to the creation of “data silos” – large collections of valuable information that are not shared with external entities. Companies might offer these data sets as part of a service, requiring clients to subscribe to their platform or pay per use, thereby controlling access and pricing.
For example, a company conducting large-scale agricultural mapping might keep all its collected spectral data, only offering farmers access to insights derived from that data, not the raw data itself. Similarly, governments might maintain exclusive databases of sensitive topographical or infrastructure maps compiled by their drones. This concentration of data can grant significant power to the owning entity, potentially leading to monopolies in specific data-driven services and limiting the ability of smaller players or academic researchers to contribute to broader societal understanding or develop competing applications. The emphasis is on maintaining competitive advantage and controlling the entire value chain from data collection to analysis and application.
Community-Driven Mapping and Collective Intelligence
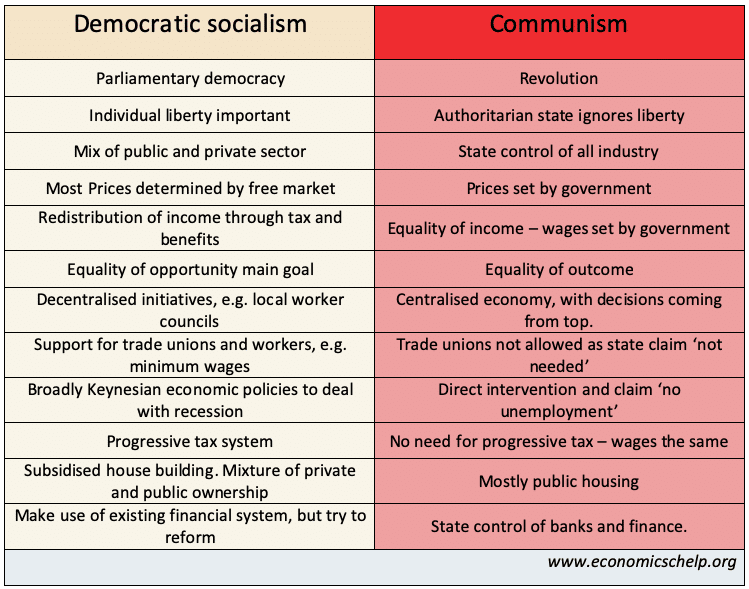
The “socialist” perspective, however, promotes the idea of data as a common resource, particularly when it serves the public good. Open-source mapping projects, powered by drone data, are excellent examples. Initiatives that encourage individuals and organizations to contribute drone imagery and mapping data to public repositories aim to build comprehensive, freely accessible datasets. Projects focusing on disaster response, environmental monitoring, or urban planning often rely on this collective intelligence, where data from multiple sources is aggregated and made available for public use.
This approach believes that widespread access to high-quality geospatial data can unlock new insights, foster innovation, and enable more effective decision-making across various sectors. For instance, volunteer drone pilots might contribute imagery of post-disaster areas to humanitarian organizations, creating up-to-date maps for rescue efforts. Researchers can freely access these datasets for scientific studies, contributing to a better understanding of our planet. The focus here is on maximizing the societal benefit derived from drone-generated data, emphasizing transparency, collaboration, and the shared ownership of information to empower a broader community.
Autonomous Flight and AI: Controlled Governance vs. Ethical Decentralization
The application of Artificial Intelligence (AI) in autonomous flight and advanced drone functions also highlights these contrasting philosophies, particularly concerning governance, ethics, and control.
Command-and-Control AI and Proprietary Algorithms
In the “communist” model of AI and autonomy, the intelligence driving drones is typically embedded in proprietary algorithms developed and controlled by a single entity. This could be a large defense contractor designing AI for military drones, or a major tech company building highly specialized autonomous delivery systems. The algorithms for obstacle avoidance, navigation, target recognition, or complex mission planning are closely guarded secrets, often patented, and not subject to external review or modification.
This centralized control ensures consistency, predictability, and often a high degree of performance within the specific parameters defined by the developer. It allows for stringent testing and validation processes under the direct supervision of the creators. However, it also raises concerns about transparency, bias, and accountability. Without public access to the underlying code or the ability for independent auditing, it can be challenging to understand how decisions are made by these autonomous systems, particularly in critical applications. The ethics of AI are often determined and enforced internally by the developing entity, with limited external input.
Collaborative AI Ethics and Public Interest Autonomy
The “socialist” approach to AI for autonomous drones champions a more transparent, collaborative, and ethically driven development process. This involves fostering open-source AI frameworks for drones, where algorithms for navigation, vision processing, and decision-making are developed and refined by a global community. The code is open for peer review, allowing for greater scrutiny of potential biases, vulnerabilities, and ethical implications.
Discussions around AI ethics become a community endeavor, with a focus on ensuring that autonomous drone systems are developed responsibly, prioritize public safety, and serve the common good. Projects might explore AI that can be easily customized for specific local needs, or frameworks that incorporate ethical guidelines directly into their design. The emphasis is on building AI systems whose behavior is predictable and auditable, fostering trust through transparency. This model seeks to decentralize the power of AI development, preventing any single entity from monopolizing the future of autonomous flight and ensuring that the benefits of advanced AI are distributed broadly and guided by collective societal values.
The Impact on Accessibility and Utility
Ultimately, these divergent approaches significantly impact the accessibility and broad utility of drone technology, shaping who benefits from innovation.
Restricted Access and Specialized Applications
When drone technology adheres to the “communist” model, characterized by proprietary systems and centralized control, access is often restricted. This can lead to drones being expensive, requiring specialized training, or limited to niche, high-value applications primarily benefiting large organizations or governments. The lack of interoperability between systems can create vendor lock-in, where users are tied to a single provider for hardware, software, and services. While these systems often excel in their specialized domains due to tailored development, their high cost and complexity can exclude smaller businesses, academic institutions, and hobbyists from leveraging cutting-edge advancements. Innovation tends to be driven by market demand from well-resourced clients, rather than a broad base of users.
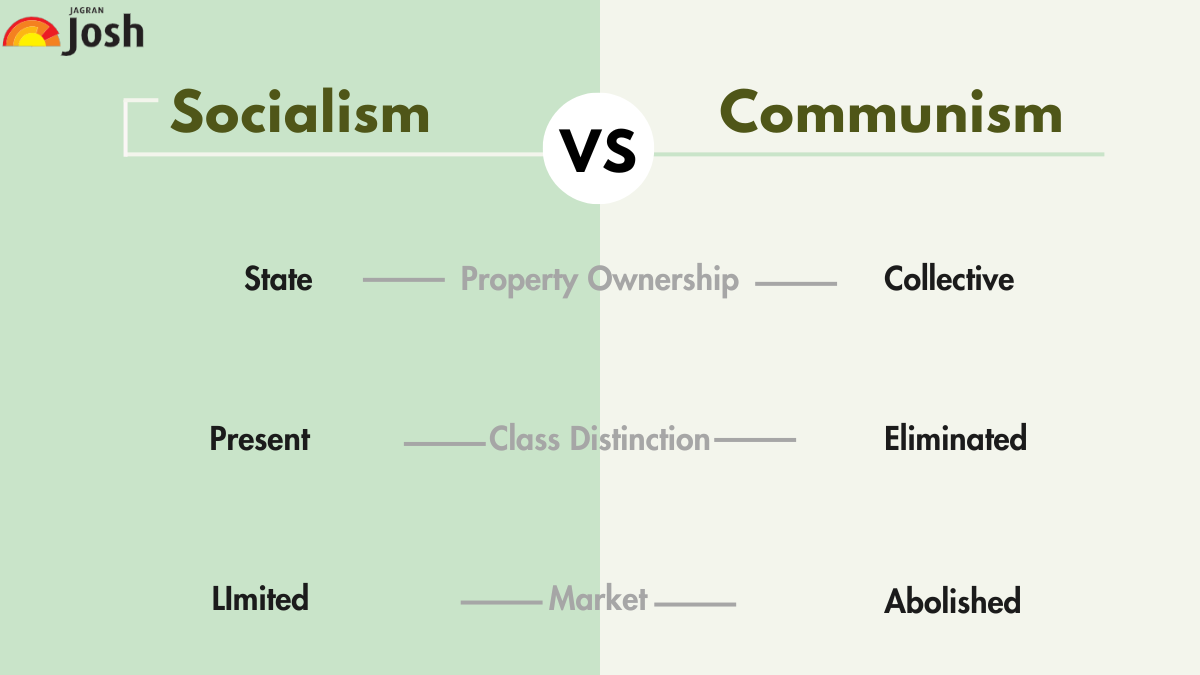
Broad Utility and Empowerment through Shared Technologies
The “socialist” model, conversely, prioritizes broad accessibility and widespread utility. By fostering open-source platforms, collaborative development, and shared resources, it democratizes drone technology. Lower costs, easier customization, and a supportive community make advanced drones and their applications accessible to a much wider audience. Small businesses can integrate drone solutions without prohibitive capital investment, educational institutions can use advanced hardware for research and teaching, and citizen scientists can contribute to environmental monitoring. This model empowers individuals and communities, allowing them to adapt and apply drone technology to address local challenges, fostering a culture of innovation from the ground up. The shared nature of the technology ensures that progress benefits the many, rather than being concentrated among a select few.