
In the intricate world of flight technology, the concept of “appropriate tire pressure” serves as a profound metaphor for the precise calibration, optimal configuration, and vigilant maintenance required for a drone’s critical flight systems. Just as a vehicle’s tire pressure fundamentally dictates its safety, efficiency, and handling characteristics on the ground, the meticulous tuning of a drone’s flight technology ensures its stability, navigational accuracy, and overall operational integrity in the air. This foundational “pressure” is not a physical measurement in PSI for airborne vehicles, but rather a holistic state of optimal readiness across interconnected sensors, processors, and control algorithms. Understanding and maintaining this metaphorical “pressure” is paramount for anyone operating advanced aerial platforms, from hobbyists to professional pilots in specialized fields.
Calibrating the Core: The “Pressure” of Flight Stabilization
The bedrock of any drone’s flight capability lies in its stabilization systems, primarily driven by the Inertial Measurement Unit (IMU). The IMU, comprising accelerometers and gyroscopes, continuously senses the drone’s orientation, angular velocity, and linear acceleration. For these sensors, “appropriate pressure” translates directly to precise calibration.
Analogy: From Ground Vehicles to Aerial Systems
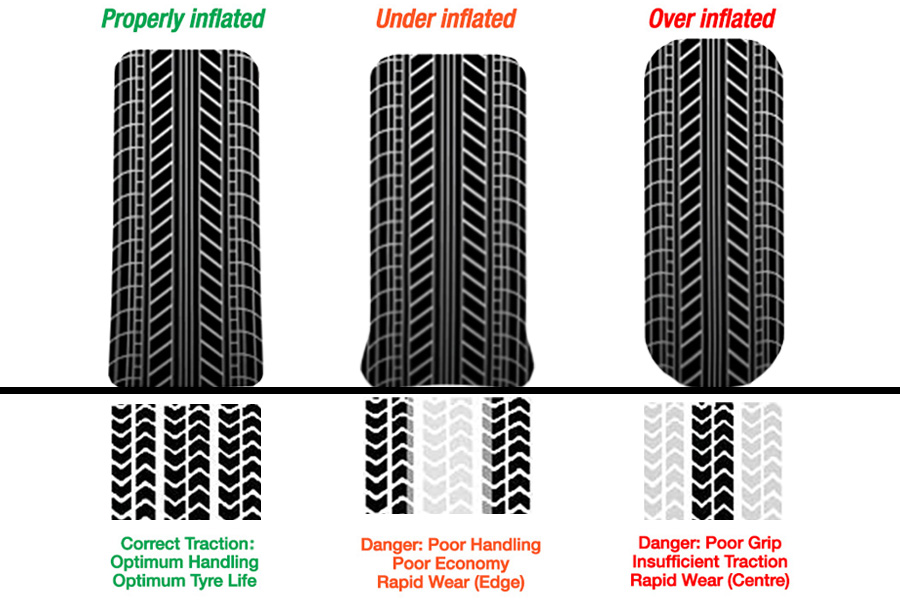
Consider the imbalance or incorrect inflation of a car tire; it leads to vibration, poor handling, and premature wear. Similarly, an uncalibrated or improperly calibrated IMU introduces errors, leading to drift, instability, and potentially catastrophic flight behavior. Without a perfectly “inflated” (calibrated) IMU, the drone’s flight controller receives flawed data, resulting in corrective actions that are either insufficient or overcompensating. This manifests as jerky movements, difficulty holding position, or even a complete loss of control, much like driving a car with dangerously uneven tire pressure.
The Critical Role of IMU Calibration
IMU calibration involves a process where the flight controller learns the baseline readings of the accelerometers and gyroscopes in a static, level state. This establishes a zero-point reference against which all subsequent motion is measured. Environmental factors like temperature changes or even minor physical shocks can subtly alter IMU performance, necessitating regular re-calibration. Some advanced flight controllers incorporate adaptive algorithms that continuously monitor IMU data for discrepancies and apply minor corrections on the fly, acting as a dynamic “pressure monitoring system.” Maintaining this precise “pressure” ensures that the drone’s stabilization systems can accurately counteract external forces, such as wind gusts, and execute precise maneuvers, maintaining its intended flight path with unwavering stability.
Navigational “Inflation”: GPS and Positional Accuracy
Beyond stable flight, a drone’s ability to navigate accurately relies heavily on its Global Positioning System (GPS) module and its integration with other navigational sensors. Here, “appropriate tire pressure” refers to the integrity and reliability of the positional data feeding into the flight controller.
Ensuring Precise Satellite Data “Pressure”
GPS modules acquire signals from satellites to triangulate the drone’s position in 3D space. For optimal accuracy, the module needs a clear sky view to receive signals from a sufficient number of satellites (typically 7-10 for robust positioning) and to maintain a low Horizontal Dilution of Precision (HDOP) value. This is the “pressure” of data quality. A low HDOP indicates that the satellites are well-distributed in the sky, leading to more precise position estimates. Conversely, poor GPS signal quality (high HDOP), often caused by obstructions like buildings or dense foliage, is akin to an underinflated tire—it significantly compromises performance and safety, leading to GPS drift, “toilet bowling” (uncommanded circular movements), or even a fly-away scenario.
The Fusion of Navigational Sensors
Modern drones often employ sensor fusion techniques, combining GPS data with other navigation aids like GLONASS, Galileo, and even visual positioning systems (VPS) or optical flow sensors, especially for indoor or low-altitude flight where GPS may be unreliable. These additional sensors act as supplementary “air pumps,” providing redundant or alternative data streams to maintain “pressure” on the overall positional accuracy. Barometric pressure sensors, for instance, are critical for maintaining altitude hold, providing accurate vertical positioning data independent of GPS. By integrating these diverse data sources and ensuring each is providing “high-pressure” (accurate) information, the drone’s navigational system can achieve robust and reliable positioning, crucial for autonomous flight, waypoint navigation, and precise mission execution.

Environmental Dynamics and Adaptive “Pressure” Adjustments
The aerial environment is far from static, presenting continuous challenges to maintaining optimal flight “pressure.” Wind, temperature, and even atmospheric pressure variations demand that a drone’s flight technology be adaptable, capable of dynamically adjusting its operational parameters.
Wind Conditions and Flight Controller Tuning
Wind is arguably the most significant environmental factor influencing drone flight. Just as tire pressure might be adjusted for different road conditions, a drone’s flight controller settings, particularly its PID (Proportional-Integral-Derivative) gains, need to be tuned to effectively counter wind forces. PID gains determine how aggressively the drone responds to errors in its orientation and position. For example, higher P-gain might be necessary in windy conditions to provide a stiffer, more immediate response to gusts, preventing the drone from being pushed off course. However, excessively high gains can lead to oscillations and instability. The “appropriate pressure” here is a finely balanced tuning that allows the drone to maintain stability without becoming overly sensitive or under-responsive to the prevailing wind. Advanced flight controllers feature adaptive tuning algorithms that can learn and adjust these parameters in real-time, acting as an automatic “tire pressure monitoring system” for aerial dynamics.
Temperature and Component Performance
Temperature variations also affect the “pressure” of various flight technology components. Batteries perform differently in cold versus hot conditions, impacting power delivery and flight time. Electronic components, including flight controllers, IMUs, and ESCs (Electronic Speed Controllers), can experience performance degradation or drift at extreme temperatures. For instance, IMU sensors can exhibit temperature-dependent biases, making re-calibration necessary when moving between significantly different climates. The “appropriate pressure” in this context involves understanding these thermal characteristics and, where possible, implementing temperature compensation mechanisms or adjusting operational limits. For example, some professional drones include heated IMU units to maintain consistent sensor performance regardless of ambient temperature, ensuring that the “pressure” of critical sensor data remains stable.
Barometric Pressure Sensors and Altitude Hold
The barometric pressure sensor is a direct and literal application of “pressure” within drone flight technology. This sensor measures atmospheric pressure to determine the drone’s altitude. Maintaining “appropriate pressure” for altitude hold means ensuring the sensor is accurately calibrated and that its readings are correctly interpreted by the flight controller. Rapid changes in weather fronts, flying through thermals, or even the drone’s own prop wash can cause localized pressure variations that impact altitude readings. Advanced algorithms filter this data and fuse it with GPS altitude (if available) to maintain a stable altitude. Without accurate barometric “pressure,” the drone struggles to hold a consistent height, leading to unwanted vertical oscillations or altitude drift, compromising tasks like aerial mapping or cinematic shots.
The Impact of Suboptimal “Pressure” on Drone Performance
Failing to maintain the “appropriate tire pressure”—that is, neglecting the calibration, tuning, and environmental considerations for a drone’s flight technology—can lead to a cascade of negative consequences, ranging from minor annoyances to critical failures.
Instability and Loss of Control
The most immediate and dangerous impact of suboptimal “pressure” in flight systems is instability. An improperly calibrated IMU, an untuned flight controller for specific conditions, or compromised GPS data can all contribute to a drone becoming erratic and difficult to control. This can manifest as unexpected drifts, wobbles, or even uncommanded movements that can quickly lead to a crash, posing risks to the drone itself, surrounding property, and people. It’s akin to driving a vehicle with tires that are drastically under or overinflated; the handling becomes unpredictable, and the risk of an accident skyrockets.
Reduced Efficiency and Component Strain
Just like driving on underinflated tires reduces fuel efficiency and wears out the tires faster, a drone operating with suboptimal flight technology “pressure” experiences reduced efficiency and increased strain on its components. If the flight controller is constantly battling inaccurate sensor data or struggling with an unoptimized PID tune, the motors and ESCs have to work harder, consuming more power and generating more heat. This leads to shorter flight times, accelerated wear and tear on motors and propellers, and a higher risk of component failure. The drone is essentially fighting itself, expending energy unnecessarily to maintain a semblance of stability.
Data Inaccuracy and Mission Failure
For professional applications such as aerial mapping, surveying, inspection, or cinematography, data accuracy is paramount. Suboptimal “pressure” in navigation systems (GPS, altimeters) leads to inaccurate positional data, resulting in skewed maps, imprecise measurements, or poorly framed shots. If the drone drifts off its intended flight path due to poor GPS “pressure” or struggles to maintain a consistent altitude because of faulty barometric readings, the entire mission’s data output can be compromised, rendering the collected information unusable and leading to costly re-flights or project delays. Ensuring every sensor and control system is operating at its “appropriate pressure” is not just about flight safety; it’s about guaranteeing the integrity and success of the aerial mission.
In conclusion, while the phrase “appropriate tire pressure” traditionally refers to wheeled vehicles, its underlying principle—the critical importance of maintaining optimal foundational settings for peak performance, safety, and longevity—is universally applicable to complex machinery, including advanced flight technology. For drone operators, this translates to an unwavering commitment to precise calibration, intelligent tuning, and a keen awareness of environmental factors. By consistently ensuring that every facet of their drone’s flight systems operates at its “appropriate pressure,” pilots can unlock the full potential of their aerial platforms, achieving safer, more efficient, and ultimately more successful flights.