
In the rapidly evolving world of unmanned aerial vehicles (UAVs), commonly known as drones, the concept of a “computer” extends far beyond a traditional desktop. Instead, a drone operates as a sophisticated, distributed computing system where multiple processors work in concert. Understanding “what is output computer” in this context is crucial to grasping the capabilities and potential of modern drone technology, particularly concerning tech and innovation. The output from these integrated computational units isn’t merely data; it’s the intelligence that drives autonomous flight, powers sophisticated data acquisition, and enables revolutionary applications in mapping, remote sensing, and AI-driven operations.
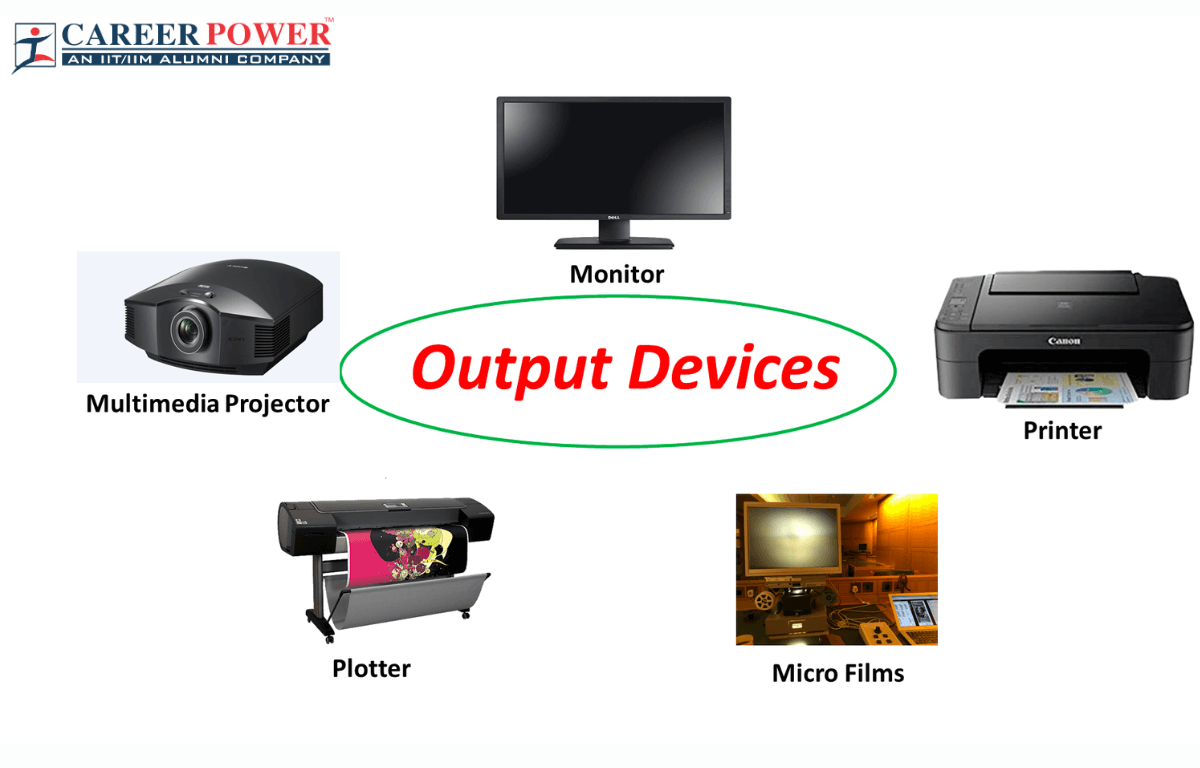
The Drone as a Distributed Computational Ecosystem
A drone’s “computer” isn’t a single monolithic entity but rather a complex ecosystem of interconnected processors, sensors, and communication modules. This distributed architecture allows for specialized tasks to be handled by dedicated units, enhancing efficiency, redundancy, and overall performance. The outputs from these various computational nodes collectively form the drone’s operational intelligence.
Onboard Processing Units
At the heart of every drone is its flight controller, often referred to as the brain. This primary onboard computer continuously processes data from a myriad of sensors – accelerometers, gyroscopes, magnetometers, barometers, and GPS modules. Its core output comprises real-time flight control commands (throttle, pitch, roll, yaw) that are sent to the electronic speed controllers (ESCs) and motors, ensuring stable and commanded flight. Beyond basic flight, advanced drones incorporate secondary, more powerful companion computers. These units are dedicated to computationally intensive tasks such as real-time image processing, object recognition, path planning for autonomous navigation, and executing complex algorithms for AI Follow Mode or precision landing. Their output includes processed visual data, identified objects, optimized flight paths, and decisions based on complex AI models.
Ground Control Station Interaction
While much of the computing power resides onboard, the ground control station (GCS) serves as another vital component of the drone’s computational ecosystem. The GCS, often a tablet or laptop running specialized software, processes telemetry data received from the drone, converting raw sensor readings into readable maps, flight logs, and system statuses. Its primary output to the user includes visual representations of the drone’s position, altitude, speed, battery level, and mission progress. Conversely, the GCS also outputs mission plans, waypoint commands, and real-time control inputs to the drone, acting as an interface for human operators to guide and instruct the autonomous system. This two-way communication and processing loop are fundamental for mission execution and remote supervision.
Primary Operational Outputs for Intelligent Flight
The most immediate and critical outputs from a drone’s computer system are those that directly facilitate its ability to fly intelligently and safely. These outputs are the bedrock upon which all advanced drone applications are built, allowing for precision and reliability in dynamic environments.
Dynamic Flight Control Commands
The core output of the flight controller is a continuous stream of precise commands directed at the drone’s propulsion system. Based on sensor inputs and desired flight parameters (from the pilot or an autonomous mission plan), the flight controller’s algorithms calculate the necessary adjustments to motor speeds. For instance, in an AI Follow Mode, the onboard computer processes live video feeds and target tracking algorithms. Its output is not just a “follow” instruction, but a series of dynamic pitch, roll, yaw, and throttle commands that precisely adjust the drone’s position and orientation to maintain optimal tracking of the subject, even as it moves unpredictably. This intricate choreography of commands ensures smooth, responsive, and stable flight performance, adapting in real-time to environmental changes and operational demands.
Comprehensive Telemetry Data
Telemetry output is the lifeblood of drone operations, providing critical feedback on the drone’s status and performance. This data stream, continuously transmitted from the drone’s onboard computers to the GCS, includes an extensive array of parameters: GPS coordinates (latitude, longitude, altitude), airspeed, ground speed, attitude (roll, pitch, yaw), battery voltage and current draw, motor RPMs, signal strength, and sensor health. For autonomous systems, this telemetry is not just for human monitoring; it’s also a crucial input for internal state estimation, allowing the drone to verify its position, track its progress against a mission plan, and detect anomalies. In innovative applications, analyzing this rich output data post-flight provides insights into flight efficiency, sensor performance, and potential areas for system optimization, directly contributing to advancements in drone autonomy and reliability.
Advanced Data Outputs for Specialized Applications
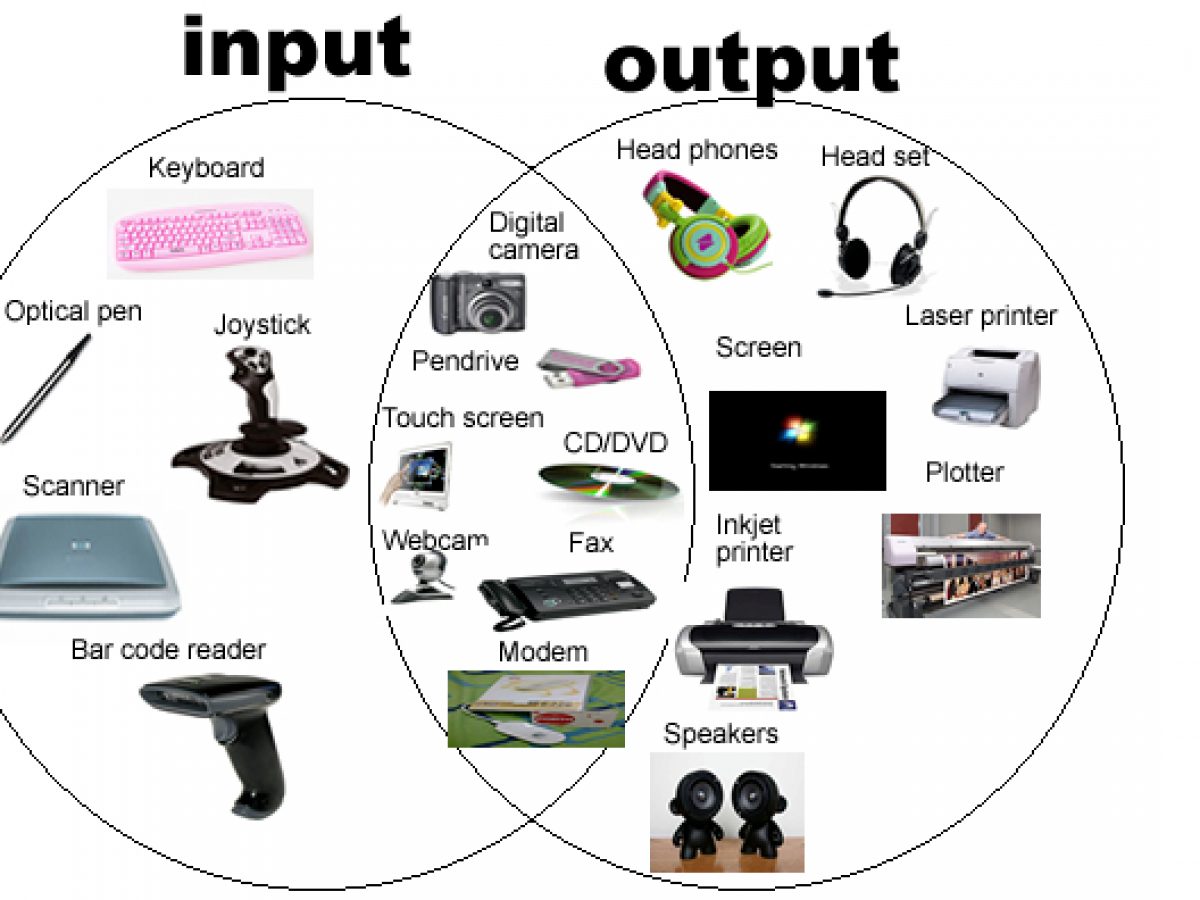
Beyond the fundamental outputs for flight, modern drone computers generate highly specialized data for advanced applications. These outputs are the tangible results of combining sophisticated sensor technology with powerful onboard and cloud-based processing, enabling drones to perform tasks that were previously impossible or impractical.
Mapping and Geospatial Data Generation
One of the most transformative outputs from a drone’s computer system, especially in the context of remote sensing and mapping, is the creation of geospatial data products. Drones equipped with high-resolution cameras, LiDAR scanners, or multispectral sensors capture vast amounts of raw imagery or point cloud data. The onboard computer, often with the assistance of powerful ground or cloud-based processing, performs initial georeferencing using GPS and IMU data. The final output includes highly accurate 2D orthomosaics, 3D point clouds, digital surface models (DSMs), and digital terrain models (DTMs). These outputs are invaluable for urban planning, construction progress monitoring, agriculture (crop health analysis via NDVI maps), environmental surveying, and infrastructure inspection. The “computer” here is not just collecting data; it’s transforming raw sensor input into actionable, spatially accurate information.
Remote Sensing Insights
For remote sensing applications, the output of a drone’s computer moves beyond raw data to processed insights. Using specialized sensors (e.g., thermal, multispectral, hyperspectral), the onboard computer can acquire data that is invisible to the human eye. The subsequent processing, often involving machine learning algorithms, generates analytical outputs such as heat signatures for wildlife detection or building insulation analysis, vegetation health indices for precision agriculture, and mineral composition maps for geological surveys. These outputs are tailored interpretations of the environment, enabling experts to make informed decisions across various industries. The drone’s computer acts as a real-time analytical engine, outputting not just images, but quantified environmental intelligence.
AI-Driven Action Outputs
The true pinnacle of “Tech & Innovation” in drones lies in AI-driven action outputs. For features like autonomous flight, obstacle avoidance, and AI Follow Mode, the onboard computer continuously processes complex data streams from vision sensors, LiDAR, and ultrasonic sensors. Using deep learning and computer vision algorithms, it identifies obstacles, classifies objects (people, vehicles, trees), and predicts trajectories. The output is not just an alert, but immediate, autonomous action commands: rerouting flight paths to avoid collisions, maintaining optimal distance from a moving subject, or precisely landing on a designated marker. For example, in an autonomous inspection scenario, the AI might process images of a wind turbine blade, identify a crack, and then output specific coordinates and an instruction to capture additional, high-resolution imagery of the anomaly, all without human intervention.
Communication and User Interface Outputs
While much of the drone’s computing output is machine-to-machine, a significant portion is designed for human interaction or integration into broader digital ecosystems. These outputs ensure that operators are informed and that drone data can be seamlessly utilized by other systems.
Visual Displays and Alerts
The most common human-centric outputs from a drone’s computer system are the visual displays and alerts presented on a ground control station screen or a remote controller. These include real-time video feeds from the drone’s camera, overlaid with critical flight information (on-screen display or OSD), digital maps showing the drone’s position and flight path, and graphical representations of battery status, signal strength, and sensor readings. Furthermore, the computer outputs audio and visual alerts to warn pilots of low battery, strong winds, GPS signal loss, or detected obstacles, allowing for immediate corrective action. This human-readable output is vital for maintaining situational awareness and safe operation.
API and Data Stream Outputs
For integrating drones into larger industrial or research ecosystems, the “computer” also outputs data through Application Programming Interfaces (APIs) and direct data streams. This allows third-party applications and backend servers to access raw telemetry, flight logs, sensor data, and processed mission outputs. For instance, in a smart city application, a drone might conduct aerial surveys, and its computer’s output—geotagged images or 3D models—is automatically uploaded to a cloud platform via an API. This data can then be analyzed by urban planners or integrated into city management systems. This programmatic output facilitates automation, enables sophisticated data analytics at scale, and unlocks new possibilities for how drones contribute to broader technological infrastructures.
The Future of Drone Output: Smarter, More Autonomous Systems
As drone technology continues to advance, the concept of “what is output computer” will become even more sophisticated. Future outputs will focus on even higher levels of autonomy, predictive intelligence, and seamless integration with artificial intelligence and machine learning. We can anticipate drones outputting not just data, but actionable insights and self-executing remediation plans. Imagine a drone inspecting a solar farm, identifying a faulty panel, and then outputting a work order directly to a maintenance crew, complete with precise location and diagnostic data. This evolution towards highly intelligent, self-optimizing outputs is propelling drones from mere data collectors to indispensable partners in a future driven by autonomous innovation.