
The Linux kernel is the heart of any Linux-based operating system, and its initialization process is a critical phase that determines how the system boots and becomes functional. Within this intricate startup sequence, the initrc script plays a pivotal role. Often referred to as the “initialization resource script” or “initialization script,” the initrc is a shell script that executes a series of commands to bring the system to a usable state after the kernel has been loaded and the initial processes have been spawned. Understanding initrc is fundamental to grasping the boot process of Linux systems, particularly those used in embedded applications, which often underpin sophisticated drone and flight control systems.
The Linux Boot Process: A Foundation for Flight Control
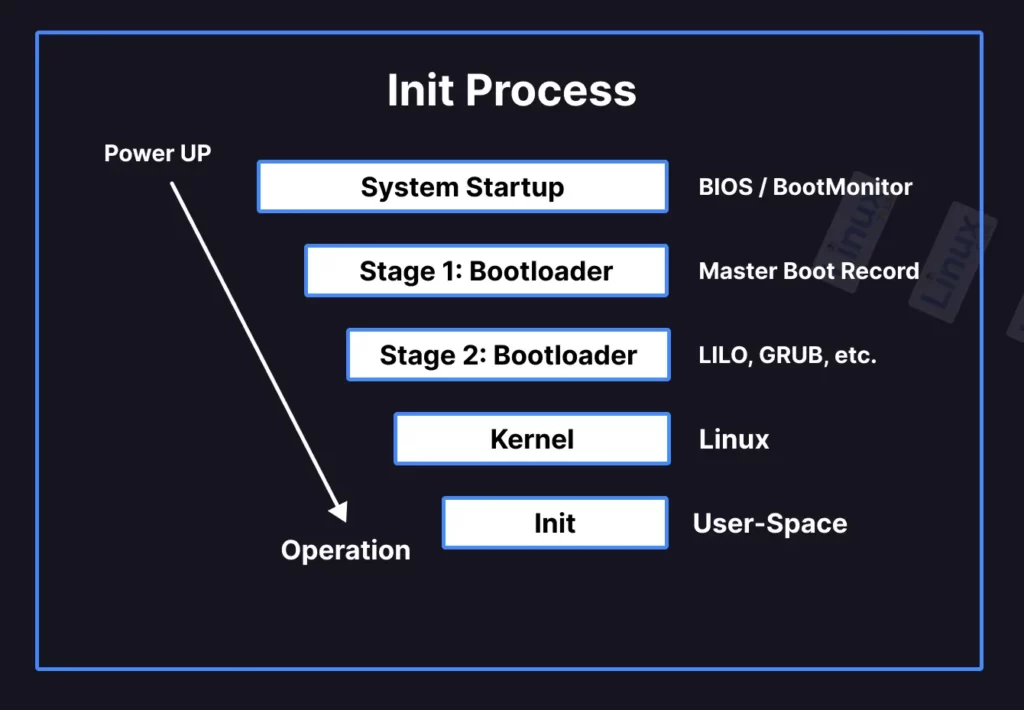
Before delving into the specifics of initrc, it’s essential to appreciate the broader Linux boot sequence. This sequence is a multi-stage process designed to load the operating system and make it ready for user interaction or application execution.
The Bootloader Stage
The boot process begins with the bootloader, such as GRUB or U-Boot, which resides in the firmware of the system’s hardware. Upon power-on, the bootloader is the first software to execute. Its primary responsibility is to locate and load the Linux kernel into memory. For embedded systems like drones, U-Boot is a common choice due to its flexibility and widespread support in the embedded Linux community. The bootloader also passes crucial kernel command-line parameters that can influence how the kernel behaves during initialization.
Kernel Initialization
Once the bootloader has loaded the kernel, the kernel takes over. It performs a series of self-checks, initializes its core data structures, and detects and configures hardware components. During this phase, the kernel mounts the root filesystem, which contains the essential files and directories needed to boot the rest of the operating system.
The Init Process: The Ancestor of All Processes
The kernel’s final act in its direct initialization is to launch the first user-space process, conventionally named init. This process has a process ID (PID) of 1 and is the “ancestor” of all other processes that will run on the system. The init process is responsible for continuing the boot process by bringing the system up to a desired runlevel or target state.
The Role of Initrc
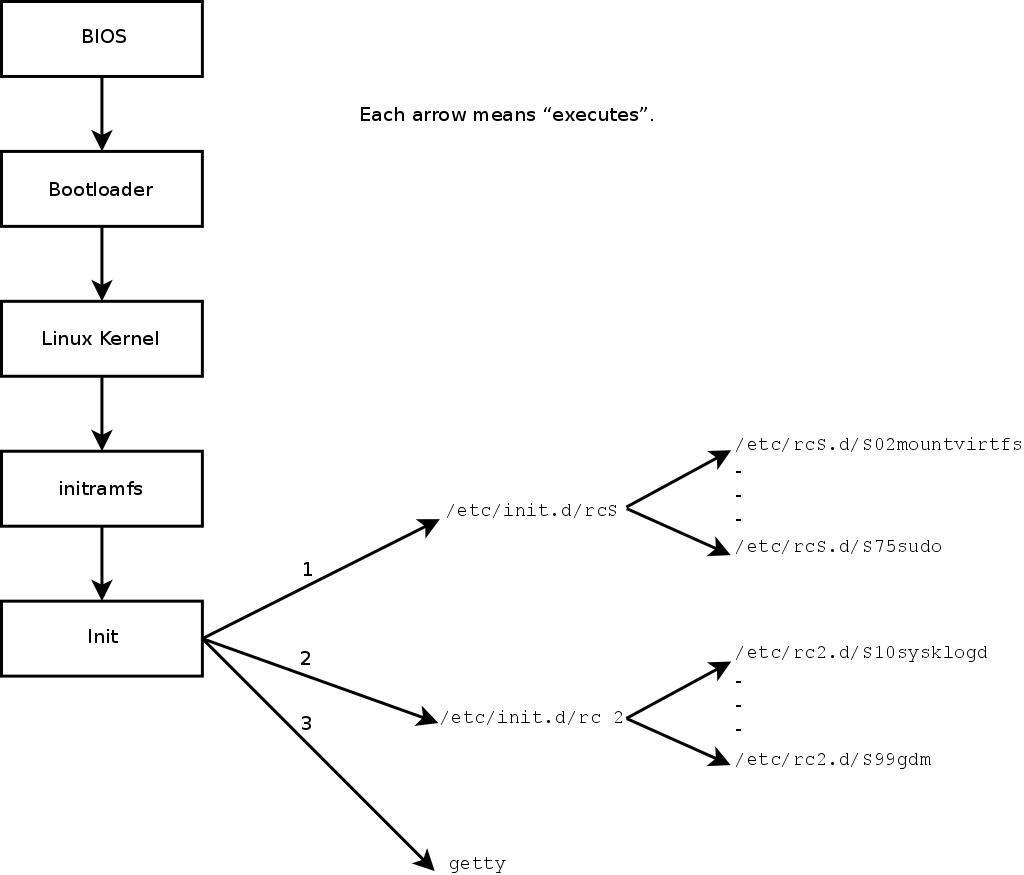
This is where the initrc script enters the picture. Traditionally, init would read configuration files from /etc/inittab (System V init) to determine what actions to perform. In more modern Linux systems, especially those employing systemd, the concept of a single initrc script executed by the traditional init daemon has evolved. However, the spirit of initrc as a script that orchestrates the startup of various services and system components remains.
In older or simpler embedded systems, the init process might directly execute a shell script located at /etc/init.d/rcS or a similar path. This script, our initrc, would then contain the commands to:
- Mount additional filesystems: Beyond the root filesystem, other partitions like
/proc,/sys, and/devneed to be mounted./procand/sysprovide interfaces to kernel data structures and hardware, while/devcontains device files. - Initialize hardware: Specific hardware components might require custom initialization routines beyond what the kernel’s generic drivers provide.
- Start essential daemons: Network services, logging daemons, and other background processes that are crucial for system operation are started here.
- Set up networking: Configuring network interfaces, IP addresses, and routing information is often handled within
initrc. - Start the console or graphical environment: Depending on the system’s purpose,
initrcmight launch a login prompt on the console or start a graphical user interface (GUI).
For systems like drones, the initrc script is tailored to the specific hardware and the requirements of the flight control software. It ensures that the necessary drivers are loaded, sensors are initialized, communication interfaces (like telemetry radios or Wi-Fi) are configured, and the core flight control daemons are brought online in the correct order.
Evolution to Modern Init Systems: systemd and Beyond
While initrc in its traditional shell script form is still relevant in many embedded Linux contexts, the broader Linux ecosystem has seen the rise of more advanced init systems, most notably systemd. systemd aims to provide a more robust, efficient, and parallelized initialization process.
Understanding systemd Units
Instead of a single monolithic initrc script, systemd uses a system of “units.” These units can be services, devices, mount points, sockets, or targets. Each unit is defined by a .service file (or other unit type) which specifies dependencies, execution commands, and lifecycle management.
The init process in a systemd system is systemd itself. It reads configuration files from /etc/systemd/system/ and /usr/lib/systemd/system/. When systemd starts, it evaluates its target units (e.g., multi-user.target for a multi-user system or graphical.target for a GUI system) and then starts all the necessary service units and their dependencies in parallel.
The Concept of rc.local
Even in systems that use systemd, there’s often a mechanism to run custom scripts during boot. This is commonly achieved through the rc.local service. The rc.local file, typically located at /etc/rc.local, is a simple shell script that systemd executes at the end of the boot process, after all other services have started. This provides a convenient way for administrators to add custom boot-time commands without needing to create complex .service unit files. For drone systems, rc.local might be used to launch custom diagnostic tools or to perform final system checks before arming.
Embedded Linux and Initrc’s Enduring Relevance
Despite the widespread adoption of systemd, many embedded Linux distributions, especially those tailored for specific hardware platforms like drone flight controllers, might still rely on or offer a simplified init system where a traditional initrc script remains central. This is often due to:
- Resource constraints: Embedded systems may have limited memory and processing power, making the leaner approach of a shell script initialization more suitable than the more complex
systemdframework. - Simplicity and familiarity: For developers accustomed to traditional Unix-like boot processes, a shell script offers a straightforward and well-understood mechanism for controlling startup sequences.
- Hardware vendor support: Some hardware vendors provide BSPs (Board Support Packages) that are designed around simpler init systems, including custom
initrcscripts.
In these contexts, understanding initrc is not merely an academic exercise; it’s a practical necessity for customizing and debugging the boot process of the flight control computer.
Customizing initrc for Drone Applications
The initrc script on a drone’s flight computer is more than just a generic boot script; it’s the orchestrator of critical flight systems. Its customization is paramount for ensuring reliable and performant operation.
Key Components Managed by initrc on Drones
- Sensor Initialization: This includes calibrating and starting up GPS modules, IMUs (Inertial Measurement Units), barometers, magnetometers, and lidar or optical flow sensors. The
initrcensures these sensors are ready to provide data to the flight controller. - Communication Interfaces: Configuring serial ports for telemetry, establishing Wi-Fi or Ethernet connections for ground control or data logging, and managing radio control receiver communication are all handled here.
- Motor Controllers (ESCs): While the actual motor control might be managed by a dedicated real-time process,
initrcensures that the necessary drivers and interfaces for the Electronic Speed Controllers (ESCs) are set up. - Flight Control Software Daemons: The core flight control software, such as ArduPilot, PX4, or custom-developed solutions, often runs as one or more daemons.
initrcis responsible for launching these daemons with the correct parameters and ensuring they have access to all necessary resources. - Logging and Diagnostics: Setting up robust logging mechanisms is vital for post-flight analysis and debugging.
initrccan configure log rotation, destination paths, and the level of detail captured. - Watchdog Timers: For critical embedded systems, watchdog timers are essential. These hardware or software mechanisms reset the system if it becomes unresponsive.
initrccan configure and enable these watchdog services.
Examples of initrc Customization
Consider a scenario where a drone needs to perform autonomous mapping. The initrc script would be modified to:
- Prioritize sensor startup: Ensure the GPS and high-resolution camera are initialized and communicating correctly before any mapping software begins.
- Configure high-bandwidth interfaces: Set up a dedicated network interface for high-volume image data transfer to a companion computer or ground station.
- Launch mapping daemons: Start the specific mapping software, providing it with configuration files that define the mission parameters and desired output formats.
- Establish inter-process communication: Ensure that the mapping software can reliably communicate with the flight control software to receive position updates and potentially send back commands or status.
Conversely, for a racing drone, the initrc might focus on minimizing boot time and prioritizing low-latency sensor and control signal processing. It would ensure that the FPV camera feed and RC receiver data are available almost instantaneously, with less emphasis on extensive sensor calibration or background service startup.
Debugging initrc Issues
When a Linux system, especially an embedded one like a drone’s flight computer, fails to boot correctly, the initrc script is often a prime suspect. Diagnosing problems at this stage requires a methodical approach.
Common initrc Problems
- Syntax errors: A simple typo or misplaced character in the shell script can prevent it from executing.
- Incorrect file permissions: If the
initrcscript or any files it tries to access do not have the correct read or execute permissions, it will fail. - Dependency issues: The script might try to start a service or mount a filesystem that isn’t available or properly configured.
- Hardware initialization failures: If a crucial sensor or communication module fails to initialize, the
initrcmight halt the boot process or cause subsequent services to fail. - Infinite loops: Poorly written scripts can sometimes enter infinite loops, leading to a frozen system.

Debugging Techniques
- Serial Console Access: The most direct way to debug boot issues is through a serial console. This provides a low-level terminal connection that is available very early in the boot process, often before networking or other higher-level services are active. By observing the kernel messages and the output of the
initrcscript on the serial console, developers can pinpoint where the boot process is failing. - Kernel Command Line Parameters: Modifying kernel command-line parameters can enable verbose boot logging, disable certain services, or force the system into a specific mode, which can aid in debugging.
- Step-by-Step Execution: In some environments, it’s possible to interrupt the boot process and manually execute parts of the
initrcscript line by line to isolate the problematic command. - Mounting the Filesystem on Another System: If the system is completely unbootable, the root filesystem can often be mounted on a separate Linux machine. This allows direct inspection and modification of the
initrcscript and its associated configuration files. - Using
straceandltrace: These powerful command-line tools can trace system calls and library calls, respectively. While typically used for debugging running applications, they can sometimes be employed to understand what a failinginitrcscript is attempting to do.
The initrc script, whether a traditional shell script or managed by a more modern init system, represents the crucial bridge between the kernel and the operational state of a Linux-based system. For the specialized world of drones and flight control, its meticulous configuration and understanding are indispensable for building safe, reliable, and feature-rich aerial platforms.