
Cascaded, in the context of flight technology, refers to a multi-stage or layered approach to processing and controlling complex systems. It’s a fundamental concept that underpins many advanced functionalities within modern aircraft, particularly in areas like navigation, stabilization, and obstacle avoidance. Understanding cascading is crucial for appreciating the sophisticated algorithms and hardware that enable drones and other flying vehicles to operate safely and effectively in dynamic environments.
Cascaded Control Systems in Flight Technology
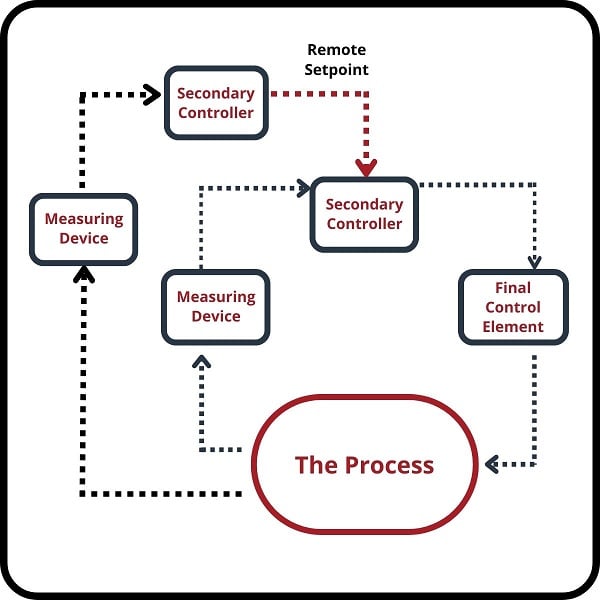
At its core, a cascaded control system involves a primary controller (outer loop) that sets a desired setpoint for a secondary controller (inner loop). The secondary controller then acts to achieve this setpoint, often by manipulating lower-level parameters. This hierarchical structure allows for greater stability, precision, and robustness compared to a single, monolithic controller.

The Outer Loop: High-Level Objectives
The outer loop of a cascaded system is responsible for achieving the broader, more abstract objectives of the flight. For instance, in navigation, the outer loop might receive commands for a desired waypoint or a specific flight path. Its task is to determine the overall commands needed to reach that objective, such as calculating the necessary pitch, roll, and yaw angles required to follow a particular trajectory.
This outer loop typically operates at a slower rate, processing information about the aircraft’s global position, destination, and environmental factors. It relies on data from navigation systems like GPS, inertial measurement units (IMUs), and potentially external reference points. The output of the outer loop is not a direct command to the actuators (motors, control surfaces) but rather a target setpoint for the inner loop.
The Inner Loop: Low-Level Execution
The inner loop is where the immediate, dynamic adjustments happen. It receives the setpoint from the outer loop and works to achieve it with high speed and accuracy. In our navigation example, the inner loop would take the desired pitch, roll, and yaw angles from the outer loop and translate them into precise motor speed commands.
This inner loop operates at a much faster rate, constantly monitoring the aircraft’s current state (e.g., angular velocity, altitude) and comparing it to the setpoint. It utilizes feedback from sensors like gyroscopes and accelerometers to detect deviations and make rapid corrections. The goal of the inner loop is to ensure that the aircraft’s attitude and motion precisely match the targets set by the outer loop, effectively decoupling the performance of the inner loop from the slower dynamics of the outer loop.
Benefits of Cascaded Control
The cascaded architecture offers several significant advantages in flight technology:
- Improved Stability: By separating fast-acting inner loops from slower outer loops, the system becomes less prone to oscillations and instability. The inner loop can quickly reject disturbances without affecting the outer loop’s ability to pursue its objective.
- Enhanced Precision: The inner loop’s high bandwidth allows it to precisely track the setpoints provided by the outer loop, leading to more accurate navigation and attitude control.
- Robustness: Cascaded systems can be more resilient to variations in the aircraft’s dynamics (e.g., changes in payload, aerodynamic conditions). The inner loop can adapt to these changes while the outer loop maintains its primary objective.
- Decoupling of Dynamics: The inner loop effectively filters out high-frequency noise and disturbances, presenting a smoother and more stable target to the outer loop. This simplifies the design and tuning of the outer loop controller.
- Modular Design: Cascaded systems lend themselves well to modular design, where individual loops can be developed, tested, and optimized independently.
Cascaded Systems in Drone Stabilization and Navigation
The application of cascaded control is pervasive in modern drones, particularly in their stabilization and navigation systems.
Gimbal Stabilization: A Prime Example
One of the most intuitive examples of cascaded control in drones is found in gimbal stabilization systems. A gimbal is a device that allows a camera to remain level and steady, even as the drone pitches, rolls, and yaws.
- Outer Loop (Camera Leveling): The outer loop of the gimbal controller aims to keep the camera perfectly level with respect to the horizon, irrespective of the drone’s orientation. It receives input from the drone’s IMU to detect its attitude and calculates the necessary tilt and pan angles for the gimbal to counteract these movements and maintain a stable horizon line.
- Inner Loop (Motor Control): The inner loop of the gimbal controller receives the desired tilt and pan angles from the outer loop. It then uses high-speed motors to drive the gimbal’s axes, ensuring that the camera precisely follows these commanded angles. This inner loop is characterized by high bandwidth and responsiveness, rapidly compensating for even minor vibrations or changes in drone orientation.
The cascaded approach here ensures that the camera remains stable, producing smooth, professional-quality footage, even when the drone is performing aggressive maneuvers or flying in turbulent conditions.
Navigation and Path Following
Cascaded control is also fundamental to how drones navigate and follow pre-defined paths.

- Outer Loop (Waypoint Navigation/Path Planning): This loop is responsible for determining the overall trajectory the drone should follow to reach its destination or execute a specific mission. It takes inputs from GPS, mission planning software, and potentially obstacle avoidance systems. The output of this loop is a series of desired position, velocity, and attitude commands for the drone.
- Inner Loop (Attitude and Velocity Control): This loop receives the desired attitude (pitch, roll, yaw) and velocity setpoints from the outer navigation loop. It then uses the drone’s flight controllers and motor control algorithms to adjust motor speeds to achieve and maintain these desired states. This involves rapidly correcting for deviations in altitude, speed, and orientation to precisely follow the planned path. For example, if the outer loop commands a specific pitch angle to ascend, the inner loop will adjust motor speeds to achieve that pitch and maintain altitude.
Obstacle Avoidance Integration
Cascaded control principles are also applied when integrating obstacle avoidance systems with navigation and control.
- High-Level Obstacle Avoidance Logic (Outer Loop): When an obstacle is detected, the high-level logic might issue a “stop” command, a “detour” command, or a command to maintain current position. This higher-level decision is an input to the standard navigation and control loops.
- Navigation/Control Re-planning (Mid-Level): The navigation system, influenced by the obstacle avoidance command, might re-plan a slightly modified path. This new path then becomes the setpoint for the lower-level control loops.
- Attitude and Velocity Control (Inner Loop): The drone’s primary flight controllers continue to operate in their cascaded manner, taking the new attitude and velocity commands from the re-planned path and executing them by controlling motor speeds. The key is that the inner loops continue to ensure stable flight even as the outer loops are rapidly adapting to avoid the detected obstacle.
Cascaded Systems in Sensor Data Processing
Beyond direct control, cascaded processing is also common in how drones interpret and utilize sensor data.
Multi-Sensor Fusion
Drones often rely on a combination of sensors (IMU, GPS, barometer, lidar, cameras) to understand their environment and position. Cascaded processing can be used to fuse this data effectively.
- Low-Level Sensor Calibration and Filtering (Inner Loop): Raw data from individual sensors is first processed. This might involve calibration routines, noise reduction filters (e.g., Kalman filters), and bias correction. This stage ensures that the data from each sensor is as accurate and reliable as possible.
- Data Fusion and State Estimation (Outer Loop): The cleaned and calibrated data from multiple sensors is then fed into a higher-level state estimation algorithm. This outer loop fuses the information from all sources to create a comprehensive and accurate picture of the drone’s position, velocity, attitude, and environmental context. For example, GPS might provide global position, while the IMU provides high-frequency attitude data. A cascaded fusion algorithm would combine these, with the inner loop handling the high-frequency IMU data and the outer loop integrating this with the lower-frequency but globally accurate GPS data.
Image Processing Pipelines
In applications requiring complex image analysis, such as for mapping or object detection, cascaded processing is often employed.
- Raw Image Capture and Pre-processing (Inner Loop): The camera captures raw image data. This might be followed by immediate pre-processing steps like debayering, noise reduction, and lens distortion correction.
- Feature Extraction and Object Detection (Outer Loop): The pre-processed images are then fed into more complex algorithms. This could involve feature extraction (identifying edges, corners), followed by object detection models (e.g., convolutional neural networks) that identify specific objects within the scene. Each stage can be seen as a “cascade” of processing, building upon the output of the previous one.
The Future of Cascaded Systems in Flight Technology
As flight technology continues to advance, the sophistication and application of cascaded control systems will undoubtedly grow.
Adaptive and Learning Cascades
Future systems may incorporate adaptive or learning elements within their cascaded structures. Instead of fixed control parameters, controllers could learn and adapt to changing environmental conditions, payload variations, or even the aging of components, further enhancing robustness and performance. Machine learning techniques could be employed to optimize the parameters of both inner and outer loops in real-time.
Hierarchical Autonomy
Cascaded control naturally lends itself to hierarchical autonomous systems. A higher-level autonomous agent might set complex goals (e.g., “conduct a survey of this area”), which are then broken down into a series of navigable waypoints and flight plans by an intermediate layer. The lowest level, the cascaded flight control system, then executes these plans with precision. This layered approach allows for increasing levels of autonomy and complexity.
Enhanced Safety and Reliability
The inherent stability and robustness of cascaded systems make them ideal for safety-critical applications. As drones venture into more complex airspace and perform more demanding tasks, the ability of cascaded controllers to react predictably and maintain stable flight under a wide range of conditions will be paramount. Redundant cascaded control systems, where multiple independent loops can take over if one fails, will also become increasingly important.
In conclusion, the term “cascaded” in flight technology signifies a powerful and elegant engineering principle. It describes a layered, hierarchical approach to control and processing that is essential for achieving the high levels of performance, stability, and autonomy demanded by modern drones and other advanced aerial vehicles. From keeping a camera steady to navigating complex environments and integrating sophisticated sensor data, cascaded systems are a cornerstone of the innovation driving the future of flight.