
A “CTF,” or Capture The Flag, when explored through the lens of modern aerospace and robotics, represents an innovative, high-stakes competitive format that pushes the boundaries of drone technology. While traditionally associated with cybersecurity challenges, the concept of a Capture The Flag event has evolved into a compelling paradigm for testing and advancing unmanned aerial vehicle (UAV) capabilities. In this context, a drone CTF is a simulated or real-world scenario where teams of operators, programmers, and engineers leverage sophisticated drone systems to locate, identify, and “capture” designated virtual or physical flags within a specified operational area, often under challenging conditions. These events are not merely about piloting skill; they are rigorous examinations of integrated flight technology, artificial intelligence, sensor fusion, and autonomous decision-making, embodying the cutting edge of tech and innovation in the drone sector.
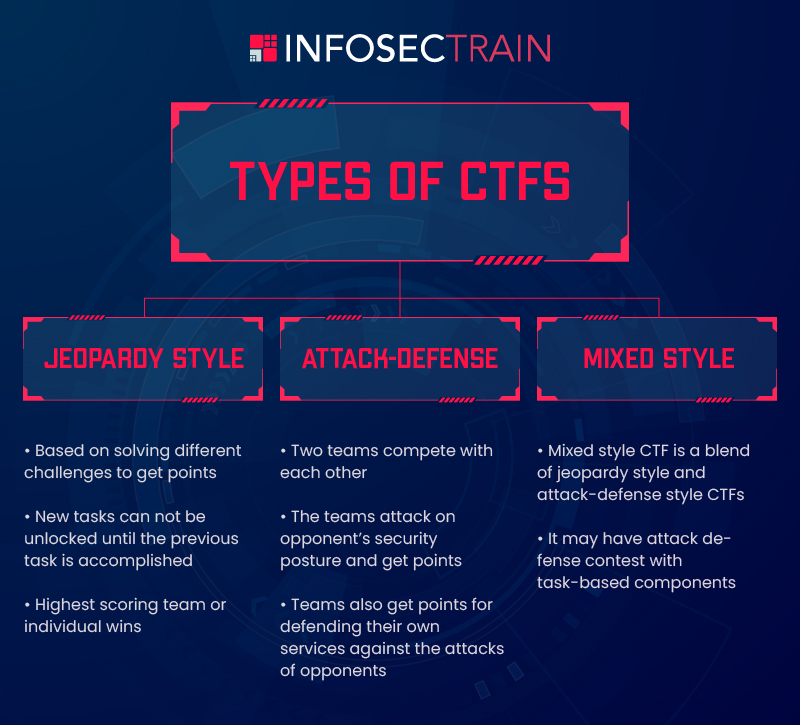
The Concept of Capture The Flag in UAV Operations
At its core, a drone CTF translates the strategic depth of its cybersecurity namesake into a dynamic, three-dimensional challenge. Participants are tasked with deploying their UAVs to achieve specific objectives that emulate real-world complex missions. These objectives often involve locating hidden markers, identifying targets based on specific criteria, navigating through intricate environments, or even establishing temporary control over designated zones. The “flag” itself can be a physical object to be photographed, a virtual beacon broadcasting a signal to be detected, or a data packet to be intercepted from a simulated network node accessible only by drone.
Core Principles and Objectives
The primary objective in a drone CTF is typically to accrue points by successfully “capturing” flags, often within a time limit or against opposing teams. This necessitates a multi-faceted approach involving meticulous mission planning, robust hardware and software integration, and adaptive execution. Key principles include:
- Reconnaissance and Intelligence Gathering: Drones equipped with advanced imaging and sensing capabilities are deployed to scout the operational area, identify potential flag locations, and gather critical data.
- Precision Navigation and Maneuverability: Successful flag capture often requires navigating through complex airspace, avoiding obstacles, and executing precise maneuvers to reach targets in challenging terrains or structures.
- Target Identification and Verification: Utilizing onboard AI and computer vision algorithms, drones must accurately identify the specified flags or targets, differentiating them from decoys or environmental clutter.
- Data Exfiltration/Interaction: Once a flag is located and identified, the drone must securely transmit its findings or perform a specific interaction, such as triggering a sensor or uploading a verification code.
Analogy to Traditional CTFs
The parallels between cybersecurity CTFs and drone CTFs are striking. Just as cybersecurity professionals exploit vulnerabilities or solve cryptographic puzzles, drone teams must overcome technical hurdles in navigation, perception, and communication. Both formats demand problem-solving under pressure, requiring deep technical understanding, strategic thinking, and the ability to adapt to unforeseen challenges. In both domains, the “flag” represents a validated accomplishment that tests participants’ mastery of their respective technologies and methodologies. This competitive framework serves as an accelerator for innovation, pushing the boundaries of what’s possible with current drone technology.
Technological Underpinnings for Drone CTFs
The demanding nature of drone CTFs requires a synthesis of advanced flight technology and intelligent systems. Success hinges on robust, reliable, and intelligent UAV platforms capable of operating semi-autonomously or fully autonomously. The foundational technologies enabling these competitions lie at the heart of modern drone innovation.
Advanced Navigation and GPS Systems
Precise positioning and navigation are paramount. Drones in CTF scenarios rely on highly accurate GPS/GNSS systems, often augmented with Real-Time Kinematic (RTK) or Post-Processed Kinematic (PPK) technology for centimeter-level accuracy, crucial for locating small flags or performing delicate maneuvers. Beyond satellite navigation, inertial measurement units (IMUs), barometers, and magnetometers are fused to provide robust state estimation, allowing drones to maintain stable flight even in GPS-denied environments or areas with signal interference. Visual Inertial Odometry (VIO) and Simultaneous Localization and Mapping (SLAM) algorithms further enhance navigation, enabling drones to build maps of unknown environments while simultaneously tracking their own position within those maps, essential for indoor or complex urban CTF settings.
AI and Computer Vision for Target Recognition
The ability to “see” and “understand” the environment is critical. Drones leverage sophisticated AI-powered computer vision systems to identify flags. This involves:
- Object Detection and Classification: Using deep learning models (e.g., YOLO, Faster R-CNN) trained on vast datasets, drones can rapidly detect specific flag patterns, colors, or shapes in real-time from video feeds or still images.
- Semantic Segmentation: More advanced systems can segment images to understand different regions (e.g., ground, sky, buildings, flag), providing contextual awareness crucial for complex environments.
- Feature Extraction and Matching: Algorithms analyze unique features of objects, allowing drones to identify specific flags even when partially obscured or viewed from different angles. This intelligence allows drones to autonomously confirm a “capture.”
Autonomous Decision-Making and Swarm Intelligence
Many drone CTFs emphasize autonomous capabilities, where the drone itself makes decisions without constant human input. This involves:
- Path Planning and Optimization: Algorithms compute the most efficient and safest flight paths to target flags, considering obstacles, no-fly zones, and energy consumption.
- Tactical Decision Logic: Drones are programmed with rules and heuristics to prioritize targets, choose between reconnaissance and capture phases, and react to dynamic changes in the environment or actions of opposing teams.
- Swarm Intelligence (Multi-Drone Coordination): In more advanced CTFs, multiple drones work collaboratively. Swarm intelligence algorithms allow drones to share information, distribute tasks (e.g., one drone scouts, another captures), and coordinate their movements to cover larger areas or overwhelm defenses more effectively than a single UAV. This represents a significant leap in drone autonomy and operational efficiency.
Challenges and Innovation in Drone CTF Environments
Drone CTFs are designed to be challenging, pushing the limits of current technology and inspiring new innovations. The environments in which these competitions take place often mirror the complexities of real-world operations, demanding resilience, adaptability, and cutting-edge solutions.
Dynamic Obstacle Avoidance and Environmental Adaptation
Unlike controlled test flights, CTF environments are rarely static. They might feature unexpected obstacles, changing weather conditions, or even human interference. Drones must employ sophisticated obstacle avoidance systems utilizing LiDAR, stereo cameras, ultrasonic sensors, and radar to detect and dynamically reroute around hazards in real-time. Environmental adaptation extends to managing varying light conditions, wind gusts, and even electromagnetic interference, requiring robust flight controllers and adaptive control algorithms. Innovation here often leads to more resilient and safer autonomous flight systems for commercial and industrial applications.
Secure Communication and Anti-Jamming Measures
In a competitive or critical operational scenario, maintaining secure and reliable communication between the drone and its ground control station (GCS) is paramount. CTFs often introduce challenges like signal degradation, deliberate jamming attempts, or network congestion. Innovative solutions include:
- Frequency Hopping Spread Spectrum (FHSS): Rapidly switching carrier frequencies to avoid interference and make jamming difficult.
- Encryption Protocols: Ensuring that command and control signals, as well as telemetry data, are encrypted to prevent unauthorized access or manipulation.
- Redundant Communication Channels: Utilizing multiple radio links (e.g., 2.4 GHz, 5.8 GHz, LTE/5G) to provide backup in case one channel fails or is jammed.
- Directional Antennas and Beamforming: Focusing radio energy to improve signal strength and resist interference from specific directions.
These measures contribute directly to the development of more robust and secure drone communication architectures for sensitive missions.
Real-Time Data Processing and Edge Computing
The sheer volume of data generated by a drone’s sensors (high-resolution video, LiDAR scans, telemetry) requires immense processing power. For autonomous decision-making in real-time, this processing cannot always be offloaded to a powerful ground station due to latency constraints. This drives innovation in edge computing, where powerful processors are integrated directly onto the drone. These onboard computers perform complex AI computations, sensor fusion, and decision-making at the source, enabling rapid responses to dynamic situations without relying on constant, low-latency communication with the GCS. This pushes the boundaries of miniaturized computing and efficient algorithm design.
Future Prospects and Applications
Drone CTFs are more than just exciting competitions; they are vital incubators for future drone technology and operational methodologies. The innovations spurred by these demanding challenges have far-reaching implications across various sectors.
Training for Complex Missions
The simulated environments and high-pressure scenarios of CTFs provide invaluable training grounds for drone operators and autonomous systems. They prepare human pilots for unexpected events and help refine the algorithms that guide autonomous drones in complex tasks such as search and rescue, disaster response, infrastructure inspection in hazardous environments, or even future urban air mobility operations. By pushing systems to their limits in a controlled setting, CTFs help identify vulnerabilities and improve operational resilience before deployment in critical real-world missions.

Driving Drone Technology Advancement
The competitive spirit of CTFs acts as a powerful catalyst for innovation. Teams are constantly seeking better sensors, more efficient flight algorithms, smarter AI, and more resilient communication systems to gain an edge. This continuous drive for improvement accelerates the development of:
- More sophisticated autonomous capabilities: Leading to drones that can operate with minimal human intervention in increasingly complex and unpredictable environments.
- Enhanced sensor fusion and perception systems: Improving a drone’s ability to “see,” “understand,” and interact with its surroundings.
- Robust and secure communication protocols: Essential for critical applications where data integrity and control are paramount.
- Miniaturized and powerful onboard computing: Enabling greater intelligence and processing at the edge, fostering more capable and self-reliant UAVs.
Ultimately, a drone CTF is a crucible where raw technological prowess meets strategic ingenuity. It’s an arena where the future of drone capabilities is not just imagined but actively built, tested, and refined, propelling the entire field of tech and innovation forward.