
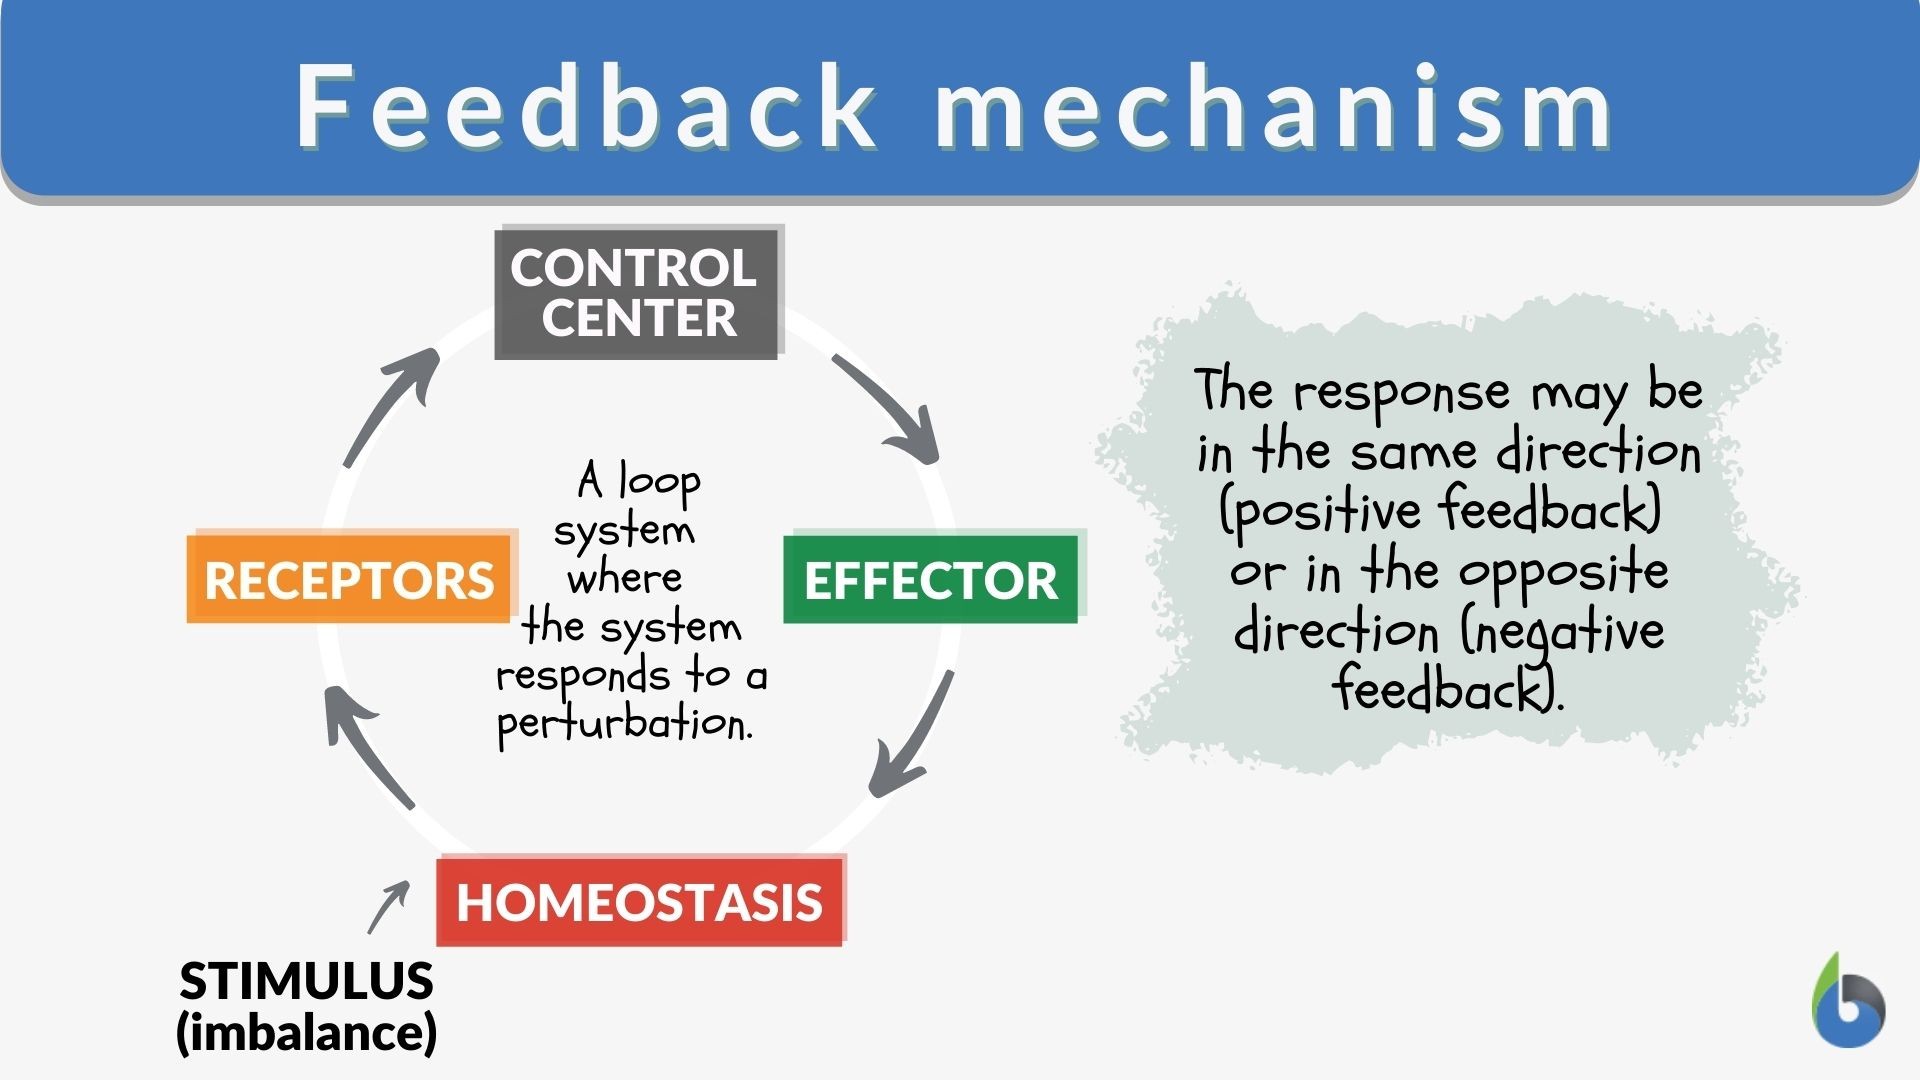
At the heart of every stable drone flight, precise navigation, and sophisticated autonomous maneuver lies a fundamental engineering concept: the feedback mechanism. In the realm of flight technology, a feedback mechanism is an essential system where the output of a process or system is returned as input, allowing for continuous adjustment and correction to achieve a desired state. It is the intelligence that enables a drone to maintain altitude, resist wind gusts, follow a programmed path, or avoid obstacles without constant manual intervention, transforming complex physical dynamics into predictable, controlled flight. Understanding this principle is crucial for comprehending the resilience, accuracy, and evolving capabilities of modern aerial platforms.
The Core Principle of Control
A feedback mechanism operates on a simple yet powerful premise: measure, compare, and correct. In any system designed to achieve a specific outcome, there will inevitably be discrepancies between the desired state (setpoint) and the actual state. A feedback loop continuously monitors the actual state, compares it to the setpoint, calculates the error, and then initiates an action to reduce or eliminate that error. This cyclical process ensures dynamic stability and performance, making it indispensable for technologies operating in fluid, unpredictable environments like the airspace.
Open-Loop vs. Closed-Loop Systems
To fully appreciate the power of feedback, it’s helpful to distinguish between open-loop and closed-loop control systems. An open-loop system operates without any knowledge of its output. It executes a command blindly, assuming that the initial calibration and input will be sufficient to achieve the desired result. For example, an early toy drone might have an open-loop system for motor thrust – a command to increase power by X percentage would always result in X percentage power, regardless of whether the drone actually gained altitude or was battling a downdraft. Such systems are simple but inherently unstable and unreliable in dynamic conditions, lacking the ability to adapt to disturbances or changes in the environment.
In stark contrast, a closed-loop system, also known as a feedback control system, incorporates the output back into the input. This means that the system measures its actual performance, compares it to the target, and then adjusts its control inputs accordingly. If our drone from the previous example had a closed-loop system for altitude, it would constantly measure its actual height, compare it to the target height, and if it deviated, it would adjust motor thrust until the target was met. This continuous monitoring and adjustment is what gives drones their remarkable stability and precision. The vast majority of sophisticated flight technology relies heavily on closed-loop feedback systems for virtually every aspect of control, from maintaining a level attitude to executing complex waypoint navigation.
Feedback in Drone Stabilization
Perhaps the most intuitive application of feedback mechanisms in flight technology is in drone stabilization. A drone, being an inherently unstable platform, would be impossible to fly without constant, rapid adjustments to its motor speeds. These adjustments are driven by a sophisticated feedback loop that works tirelessly to counteract external forces like wind, turbulence, and even small imperfections in the drone’s own construction. The goal is to maintain a desired attitude (roll, pitch, yaw) and position, ensuring a smooth and controlled flight path.
Inertial Measurement Units (IMUs)
The primary sensors feeding information into the stabilization feedback loop are typically housed within the drone’s Inertial Measurement Unit (IMU). An IMU is a composite device containing accelerometers and gyroscopes. Accelerometers measure linear acceleration along three axes (X, Y, Z), providing data on the drone’s movement and tilt relative to gravity. Gyroscopes, on the other hand, measure angular velocity, detecting changes in orientation around the roll, pitch, and yaw axes.
The data from the IMU is continuously sampled at high frequencies (hundreds or thousands of times per second). This raw sensor data is then processed through complex algorithms, often involving sensor fusion techniques like Kalman filters, to estimate the drone’s current attitude and angular rates. This estimated state information represents the “actual output” of the system, which is then fed back to the flight controller.
PID Controllers and Flight Performance
Once the flight controller knows the drone’s current attitude (actual output) and compares it to the pilot’s input or the desired autonomous state (setpoint), it calculates the error. To correct this error and bring the drone back to the desired state, most flight controllers employ a Proportional-Integral-Derivative (PID) controller. The PID controller is a classic feedback loop mechanism renowned for its effectiveness and robustness.
- Proportional (P) component: This part of the controller responds to the current error. The larger the error, the larger the correctional force applied. If a drone is tilted significantly, the P component will immediately command a strong correction.
- Integral (I) component: This component addresses accumulated error over time. It helps to eliminate steady-state errors, ensuring that the drone eventually settles exactly at the desired setpoint rather than constantly having a small, persistent deviation. For instance, if a drone continually drifts slightly due to a minor imbalance, the I component will gradually increase the correctional force until the drift is eliminated.
- Derivative (D) component: This component responds to the rate of change of the error. It acts as a dampener, preventing overshoots and oscillations. If the drone is correcting very rapidly, the D component will apply an opposing force to smooth out the movement and ensure precise, stable settling. Without a D component, a drone might oscillate wildly as it tries to correct an error, constantly overshooting its target.
The output of the PID controller translates directly into commands for the electronic speed controllers (ESCs), which in turn adjust the RPM of each motor. This rapid, continuous feedback loop involving IMUs, flight controller algorithms, and motor adjustments is what gives drones their characteristic stability, agility, and responsiveness, making complex maneuvers possible and ensuring safe operation.
Enhancing Navigation and Autonomy
Beyond basic stabilization, feedback mechanisms are absolutely critical for advanced navigation and autonomous flight capabilities. For a drone to follow a precise flight path, maintain a specific geographical position, or avoid dynamically changing obstacles, it must continuously know its position, velocity, and surroundings, comparing these to its planned trajectory and making real-time adjustments.
GPS and Sensor Fusion
Global Positioning System (GPS) receivers provide crucial feedback for a drone’s horizontal and vertical position. While GPS offers valuable absolute positioning data, it can be slow to update and prone to inaccuracies in urban canyons or under dense foliage. To overcome these limitations, flight technology employs sensor fusion, which combines GPS data with information from other sensors like the IMU, barometers (for altitude), magnetometers (for heading), and even optical flow sensors (for relative ground movement).
The feedback mechanism here involves continuously integrating data from multiple sources to create a more accurate and robust estimate of the drone’s current state (position, velocity, attitude). This fused state estimate is then compared to the desired navigation setpoint (e.g., a specific waypoint or a pre-programmed trajectory). Any deviation triggers the flight controller to adjust motor thrusts and vectoring, guiding the drone back onto its intended course. This closed-loop navigation ensures that even if one sensor momentarily provides poor data, the overall system can still maintain high precision and reliability.
Obstacle Avoidance and Path Planning
Autonomous obstacle avoidance is another sophisticated application of feedback mechanisms. Drones equipped with various ranging sensors – such as LiDAR, ultrasonic sensors, stereo cameras, or radar – constantly scan their environment for potential collisions. Each sensor provides data on the distance and direction of objects. This real-time environmental data serves as critical feedback.
The system continuously compares the drone’s current trajectory with the detected obstacles. If a potential collision is imminent, the feedback mechanism triggers a response. This could involve dynamically altering the flight path to maneuver around the obstacle, adjusting altitude, or even initiating a complete stop or hover. Advanced algorithms for path planning use this environmental feedback to calculate the optimal collision-free route in real-time. The drone then continuously monitors its new path and its relationship to the changing environment, closing the loop to ensure safe navigation even in complex, dynamic spaces. This constant sensing, processing, decision-making, and execution, all informed by feedback, is what enables drones to operate safely in increasingly complex environments.
Future of Flight Technology: Adaptive Feedback
The evolution of flight technology is inexorably linked to increasingly sophisticated feedback mechanisms. As drones become more autonomous, capable of performing complex tasks in unpredictable environments, the feedback loops must become more intelligent, robust, and adaptive. This moves beyond simple PID control to systems that can learn and optimize their own parameters.

Machine Learning and Predictive Control
The integration of machine learning (ML) and artificial intelligence (AI) is transforming feedback mechanisms. Instead of relying solely on pre-programmed control laws, future drone systems will employ adaptive feedback loops that can learn from experience and adjust their control strategies in real-time. For instance, an AI-powered flight controller could learn how a drone responds to different wind conditions over time and proactively adjust its controls even before significant drift occurs, rather than just reacting to it. This involves predictive control, where the system uses models of the drone’s dynamics and its environment to anticipate future states and apply correctional inputs before deviations fully manifest.
Furthermore, machine learning can optimize the gains of PID controllers dynamically, or even entirely replace them with neural network-based controllers that can handle highly non-linear dynamics more effectively. This allows drones to perform more complex and agile maneuvers, adapt to payload changes without manual retuning, and maintain stability even if a propeller is damaged. The feedback mechanism, in this context, extends beyond immediate state correction to encompass continuous learning, adaptation, and optimization of the control strategy itself, pushing the boundaries of what autonomous flight technology can achieve.