
Dropout is a fundamental regularization technique employed in the training of artificial neural networks, a cornerstone of modern artificial intelligence. In the context of drone technology and innovation, where AI models are increasingly vital for autonomous flight, object recognition, navigation, and data analysis, understanding dropout is crucial. It directly addresses a pervasive challenge in machine learning: overfitting, ensuring that the AI systems powering advanced drones are robust, reliable, and capable of generalizing effectively to real-world, unpredictable scenarios.
The Challenge of Overfitting in Advanced Drone AI
Artificial intelligence models, particularly deep neural networks, are trained on vast datasets to learn complex patterns and make predictions or decisions. In the realm of drone technology, this might involve training a model to identify specific objects for inspection, navigate through intricate environments autonomously, or classify land features from aerial imagery. A significant hurdle during this training process is overfitting.
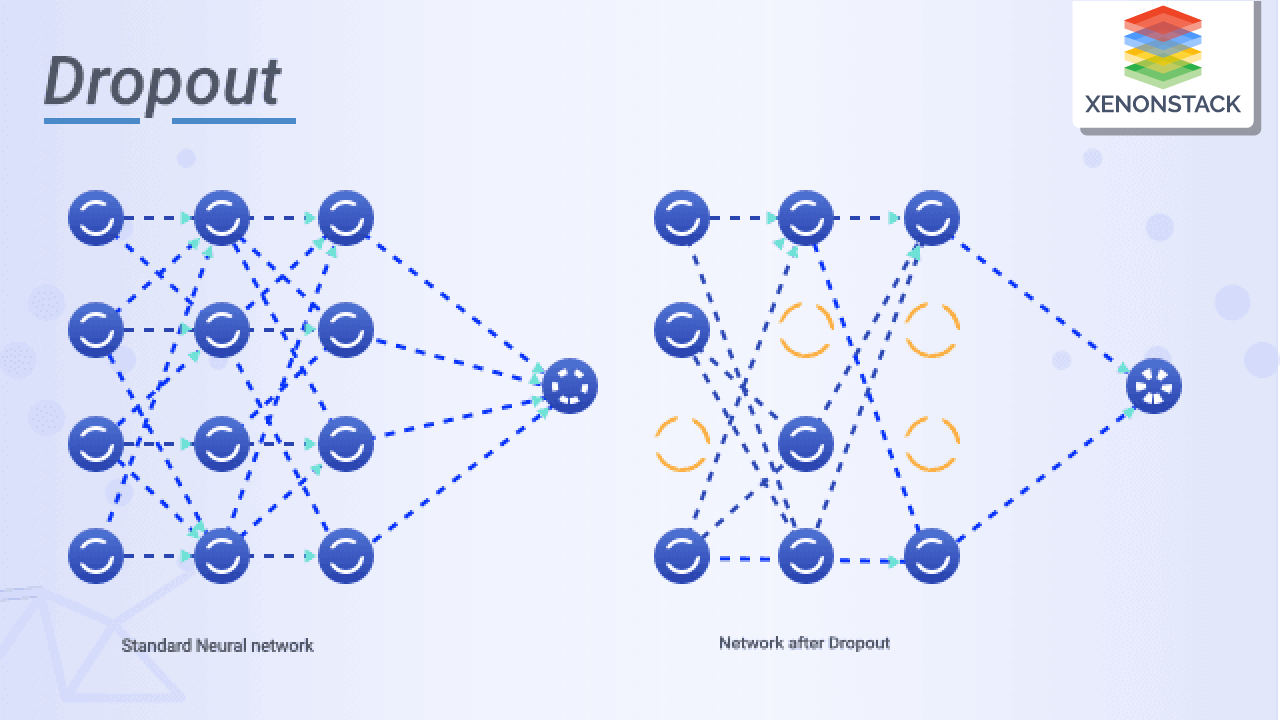
Overfitting occurs when a neural network learns the training data too well, memorizing specific examples and noise rather than capturing the underlying generalizable patterns. While an overfit model performs exceptionally on the data it was trained on, its performance drastically degrades when exposed to new, unseen data—the very data it will encounter in operational drone missions.
Consider a drone’s AI system designed for autonomous obstacle avoidance. If its neural network overfits to the specific obstacles and lighting conditions present in its training environment, it might fail catastrophically when encountering novel obstacles or variations in light and weather during an actual flight. Similarly, an overfit model for agricultural mapping might misclassify crop health when presented with fields exhibiting slightly different characteristics than those in its training set. Such failures compromise the safety, efficiency, and reliability of drone operations, making the prevention of overfitting a paramount concern in the development of robust drone AI.
How Dropout Works: A Mechanism for Robustness
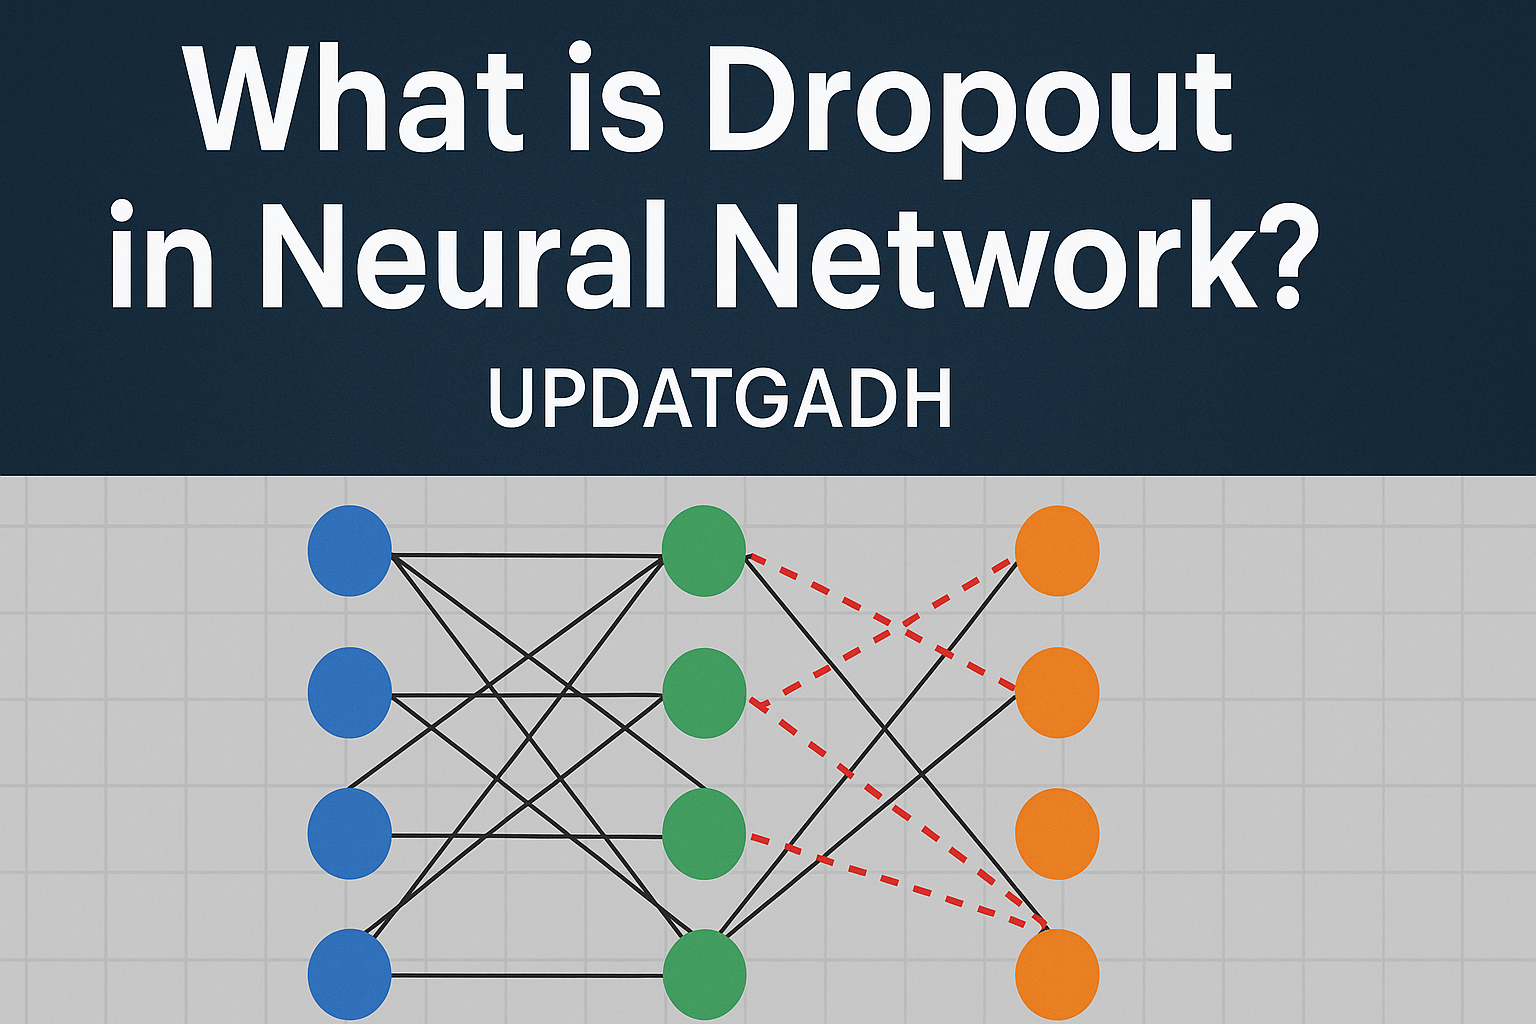
Dropout tackles the problem of overfitting by introducing an element of controlled randomness during the training phase of a neural network. The core idea is remarkably simple yet profoundly effective: during each training iteration, a random subset of neurons (and their connections) within the network is temporarily “dropped out” or deactivated. This means they are not considered during the forward pass (input processing) or the backward pass (gradient calculation) for that particular training step.
Typically, a “dropout rate” (e.g., 0.5 or 50%) is specified, indicating the probability that any given neuron will be dropped. This process is repeated for every training batch, ensuring that a different subset of neurons is dropped at each iteration. Crucially, dropout is only applied during training. During inference (when the trained model is used for real-world predictions, such as guiding a drone), all neurons are active, but their outputs are scaled by the dropout rate to compensate for the higher number of active neurons.
The rationale behind dropout is multi-faceted:
- Ensemble Effect: By randomly dropping neurons, dropout forces the network to learn more robust features that are not reliant on the presence of any single neuron or a small set of neurons. Each iteration can be viewed as training a slightly different “thinned” network. Over many iterations, the network learns to approximate an ensemble of many different, smaller networks, averaging their predictions. This ensemble effect is known to significantly improve generalization.
- Prevents Co-Adaptation: Without dropout, neurons can become overly reliant on specific other neurons. This “co-adaptation” can lead to a fragile network where if one neuron gives a slightly wrong output, others might amplify that error. Dropout prevents this by forcing neurons to learn to function independently and contribute meaningfully, regardless of which other neurons are active. This makes the network less sensitive to minor perturbations or missing information.
- Reduces Complex Dependencies: By regularly interrupting specific pathways, dropout compels the network to find multiple, redundant ways to represent important information. This redundancy makes the network more resilient to noise and variations in input data, which is highly beneficial for the dynamic and often noisy data encountered by drones.
In essence, dropout acts as a sophisticated regularizer, encouraging the neural network to develop a more distributed and less specialized representation of the learned features, thereby fostering greater resilience and generalizability—qualities indispensable for cutting-edge drone applications.
Enhancing Drone Autonomy with Dropout-Regularized AI
The benefits of employing dropout during the training of neural networks translate directly into more capable and reliable AI systems for drones. For sophisticated tasks like autonomous flight, advanced navigation, and real-time environmental analysis, the robustness provided by dropout is transformative.
Enhanced Autonomous Flight and Navigation
Autonomous flight systems rely heavily on neural networks to process sensor data (e.g., LiDAR, cameras, IMUs) and make real-time decisions regarding flight path, altitude, and speed. An AI model trained with dropout is less prone to overfitting to specific flight conditions or sensor noise encountered during training. This means the drone’s navigation system will be more resilient to environmental variations, such as sudden wind gusts, changes in lighting, or partial sensor occlusions. It can generalize better to unseen terrains and dynamic obstacles, leading to safer and more efficient autonomous missions, whether for package delivery, infrastructure inspection, or search and rescue operations.
Superior Object Recognition and Obstacle Avoidance
Drone vision systems are crucial for object detection, tracking, and obstacle avoidance. Neural networks, particularly convolutional neural networks (CNNs), are at the heart of these capabilities. When trained with dropout, these CNNs develop a more robust understanding of various objects and potential hazards. They are less likely to misclassify an object due to minor variations in appearance, angle, or lighting that weren’t explicitly present in the training set. This significantly improves the accuracy of identifying power lines, trees, buildings, or even other moving aircraft, enhancing the drone’s ability to navigate complex environments safely and perform precise tasks like automated inspections or precision agriculture applications.
Reliable Data Analysis for Mapping and Remote Sensing
Drones are invaluable platforms for collecting vast amounts of data for mapping, remote sensing, and environmental monitoring. Analyzing this data often involves using neural networks for tasks such as land cover classification, agricultural health assessment, or change detection. Models trained with dropout exhibit superior generalization capabilities, which means they can accurately interpret data collected from diverse geographical regions, varying seasons, or under different sensor configurations. This leads to more reliable and consistent insights, ensuring that environmental scientists, urban planners, or agricultural experts receive actionable intelligence that isn’t biased by the specifics of the training data. For example, a dropout-regularized model can more accurately distinguish between different crop types or identify signs of disease across a wide range of fields, regardless of subtle differences in image acquisition.
Implementing Dropout: Considerations for Drone Developers
Integrating dropout effectively into the AI development pipeline for drones requires careful consideration and understanding of best practices. While the concept is straightforward, its optimal application can significantly impact the performance and reliability of drone AI systems.
Choosing the Right Dropout Rate
The dropout rate, typically between 0.2 and 0.5 (20% to 50%), is a hyperparameter that needs to be tuned. A rate that is too low might not provide sufficient regularization, while a rate that is too high could lead to underfitting, where the network doesn’t learn enough relevant features. The optimal rate often depends on the specific network architecture, the complexity of the task, and the size of the training dataset. For convolutional layers in vision tasks, a lower dropout rate (e.g., 0.2-0.3) is often preferred, while fully connected layers can sometimes benefit from higher rates (e.g., 0.5). Experimentation and validation on a diverse dataset representing real-world drone operational conditions are key to finding the sweet spot.
Placement of Dropout Layers
Dropout layers are typically inserted between hidden layers, particularly fully connected layers, within a neural network. For convolutional neural networks (CNNs) used extensively in drone vision systems, dropout is often applied after convolutional layers and before or after pooling layers, or within the fully connected layers that follow the feature extraction stage. Strategic placement ensures that the regularization effect targets the most susceptible parts of the network to overfitting, often the denser layers with a high number of parameters. Care must be taken not to apply dropout too early in the network, as it might impede the initial feature extraction process, which is crucial for vision-based tasks.

Combining with Other Regularization Techniques
Dropout is a powerful technique, but it can often be combined effectively with other regularization methods to achieve even greater robustness. Techniques such as L1/L2 regularization (weight decay), batch normalization, and data augmentation are complementary. For drone applications, data augmentation—generating diverse training examples by rotating, scaling, cropping, or adding noise to original images—is particularly valuable as it directly simulates variations encountered in real-world flight conditions. When combined, these techniques collectively enhance the model’s ability to generalize, making drone AI systems exceptionally robust and reliable across a wide spectrum of operational challenges. Developers must meticulously validate the combined effects of these techniques to ensure optimal performance without introducing new complexities or hindering convergence during training.