
In the vast and rapidly evolving landscape of Tech & Innovation, particularly concerning advanced autonomous systems like drones, underlying mathematical principles form the bedrock of functionality and reliability. Among these fundamental concepts, the associative property of multiplication might seem like a basic arithmetic rule taught in early education. However, its profound implications extend far beyond simple numbers, influencing the very design, efficiency, and robustness of complex algorithms that power cutting-time drone technologies, from precise navigation to intelligent autonomous decision-making.
The Core Concept: Flexibility in Computation
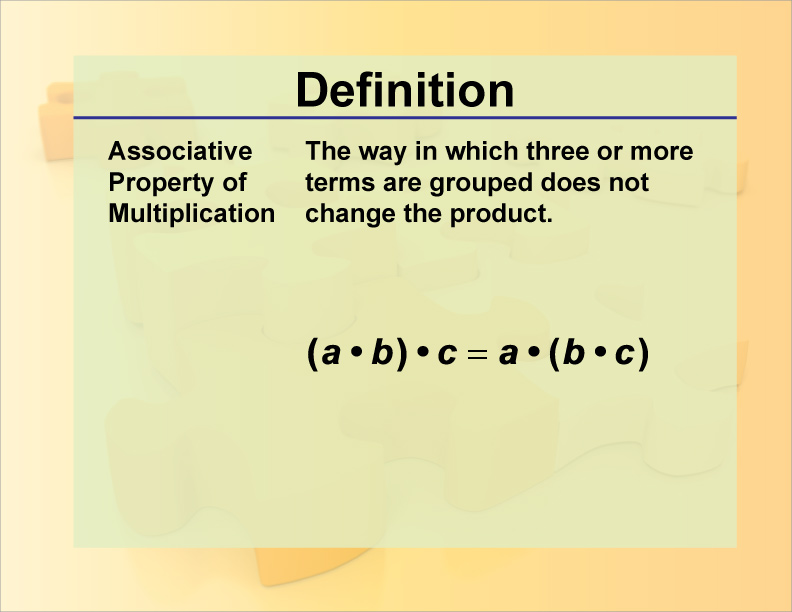
At its heart, the associative property of multiplication states that the way in which numbers (or elements in a more abstract system) are grouped in a multiplication operation does not affect the final product. Expressed mathematically, for any three numbers a, b, and c, the property holds true: (a × b) × c = a × (b × c). This seemingly simple rule provides immense flexibility, allowing calculations to be ordered in different sequences without altering the ultimate outcome.
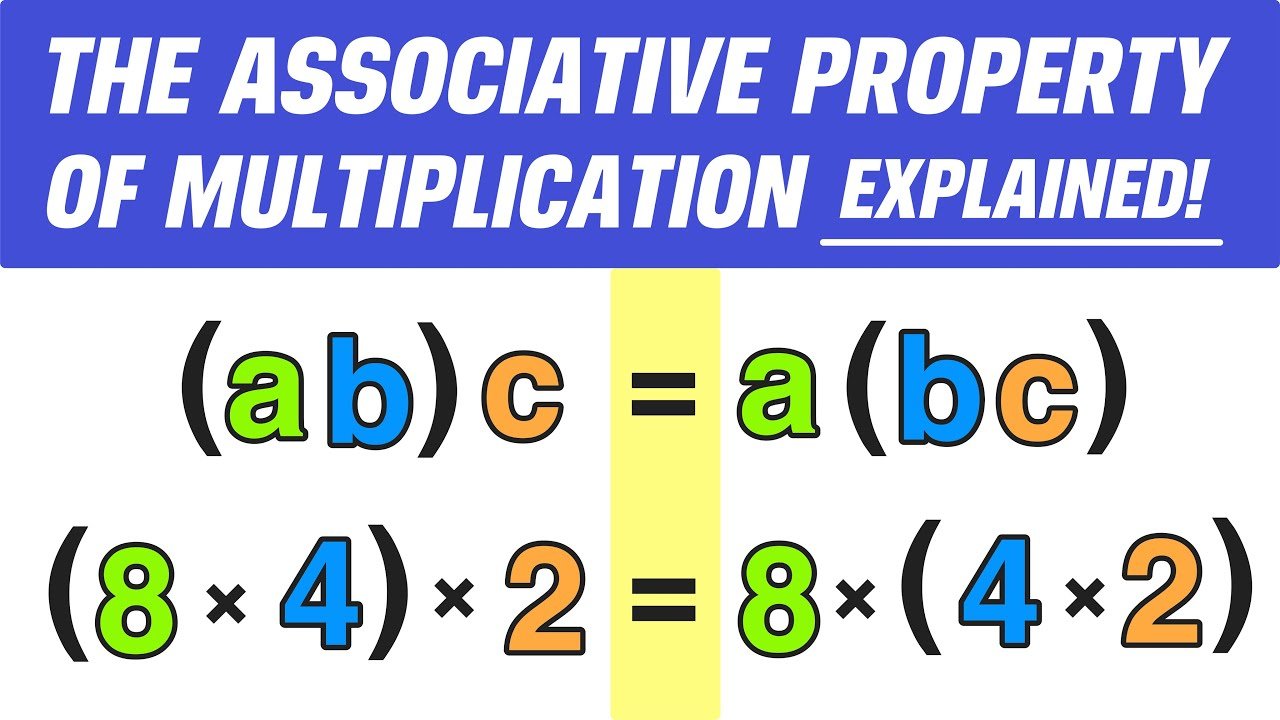
For instance, consider the multiplication of 2 × 3 × 4. If we group the first two numbers, we get (2 × 3) × 4 = 6 × 4 = 24. If we group the last two, we get 2 × (3 × 4) = 2 × 12 = 24. The result remains identical. While straightforward with scalar numbers, this property gains significant importance when applied to more complex mathematical structures such as matrices, which are ubiquitous in the computational core of modern technological innovations. In the domain of Tech & Innovation, particularly where real-time processing and intricate data manipulations are essential, understanding and leveraging this property is crucial for designing efficient and predictable systems.
Associativity in Advanced Algorithm Design for Autonomous Systems
The leap from basic arithmetic to sophisticated autonomous systems like drones is mediated by advanced algorithms that translate real-world dynamics into computable operations. Here, the associative property of multiplication plays an often-invisible, yet critical, role, especially in the realms of matrix operations and sensor data fusion.
Matrix Operations and Transformations
Modern drone technology relies heavily on understanding and manipulating objects and the drone itself within a three-dimensional space. This is achieved through linear algebra, where mathematical entities called matrices are used to represent everything from the drone’s orientation and position to camera perspectives and object locations. Matrix multiplication is the primary operation for performing transformations such as rotation, scaling, and translation in 3D space.
For example, when a drone performs a series of maneuvers, its orientation changes through a sequence of rotations. If we denote successive rotation matrices as R1, R2, and R3, the final orientation can be calculated by applying these transformations to an initial vector representing the drone’s pose. The associative property of matrix multiplication dictates that (R1 × R2) × R3 = R1 × (R2 × R3). This means that whether the drone’s onboard flight controller first calculates the combined effect of R1 and R2, and then applies R3, or first computes the combined effect of R2 and R3, and then applies R1, the ultimate orientation will be the same. This flexibility is vital for:
- Predictable Flight Paths: Ensuring that complex flight trajectories involving multiple turns and attitude adjustments maintain their intended path regardless of how the sequence of transformations is grouped in the control algorithm.
- Accurate Object Tracking: When a drone tracks a moving object, its internal model constantly updates the object’s position relative to its own. Chained transformations accurately predict the object’s projected location on the camera sensor or in the drone’s environment map.
- Gimbal Stabilization: For aerial filmmaking, the camera’s gimbal system performs rapid, precise rotations to counteract drone movement. The associative property ensures that the sequence of stabilization rotations, when multiplied, achieves the desired steady shot without unintended compounding errors based on calculation order.
This inherent consistency guaranteed by associativity allows engineers to design robust control systems where the order of intermediate matrix computations can be optimized for performance without sacrificing accuracy or introducing errors that could destabilize the drone.
Sensor Fusion and Real-time Data Processing
Drones are equipped with an array of sensors—Inertial Measurement Units (IMUs), GPS, LiDAR, optical cameras, and more—each providing a stream of data about the drone’s state and its environment. To make sense of this deluge of information, drones employ sophisticated sensor fusion algorithms, such as Kalman filters or particle filters, to combine these diverse inputs into a single, more accurate estimate of the drone’s position, velocity, and orientation.
Many of these fusion algorithms rely on iterative updates that involve matrix multiplications. For instance, in a Kalman filter, a prediction step is followed by an update step, both of which involve matrix operations to propagate state estimates and manage uncertainty. The associative property ensures that as new sensor data streams in, and subsequent correction matrices are applied, the way these matrices are grouped in the ongoing calculation does not affect the final, filtered state estimate.
This is critical for:
- Robust State Estimation: Guaranteeing that the drone’s internal model of its own state (where it is, how fast it’s moving, its orientation) remains consistent and accurate, regardless of the specific computational sequence chosen for processing different sensor inputs or applying correction factors.
- Adaptive Processing: Allowing developers the flexibility to structure their sensor fusion pipelines, potentially processing certain sensor data in parallel or in different sub-groups, knowing that the associative property will preserve the correctness of the final, aggregated estimate. This adaptability is key for managing computational load in real-time.
- Error Propagation: Understanding how errors accumulate and propagate through a system often involves matrix calculus. The associative property ensures that the fundamental structure of these error models remains consistent, regardless of computational grouping, which is essential for predicting system behavior under various conditions.
Optimizing Performance and Resource Management in Drone Computing
In embedded systems like those found in drones, computational power, memory, and energy are finite resources. Every millisecond counts, especially for real-time applications like obstacle avoidance or autonomous navigation. The associative property of multiplication offers opportunities for significant optimization in algorithm design and hardware utilization.
Parallel Processing and Computational Efficiency
Complex drone operations often involve massive numbers of calculations. For example, simultaneously localizing the drone within an unknown environment and mapping that environment (SLAM) requires continuous processing of sensor data and frequent matrix operations. Modern drone processors, often system-on-chips (SoCs), frequently incorporate multiple CPU cores, GPUs, and specialized accelerators to handle this workload.
The associative property can be leveraged to restructure computations for parallel execution. If a series of matrix multiplications (A × B × C × D) needs to be performed, an associative property allows us to compute (A × B) and (C × D) simultaneously on different processing units, then multiply their results. This parallelization dramatically reduces the overall computation time, which is paramount for real-time decision-making in fast-moving autonomous drones. This enables features like:
- Faster Obstacle Avoidance: Quicker computation of potential collision paths and evasive maneuvers, enhancing safety.
- Higher Frame Rates for Vision Processing: Essential for AI-powered object recognition, tracking, and cinematic aerial photography.
- Extended Flight Times: By optimizing computation, the processor spends less time at peak load, reducing energy consumption and extending battery life.
Algorithm Reliability and Predictability
For safety-critical applications like autonomous aerial delivery or passenger transport (in the future), the reliability and predictability of software are non-negotiable. Algorithms must consistently produce the correct output under all specified conditions. The associative property is a mathematical guarantee that helps uphold this.
It ensures that variations in how a drone’s control software groups its calculations—perhaps due to different compiler optimizations, hardware architectures, or dynamic runtime scheduling—will not lead to divergent or incorrect results. This consistency is fundamental for:
- Software Verification and Validation: Simplifies the testing process by reducing the number of permutations that need to be explicitly checked for correctness.
- Regulatory Compliance: Provides a mathematical basis for ensuring that core computational routines behave predictably, contributing to the drone’s overall safety certification.
- Debugging: When errors occur, understanding that the grouping of multiplications doesn’t change the outcome can help isolate where a computational flaw might truly lie, rather than chasing phantom inconsistencies introduced by arbitrary calculation order.
Future Innovations and the Enduring Relevance of Associativity
As the realm of Tech & Innovation continues to push boundaries, particularly in drone capabilities, fundamental mathematical properties like associativity will retain their critical importance, underpinning new paradigms and advanced functionalities.
AI, Machine Learning, and Neural Networks
The explosion of artificial intelligence and machine learning in drone technology—powering features like AI follow mode, autonomous navigation, and intelligent payload delivery—is deeply rooted in linear algebra. Neural networks, for instance, perform vast numbers of matrix multiplications during both their training phase and inference (when making real-time decisions). The efficiency and stability of these computations are implicitly reliant on the associative property. Optimizing these matrix operations, often through specialized hardware like AI accelerators, leverages this property to achieve faster processing and more robust model performance. This directly translates to more intelligent, responsive, and reliable autonomous drone operations.

Quantum Computing and Advanced Mathematical Models
Looking further into the future, the advent of quantum computing holds transformative potential for drones, enabling computational power far beyond today’s classical machines for tasks like complex route optimization or real-time atmospheric modeling. Even in this nascent field, where operations are based on unitary transformations of quantum states (represented by matrices), the associative property will remain a cornerstone. It will continue to define how sequences of quantum gates or operations can be combined and optimized, influencing the design of quantum algorithms that could power the next generation of ultra-intelligent, hyper-efficient drones.
In conclusion, while the associative property of multiplication may appear to be a simple arithmetic rule, its implications are profoundly impactful within the sophisticated world of Tech & Innovation, particularly in the realm of drone technology. From ensuring the predictable flight of an autonomous drone through complex matrix transformations to optimizing real-time sensor fusion and paving the way for future AI and quantum computing advancements, this fundamental mathematical principle quietly underpins the very capabilities that define and propel modern drone innovation.