
The Address Resolution Protocol (ARP) table, while seemingly a low-level networking detail, forms a critical invisible layer in the communication architecture that underpins modern drone technology. In an era where autonomous flight, sophisticated data collection, and real-time command and control are paramount, understanding how devices locate each other on a local network is fundamental. For drones, especially those engaged in complex operations involving ground control stations, sensor data transfer, or even multi-UAV swarm intelligence, the ARP table is the unsung hero that enables seamless IP-based communication, ensuring that packets reach their intended hardware destination.
The Unseen Protocol Enabling Drone Connectivity
At its core, the internet protocol (IP) suite orchestrates communication across global networks. However, IP addresses, which are logical addresses, need a mechanism to map to the physical hardware addresses of devices on a local network segment. This is precisely the function of the ARP table, which maintains a dynamic registry of these IP-to-MAC address mappings. Without it, even the most sophisticated drone, equipped with cutting-edge sensors and AI, would be a disconnected island unable to receive commands or transmit vital telemetry data over a standard local area network (LAN).

Bridging IP and Hardware Addresses in UAV Networks
Every device capable of connecting to a network — be it a ground control station (GCS), a drone’s onboard computer, a network-attached storage device for collected data, or a local Wi-Fi router used for drone communication — possesses a unique Media Access Control (MAC) address. This MAC address is a permanent hardware identifier, typically burned into the network interface card (NIC) by the manufacturer. Conversely, an IP address is a logical address assigned to a device within a network, which can be static or dynamically assigned.
For a GCS to send an IP packet (e.g., a flight command or mission update) to a drone on the same local network, it doesn’t just need the drone’s IP address; it ultimately needs the drone’s MAC address to physically deliver the data frame to the correct network interface. The ARP table acts as the essential bridge between these two distinct addressing schemes. It allows the GCS to translate the drone’s known IP address into its unknown MAC address, making direct local communication possible.
The Fundamental Role in Data Exchange
Consider a drone performing an aerial survey, collecting high-resolution imagery or LiDAR data. This data, once processed or buffered onboard, often needs to be transferred to a local server or a ground station for further analysis. If this transfer occurs over a local IP-based network link (e.g., Wi-Fi or a dedicated mesh network), the ARP table on both the drone and the receiving station ensures that data packets are correctly addressed at the hardware level. The ability to efficiently and reliably exchange such large volumes of critical data is paramount for applications like precision agriculture, infrastructure inspection, and environmental monitoring, all of which rely heavily on robust network communication facilitated by ARP.
Mechanics of ARP Resolution in Ground Control Systems
The operational efficiency and responsiveness of drone systems are directly tied to the underlying network’s ability to quickly resolve addresses. For a ground control system, rapid and accurate communication with its fleet is non-negotiable, particularly in dynamic or time-sensitive missions. The ARP process, while seemingly simple, is executed millions of times daily in busy networks, providing the necessary mappings for every IP packet that traverses a local segment.
How Ground Stations Locate Drones on a Local Network
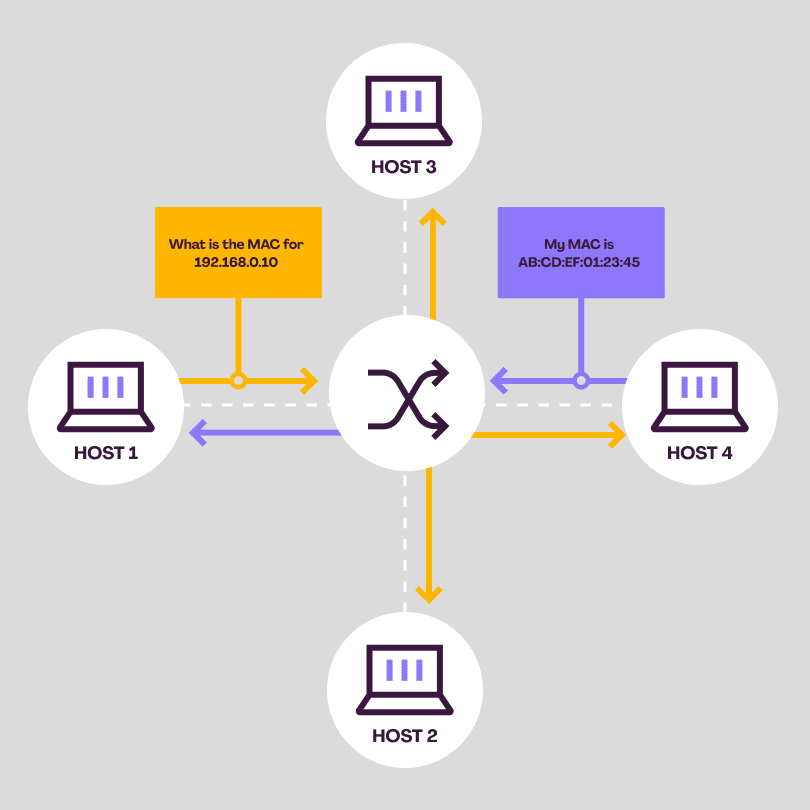
When a GCS needs to communicate with a drone for the first time on a local network, and it only knows the drone’s IP address, it performs an ARP request. This request is broadcast across the local network segment, asking, “Who has this IP address? Please tell me your MAC address.” Every device on that segment receives the broadcast, but only the drone with the matching IP address will respond with an ARP reply containing its MAC address.
Upon receiving the reply, the GCS caches this IP-to-MAC mapping in its own ARP table. Subsequent packets destined for that drone can then be encapsulated with the correct MAC address, allowing for direct and efficient communication without the need for another broadcast. This process is critical for maintaining consistent control links and ensuring the timely delivery of commands, telemetry, and critical alerts between the GCS and the drone. For drones operating in environments with intermittent connectivity or dynamic network topologies, the speed and reliability of ARP resolution directly impact mission success.
Dynamic Mapping for Agile Operations
The dynamic nature of ARP tables is a significant advantage for agile drone operations. Unlike static configurations, ARP entries have a lifespan (a “Time-To-Live” or TTL). This ensures that if a drone’s IP address changes (e.g., due to DHCP lease renewal or manual reconfiguration) or if a drone powers off and on again with a different IP (less common but possible in certain setups), the outdated entry in the GCS’s ARP table will eventually expire. When the GCS next tries to communicate, it will issue a new ARP request, resolving the new mapping. This self-healing aspect is crucial for maintaining network integrity and flexibility, especially in scenarios where drones might join or leave a network segment frequently, such as in field operations or multi-drone deployments.
ARP’s Impact on Advanced Drone Operations
As drone technology evolves, moving towards greater autonomy and swarm intelligence, the reliability and security of their communication networks become even more critical. ARP, as a foundational protocol, inherently influences these advanced operational paradigms, particularly in how multiple drones interact and how their network integrity is maintained.
Facilitating Multi-Drone Swarm Communication
In multi-drone swarm operations, individual UAVs might need to communicate directly with each other or with a central coordinating drone or ground station within a local network. This peer-to-peer or peer-to-coordinator communication relies heavily on the efficient resolution of IP-to-MAC addresses. For instance, if drones in a swarm are collaboratively mapping an area, they might exchange real-time positional data or sensor readings to optimize coverage and avoid collisions. Each such data exchange, if IP-based and local, would leverage ARP to correctly identify the hardware destination of the data packet. The speed and accuracy of ARP resolution directly contribute to the responsiveness and coherence of the swarm’s collective intelligence and movement patterns, which are cornerstones of “Tech & Innovation” in autonomous systems.
Securing the Network Edge for Autonomous UAVs
While essential, ARP is inherently vulnerable to certain types of attacks, most notably ARP spoofing or ARP poisoning. In an ARP spoofing attack, a malicious actor sends falsified ARP replies across the local network, associating their own MAC address with the IP address of a legitimate drone or GCS. If successful, this can redirect network traffic through the attacker’s device, allowing them to intercept, modify, or drop command and control packets, telemetry data, or sensitive sensor information. For autonomous UAVs, such an attack could have catastrophic consequences, ranging from loss of control and data breaches to physical damage or mission failure.
Innovations in drone network security, therefore, must consider these foundational vulnerabilities. Strategies include:
- Static ARP entries: For critical devices like GCS and specific drones, static ARP entries can be configured, preventing dynamic updates and thus mitigating spoofing.
- ARP inspection: Network switches can be configured to validate ARP packets against DHCP snooping tables, dropping any unauthorized ARP replies.
- Encrypted communication: While ARP itself is not encrypted, securing the data payload with protocols like TLS/SSL over IP can protect the content, even if the underlying ARP exchange is compromised.
- Network segmentation: Isolating drone communication on dedicated, controlled network segments can limit the blast radius of an ARP attack.
These measures are vital for ensuring the robustness and trustworthiness of drone systems, especially as they undertake more critical and sensitive missions.
Future Implications for Drone Network Innovation
As drone technology continues its rapid advancement, the underlying communication infrastructure must evolve in tandem. The future of networked drone systems will likely see increasingly sophisticated architectures, where ARP’s role, while remaining fundamental, will be augmented and managed by advanced protocols and paradigms.
Resilient Communication Architectures
Future drone operations, particularly those involving large-scale swarms, urban air mobility (UAM), or beyond visual line of sight (BVLOS) flights, will demand highly resilient and adaptive communication networks. This includes not just redundant physical links but also intelligent network management that can dynamically reconfigure routes and identify trustworthy communication paths. While ARP handles local resolution, its robustness will be critical for the stability of higher-level routing protocols and mesh networking solutions that enable drones to operate autonomously in complex and contested environments. Innovations in self-healing networks for drones will implicitly rely on reliable underlying address resolution to rebuild connections quickly after disruptions.
Integration with Software-Defined Networking (SDN) for UAVs
Software-Defined Networking (SDN) represents a paradigm shift in network management, separating the network’s control plane from its data plane. For drone networks, SDN could offer unprecedented flexibility and granular control over communication paths, bandwidth allocation, and security policies. In an SDN-enabled drone network, the ARP function might still exist at the data plane, but its behavior (e.g., what to do with an unresolvable address, how to handle suspicious ARP activity) could be centrally orchestrated by an SDN controller. This allows for dynamic security policies, efficient resource allocation for data-intensive tasks like real-time video streaming, and rapid adaptation to changing operational needs of a drone fleet, pushing the boundaries of autonomous network management.

Edge Computing and Onboard ARP Management
With the increasing computational power of onboard drone processors, there’s a growing trend towards edge computing, where data processing occurs closer to the source (the drone itself). This can reduce latency and bandwidth requirements for data transfer to ground stations. In such scenarios, drones might manage more sophisticated local area networks among themselves or with nearby mobile ground units. Onboard ARP management, perhaps enhanced with machine learning to detect anomalous ARP behavior or optimize resolution for specific mission profiles, could become a feature. This would ensure that even at the network edge, the foundational elements of communication are highly efficient, secure, and resilient, truly embodying the spirit of “Tech & Innovation” in advanced UAV systems.