
In the dynamic world of drone technology, precision, stability, and autonomy are not just desirable features; they are fundamental requirements. Achieving these feats relies heavily on the ability of a drone to accurately know its own state—its position, velocity, orientation, and even its angular rates—at any given moment. However, directly measuring all these parameters perfectly is an impossible task due to sensor noise, latency, and environmental ambiguities. This is where estimators come into play, serving as the unsung heroes of modern flight technology.
The Indispensable Role of Estimators in Drone Flight
Imagine a drone soaring through the sky. It’s constantly bombarded with data from a multitude of sensors: GPS satellites provide approximate location, accelerometers measure linear forces, gyroscopes detect angular rates, magnetometers sense magnetic North, and barometers track altitude. Each of these sensors, while valuable, has inherent limitations. GPS signals can drift or be lost entirely, accelerometers are affected by gravity and vibrations, gyroscopes accumulate drift over time, and magnetometers are susceptible to electromagnetic interference. Relying on any single sensor alone would lead to an unstable, inaccurate, and potentially dangerous flight.
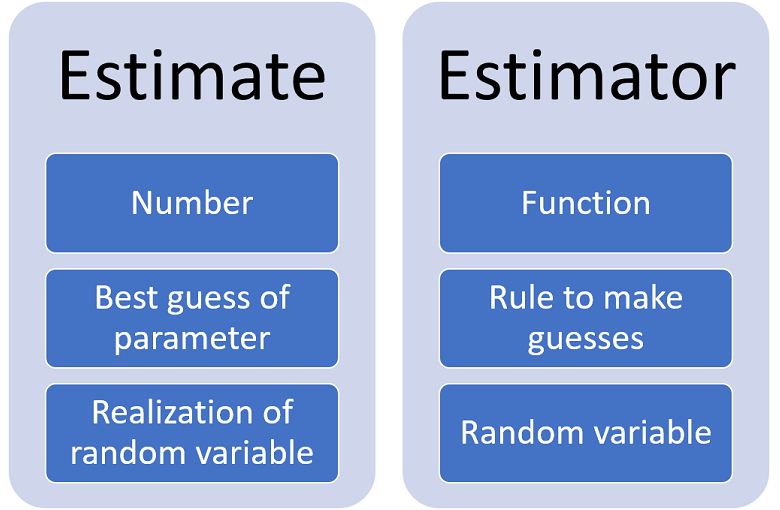
This is precisely the challenge estimators address. An estimator is essentially a sophisticated algorithm or mathematical model designed to process imperfect and often contradictory sensor data to produce the best possible “guess” or estimation of a system’s true state. It doesn’t just average the readings; instead, it intelligently combines data, weights different sources based on their reliability, and often predicts future states based on a dynamic model of the drone’s movement. By continuously refining its understanding of the drone’s position, velocity, and attitude, estimators bridge the gap between noisy sensor inputs and the precise, real-time information critical for stable flight, navigation, and complex autonomous operations. Without estimators, the smooth, controlled flight we associate with modern UAVs would be impossible.
Core Principles: How Estimators Work
The magic of estimators lies in their ability to synthesize information, manage uncertainty, and adapt to changing conditions. At their heart, they follow a cyclical process of prediction and correction, constantly refining their understanding of the drone’s state.
Sensor Fusion: Combining Disparate Data
A modern drone is a symphony of sensors, each providing a piece of the puzzle about the drone’s current situation. GPS offers global positioning, but often with limited accuracy and update rates. An Inertial Measurement Unit (IMU), comprising accelerometers and gyroscopes, provides high-frequency data about changes in motion and orientation, but is prone to drift. Magnetometers offer heading information, while barometers provide altitude relative to atmospheric pressure. Vision sensors (cameras) can aid in relative positioning and obstacle detection.
Sensor fusion is the process by which an estimator intelligently combines these disparate data streams. Instead of treating each sensor in isolation, the estimator integrates their outputs, leveraging the strengths of one sensor to compensate for the weaknesses of another. For instance, a gyroscope’s high-frequency data can provide immediate attitude changes, while a magnetometer or accelerometer can periodically correct the gyroscope’s drift, ensuring a stable long-term orientation estimate. This synergistic approach yields a more robust and accurate overall state estimate than any single sensor could provide.
State Estimation: Predicting the Unseen
The “state” of a drone refers to a complete set of variables that describe its current condition. This typically includes its 3D position (e.g., latitude, longitude, altitude), 3D velocity, 3D orientation (roll, pitch, yaw), and 3D angular rates. Many of these variables cannot be directly measured with perfect accuracy, or sometimes at all.
Estimators work on a principle of a prediction-correction cycle. First, based on a dynamic model of the drone (how it moves in response to commands and physics) and its previous estimated state, the estimator predicts the drone’s new state. This prediction is inherently uncertain. Then, when new sensor measurements arrive, the estimator corrects its prediction. It compares the predicted sensor readings (based on the predicted state) with the actual sensor readings. The difference between these, weighted by the certainty of both the prediction and the measurements, is used to update and refine the state estimate. This iterative process allows the estimator to continuously converge on the most probable true state of the drone.
Dealing with Uncertainty and Noise
All sensor measurements are inherently noisy and uncertain. A GPS reading might be off by a few meters, an accelerometer might pick up vibrations, and a gyroscope might drift. A crucial aspect of robust estimation is not just to provide an estimate, but also to quantify the uncertainty of that estimate.
Advanced estimators maintain a statistical model of uncertainty, often represented by a covariance matrix. This matrix indicates how much each state variable (position, velocity, etc.) might deviate from the estimated value and how these uncertainties are correlated. When new sensor data arrives, the estimator considers both the measurement noise of the sensor and the uncertainty of its own current estimate. It then calculates a new, more refined estimate along with a reduced uncertainty, reflecting the added information from the new measurement. This rigorous mathematical framework allows estimators to make optimal use of noisy data, providing not just a best guess, but also a quantifiable confidence level in that guess, which is vital for safe and reliable autonomous operation.
Key Estimator Algorithms in Drone Technology
A variety of algorithms have been developed for state estimation, each with its own strengths and ideal applications. For drones, certain filters have become foundational due to their robustness, computational efficiency, and accuracy.
Kalman Filters: The Workhorse of Navigation
The Kalman Filter (KF) is arguably the most widely used and celebrated estimator in navigation and control systems, including drones. It is an optimal recursive data processing algorithm that provides an efficient computational means to estimate the state of a system from a series of incomplete and noisy measurements.

- Extended Kalman Filter (EKF): While the original Kalman filter is designed for linear systems, most drone dynamics are non-linear. The EKF addresses this by linearizing the system’s dynamics and observation models around the current state estimate. It’s extensively used in drones for estimating position, velocity, and attitude by fusing IMU data with GPS, barometers, and magnetometers.
- Unscented Kalman Filter (UKF): An advancement over the EKF, the UKF handles non-linearities more effectively without explicit linearization. Instead of linearizing, it uses a deterministic sampling technique (sigma points) to capture the true mean and covariance of the state distribution more accurately after propagation through the non-linear system. This often results in more robust and accurate estimates, especially for highly non-linear dynamics, albeit with a slightly higher computational cost than the EKF.
Particle Filters: For Non-Gaussian, Non-Linear Systems
Particle filters, also known as Sequential Monte Carlo methods, are a class of algorithms that can estimate the state of non-linear and non-Gaussian systems. Instead of approximating the state distribution with a single Gaussian (as Kalman filters do), particle filters represent the probability distribution of the state using a set of “particles,” each representing a possible state with an associated weight.
While generally more computationally intensive than Kalman filters, particle filters excel in situations where the drone’s state distribution is highly complex or multi-modal (e.g., when a drone might be in one of several possible locations with equal probability). They find applications in complex perception tasks like robust object tracking in cluttered environments or localization in highly ambiguous sensor-denied areas, though less commonly for primary flight state estimation due to their computational overhead for high-dimensional states.
Complementary Filters: Simplicity and Efficiency
For many smaller drones or hobbyist platforms, computational resources can be a limiting factor. Complementary filters offer a computationally efficient and simple alternative for attitude estimation, particularly when fusing gyroscope and accelerometer data.
A complementary filter works by taking advantage of the complementary nature of different sensors. Gyroscopes provide accurate short-term angular velocity measurements but suffer from long-term drift. Accelerometers, on the other hand, provide a stable long-term reference for gravity (and thus pitch and roll) but are noisy and susceptible to linear accelerations. The complementary filter combines these by high-passing the gyroscope data (to get fast changes) and low-passing the accelerometer data (to get slow, stable corrections), then summing them. This provides a clean, stable attitude estimate. While simpler and faster than Kalman filters, they do not provide an explicit measure of uncertainty and are less robust to certain disturbances, making them suitable for less demanding applications.
Practical Applications in Drone Flight Technology
Estimators are the invisible force enabling a drone’s core functionalities, translating raw sensor data into actionable intelligence for the flight controller and autonomous systems.
Precision Navigation and Positioning
One of the most critical roles of estimators is to provide highly accurate and reliable position and velocity information. In environments where GPS signals are weak or unavailable (such as indoors, under bridges, or in dense urban canyons), estimators combine data from IMUs, barometers, and often visual sensors (Visual-Inertial Odometry or VIO) to create robust estimates. This capability underpins precise waypoint navigation, allows drones to maintain exact positions for aerial photography, and is fundamental for applications like mapping (Simultaneous Localization and Mapping, or SLAM), where the drone needs to build a map while simultaneously localizing itself within it.
Robust Stabilization and Control
The stability of a drone is paramount. Estimators feed precise, low-latency estimates of the drone’s attitude (roll, pitch, yaw) and angular rates directly to the flight controller. This allows the controller to rapidly adjust motor speeds to counteract external disturbances like wind gusts, maintain a desired orientation, and execute smooth maneuvers. Without accurate and responsive state estimates, the drone would wobble uncontrollably, making precise flight impossible. The stability provided by robust estimation is the bedrock upon which all other drone capabilities are built.
Obstacle Avoidance and Path Planning
For drones operating in complex or dynamic environments, obstacle avoidance is a critical safety feature. Estimators play a dual role here: first, by providing highly accurate real-time estimates of the drone’s own position and velocity, allowing it to predict its future trajectory. Second, by processing data from proximity sensors (ultrasonic, lidar, radar) or vision sensors, estimators can estimate the position, size, and even velocity of potential obstacles. This information is then used by path planning algorithms to calculate collision-free trajectories, ensuring the drone can navigate safely around stationary objects or even dynamic elements in its environment.
Advanced Features: From AI to Autonomous Flight
Beyond basic flight, estimators are the backbone for many advanced and autonomous drone capabilities. Features like “AI Follow Mode,” where a drone autonomously tracks and films a moving subject, rely on estimators to predict the subject’s movement and the drone’s optimal flight path. Autonomous delivery drones use estimators for precise navigation to drop-off points and for robust flight in varied conditions. In remote sensing, estimators ensure that sensor data (e.g., from thermal or multispectral cameras) is accurately geo-referenced to a precise location, making the collected data scientifically valuable. Essentially, any smart decision a drone makes is informed by the accurate and reliable state information provided by its estimators.

The Future of Estimation in UAVs
As drone technology continues to advance, so too will the sophistication of estimation algorithms. The future will see even more seamless integration of diverse sensor modalities, including advancements in event-based cameras, millimeter-wave radar, and enhanced lidar systems, all contributing to richer data streams for estimators. We can expect estimators to become even more robust in challenging environments, such as GPS-denied areas or during aggressive maneuvers, leveraging advancements in computational power and real-time processing.
Furthermore, the convergence of estimation with Artificial Intelligence and Machine Learning will lead to adaptive estimators that can learn from environmental conditions and drone performance, dynamically adjusting their parameters for optimal accuracy and resilience. This will pave the way for increasingly autonomous UAVs capable of navigating highly complex, dynamic, and unpredictable environments with unprecedented safety and efficiency, pushing the boundaries of what drones can achieve.