
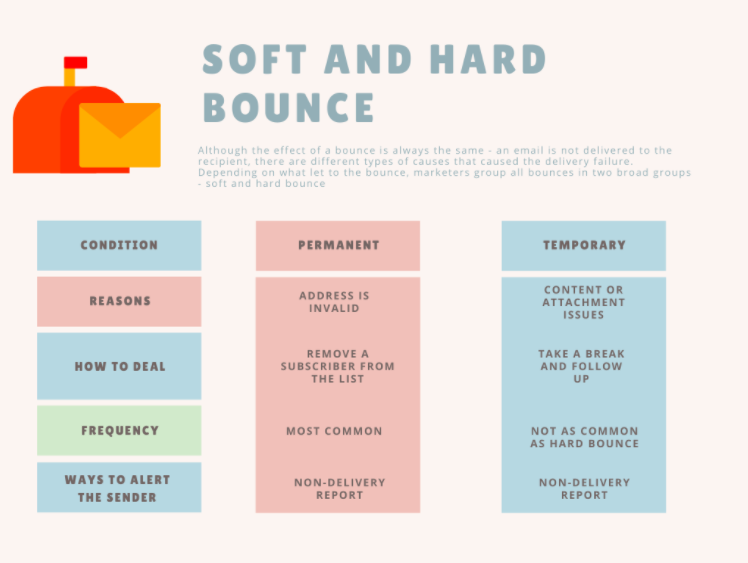
In the intricate world of aerial systems, where precision and reliability are paramount, the concept of a “hard bounce” carries a far more critical and tangible meaning than its digital email counterpart. While an email hard bounce signifies a permanent delivery failure to an invalid address, a hard bounce in flight technology refers to a catastrophic, often irreversible, impact or system failure that permanently incapacitates an aerial platform. This isn’t merely a software glitch or a temporary communication loss; it represents a fundamental breakdown within the sophisticated layers of flight technology, resulting in uncontrolled descent, collision, or irreparable damage. Understanding the nature of a hard bounce in this context is crucial for engineers, operators, and regulatory bodies striving for safer and more robust autonomous and remotely piloted flight.
Defining the “Hard Bounce” in Aerial Systems
A hard bounce in the realm of drones, UAVs, and other flight systems signifies a definitive and often destructive event that renders the aircraft permanently unable to perform its intended function without substantial repair or replacement. Unlike a “soft bounce,” which might imply a temporary loss of signal, a minor system anomaly that can be rectified mid-flight, or a controlled emergency landing, a hard bounce is characterized by the severity and permanence of the failure. It is the aerospace equivalent of an email returning as “address non-existent” – the intended destination (continued flight or safe operation) is unreachable due to an insurmountable obstacle or a fundamental flaw.
This catastrophic event often manifests as an uncontrolled crash into terrain, structures, or even other aircraft, triggered by a cascade of errors or a single, critical component failure. The implications extend beyond the immediate loss of hardware, encompassing potential injury, collateral damage to property, data loss, and severe reputational damage. For mission-critical applications such as search and rescue, remote sensing, or logistical delivery, a hard bounce represents a complete and immediate termination of operations, often with significant financial and operational setbacks. The focus of preventing such events lies squarely on the integrity and resilience of the flight technology itself, from navigation and stabilization systems to sensor arrays and power management.
Root Causes: Flight Technology Failures
The genesis of a hard bounce in aerial systems almost invariably traces back to a critical failure or severe degradation within the sophisticated array of flight technology components. These systems are designed to operate in challenging, dynamic environments, and a vulnerability in any one aspect can precipitate a cascading failure leading to a catastrophic outcome.
Navigation System Malfunctions
Global Positioning Systems (GPS) are the backbone of modern drone navigation, providing precise location and velocity data. A hard bounce can occur if the GPS receiver experiences a complete signal loss due to jamming, spoofing, or environmental interference (e.g., urban canyons, dense foliage). Even more critically, an internal malfunction within the GPS module itself, or a corruption of the navigation algorithm that processes this data, can lead to inaccurate position estimates. If the flight controller is fed erroneous positional data, it may command incorrect flight paths, leading the drone into obstacles or beyond its operational limits, culminating in an uncontrolled impact. Inertial Measurement Units (IMUs), comprising accelerometers and gyroscopes, are also vital for dead reckoning and short-term stabilization. A hard failure in an IMU, delivering wildly incorrect attitude or velocity data, can destabilize the aircraft instantaneously, leading to a hard bounce.
Stabilization System Critical Errors
Flight stabilization systems are at the heart of maintaining level flight, compensating for wind gusts, and responding to pilot inputs. These systems rely on a complex interplay of sensors, microcontrollers, and electronic speed controllers (ESCs) driving the motors. A hard bounce can be directly caused by a critical error in this domain. For instance, a sudden failure of an ESC can cause one motor to lose thrust, immediately throwing the aircraft into an unrecoverable spin or tumble. Similarly, a software bug or hardware malfunction within the flight controller’s stabilization algorithms can lead to incorrect motor commands, resulting in rapid loss of control. Gyroscope or accelerometer drift, if uncorrected or undetected, can accumulate errors over time, eventually causing the stabilization system to misinterpret the drone’s orientation, leading to an erratic flight path that culminates in a crash.
Sensor Degradation and False Positives
Beyond navigation and stabilization, aerial platforms rely on a suite of environmental sensors for various functions, including altitude hold (barometers, sonar, lidar), airspeed measurement (pitot tubes), and obstacle detection. A hard bounce can be triggered by the abrupt failure or severe degradation of these sensors. For example, a barometer giving wildly inaccurate altitude readings can cause the drone to autonomously descend into the ground or ascend uncontrollably into unsafe airspace. Ultrasonic or lidar sensors, crucial for proximity sensing, might fail to detect an obstacle due to internal malfunction, dirt accumulation, or adverse weather conditions, leading to a direct collision. Furthermore, “false positives” – where a sensor erroneously reports a critical condition or obstacle when none exists – can cause erratic evasive maneuvers that destabilize the aircraft, ultimately contributing to an uncontrolled impact.
Obstacle Avoidance System Lapses
Modern flight technology often incorporates sophisticated obstacle avoidance systems utilizing vision cameras, lidar, radar, or ultrasonic sensors. While these systems are designed to prevent collisions, their failure can ironically lead to a hard bounce. This can happen if the processing unit responsible for interpreting sensor data malfunctions, if the algorithms for path planning encounter an unhandled error, or if the sensors themselves are blinded or damaged. A system that fails to detect an impending collision, or one that misinterprets the environment and initiates an inadequate or incorrect evasive maneuver, can lead directly to a high-impact event. The complexity of these systems means that a single point of failure, whether hardware or software, can have devastating consequences, converting an intended safety feature into a vulnerability.

The Ripple Effect: Consequences of a Hard Bounce
The immediate outcome of a hard bounce is the physical destruction or severe damage to the aerial platform. However, the ripple effects extend far beyond the tangible loss of equipment, impacting operations, safety, data integrity, and public perception.
Operationally, a hard bounce leads to immediate mission failure. Whether the drone was conducting critical surveillance, delivering vital supplies, or gathering scientific data, the mission is aborted, often with irretrievable loss of opportunity and the need for costly re-deployment or manual intervention. For commercial operators, this translates directly to financial losses from damaged equipment, lost contracts, and potential liability claims.
Safety is paramount in aviation, and a hard bounce poses significant risks. Depending on the altitude and location of the impact, falling debris can cause injury or even fatalities to people on the ground. Collisions with manned aircraft, while rare, represent an existential threat to aviation safety. The public, often wary of drone operations, can lose trust, leading to stricter regulations and limitations on drone use in various sectors.
Data integrity is also severely compromised. Many drones carry high-value sensors, cameras, and data storage devices. A hard bounce can result in the complete destruction of recorded data, rendering the entire mission’s effort useless. This is particularly critical in fields like remote sensing, mapping, or forensic analysis where the captured data is the primary deliverable. Even if the storage survives, the impact forces can corrupt data, making it inaccessible or unreliable.
From a regulatory standpoint, a hard bounce typically triggers an investigation by aviation authorities. This process can be lengthy and resource-intensive, scrutinizing flight logs, telemetry data, and system diagnostics to ascertain the root cause. Depending on the findings, it can lead to hefty fines, revocation of operating licenses, and mandatory safety revisions across the industry. Such incidents also contribute to the ongoing debate around drone integration into national airspace, influencing policies that shape the future of flight technology.
Mitigation and Prevention Strategies for Robust Flight
Preventing a hard bounce requires a multi-faceted approach, integrating advanced engineering, rigorous testing, intelligent software, and comprehensive operational protocols. The goal is to build redundancy, enhance predictive capabilities, and ensure that human and automated systems work in harmony to maintain flight integrity.
Redundancy in Critical Systems
A cornerstone of robust flight technology is redundancy. This involves incorporating duplicate or parallel critical components and systems so that if one fails, another can seamlessly take over. For instance, high-end drones may feature dual flight controllers, multiple GPS modules, or even redundant power distribution systems. Redundant sensors (e.g., two barometers, multiple IMUs) can cross-check readings, allowing the flight controller to detect and disregard erroneous data from a failing sensor. In the event of a total failure of a primary system, a secondary, independent system can activate, providing a failsafe mechanism that allows for controlled flight termination or an emergency landing, thereby preventing a hard bounce. This strategy significantly reduces single points of failure that can lead to catastrophic outcomes.
Advanced Diagnostics and Predictive Maintenance
Moving beyond reactive repairs, modern flight technology incorporates sophisticated diagnostic tools and predictive maintenance algorithms. These systems continuously monitor the health and performance of all critical components, from motor temperatures and battery cell voltages to sensor outputs and communication link quality. By analyzing real-time data and historical trends, these systems can identify subtle degradations or anomalous behaviors that might precede a critical failure. For example, slight variations in motor RPMs or increased power draw might indicate an impending motor failure. Predictive algorithms can alert operators to these potential issues, recommending pre-emptive maintenance or grounding the aircraft before a hard bounce occurs. This proactive approach ensures that components are replaced or serviced before they become a liability.
Enhanced Environmental Sensing
The ability of an aerial platform to accurately perceive its environment is critical for avoiding hard bounces, especially in complex or dynamic operational areas. This necessitates enhanced environmental sensing capabilities, often combining multiple sensor types (sensor fusion). Stereo vision cameras, lidar, radar, and ultrasonic sensors can work in concert to create a comprehensive 3D map of the surroundings, even in challenging conditions like low light or fog. Advances in AI and machine learning allow these systems to more accurately classify objects, predict their movement, and calculate optimal collision-free trajectories. Beyond immediate obstacle avoidance, improved weather sensing and wind prediction models can help the flight controller adapt its flight path and power settings to maintain stability in adverse conditions, preventing environmental factors from contributing to a hard bounce.
Operator Proficiency and Emergency Protocols
While technology plays a dominant role, the human element remains vital, especially in situations where automated systems might falter. Highly proficient operators, thoroughly trained in emergency procedures, can often mitigate the risk of a hard bounce when unforeseen circumstances arise. This includes mastering manual flight controls, understanding system limitations, and being adept at executing emergency landings or controlled descents. Robust emergency protocols, clearly defined and frequently rehearsed, ensure that operators know exactly how to respond to various failure scenarios, from loss of GPS to motor malfunction. These protocols often involve pre-programmed failsafe behaviors (e.g., “return to home” if communication is lost, emergency parachute deployment) that act as a last line of defense, reducing the likelihood that a technical anomaly escalates into a catastrophic hard bounce.