
The term “gnat bug,” typically conjuring images of ubiquitous, often irritating small flying insects, takes on a fascinating new dimension within the realm of modern technology and innovation. Far from being merely a biological nuisance, the gnat – with its astonishing agility, resilience, and inherent swarming capabilities – has emerged as a profound source of inspiration for a new frontier in robotics: the development of insect-scale autonomous vehicles. In this context, a “gnat bug” can be understood not just as a natural creature but as a concept, a design aspiration, and even a nascent classification for ultra-miniature drones and robotic systems that push the boundaries of bio-inspired engineering, autonomous flight, and remote sensing.
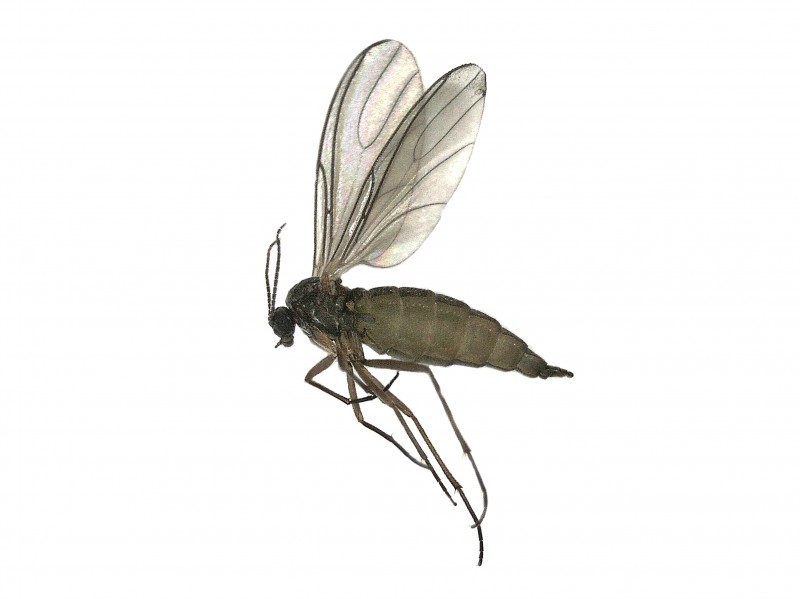
The Micro-Scale Frontier: From Insect Inspiration to Robotic Mimicry
The natural world has always provided a rich canvas for technological innovation, and few creatures captivate engineers quite like the humble gnat. Its ability to navigate complex environments, perform intricate aerial maneuvers, and operate on minimal energy at an incredibly small scale offers a blueprint for the next generation of flying robots. The pursuit of “gnat bug” robotics is fundamentally about transcending traditional drone limitations by replicating the unparalleled efficiency and robustness of biological micro-fliers.
Bio-Inspired Design Principles
Central to creating “gnat bug” robots is the study of biomimicry. Researchers meticulously analyze the anatomy, physiology, and flight mechanics of real gnats and other small insects. This involves understanding their wing kinematics – the precise movements, flapping frequencies, and aerodynamic principles that allow them to generate lift and thrust. Unlike fixed-wing aircraft or even multi-rotor drones that rely on propellers for continuous rotation, insects often employ complex, oscillating wing strokes that create vortices and leverage unsteady aerodynamics, offering superior efficiency at low Reynolds numbers (relevant for small-scale flight). Innovations in flexible materials, micro-actuators, and distributed sensing are all directly informed by these biological insights. The goal is not merely to copy an insect, but to extract the fundamental engineering principles that enable such extraordinary performance in a miniature package.
Challenges of Miniaturization
Building a functional flying robot the size of a gnat presents formidable engineering challenges. Every component, from power sources to sensors and actuators, must shrink dramatically without compromising performance. The square-cube law dictates that as size decreases, mass reduces by the cube of the dimension, while surface area reduces by the square. This has profound implications for lift generation, power-to-weight ratio, and the structural integrity of components. Furthermore, traditional electromechanical actuators struggle at these scales, leading to the exploration of novel actuation methods like piezoelectric materials or electro-active polymers. Integrating processing power, communication modules, and robust control systems into such a minute form factor while maintaining flight stability and autonomy is a monumental task, requiring breakthroughs across multiple disciplines.
Engineering the “Gnat Bug” Drone: Cutting-Edge Technology
The development of insect-scale drones necessitates pioneering advancements in materials science, micro-fabrication, and energy systems. Each aspect of these tiny flying machines requires a re-imagining of conventional engineering solutions.
Propulsion and Aerodynamics at Tiny Scales
Traditional propeller-based propulsion becomes inefficient and complex at insect scales due to the very low Reynolds numbers where air behaves more like a viscous fluid than a continuous flow. This pushes engineers towards flapping-wing (ornithopter) designs, directly mimicking insect flight. Developing ultra-lightweight, high-frequency flapping mechanisms is critical. This involves micro-actuators capable of generating significant force and displacement at frequencies often exceeding hundreds of hertz, alongside wings fabricated from advanced composite materials or even biological tissues (in hybrid designs) that can withstand constant flexion without fatigue. Precision manufacturing techniques, such as micro-electromechanical systems (MEMS) fabrication, are essential for creating these intricate structures with micron-level accuracy.
Powering the Miniature Flight
Energy storage and delivery are perhaps the most significant hurdles for “gnat bug” drones. Conventional batteries are too heavy and bulky for insect-scale robots, offering insufficient power density for sustained flight. Research is intensely focused on ultra-compact, high-energy-density power sources. This includes miniaturized solid-state batteries, micro-fuel cells, and even harvesting ambient energy through solar cells or wireless power transfer. The goal is to achieve flight times that extend beyond mere seconds, enabling practical applications. Innovations in power management circuits that operate with extreme efficiency are also crucial to maximize the limited onboard energy.
Sensors and Navigation for Micro-UAVs

For a “gnat bug” drone to operate autonomously, it requires miniaturized sensor arrays and sophisticated navigation algorithms. Conventional GPS is often too large and power-intensive for these systems, and its accuracy can be insufficient in indoor or cluttered environments. Therefore, researchers are exploring alternative navigation strategies inspired by insects themselves. This includes optical flow sensors that detect movement patterns across their visual field, mimicking insect compound eyes to infer speed and direction. Micro-LIDAR or ultra-miniature cameras provide environmental mapping and obstacle avoidance. Inertial Measurement Units (IMUs) composed of MEMS gyroscopes and accelerometers maintain orientation, while algorithms capable of processing sensor data with minimal computational resources are essential for real-time decision-making on board these resource-constrained platforms.
Autonomous Flight and Swarm Intelligence
The true potential of “gnat bug” robotics lies in their ability to operate autonomously and, crucially, as part of a collective. Their small size and potentially low individual cost make them ideal candidates for swarm robotics, where multiple units cooperate to achieve complex tasks that are impossible for a single robot.
AI in Micro-Drone Operations
Artificial intelligence plays a transformative role in enabling the autonomy of these tiny platforms. AI algorithms are essential for interpreting sensor data, path planning, and dynamic obstacle avoidance in unpredictable environments. For instance, tiny onboard neural networks can process visual input to identify targets or navigate through confined spaces. Reinforcement learning is used to teach robots optimal flight maneuvers and energy management strategies. The emphasis is on developing lightweight, efficient AI models that can run on minimal processing power, often leveraging edge computing principles to make decisions instantaneously without constant communication with a central hub. This allows for true self-sufficiency even in environments where communication might be disrupted or limited.
Collective Behavior and Swarm Robotics
Inspired by natural insect swarms, robotic swarms of “gnat bug” drones promise unparalleled capabilities. A single insect-scale drone may have limited perception and processing power, but a swarm of hundreds or thousands, acting in concert, can gather vast amounts of data, cover large areas rapidly, and exhibit robust fault tolerance. If one unit fails, others can take its place. Developing swarm intelligence involves programming simple local rules that, when followed by each individual, lead to complex, emergent group behaviors. This includes collective search patterns, synchronized mapping, and distributed sensing. Challenges include inter-robot communication at close quarters, collision avoidance within the swarm, and maintaining overall mission coherence without centralized control, which can be a single point of failure.
Applications and Future Impact of Gnat-Scale Robotics
The innovative leap toward “gnat bug” robotics holds profound implications across numerous sectors, promising to revolutionize how we interact with and monitor our world. Their discreet nature, ability to access difficult environments, and potential for swarm deployment unlock possibilities previously confined to science fiction.
Environmental Monitoring and Agriculture
Imagine a swarm of insect-scale drones autonomously patrolling forests to detect early signs of wildfires, mapping plant health with unprecedented detail, or monitoring air quality by identifying specific airborne pollutants. Their small size allows them to navigate dense foliage or sensitive ecosystems without causing disturbance. In agriculture, “gnat bug” drones could perform hyper-localized pest detection, precisely apply micro-doses of nutrients, or monitor individual plant stress levels, leading to more efficient resource management and higher yields with reduced environmental impact.
Infrastructure Inspection and Search & Rescue
The ability to access tight, confined, and dangerous spaces makes these robots invaluable for inspecting critical infrastructure. They could navigate inside pipelines, ventilations systems, or through the intricate structures of bridges and buildings to identify structural weaknesses or maintenance needs without risking human lives. In search and rescue operations, particularly after natural disasters, swarms of “gnat bug” drones could rapidly scour collapsed buildings, tunnels, or dense debris fields to locate survivors, relaying vital information to rescue teams in real-time, often reaching areas inaccessible to larger drones or human responders.

The Ethical Horizon
As with any transformative technology, the rise of “gnat bug” robotics presents an important ethical discourse. Their potential for discreet surveillance, whether for legitimate security purposes or less benign applications, raises questions about privacy and accountability. The development of autonomous swarms capable of complex decision-making also prompts discussions around control, intent, and the rules of engagement in sensitive or contested environments. Ensuring responsible development, establishing clear ethical guidelines, and implementing robust oversight mechanisms will be crucial as these miniature marvels transition from research labs to widespread deployment, shaping their impact on society. The “gnat bug” of the future is not just a technological marvel but a societal mirror, reflecting our capacity for innovation and our responsibility in wielding its power.