
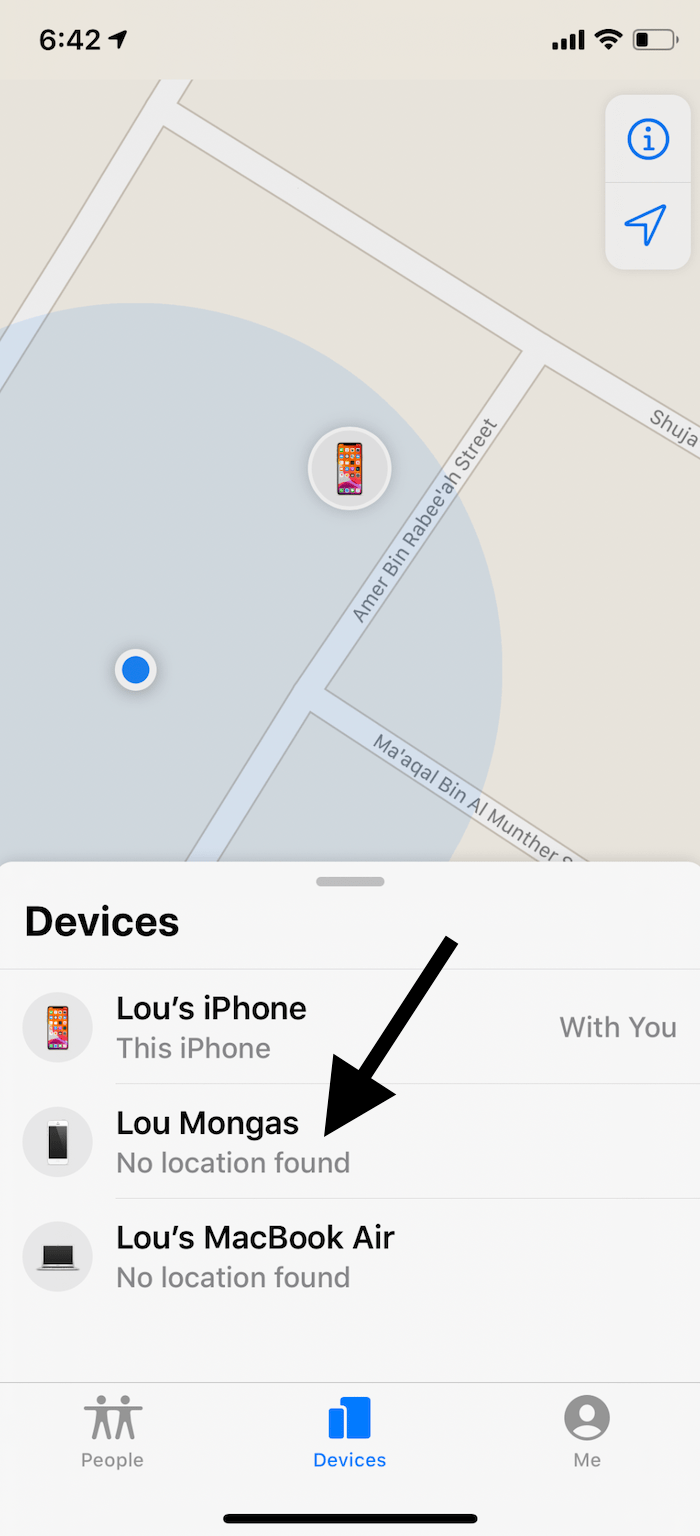
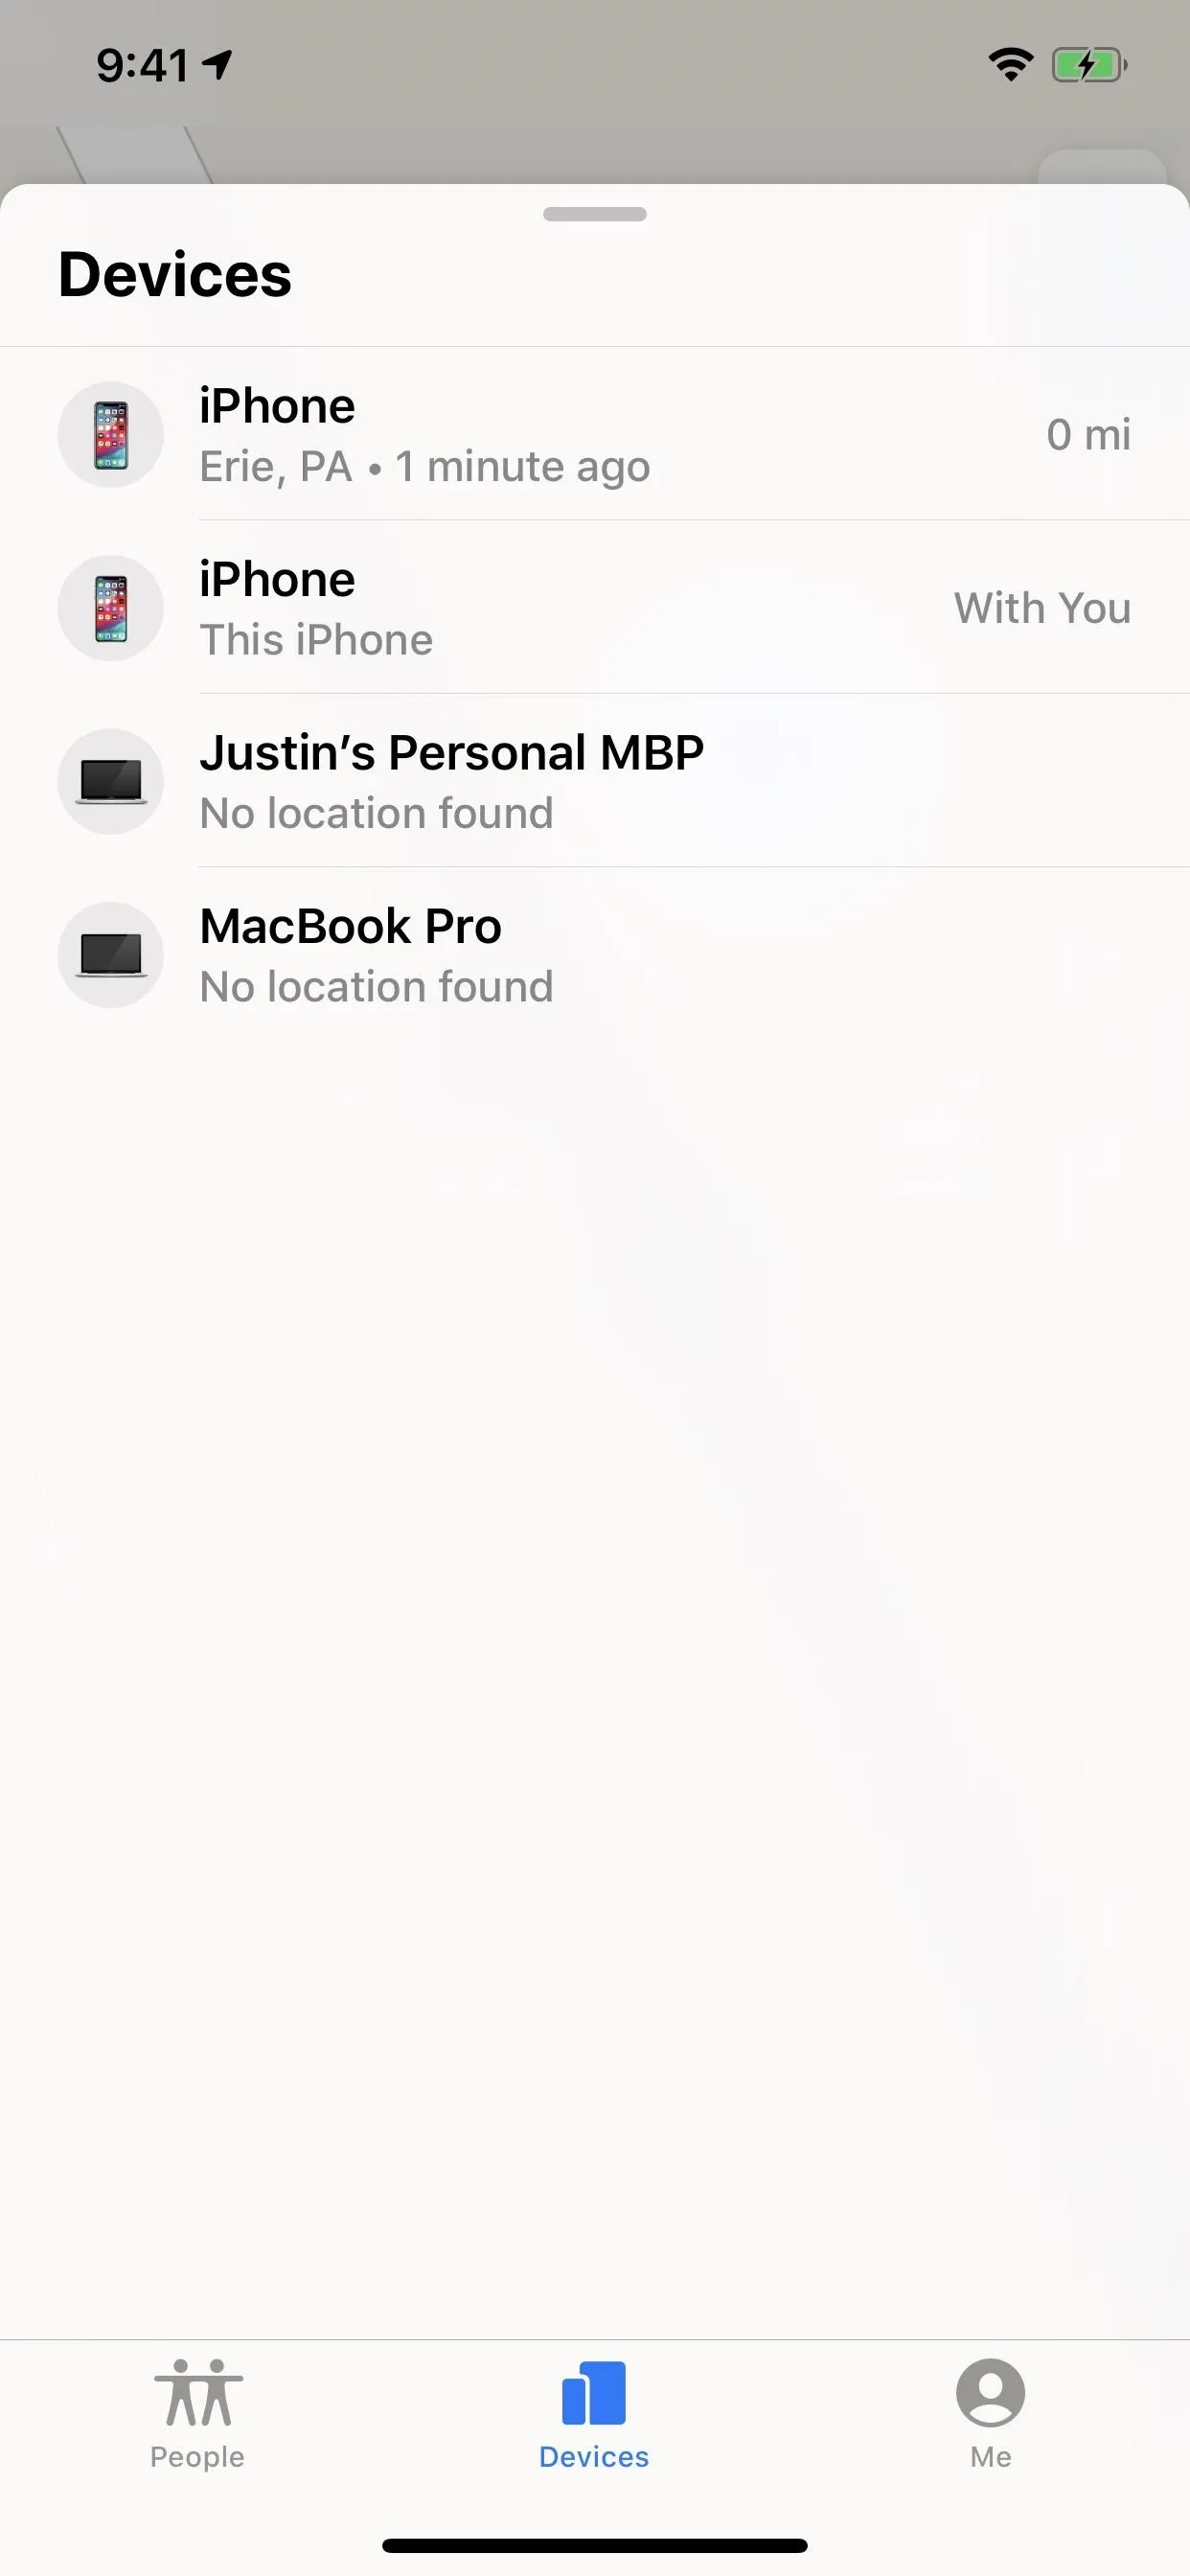
The ubiquitous phrase “No Location Found” within digital mapping and tracking applications, particularly on platforms like Apple’s Find My Friends, signals more than just an inconvenience; it represents a momentary or persistent breakdown in the intricate symphony of navigation and sensor technologies that underpin modern location services. Far from being a simple failure, this message reveals critical insights into the operational challenges and inherent limitations of the very systems that guide everything from ground-based personal tracking to sophisticated autonomous flight. Understanding its implications requires a journey into the core principles of GPS, inertial measurement units (IMUs), cellular triangulation, and Wi-Fi positioning – the fundamental pillars of contemporary flight technology and digital navigation.
The Pillars of Digital Navigation: GPS and Its Supporting Cast
At the heart of any location-aware system, whether it’s a smartphone locating a friend or a drone executing an autonomous flight path, lies Global Positioning System (GPS) technology. GPS, a satellite-based radio navigation system owned by the U.S. government and operated by the U.S. Space Force, provides precise positioning, navigation, and timing (PNT) services globally. A device calculates its position by triangulating signals received from multiple GPS satellites orbiting Earth. For a successful fix, a receiver typically needs signals from at least four satellites to determine its latitude, longitude, altitude, and time.
The Role of Augmented GPS (A-GPS) and Network-Based Positioning
While pure satellite GPS is foundational, modern personal devices and many drone navigation systems often leverage Assisted GPS (A-GPS). A-GPS significantly enhances the speed and accuracy of location fixes, especially in challenging environments like urban canyons or indoors. It does this by using cellular network data to provide initial satellite information (such as approximate location and satellite almanac data) to the GPS receiver, reducing the time needed to acquire satellite signals and compute a position.
Beyond A-GPS, two other critical network-based technologies complement GPS to ensure more robust location services:
- Cellular Triangulation: This method estimates a device’s location based on its proximity to multiple cellular towers. By measuring the signal strength from several towers, the network can triangulate the device’s approximate position. While less precise than GPS, it’s invaluable in areas where GPS signals are weak or unavailable, particularly indoors or in dense urban areas.
- Wi-Fi Positioning System (WPS): WPS determines a device’s location by identifying and ranging nearby Wi-Fi access points. A massive database of Wi-Fi hotspots and their geographical coordinates allows a device to estimate its position by comparing the SSIDs (network names) and signal strengths of visible networks against known locations. WPS is particularly effective in urban and indoor environments where GPS signals struggle to penetrate.
When “No Location Found” appears, it often indicates a failure in one or more of these primary systems. The device might not be able to receive enough clear GPS signals, lack access to cellular networks for A-GPS or triangulation, or be out of range of recognizable Wi-Fi networks for WPS.
Sensory Input: The Device’s Internal Compass and Inertial Measurement Units
Beyond the external signals of GPS and network data, modern devices, including smartphones and virtually all flight systems, rely heavily on an array of internal sensors to refine location, determine orientation, and track movement. These components form what is broadly known as an Inertial Measurement Unit (IMU), crucial for dead reckoning and maintaining situational awareness when external navigation aids are compromised.
Accelerometers, Gyroscopes, and Magnetometers
- Accelerometers: These sensors measure non-gravitational acceleration. In a smartphone, they detect changes in velocity and orientation, helping to determine if the device is moving and in what direction. In flight technology, accelerometers are vital for measuring linear acceleration, which contributes to understanding the aircraft’s speed and changes in its flight path.
- Gyroscopes: Gyroscopes measure angular velocity, or rotational motion. They detect how much and how fast a device is rotating around its X, Y, and Z axes. This information is critical for maintaining screen orientation on a phone and, more importantly, for stabilizing drones and other aircraft, preventing uncontrolled rolls, pitches, and yaw movements.
- Magnetometers: Often referred to as a digital compass, magnetometers measure the strength and direction of magnetic fields. They are used to determine the device’s orientation relative to the Earth’s magnetic north, providing crucial heading information. For both ground navigation and flight, an accurate heading is indispensable for translating relative movements into absolute directional changes on a map.
The data from these sensors is continuously processed and fused to provide a more robust and responsive understanding of the device’s position and movement. For instance, if GPS signals are temporarily lost, the IMU can estimate the device’s new position based on its last known GPS fix and subsequent movements (dead reckoning). While less precise over long periods, this sensor fusion allows for seamless tracking and navigation, bridging gaps in external signal availability. A “No Location Found” message can sometimes indicate a failure in this sensor fusion process, where corrupted or missing sensor data prevents a coherent location estimation.
Common Causes of “No Location Found” and Their Technological Roots
The appearance of “No Location Found” is a composite indicator, pointing to various potential disruptions within the intricate web of flight technology responsible for pinpointing a device’s geographical coordinates.
1. Signal Blockage and Environmental Interference
The most prevalent reason stems from the inability of the device to receive adequate signals from GPS satellites, cellular towers, or Wi-Fi access points.
- Physical Obstruction: Dense urban environments with tall buildings (urban canyons), underground areas, thick concrete structures, or even dense foliage can block or reflect GPS, cellular, and Wi-Fi signals, making accurate triangulation impossible. For drones, this is akin to flying in an area with poor GPS coverage, which can lead to drift or forced landing if position hold cannot be maintained.
- Atmospheric Conditions: While less common for everyday “Find My Friends” usage, severe weather can impact satellite signal propagation, adding noise or weakening signals, analogous to how atmospheric conditions affect drone flight stability.
- Electromagnetic Interference (EMI): Strong radio frequency (RF) interference from other electronic devices or specialized jamming equipment can overwhelm a device’s receivers, making it impossible to decode legitimate navigation signals. This is a critical concern in controlled airspace and military applications, but even consumer electronics can experience localized interference.
2. Device Power and Software Malfunction
Even with clear signals, a device cannot provide location if its operational parameters are compromised.
- Device Offline or Powered Off: The most straightforward cause. If a device has run out of battery or has been manually powered down, its navigation systems are inactive, rendering location tracking impossible.
- Location Services Disabled: Users often have control over privacy settings, including the ability to disable location services for specific apps or the entire device. When these are off, the navigation hardware is prevented from transmitting or processing location data.
- Software Glitches or Crashes: Bugs in the operating system or the specific tracking application can prevent location data from being properly acquired, processed, or displayed. A device might be receiving signals, but the software fails to interpret them correctly or transmit the resulting location.
- Outdated Firmware or Drivers: Just as drone flight controllers require updated firmware for optimal performance, a phone’s GPS module or network interfaces might require updates to function correctly with evolving signal protocols or mapping databases.
3. Network Connectivity Issues
The reliance on cellular and Wi-Fi networks for A-GPS, triangulation, and WPS means that network outages or poor coverage can directly lead to a “No Location Found” message. If a device is outside cellular service areas or in a Wi-Fi dead zone, these crucial augmentation services become unavailable, severely degrading location accuracy and often resulting in a complete failure to locate. This mirrors the challenges in drone operations where command and control links rely on robust radio frequency communication.
The Interplay of Hardware and Software in Location Services
The ability to successfully provide location data is a testament to the seamless interplay between a device’s hardware components and its operating system’s software architecture. The GPS receiver, the cellular radio, the Wi-Fi module, and the IMU sensors are the physical engines, constantly gathering raw data. However, it is the sophisticated algorithms and software protocols that transform this raw data into meaningful, precise, and real-time location information.
Operating systems like iOS and Android employ advanced sensor fusion algorithms that intelligently combine data from all available sources – GPS, A-GPS, cellular, Wi-Fi, accelerometers, gyroscopes, and magnetometers. This multi-source approach creates a resilient and accurate location solution. When “No Location Found” occurs, it can indicate a break in this chain, either due to a hardware malfunction (e.g., a faulty GPS antenna), a software error (e.g., a process failing to interpret sensor data), or a communication breakdown between these layers. This is analogous to how modern flight controllers integrate data from multiple sensors (GPS, barometer, IMU, optical flow, ultrasonic) to achieve stable and autonomous flight; a failure in any one component or the fusion algorithm can lead to erratic behavior or loss of positional awareness.
Implications for Autonomous Systems and Future Navigation
The “No Location Found” message serves as a stark reminder of the inherent vulnerabilities in even our most advanced navigation systems. For personal tracking applications, it’s an inconvenience. For autonomous flight systems, however, such a failure can be catastrophic. Drones, self-driving vehicles, and other robotic systems demand uninterrupted, highly accurate, and reliable positional data to operate safely and effectively.
The lessons learned from common location service failures directly inform the development of more robust navigation strategies for future flight technology:
- Redundancy and Diversity: Future systems are increasingly incorporating redundant GPS receivers, multiple IMUs, and diverse navigation methods (e.g., visual odometry, LiDAR-based SLAM – Simultaneous Localization and Mapping) to ensure continuity even if one system fails.
- Enhanced Sensor Fusion: Algorithms are becoming more sophisticated, capable of intelligently weighing the reliability of different sensor inputs under varying environmental conditions and seamlessly transitioning between them.
- Resilience Against Interference: Research into anti-jamming and anti-spoofing technologies for GPS is critical, especially for sensitive applications, ensuring that signals are not maliciously disrupted or faked.
- Edge Computing and Local Mapping: Devices are becoming smarter, capable of performing more localization calculations on-board (edge computing) and building localized maps of their environment to aid in navigation, reducing reliance on constant external signals.
In essence, “No Location Found” is more than a notification; it’s a diagnostic echo of the complex, interconnected, and occasionally fragile world of modern navigation and sensor technology. As we push the boundaries of autonomy and interconnectedness, understanding these fundamental principles becomes paramount for building more resilient and dependable systems, from a simple phone app to the most advanced aerial vehicles.