
In the intricate world of drone flight technology, precision, reliability, and consistency are paramount. Every sensor reading, every navigational command, and every stabilization adjustment contributes to the overall performance and safety of an unmanned aerial vehicle (UAV). Understanding statistical measures like standard deviation is not just an academic exercise; it offers critical insights into the real-world variability and robustness of a drone’s core systems. A higher standard deviation, in essence, signals greater inconsistency and less predictability in the performance of a given flight technology component.
The Core Concept of Standard Deviation in Aviation
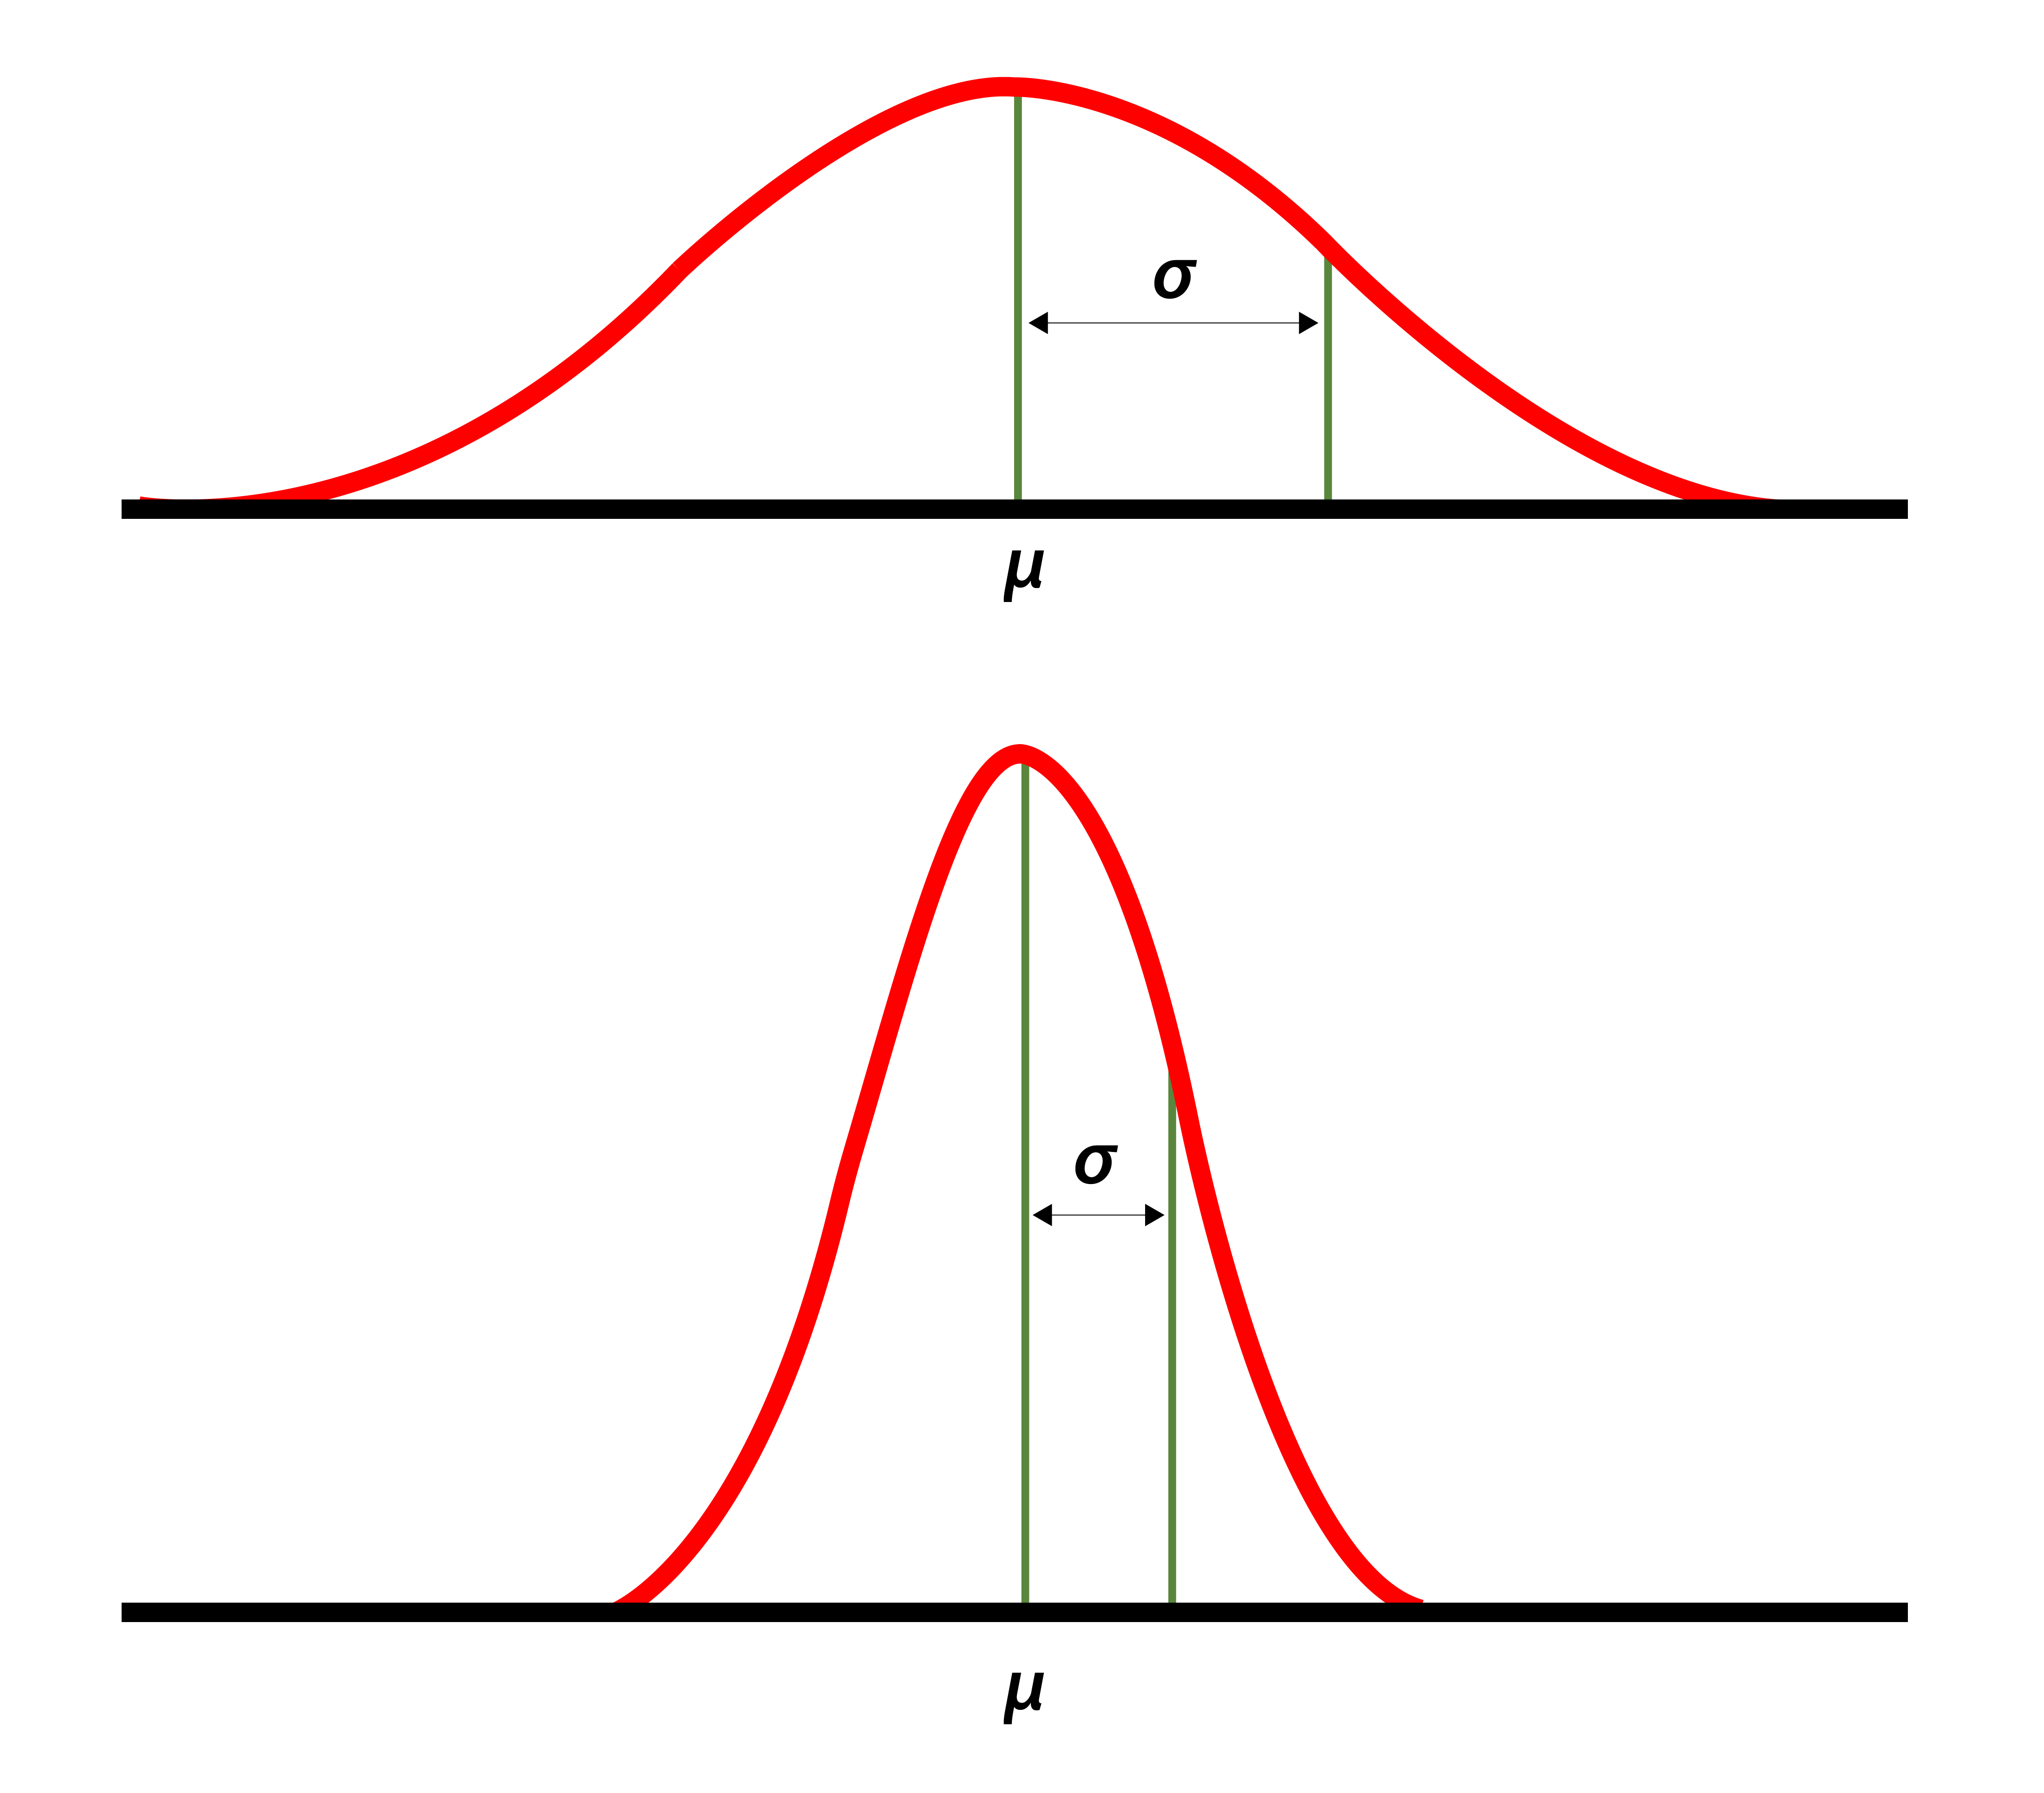
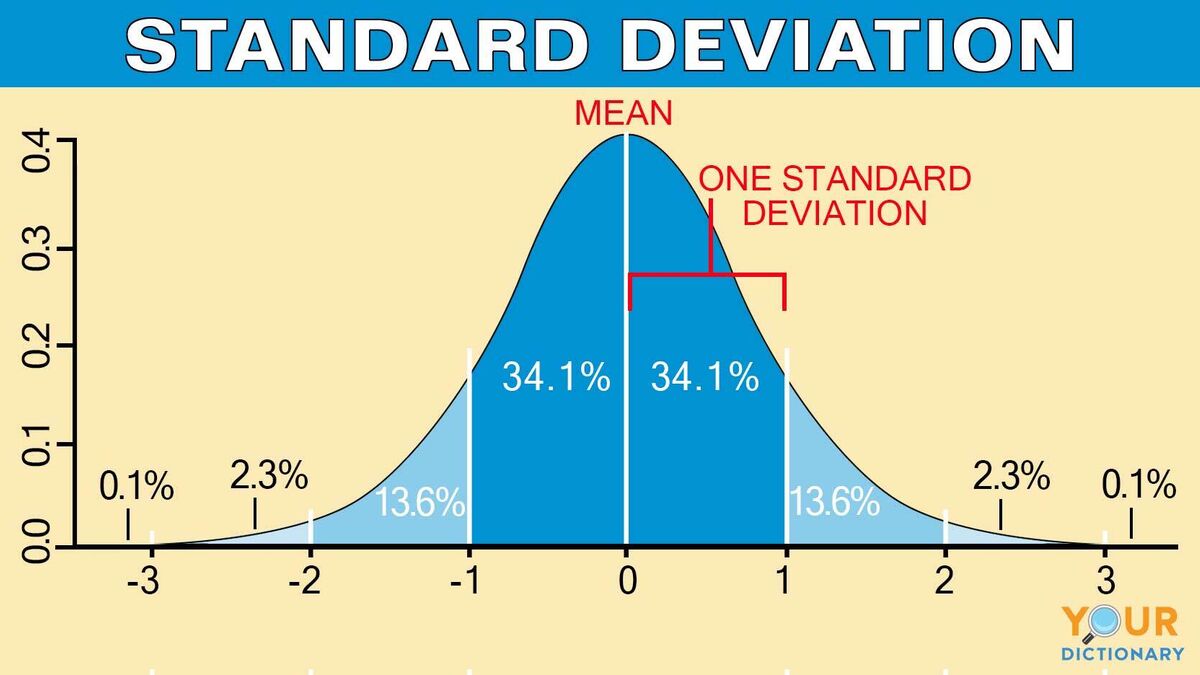
Standard deviation is a fundamental statistical measure that quantifies the amount of variation or dispersion of a set of data values. In simpler terms, it tells us how spread out the data points are around the average (mean) value. A low standard deviation indicates that data points tend to be close to the mean, while a high standard deviation indicates that the data points are spread out over a wider range.
Measuring Variability
For drone flight technology, this concept is directly applicable to various operational parameters. Imagine a drone commanded to maintain a precise altitude or hover at a specific GPS coordinate. If we were to repeatedly measure its actual altitude or position over time, the collection of these measurements would form a dataset. The standard deviation of this dataset would then reveal how consistently the drone maintained its target. A small standard deviation would indicate highly consistent performance, with the drone staying very close to its commanded parameters. Conversely, a large standard deviation would suggest erratic behavior, with significant deviations from the target.
Why It Matters for Drones
In the context of drone flight, a higher standard deviation implies several critical issues:
- Reduced Precision: The drone’s ability to execute commands or maintain states accurately is diminished.
- Lower Reliability: System performance becomes less predictable, making operations riskier.
- Increased Error Margins: The actual position, altitude, or attitude deviates more significantly from the intended one.
- Compromised Safety: Unpredictable behavior can lead to collisions, instability, or loss of control.
Understanding and, where possible, reducing standard deviation is thus a key objective in the design, calibration, and operation of advanced drone flight systems.
Standard Deviation in Navigation and GPS Accuracy
One of the most immediate and critical areas where standard deviation plays a vital role is in drone navigation, particularly concerning Global Positioning System (GPS) accuracy. Drones rely heavily on GPS for positional awareness, waypoint navigation, and autonomous flight.
Positional Precision
When a drone’s GPS module reports its position, it’s not always the exact true location. There’s inherent noise and variability in satellite signals, atmospheric conditions, and receiver capabilities. If we were to log the reported GPS coordinates of a stationary drone over time, we would observe a cluster of points, not a single static point. The standard deviation of these recorded latitude, longitude, and altitude values provides a direct measure of the GPS system’s positional precision. A higher standard deviation in these measurements means the reported position is less reliable and more prone to drift.
For instance, a drone with a horizontal positional standard deviation of 0.5 meters is far more precise than one with a 5-meter standard deviation. The latter suggests the drone could be reporting its position up to several meters away from its actual location, which is a significant margin of error for applications requiring precise flight paths or data collection over specific targets.
Impact on Autonomous Flight Paths
Autonomous flight missions, such as mapping, inspection, or delivery, depend entirely on the drone’s ability to follow a pre-programmed flight path with minimal deviation. If the underlying GPS data exhibits a high standard deviation, the drone’s flight controller will struggle to accurately track the intended trajectory.
A higher standard deviation in navigation means:
- Wider Flight Corridor: The drone might weave more significantly around the intended path, rather than following it tightly. This can lead to inefficient flight, missed data points for mapping, or even trespassing into restricted airspace.
- Inaccurate Data Acquisition: For photogrammetry or remote sensing, consistent flight paths are crucial for proper image overlap and accurate data reconstruction. High positional variability can lead to gaps in data or distorted models.
- Increased Collision Risk: In complex environments or corridors with obstacles, a drone that deviates widely from its planned path due to high navigational standard deviation poses a greater risk of collision.
Engineers and operators strive for systems with low standard deviation in navigation, often employing technologies like RTK (Real-Time Kinematic) or PPK (Post-Processed Kinematic) GPS, which significantly reduce positional variability by correcting real-time errors, thereby lowering the standard deviation of position estimates to centimeter-level accuracy.
Stability and Sensor Performance
Beyond navigation, standard deviation also provides crucial insights into the stability of a drone and the performance of its various sensors, which are fundamental to maintaining controlled flight.

Altitude Hold and Gimbal Stabilization
Maintaining a stable altitude is a core function for many drones, especially those used for photography or mapping. An altitude hold system relies on barometric pressure sensors, ultrasonic sensors, or GPS altitude data. If these sensors, or the control algorithms interpreting them, exhibit a high standard deviation, the drone will not be able to maintain a consistent altitude. Instead, it will drift up and down, making it challenging to capture steady footage or perform accurate surveys. A high standard deviation here indicates a “bouncy” or unstable altitude hold.
Similarly, gimbal stabilization systems are designed to keep cameras perfectly level, isolating them from the drone’s movements. The effectiveness of a gimbal can be quantified by measuring the standard deviation of its angular deviations from a perfectly level plane. A high standard deviation means the gimbal is not effectively counteracting drone movements, resulting in shaky footage. Professional aerial cinematographers demand gimbals with extremely low standard deviation in their stabilization performance to achieve cinematic quality.
Understanding Sensor Noise and Reliability
Drones are equipped with an array of sensors—accelerometers, gyroscopes, magnetometers, pressure sensors, optical flow sensors, and more. Each sensor provides data that the flight controller uses to understand its orientation, movement, and environment. All sensors, however, have inherent noise and inaccuracies.
A higher standard deviation in the readings from any of these sensors indicates:
- Increased Sensor Noise: The sensor’s output is highly variable even when the input (e.g., actual acceleration, rotation rate) is constant. This “noisy” data makes it harder for the flight controller to accurately perceive the drone’s state.
- Reduced Data Reliability: The flight controller has less confidence in any single reading, potentially leading to delayed or incorrect control actions.
- Challenging Sensor Fusion: Modern drones use sensor fusion algorithms to combine data from multiple sensors to get a more robust estimate of the drone’s state. If individual sensor data has a high standard deviation, the fusion algorithm’s task becomes much harder, and the resulting estimate will also have a higher degree of uncertainty.
For instance, a gyroscope with a high standard deviation in its reported angular velocity might cause the drone to overcorrect or undercorrect its attitude, leading to unstable flight or unexpected maneuvers. Engineers meticulously characterize the standard deviation of sensor outputs to design effective filtering and fusion algorithms that can mitigate the impact of sensor noise.
Implications for Obstacle Avoidance and Safety
Obstacle avoidance systems are crucial safety features that rely on a variety of sensors (ultrasonic, LiDAR, visual cameras) to detect objects in the drone’s path. The effectiveness and reliability of these systems are directly influenced by the standard deviation of their sensor readings and the consistency of their processing.
Consistency in Detection
An obstacle avoidance system’s ability to consistently detect and range objects is critical. If, for example, a LiDAR sensor used for obstacle detection has a high standard deviation in its range measurements, it means that for the same physical distance, it might report a wide range of values. This inconsistency can lead to:
- False Positives/Negatives: The system might incorrectly identify obstacles that aren’t there (false positive) or, more dangerously, fail to detect existing obstacles (false negative).
- Delayed Reactions: If the system is unsure about the presence or distance of an obstacle due to variable readings, it might delay its avoidance maneuver, reducing the margin for safety.
- Erratic Avoidance Maneuvers: A system that has a high standard deviation in its spatial perception might initiate jerky or unpredictable avoidance maneuvers, making the drone’s flight less smooth and potentially destabilizing.
A higher standard deviation in obstacle detection capability translates directly into reduced safety and increased risk of collision, particularly in dynamic or complex environments.
Mitigating Risks Through Data Analysis
Drone manufacturers and operators use statistical analysis, including standard deviation, to rigorously test and validate obstacle avoidance systems. By understanding the variability in detection range, angular accuracy, and response times, they can establish appropriate safety margins and operational limits. For instance, if a system consistently shows a high standard deviation in detecting objects beyond a certain range, that range might be deemed unreliable, and the drone’s operational envelope would be adjusted accordingly. Advanced algorithms often employ techniques to filter out noise and reduce the effective standard deviation of sensor data, thereby improving the consistency and reliability of avoidance decisions.
Enhancing Drone Performance Through Reduced Variability
The overarching goal in drone flight technology is to minimize variability, thereby reducing the standard deviation of critical performance metrics. Achieving this leads to more precise, reliable, and safer drones.
Advanced Algorithms and Hardware
Continuous advancements in drone technology are primarily focused on reducing standard deviation across the board. This includes:
- Improved Sensor Quality: Developing sensors with lower inherent noise and higher repeatability.
- Sophisticated Filtering and Fusion Algorithms: These software components intelligently process raw sensor data to filter out noise and combine information from multiple sources, yielding a more accurate and less variable estimate of the drone’s state. For example, Kalman filters are widely used to reduce the standard deviation of state estimates (position, velocity, attitude) by effectively blending noisy sensor data with a predictive model.
- More Robust Control Systems: Flight controllers with adaptive capabilities can respond to changing environmental conditions (like wind gusts) or internal dynamics to maintain stability with minimal deviation.
- High-Precision GPS Systems: Technologies like RTK and PPK significantly reduce the standard deviation of positional data, enabling centimeter-level accuracy for demanding applications.
Operator Awareness and Best Practices
While hardware and software innovations play a massive role, operator awareness and adherence to best practices also contribute to minimizing operational variability. Understanding how environmental factors (e.g., strong winds, GPS signal interference, extreme temperatures) can increase the standard deviation of a drone’s performance metrics allows operators to make informed decisions about flight conditions and operational limits. Pre-flight checks, calibration procedures, and adherence to manufacturer guidelines are all practices that help ensure the drone performs within expected, low-variability parameters.
Ultimately, a deep understanding of what a higher standard deviation means in drone flight technology empowers both engineers to design superior systems and operators to fly them with greater confidence and safety. It’s a fundamental concept that underpins the quest for ever more precise, reliable, and autonomous flight.