
In the complex world of drone technology and innovation, precision, reliability, and efficiency are paramount. While often associated with abstract mathematical concepts, the term “extraneous” carries significant, practical implications for the development and deployment of autonomous flight systems, advanced mapping solutions, and intelligent data processing. Understanding what extraneous means in a mathematical context—and how to identify and manage such elements—is fundamental to refining algorithms, ensuring data integrity, and achieving robust operational performance in UAVs.
Defining Extraneous: Beyond Pure Mathematical Solutions
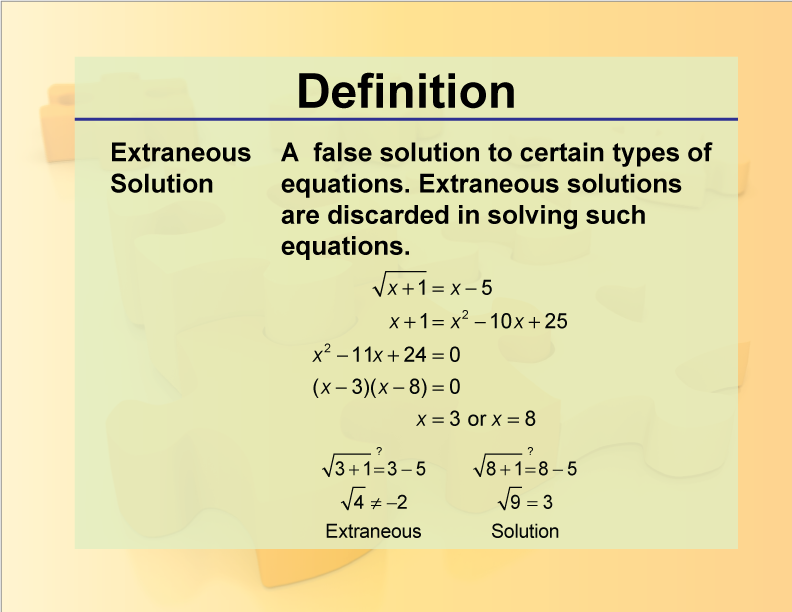
At its core, “extraneous” refers to something that is not a necessary or relevant part of something else. In mathematics, this definition often manifests in two primary forms: extraneous solutions and extraneous data/variables. Both concepts have direct analogies and critical relevance in the realm of drone technology.
Extraneous Solutions in Algorithmic Processes
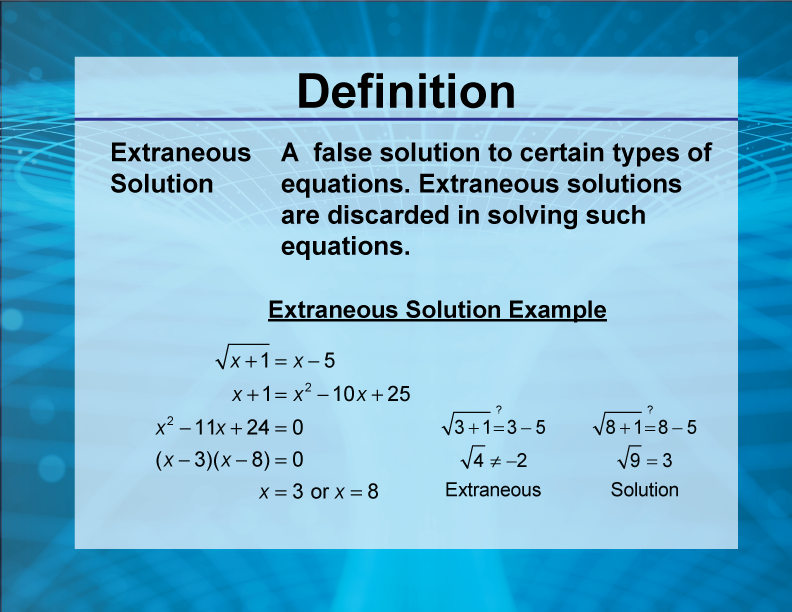
An extraneous solution typically arises when solving an equation, particularly those involving square roots, fractions, or logarithms, where intermediate algebraic steps might introduce values that do not satisfy the original equation when substituted back. These solutions are mathematically derived but physically or contextually invalid. For drone systems, an “extraneous solution” can represent a computed outcome or path that, while mathematically plausible in isolation, is impossible or unsafe within the real-world constraints of flight dynamics, environmental conditions, or operational parameters. For instance, a path planning algorithm might generate a trajectory that mathematically minimizes fuel consumption but requires an instantaneous change in velocity that exceeds the drone’s physical capabilities, rendering it an extraneous solution in a practical sense.
Extraneous Data and Variables in System Modeling
More broadly applicable to drone innovation is the concept of extraneous data or variables. This refers to information that is irrelevant, redundant, misleading, or noisy within a dataset or a system model. In the context of sensor fusion, for example, a faulty GPS reading or a transient electromagnetic interference signal could be considered extraneous data. Similarly, in machine learning models designed for object detection or predictive maintenance, features that do not contribute to the model’s accuracy or even degrade its performance are extraneous variables. Identifying and excising these extraneous elements is vital for maintaining the integrity of data streams, the accuracy of predictive models, and the reliability of autonomous decision-making processes.
The Impact of Extraneous Elements on Drone Navigation and Control
Autonomous drone flight, precise navigation, and stable control are built upon intricate mathematical models and real-time data processing. The presence of extraneous information can severely compromise these critical functions, leading to reduced performance, system instability, or even mission failure.
Filtering Sensor Data for Autonomous Flight
Modern drones rely on a multitude of sensors—IMUs (Inertial Measurement Units), GPS, barometers, magnetometers, ultrasonic, and optical sensors—to perceive their environment and determine their state. Extraneous data from any of these sources can introduce significant errors. A single erroneous GPS fix due to signal multipath or jamming, if not identified as extraneous, could cause the drone to drift significantly off course. Similarly, transient noise in IMU readings can lead to inaccurate attitude estimation, jeopardizing stable flight. Advanced filtering algorithms, such as Kalman filters or Extended Kalman filters, mathematically process sensor inputs, continuously predicting the drone’s state and correcting it based on new observations. A key function of these filters is to implicitly or explicitly identify and discount extraneous (outlier or noisy) sensor readings, ensuring that only relevant and reliable data contribute to the drone’s estimated position, velocity, and orientation.
Mitigating Extraneous Variables in Control Algorithms
Control algorithms are the brains behind a drone’s flight stability and maneuverability. They take desired inputs (e.g., desired altitude, heading, speed) and translate them into motor commands. The mathematical models underpinning these algorithms must accurately represent the drone’s dynamics. If the model includes extraneous variables—parameters that have negligible influence or are incorrectly weighted—it can lead to suboptimal control responses, increased computational load, or even instability. For instance, if an aerodynamic model overemphasizes a minor drag coefficient that is irrelevant at typical operating speeds, the control system might expend unnecessary energy compensating for a non-existent effect. By meticulously validating and refining these models, engineers can eliminate extraneous variables, simplifying the control problem and enhancing efficiency and responsiveness.
GPS Accuracy and Extraneous Signals
GPS is a cornerstone of drone navigation. However, the signals can be susceptible to various forms of interference, intentional or unintentional, leading to extraneous positional data. Multipath errors (signals reflecting off surfaces), atmospheric delays, and jamming signals can all introduce inaccuracies. High-precision drone operations, such as precision agriculture or infrastructure inspection, cannot tolerate such extraneous noise. Techniques like differential GPS (DGPS) or Real-Time Kinematic (RTK) GPS, along with robust signal processing algorithms, are employed to identify and correct for these extraneous influences, ensuring centimeter-level accuracy by comparing raw satellite data with known ground station data, effectively filtering out discrepancies.
Extraneous Data in Remote Sensing and Mapping
Drones are transformative tools for remote sensing and mapping, capturing vast amounts of visual, thermal, and spectral data. The utility of this data, however, hinges on its purity and relevance. Extraneous data can distort models, compromise measurements, and undermine the accuracy of derived insights.
Cleaning Photogrammetry Data
Photogrammetry involves stitching together hundreds or thousands of overlapping images to create 2D orthomosaics or 3D models. The process relies on identifying common features across multiple images. Extraneous data in this context can include blurry images, images taken from angles that create severe distortion, or those affected by poor lighting. Cloud cover, moving objects, or reflections can also introduce noise and artifacts into the point cloud or mesh. Sophisticated photogrammetry software employs algorithms to detect and reject such extraneous imagery or data points, ensuring that the resulting 3D models are geometrically accurate and visually consistent, crucial for applications like construction monitoring, volumetric calculations, and urban planning.
Dealing with Outliers in Lidar Scans
Lidar (Light Detection and Ranging) systems on drones emit laser pulses and measure the time it takes for them to return, creating a precise 3D point cloud of the environment. However, extraneous reflections (e.g., from water surfaces, highly reflective materials, or dust particles) or sensor noise can generate outlier points that do not represent the true geometry of the scanned area. These extraneous points can lead to jagged surfaces, incorrect distance measurements, and inaccurate volumetric assessments. Advanced point cloud processing algorithms are designed to identify and remove these outliers using statistical methods, density-based clustering, or model-fitting techniques, thus enhancing the fidelity of the Lidar data for applications in forestry, terrain modeling, and infrastructure inspection.
Enhancing Data Integrity for AI-Driven Analytics
For drone-collected data to be truly valuable, it often feeds into AI and machine learning models for automated analysis, such as defect detection in wind turbines, crop health monitoring, or security surveillance. The presence of extraneous data—irrelevant pixels, sensor glitches, or mislabeled training examples—can severely degrade the performance of these AI models. Training an AI model on noisy data can lead to models that generalize poorly or make erroneous predictions. Rigorous data curation, including automated filtering and manual review, is essential to identify and eliminate extraneous data, ensuring the high-quality input needed for robust and reliable AI-driven insights.
Machine Learning and AI: Identifying and Handling Extraneous Features
The cutting edge of drone innovation often lies in its integration with Artificial Intelligence, from autonomous decision-making to predictive analytics. The ability to distinguish between meaningful information and extraneous noise is paramount for effective AI.
Feature Selection for Predictive Models
In machine learning, “features” are the individual measurable properties or characteristics of a phenomenon being observed. For drones, these could include flight parameters (altitude, speed, motor RPM), sensor readings (temperature, battery voltage), or environmental data (wind speed). When building predictive models—for example, to anticipate battery drain, predict component failure, or optimize flight paths—it’s common to have a large number of potential features. However, not all features are equally informative; some may be redundant, irrelevant, or highly correlated with other features. These are considered extraneous features. Effective feature selection techniques (e.g., recursive feature elimination, L1 regularization, tree-based feature importance) are critical to identify and remove extraneous features. This process not only improves model accuracy and generalization but also reduces computational complexity, making models more efficient for onboard processing in drones with limited resources.
Robustness Against Noise in AI Follow Mode
AI follow mode allows drones to autonomously track moving subjects. This relies on real-time object detection and tracking algorithms. The visual data streams are inherently noisy, with variations in lighting, background clutter, partial occlusions, and sudden movements. These constitute extraneous visual information that can confuse the tracking algorithm. Advanced computer vision models employ techniques like robust estimation, motion prediction, and deep learning architectures trained on diverse datasets to minimize the impact of such extraneous visual noise. The goal is to ensure the drone maintains a consistent lock on the intended target, even when confronted with challenging visual inputs, rather than getting distracted by extraneous elements in the scene.
Anomaly Detection for Predictive Maintenance
Predictive maintenance for drone fleets leverages sensor data to anticipate component failures. AI models analyze operational parameters (e.g., motor vibration, temperature, current draw) for deviations from normal behavior. An “anomaly” in this context is often an outlier or an unusual pattern of data that could signify an impending issue. Extraneous data or noise in the sensor readings themselves can, however, lead to false positives (identifying a normal event as an anomaly) or mask true anomalies. Robust anomaly detection algorithms are designed to distinguish between genuine signs of impending failure and extraneous fluctuations, ensuring that maintenance schedules are optimized and critical failures are prevented, thereby extending the operational life of drone components.
Best Practices for Mitigating Extraneous Factors
Effectively dealing with extraneous elements is not a one-time fix but an ongoing process embedded in the design, development, and operation of drone technology.
Advanced Filtering Techniques
The continuous development of advanced filtering and signal processing algorithms is crucial. Techniques like adaptive filters, unscented Kalman filters, particle filters, and deep learning-based denoising methods are progressively enhancing the ability of drone systems to extract clean, relevant data from noisy, complex environments. These methods allow drones to maintain high levels of performance even in challenging conditions where extraneous data is prevalent.
Robust Algorithm Design
Designing algorithms with inherent robustness against extraneous inputs is paramount. This includes incorporating error handling mechanisms, redundancy checks, and fallback strategies. For instance, a navigation system might fuse data from multiple dissimilar sensors, such that if one sensor provides extraneous readings, the system can still rely on the others or switch to an alternative navigation mode. Robust control theory also aims to design controllers that maintain desired performance despite uncertainties and disturbances, which can be seen as forms of extraneous influences.
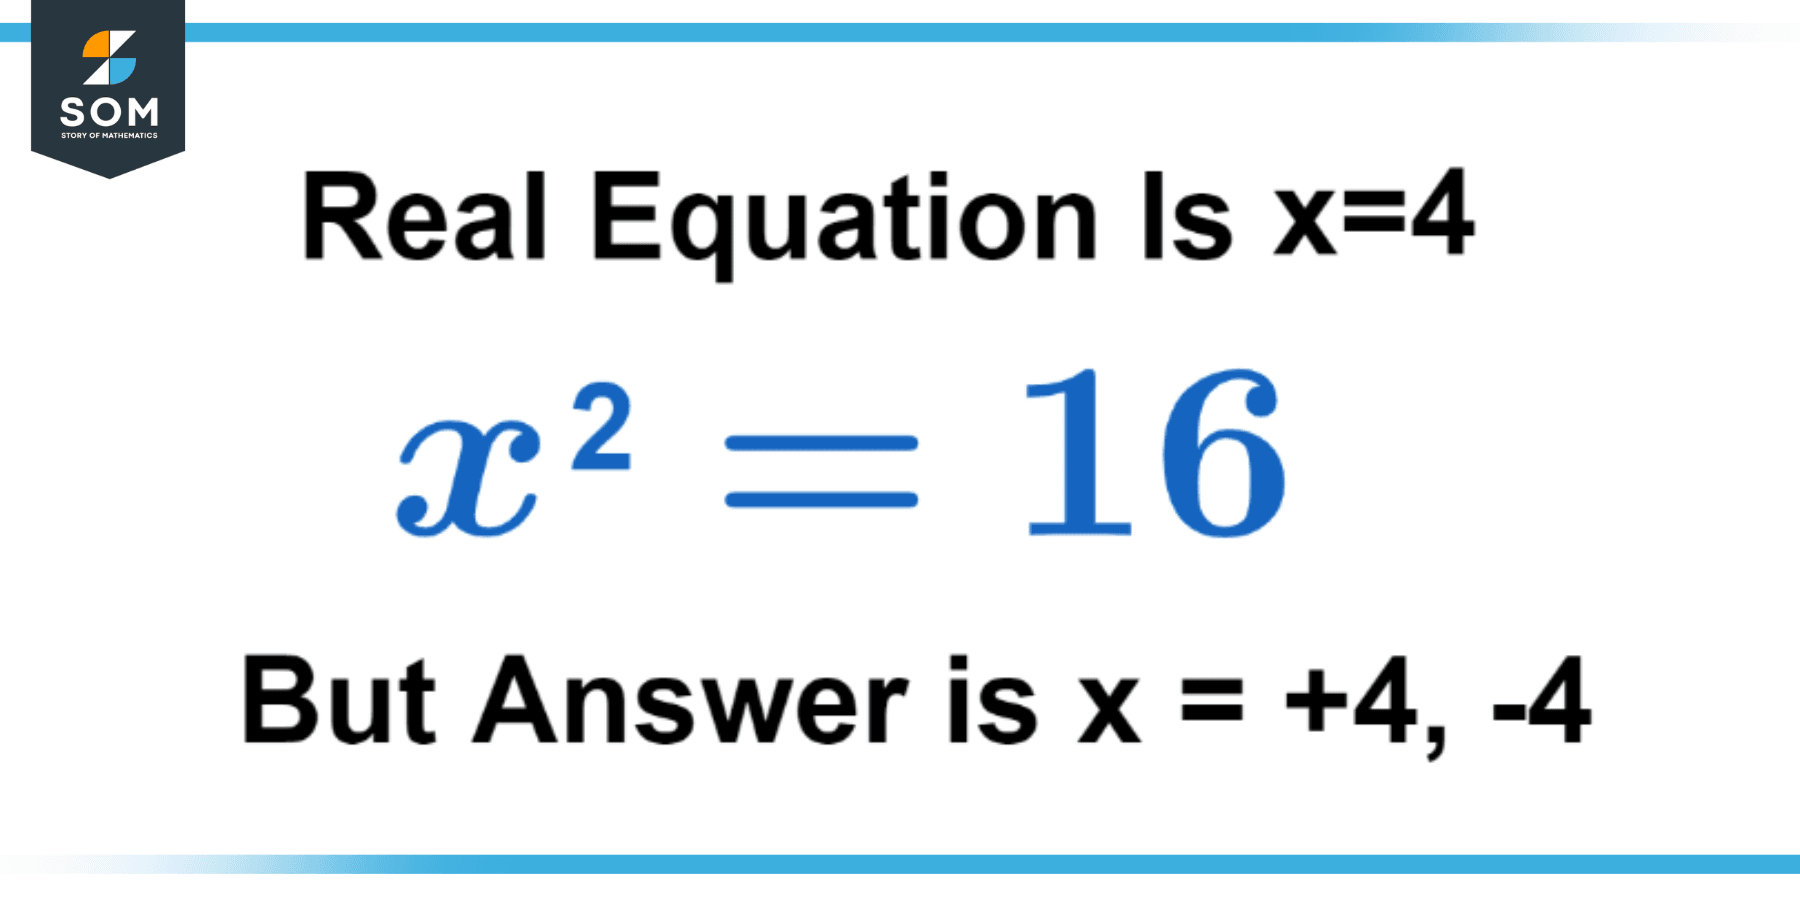
Continuous Validation and Verification
The entire development lifecycle—from simulation to field testing—must include rigorous validation and verification processes specifically aimed at identifying and mitigating extraneous factors. This involves testing drone systems in diverse, challenging environments to expose potential weaknesses to extraneous data or conditions. Post-flight analysis of logged data is also critical for identifying patterns of extraneous behavior and refining algorithms to improve resilience and accuracy in future operations.
In essence, understanding what extraneous means in a mathematical context is not just an academic exercise for drone engineers and innovators; it is a practical necessity. By meticulously identifying, understanding, and mitigating extraneous solutions, data, and variables, the industry can continue to push the boundaries of what autonomous drone technology can achieve, ensuring safer, more efficient, and more reliable aerial operations across all sectors.