
Alaska, the largest state in the United States, presents a unique and often complex temporal landscape for both human endeavors and, critically, for advanced flight technology applications, particularly in the realm of unmanned aerial vehicles (UAVs). While the fundamental “time difference” refers to its offset from Coordinated Universal Time (UTC), its geographical position also dictates extreme variations in daylight hours throughout the year, a factor profoundly impacting drone flight planning, navigation, sensor performance, and overall mission execution within the “Flight Technology” domain.
Alaska’s Temporal Landscape and its Influence on Drone Flight Planning
Understanding Alaska’s time difference is not merely an academic exercise for drone operators and flight technologists; it is a foundational element for successful mission planning, regulatory compliance, and data integrity. The state’s vast expanse and high latitude create distinct temporal considerations that must be integrated into every aspect of drone flight technology.

Geopolitical Time Zones and UTC Offsets
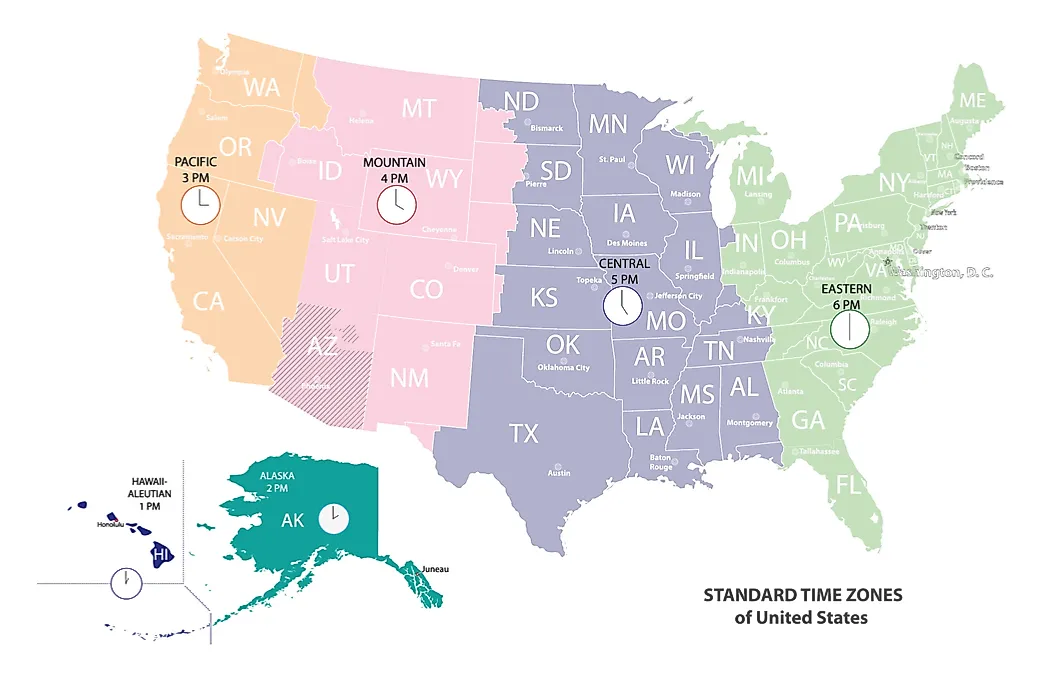
The majority of Alaska observes Alaska Standard Time (AST), which is UTC-9. This means that when it is noon UTC, it is 3:00 AM in most of Alaska. However, the westernmost Aleutian Islands (west of 172° W longitude) operate under Hawaii Standard Time (HST), which is UTC-10. This internal time zone boundary, though minor in land area, can be a critical planning point for long-range drone missions traversing the full breadth of the state or for coordinating data collection efforts that span these regions. For flight technologists developing autonomous navigation systems or mission planning software, accurately incorporating these distinct UTC offsets is paramount for internal clock synchronization, precise data logging, and seamless handovers between operational segments. Mismanagement of time zones can lead to scheduling conflicts, data timestamp errors, and potentially non-compliance with operational windows.
Extreme Daylight Variation: A Seasonal Challenge for UAVs
Beyond the static UTC offset, Alaska’s high latitude dictates perhaps the most significant “time difference” challenge: the dramatic seasonal variation in daylight hours. During the summer solstice, parts of Alaska experience nearly 24 hours of daylight, while during the winter solstice, they may see only a few hours of weak sunlight. This dynamic environment directly impacts flight technology in several ways:
- Visual Line of Sight (VLOS) Operations: Many drone regulations mandate VLOS operations. Prolonged darkness in winter severely limits the permissible flight windows, requiring sophisticated flight planning software to optimize scarce daylight hours. Conversely, perpetual daylight in summer offers extended operational periods, but also demands vigilant battery management for sustained missions.
- Sensor Performance: Optical sensors (RGB, multispectral) rely heavily on ambient light. In winter, low light conditions degrade image quality, necessitating longer exposure times or higher ISO settings, which can introduce noise. Thermal sensors are less affected by visible light but their efficacy in distinguishing targets can be influenced by temperature differentials that shift with solar radiation cycles. Flight technology must incorporate adaptive sensor control algorithms that adjust parameters based on real-time light conditions, or operators must select sensors appropriate for the extreme variations.
- Energy Management for Long-Endurance Drones: For solar-powered or hybrid-electric drones designed for extended missions, the availability of solar radiation is a direct determinant of flight endurance. Flight technology for these platforms must include sophisticated energy harvesting prediction models, considering sun angle, cloud cover, and hours of daylight, especially in Alaska’s fluctuating solar environment.
Precision Timing and Navigation System Reliance
The vast, often unmapped and remote terrain of Alaska, combined with its unique temporal characteristics, places immense reliance on precision timing within drone navigation systems. Flight technology in this region demands robust solutions for accurate positioning, data synchronization, and autonomous function.
GNSS Accuracy and Data Synchronicity in High Latitudes
Global Navigation Satellite Systems (GNSS) like GPS are the backbone of modern drone navigation. However, satellite geometry and signal reliability can be influenced by atmospheric conditions, which can be particularly volatile in Alaska. Furthermore, the accuracy of Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK) GNSS corrections hinges on precise time synchronization between the drone’s receiver and a base station. Any discrepancies in timekeeping, even microseconds, can lead to significant positional errors, critical for applications requiring centimeter-level accuracy such as surveying, mapping, or infrastructure inspection. Flight technology systems must incorporate highly accurate internal clocks, often disciplined by GNSS signals themselves, and robust algorithms for synchronizing data packets with precise timestamps to ensure integrity during post-processing. The “time difference” here extends beyond merely the UTC offset to the granular level of synchronized time for differential correction calculations.

Autonomous Flight and Time-Sensitive Sensor Integration
Autonomous drone operations, whether for mapping, surveillance, or package delivery, rely on the seamless and synchronized integration of multiple sensors: inertial measurement units (IMUs), LiDAR, cameras, altimeters, and more. Each sensor generates data that must be precisely timestamped and correlated with the drone’s position and orientation. In Alaska’s dynamic environment, where light conditions can change rapidly and flight paths might extend over remote areas for hours, the internal timing mechanisms of the flight controller and sensor suite are paramount. For example, in obstacle avoidance systems, precise timestamping of LiDAR scans and camera feeds allows the flight control system to build an accurate, real-time 3D model of the environment. A temporal lag or desynchronization, even minor, could lead to outdated environmental models and potential collisions. Flight technology must therefore incorporate advanced sensor fusion algorithms that robustly handle and synchronize time-series data from disparate sources, adapting to the “time difference” in data acquisition rates and processing latencies.
Operational Logistical Challenges and Solutions
The extreme time differences in Alaska, both in terms of UTC offset and daylight duration, translate into significant logistical hurdles for drone operations. Flight technology solutions must address these challenges to ensure efficient, safe, and effective deployment of UAVs across the state’s diverse environments.
Scheduling and Coordination Across Vast Distances
Operating drones across Alaska’s immense distances and potentially varied time zones (though most is AST) necessitates meticulous scheduling and coordination. Missions originating from outside Alaska require careful consideration of the UTC-9 or UTC-10 offset for crew rotations, battery charging schedules, and data offloading. For search and rescue, environmental monitoring, or long-range infrastructure inspection missions, coordinating multiple drone teams or ground support units across geographically dispersed sites becomes a complex time-management problem. Flight technology applications, such as mission planning software, must offer intuitive interfaces that allow operators to account for local time, UTC, and specific operational windows based on light availability. Effective communication systems, often satellite-based in remote Alaskan regions, also need to consider time differences for optimal crew rest periods and communication schedules.
Battery Management and Endurance in Varied Light Conditions
As previously mentioned, the profound “time difference” in daylight hours directly impacts battery management, especially for drones reliant on visual line of sight or those using solar charging. In the long summer days, extended flight times are possible, but demand robust battery monitoring and efficient power management systems to prevent overheating or over-discharge. Conversely, in the brief winter daylight, every minute of flight time is precious, requiring optimized flight paths, minimal hovering, and efficient payload usage to maximize endurance. Flight technology for Alaskan operations often integrates advanced battery management systems (BMS) that not only monitor charge and discharge cycles but also predict remaining flight time based on current power draw, external temperature, and remaining daylight, providing critical real-time data to operators in the field.
Advancements in Flight Technology for Alaskan Conditions
To overcome the unique challenges posed by Alaska’s temporal and environmental characteristics, ongoing advancements in flight technology are crucial. These innovations aim to enhance drone reliability, autonomy, and operational flexibility, specifically tailored for extreme conditions.
Adaptive Navigation Algorithms
Future flight technology for Alaska is focusing on adaptive navigation algorithms that can intelligently adjust to changing environmental and temporal conditions. This includes algorithms that can switch seamlessly between GNSS, visual-inertial odometry (VIO), and LiDAR-based navigation, especially when GNSS signals might be degraded or in low-light conditions. These systems could leverage predictive models of satellite availability and atmospheric interference, combined with real-time sensor data, to maintain precise positioning even in challenging environments. Furthermore, advancements in real-time kinematic (RTK) and post-processed kinematic (PPK) correction methods, utilizing local ground stations or network-based corrections, are continually being refined to enhance accuracy despite potential communication latency or signal disruptions over vast Alaskan distances. The integration of highly accurate internal clocks and robust time synchronization protocols remains central to these advancements.
Enhanced Sensor Fusion for All-Conditions Operations
To mitigate the impact of extreme daylight variation, flight technology is evolving towards more sophisticated sensor fusion techniques. This involves combining data from multiple sensor types—such as thermal cameras, low-light optimized optical cameras, and LiDAR—to create a comprehensive environmental perception regardless of ambient light. For instance, in low-light winter conditions, a drone might rely more heavily on thermal imaging for obstacle detection and target identification, while complementing it with sparse data from a low-light optical camera. The challenge lies in accurately fusing this disparate data, which often comes with varying resolutions, fields of view, and, crucially, different acquisition times. Advanced sensor fusion algorithms are being developed to intelligently weight and combine this data, compensating for any subtle “time differences” in their capture and processing, to provide a coherent and reliable operational picture to the flight control system, enabling safer and more effective drone operations throughout Alaska’s diverse temporal cycles.