
The term “higher order conditioning” originates from behavioral psychology, specifically within the realm of classical conditioning. While its roots are firmly planted in the study of animal and human behavior, the underlying principles offer profound insights into the mechanics of learning and association that are increasingly relevant to the field of Tech & Innovation, particularly in the development of advanced artificial intelligence (AI) and autonomous systems, such as those powering modern drones. In essence, higher order conditioning describes a process where a previously established conditioned stimulus (CS) is used to condition a new neutral stimulus (NS), transforming it into a second-order conditioned stimulus without ever directly pairing it with the original unconditioned stimulus (UCS). This complex layering of associations allows for more nuanced and indirect forms of learning, which hold significant implications for how intelligent machines perceive, interpret, and react to their environments.

Foundations: Classical Conditioning in Autonomous Systems
To grasp higher order conditioning, it’s crucial to first understand its bedrock: classical conditioning. Pioneered by Ivan Pavlov, classical conditioning involves associating a neutral stimulus with an unconditioned stimulus that naturally elicits an unconditioned response. Over time, the neutral stimulus becomes a conditioned stimulus, capable of eliciting a conditioned response on its own.
In the context of autonomous systems, this fundamental learning mechanism is vital for developing adaptive behaviors. Imagine a drone equipped with AI:
Direct Associations in Drone AI
- Unconditioned Stimulus (UCS): A sudden, strong gust of wind.
- Unconditioned Response (UCR): The drone naturally destabilizes, requiring immediate corrective action by its flight controller.
- Neutral Stimulus (NS): A specific, unique auditory pattern detected by the drone’s microphones, often preceding strong wind gusts due to atmospheric shifts or rotor noise changes from distant turbines.
- Conditioning Process: The AI system repeatedly correlates the detection of this specific auditory pattern (NS) with the subsequent experience of a strong wind gust (UCS) and the resulting destabilization (UCR).
- Conditioned Stimulus (CS): The auditory pattern alone.
- Conditioned Response (CR): Upon detecting the auditory pattern, the drone’s stabilization system preemptively adjusts thrust vectors, alters its flight path, or increases its power output to brace for an anticipated wind gust, minimizing destabilization.
This simple form of learning allows drones to build direct cause-and-effect relationships from their operational data, leading to more robust and predictive autonomous capabilities. It enables them to learn from past experiences to anticipate and mitigate environmental challenges, improving flight stability, energy efficiency, and operational safety.
Elevating Learning: The Mechanics of Higher Order Conditioning in AI
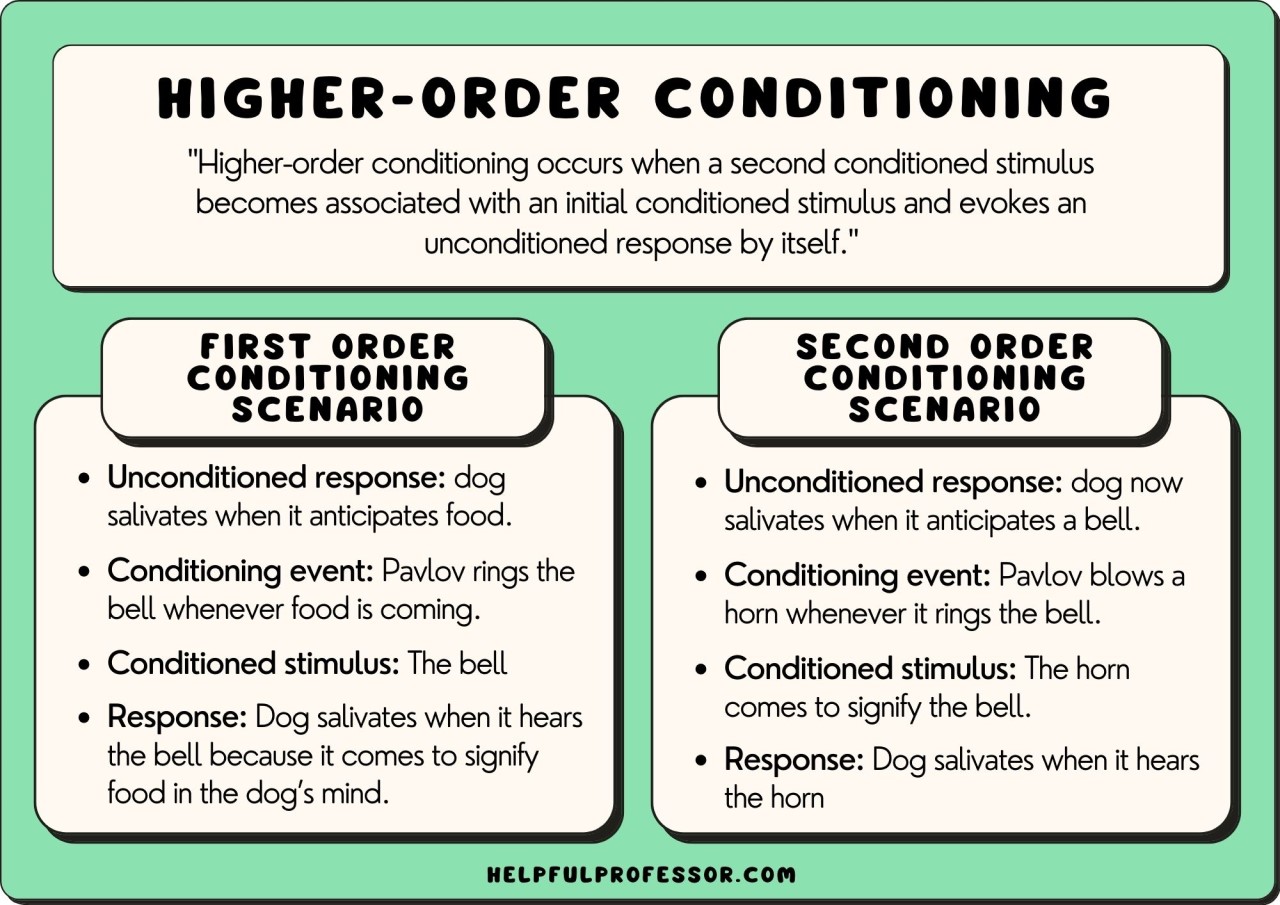
Higher order conditioning takes this associative learning a significant step further. Instead of pairing a neutral stimulus directly with an unconditioned stimulus, it pairs a new neutral stimulus with an already established conditioned stimulus. This creates a chain of associations, allowing the AI to respond to cues that are only indirectly linked to the original unconditioned stimulus.
The Two-Step Process
- First-Order Conditioning: An NS (e.g., specific auditory pattern) is paired with a UCS (e.g., strong wind gust) to create a CS1 (auditory pattern) that elicits a CR (preemptive stabilization).
- Second-Order Conditioning: A new NS (e.g., a visual pattern of approaching dark clouds in the distance) is then consistently paired with CS1 (the auditory pattern). Crucially, the visual pattern (new NS) is never directly paired with the strong wind gust (UCS).
- Result: Eventually, the visual pattern alone (now CS2) becomes capable of eliciting the same preemptive stabilization response (CR) from the drone, even in the absence of the auditory pattern or the actual wind gust.
This hierarchical learning mechanism empowers AI systems with a more sophisticated understanding of their environment, enabling them to react to more subtle, distal, or abstract cues. For a drone, this means it can develop a layered understanding of environmental predictors. It’s not just learning that this sound means wind, but also that this visual cue means that sound is coming, which means wind is coming. This depth of learning moves beyond simple reactive behaviors towards a more proactive and context-aware intelligence.
Implications for Predictive Sensing
Higher order conditioning facilitates predictive sensing by allowing AI to build complex causal chains. A drone might learn to associate a particular type of light refraction pattern (CS2) with certain atmospheric pressure readings (CS1), which in turn predicts ice formation on its propellers (UCS). This multi-layered prediction allows the drone to initiate de-icing procedures much earlier, preventing critical system failures. It can move beyond sensing the immediate threat to sensing the predictors of the predictors, granting it a significant advantage in preemptive action.
Practical Applications in Drone Tech & Innovation
The principles of higher order conditioning are not merely theoretical for autonomous systems; they hold immense practical value for enhancing the intelligence, adaptability, and safety of drones across various applications.
Enhanced Navigation and Obstacle Avoidance
In complex urban environments or dense foliage, a drone might encounter various sensory inputs.
- First-Order: The drone learns to associate a specific sonar echo signature (CS1) directly with the physical impact of an obstacle (UCS), leading to an avoidance maneuver (CR).
- Second-Order: The drone, while flying, repeatedly encounters a particular pattern of wireless signal interference (NS) just before detecting the sonar echo signature (CS1). It never directly associates the interference with the impact.
- Result: The wireless signal interference (CS2) alone triggers an early, subtle deviation maneuver, anticipating an obstacle even before direct sonar detection, potentially allowing for smoother, safer, and more efficient navigation through obstructed areas. This could be critical for search and rescue operations or delivery drones in cluttered environments.
Adaptive Surveillance and Remote Sensing
For surveillance or environmental monitoring drones, higher order conditioning can enable more intelligent pattern recognition and alert systems.
- First-Order: A drone learns to associate specific thermal signatures (CS1) with the presence of a target of interest (UCS), triggering an alert and tracking protocol (CR).
- Second-Order: The drone frequently observes a unique spectral reflection pattern from vegetation (NS) occurring just before it detects the specific thermal signature (CS1) of the target.
- Result: The spectral reflection pattern (CS2) alone can trigger a ‘pre-alert’ state, prompting the drone to adjust its camera settings, zoom in on the area, or deploy additional sensors to confirm the presence of the target, even before its thermal signature is fully clear. This proactive sensing reduces latency in critical responses and conserves processing power by focusing resources effectively.
Autonomous Mission Planning and Resource Management
Higher order conditioning can also contribute to more sophisticated mission planning, allowing drones to adapt their strategies based on indirect environmental cues.
- First-Order: A drone learns that a sudden drop in barometric pressure (CS1) frequently precedes heavy rainfall (UCS), necessitating an immediate return-to-base protocol (CR).
- Second-Order: The drone observes a specific type of cloud formation (NS) consistently appearing just before the barometric pressure drop (CS1).
- Result: The cloud formation (CS2) alone triggers a ‘pre-return’ sequence, where the drone might re-prioritize remaining tasks, seek temporary shelter, or optimize its flight path for an earlier return, even before the barometric pressure actually drops. This foresight allows for more resilient and flexible mission execution in unpredictable weather.
Challenges and Future Directions
While the theoretical framework for higher order conditioning offers compelling advantages for AI development in drones, its practical implementation faces several challenges. The complexity of real-world environments means that stimuli are rarely as clear-cut as in laboratory settings. Distinguishing relevant “neutral stimuli” from mere coincidental occurrences requires sophisticated filtering and context-awareness algorithms.
Data Acquisition and Interpretation
Training AI models for higher order conditioning demands vast amounts of precisely labeled data, documenting not just direct cause-and-effect relationships but also multi-step associative chains. Accurately identifying and categorizing these sequential triggers in noisy, dynamic environments is a significant hurdle. Advanced sensor fusion techniques and robust machine learning models capable of discerning subtle correlations from massive datasets are crucial.
Preventing Spurious Associations
AI systems must be designed to avoid learning spurious higher-order associations that are not truly predictive. Without careful validation and reinforcement learning mechanisms, a drone might associate an irrelevant visual cue (e.g., a specific shadow pattern) with an impending event, leading to erroneous or inefficient behaviors. This requires sophisticated algorithms that can assess the statistical significance and predictive power of observed correlations.

Transfer Learning and Generalization
The ultimate goal is for drones to generalize these higher-order learned associations across different environments and scenarios. A drone that learns to associate specific cloud formations with wind gusts in one region should ideally be able to apply that knowledge, with appropriate adjustments, in another. Advancements in transfer learning and meta-learning will be key to making higher order conditioning a scalable and robust feature of autonomous systems.
As AI research continues to push the boundaries of machine learning and cognitive architectures, the principles of higher order conditioning provide a powerful blueprint for developing drones that are not merely reactive but truly anticipatory, adaptive, and intelligent, capable of navigating and interacting with the world in increasingly sophisticated ways. The ability to form intricate, layered associations will be instrumental in the next generation of autonomous flight, making drones more resilient, efficient, and capable across an expanding array of applications.