
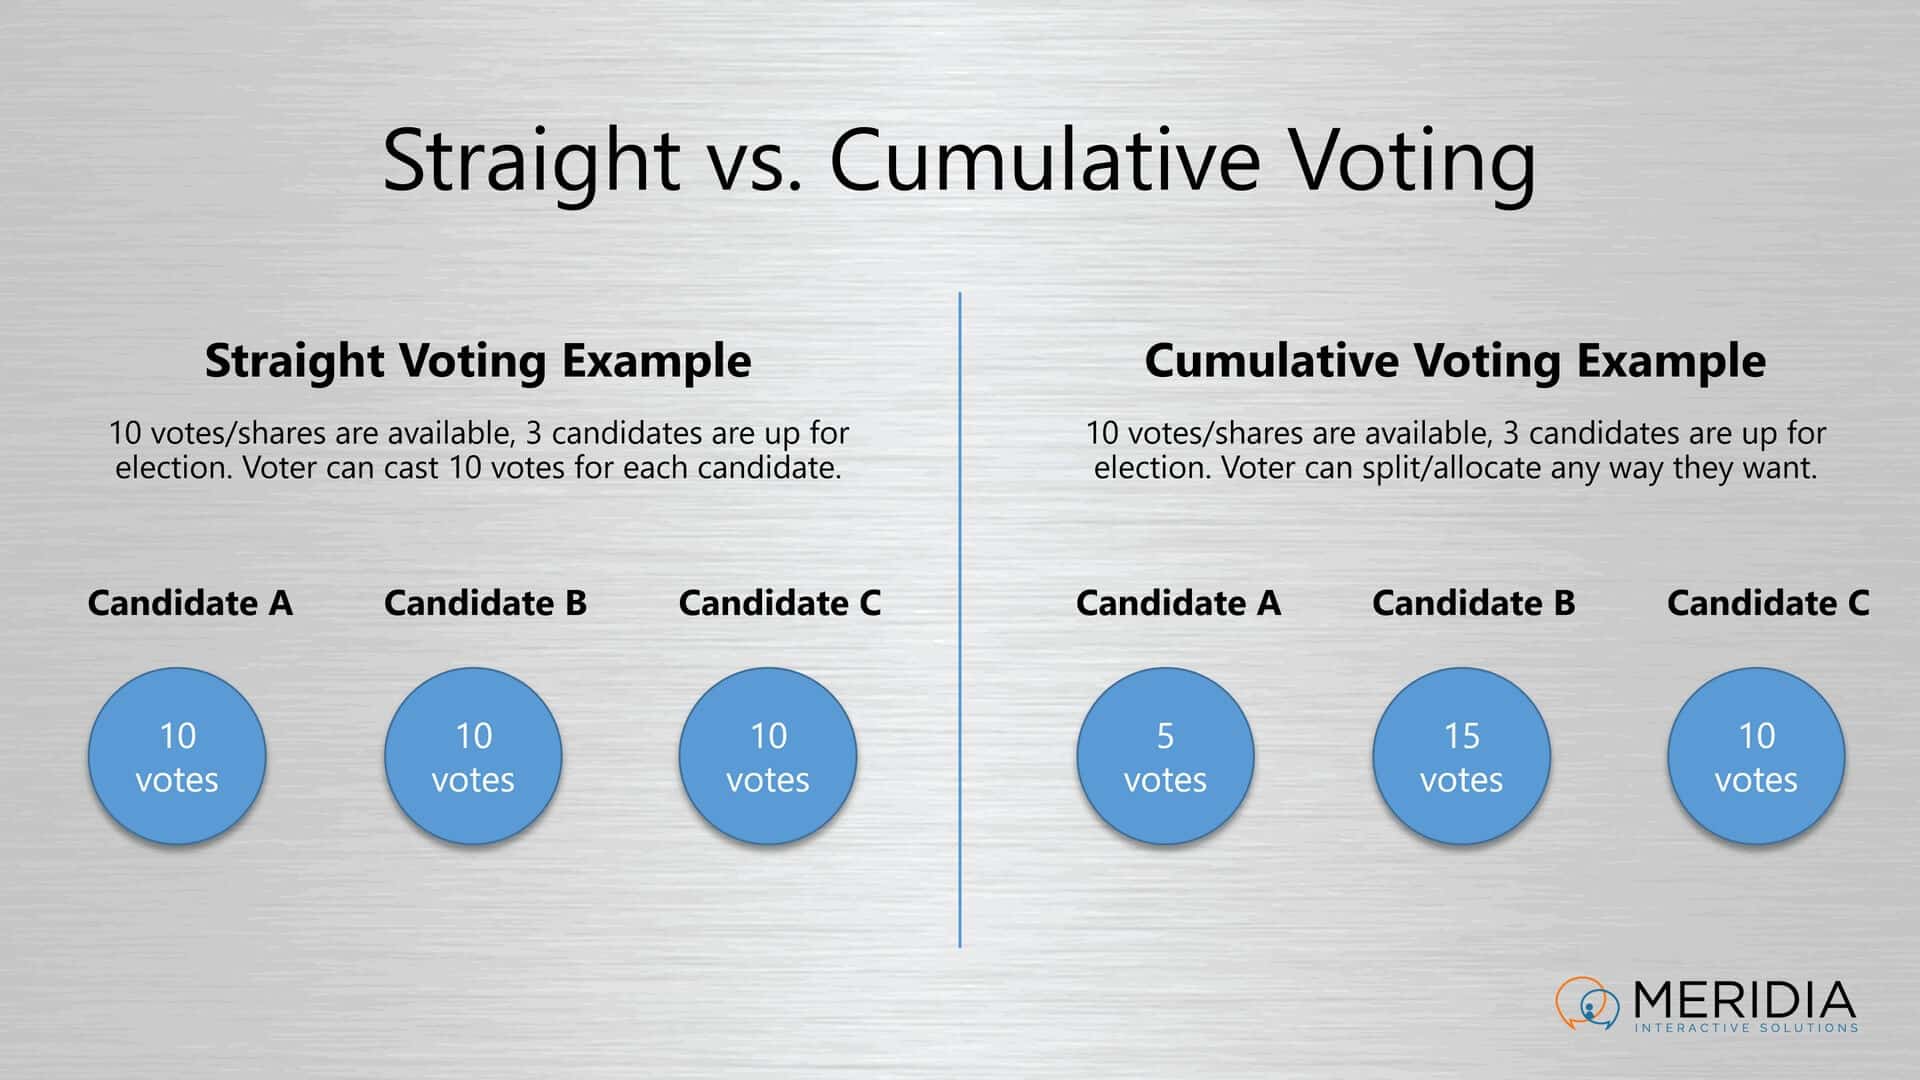
In the dynamic landscape of modern technology, particularly within the realms of AI, autonomous systems, and distributed intelligence, the concept of “cumulative voting” emerges not as a political or corporate governance mechanism, but as a sophisticated methodology for decentralized decision-making and robust data aggregation. Far from its traditional definition, in the context of Tech & Innovation, cumulative voting refers to an architectural pattern or an algorithmic approach where multiple entities or modules within a complex system contribute weighted inputs or preferences towards a collective decision, allowing for nuanced outcomes that transcend simple majority rule or single-point failures. It represents a paradigm shift towards incorporating diverse perspectives and confidence levels, leading to more resilient, adaptive, and intelligent systems.
The Principle of Distributed Decision-Making
At its core, cumulative voting in technology is about empowering distributed components to influence collective outcomes in a proportional or weighted manner. Instead of a binary “yes” or “no” from individual sensors or AI agents, this approach allows each contributor to express a spectrum of confidence, preference, or probability across multiple potential choices or interpretations. This richer input model moves beyond simple arbitration, facilitating a more granular and representative synthesis of available information.
Beyond Simple Majority: Nuance in Complex Systems
Traditional decision-making in automated systems often relies on straightforward majority votes or hierarchical arbitration. For instance, if three out of five sensors detect an obstacle, the system reacts. While effective for clear-cut scenarios, this method can fall short in environments characterized by ambiguity, conflicting data, or varying degrees of certainty. Cumulative voting addresses this by allowing “voters” (e.g., individual sensors, processing units, or AI sub-models) to allocate their “voting power” across several options. An optical sensor might give 70% confidence to “obstacle A” and 30% to “obstacle B,” while a radar might give 90% confidence to “obstacle A” and 10% to “no obstacle.” By aggregating these distributed, weighted preferences, the system gains a much finer-grained understanding of its environment, enabling more sophisticated and less abrupt responses. This nuanced aggregation is critical for autonomous systems operating in unpredictable real-world scenarios, where a simple majority might overlook critical edge cases or valuable minority insights.
Weighting Inputs for Robust Outcomes
A key aspect of cumulative voting is the assignment and aggregation of weights. Not all “votes” are created equal. In a technological system, these weights can be dynamically assigned based on a multitude of factors: a sensor’s historical accuracy, its current operational conditions (e.g., lighting for a camera, interference for a radar), the processing unit’s computational load, or the AI model’s training confidence. This dynamic weighting allows the system to prioritize inputs from more reliable or relevant sources at any given moment. For example, in poor visibility, a LiDAR sensor’s input might be weighted higher than an optical camera’s. In autonomous flight, if multiple flight controllers are monitoring different parameters, the one detecting an anomaly might have its “vote” for an emergency maneuver cumulatively weighted higher, even if other controllers report normal operation. This mechanism significantly enhances the robustness and fault tolerance of the overall system, as decisions are based on a weighted consensus that adapts to prevailing conditions rather than a rigid set of rules.
Applications in Autonomous Flight and Swarm Robotics
The principles of cumulative voting find particularly fertile ground in the development of highly complex and interconnected autonomous systems, such as those found in modern drone technology, autonomous vehicles, and robotic swarms. These applications demand real-time, adaptive decision-making capabilities that can effectively integrate diverse data streams and coordinate actions among multiple agents.
Sensor Fusion and Environmental Perception
In autonomous drones and vehicles, accurate environmental perception is paramount. Modern platforms integrate a multitude of sensors—LiDAR, radar, cameras (optical, thermal, multispectral), ultrasonic, and inertial measurement units (IMUs). Each sensor provides a unique perspective and has its own strengths and weaknesses depending on environmental conditions. Cumulative voting offers a powerful framework for sensor fusion, where data from these disparate sources are not merely combined but are collectively “voted” upon. Each sensor or its dedicated processing module can “cast” its confidence score or probability distribution for various environmental parameters (e.g., object detection, distance estimation, velocity tracking, terrain mapping). For instance, a camera might identify a tree with 85% certainty, while a LiDAR unit confirms its presence at a specific coordinate with 98% certainty, and a thermal camera registers a heat signature with 60% confidence. A cumulative voting algorithm would aggregate these weighted confidences to form a consolidated, highly robust perception of the environment. This prevents over-reliance on a single sensor, mitigates the impact of sensor failures or noise, and provides a richer, more reliable understanding of the operational space for flight navigation, obstacle avoidance, and mission planning.
Collaborative Path Planning and Resource Allocation
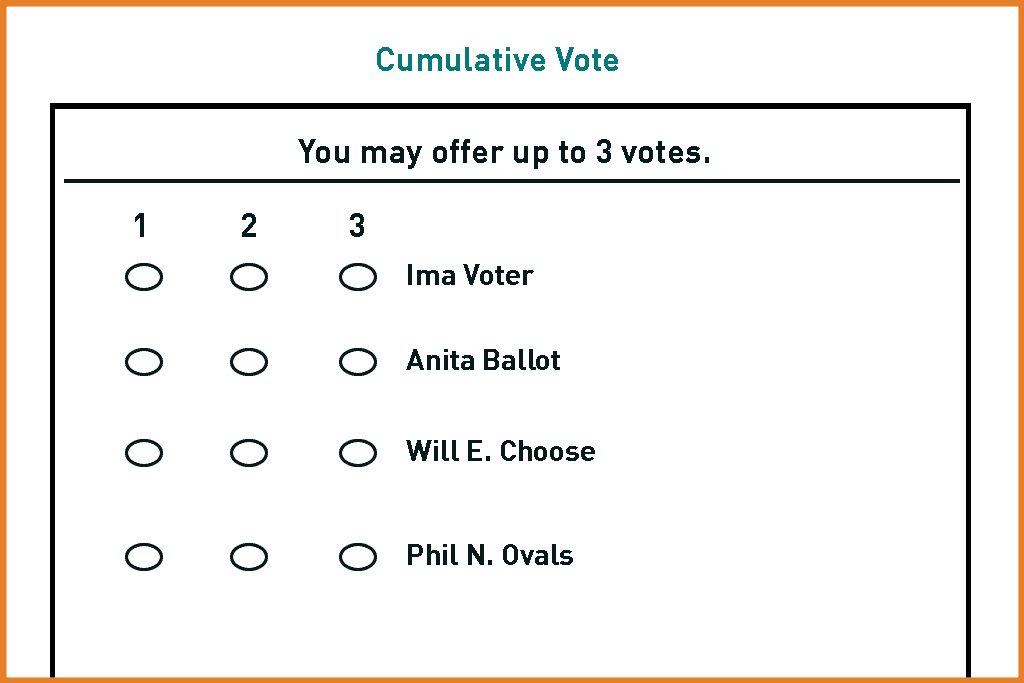
For swarm robotics or fleets of autonomous drones working in concert, cumulative voting can orchestrate collaborative decision-making. Imagine a group of drones tasked with mapping a large area or searching for survivors after a disaster. Each drone, acting as an independent agent, might identify potential points of interest, optimal flight paths, or areas requiring further investigation. Using a cumulative voting mechanism, individual drones can “vote” on preferred paths or resource allocations, distributing their preference across several options based on their local observations, battery levels, and mission objectives. A drone with ample battery might “vote” strongly for a longer, more comprehensive search path, while another with low power might “vote” for a more direct return route to a charging station. The collective “vote” would then generate a harmonized mission plan that optimizes overall efficiency, resource utilization, and task completion, ensuring that the swarm’s actions are a product of distributed intelligence rather than centralized command or simple individualistic pursuit. This enhances the swarm’s adaptability, robustness against individual agent failure, and overall effectiveness in complex, dynamic environments.
Enhancing AI and Machine Learning Models
Beyond sensor fusion and swarm coordination, the principles of cumulative voting are increasingly influencing the architecture and decision-making processes within artificial intelligence and machine learning, particularly in areas requiring high confidence, interpretability, and the ability to integrate diverse predictive insights.
Ensemble Learning and Predictive Confidence
In machine learning, ensemble methods combine the predictions of multiple individual models to achieve better predictive performance than any single model could on its own. Cumulative voting offers an advanced perspective on these ensemble techniques. Instead of merely averaging or taking a majority vote of individual model predictions, a cumulative voting approach allows each constituent model to “vote” for a range of outcomes with varying degrees of confidence. For example, in an image classification task, one neural network might predict “cat” with 90% confidence and “dog” with 10%, while another might predict “cat” with 80% and “fox” with 20%. A cumulative aggregation mechanism could then weigh these individual confidences, potentially learning to give more credence to models that have historically performed better in similar scenarios. This not only improves overall accuracy but also provides a more nuanced understanding of the system’s certainty about its predictions, which is crucial for high-stakes applications like medical diagnostics, autonomous vehicle perception, or critical infrastructure monitoring. By distributing confidence across possibilities, the system can express uncertainty rather than forcing a single, potentially incorrect, definitive answer.
Human-in-the-Loop Integration and Preference Aggregation
As AI systems become more pervasive, the challenge of effectively integrating human oversight and preferences becomes critical. Cumulative voting can serve as a powerful framework for human-in-the-loop (HITL) systems, allowing human operators to express nuanced preferences or validate AI-generated options. For instance, in an AI-assisted design tool or a planning system for drone delivery routes, the AI might generate several optimal solutions. Instead of simply selecting one, a human operator could “cumulatively vote” by assigning preference scores or weights to different aspects of each solution (e.g., speed, cost, environmental impact, aesthetic appeal). These human preferences can then be aggregated with the AI’s internal metrics to arrive at a final decision that is not only computationally optimal but also aligned with human values and practical constraints. This approach democratizes the decision-making process within intelligent systems, making them more adaptive to subjective criteria and user requirements, thereby enhancing trust and usability. It transforms the human role from a simple override mechanism to an integral, weighted contributor to the system’s collective intelligence.
Challenges and Future Directions
While the application of cumulative voting principles in Tech & Innovation offers significant advantages, its implementation is not without challenges, necessitating ongoing research and development in several key areas.
Scalability and Real-time Processing
Implementing cumulative voting in highly distributed, real-time autonomous systems, such as large drone swarms or high-speed autonomous vehicles, presents considerable computational hurdles. The aggregation and weighting of numerous, continuously updated “votes” from potentially hundreds or thousands of sources require immense processing power and efficient communication protocols. Ensuring low-latency decision-making, especially in safety-critical applications, demands optimized algorithms and hardware architectures capable of parallel processing and distributed computation. Future advancements will likely focus on developing lightweight, adaptive cumulative voting protocols that can scale effectively with increasing system complexity and data velocity, potentially leveraging edge computing and specialized AI accelerators to process “votes” closer to their source.

Explainability and Bias Mitigation
As with many advanced AI techniques, the interpretability of decisions made through cumulative voting mechanisms can be challenging. Understanding why a particular weighted consensus was reached from a multitude of distributed preferences can be complex, especially when weights are dynamically adjusted. This lack of explainability can hinder debugging, auditing, and regulatory compliance. Future research must focus on developing methods to visualize and articulate the contributions of individual “voters” (sensors, models, agents) to the final cumulative decision. Furthermore, like any system aggregating inputs, cumulative voting is susceptible to bias if the underlying “voters” or their assigned weights carry inherent biases. For example, if certain sensors are consistently over-weighted due to an initial design flaw, their biases will disproportionately influence the collective outcome. Mitigating bias requires careful design of weighting schemes, continuous calibration of contributing modules, and robust validation processes to ensure fairness and accuracy in the aggregated decisions. Addressing these challenges will pave the way for more transparent, trustworthy, and effective deployment of cumulative voting principles in the next generation of intelligent technologies.