
In the rapidly evolving landscape of drone technology, particularly within advanced applications like mapping, remote sensing, and the creation of digital twins, understanding the underlying principles of 3D model construction is paramount. At the heart of creating visually coherent and information-rich 3D models from drone-captured data lies a fundamental concept known as a UV map. Far from being a mere technical detail, a well-executed UV map is the bedrock upon which realistic textures are applied, transforming raw geometric data into an interpretable and immersive visual representation of the real world.
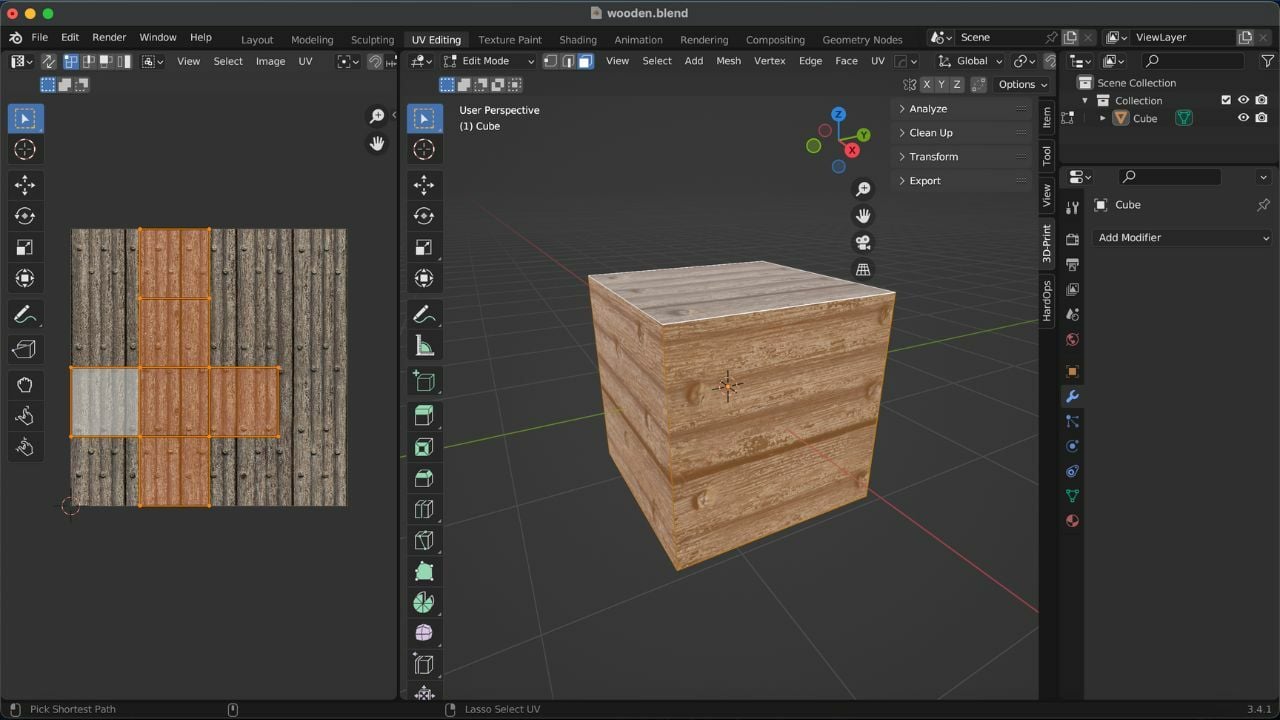
A UV map serves as the critical bridge between a three-dimensional model and its two-dimensional texture. Imagine a complex object, such as a building or a terrain feature captured by a drone. This object, in its digital form, is a 3D mesh composed of vertices, edges, and faces. To make this mesh appear realistic, it needs surface detail – color, patterns, and environmental cues. These details are typically stored in a 2D image file, often referred to as a texture map or diffuse map. A UV map dictates how that 2D image “wraps around” the 3D object, ensuring that the texture aligns correctly with the geometry. Without it, textures would be stretched, distorted, or misaligned, rendering the 3D model visually inaccurate and undermining its utility for analysis, simulation, or visualization.
The Fundamentals of UV Mapping
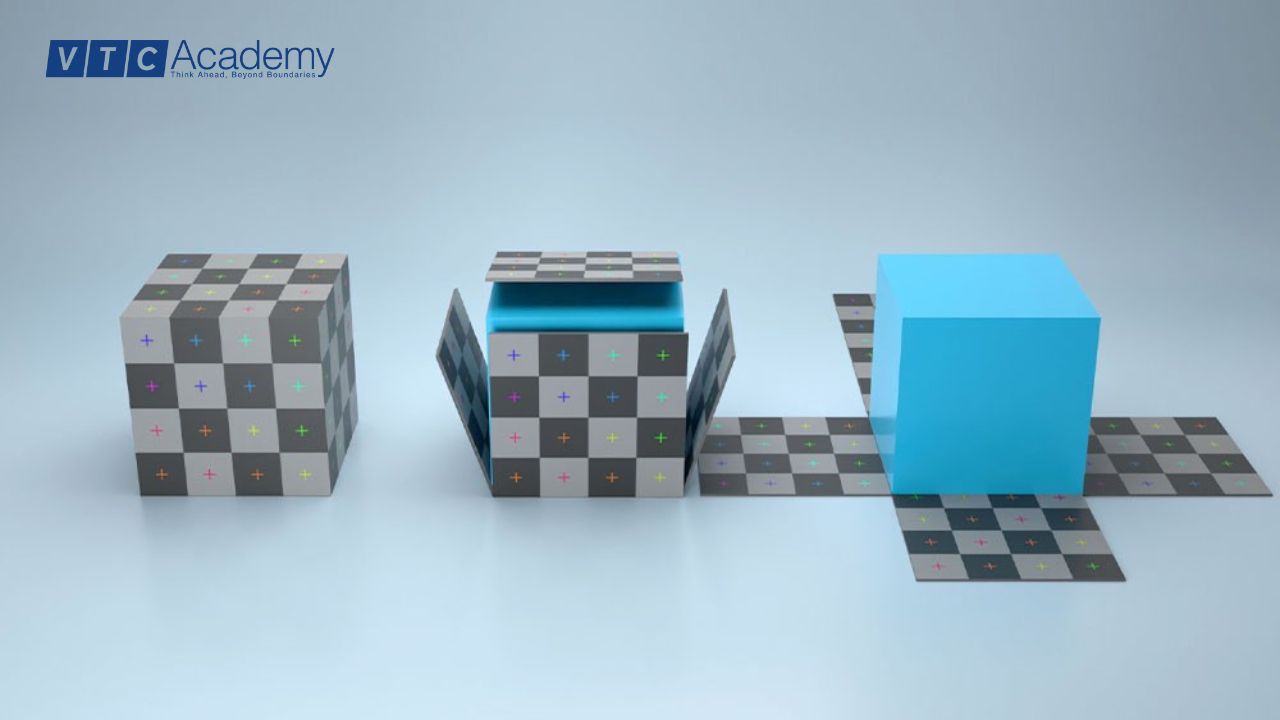
At its core, UV mapping involves projecting a 3D object’s surface onto a 2D plane. This process is often likened to taking a 3D paper model, carefully cutting along its seams, and flattening it out into a 2D pattern. Each point on the 3D model’s surface is assigned a corresponding coordinate on this 2D plane. These 2D coordinates are traditionally denoted as U and V, hence the term “UV map,” to distinguish them from the X, Y, and Z coordinates used for the 3D geometry itself. The U coordinate typically represents the horizontal axis on the 2D texture, while V represents the vertical axis.
Unwrapping and Seams
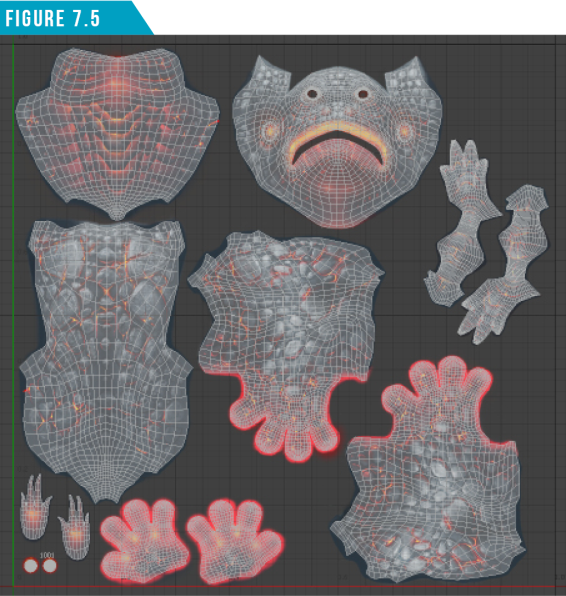
The process of creating a UV map is called “unwrapping.” For complex 3D objects, especially those generated from photogrammetry, unwrapping involves strategically placing “seams” on the 3D model. These seams define where the 3D surface will be cut to allow it to be flattened without excessive stretching or compression. The goal is to create a 2D layout where each polygon of the 3D mesh has a unique, non-overlapping space on the UV map, and where the texture distortion is minimized. A well-designed UV layout maximizes the use of the 2D texture space, leading to higher texture resolution and visual fidelity on the 3D model.
Texture Atlases and Pixel Density
When dealing with large-scale drone mapping projects, multiple texture images might be generated. These are often combined into a single, larger image called a “texture atlas.” The UV map then points to specific regions within this atlas for different parts of the 3D model. The quality of a UV map also directly impacts the pixel density—the number of texture pixels per unit of 3D surface area. A well-optimized UV map ensures that critical features or highly visible areas of the 3D model receive a higher pixel density, translating to sharper details and more realistic rendering, which is crucial for the precise visualization required in mapping and inspection tasks.
UV Mapping in the Context of Drone Mapping and Remote Sensing
The utility of UV maps becomes profoundly clear when considering their role in processing data acquired through drone-based mapping and remote sensing. Drones equipped with high-resolution cameras capture vast quantities of overlapping aerial imagery. This imagery serves as the raw input for photogrammetry software, which processes these 2D images to construct detailed 3D models of terrain, structures, and environments.
Photogrammetry and 3D Model Generation
In photogrammetry workflows, software stitches together hundreds or thousands of individual drone images to generate a dense point cloud, which is then converted into a textured 3D mesh. During this process, the software automatically creates a UV map. The captured drone images themselves become the source for the textures. The photogrammetry algorithm intelligently projects these 2D images onto the reconstructed 3D surface, effectively creating the UV coordinates that dictate where each pixel from the original images should land on the 3D model. This automated process is a cornerstone of modern drone mapping, allowing for the rapid creation of realistic digital representations without manual UV manipulation.
Orthoimages as Texture Sources
Often, the drone imagery is first processed into an orthomosaic—a geo-referenced, high-resolution image of an area where all geometric distortion from topography and camera tilt has been removed. While an orthomosaic itself is a 2D map, it frequently serves as the primary texture source for 3D models generated from the same drone flight. The UV map then correctly applies sections of this orthoimage onto the corresponding parts of the 3D mesh, ensuring consistent and accurate surface detailing across the entire model. This integration ensures that the visual data from the drone’s perspective is seamlessly transferred to the 3D digital environment.
Why UV Maps Are Critical for Accurate and Realistic Drone-Derived Models
The accuracy and realism of 3D models derived from drone data are not solely dependent on the precision of the geometric mesh; they are equally reliant on the quality and fidelity of their textures, which are managed by UV maps. For applications ranging from urban planning and construction monitoring to environmental analysis and infrastructure inspection, a model’s visual integrity directly impacts its analytical value.
Enhancing Visual Fidelity and Data Interpretation
A well-constructed UV map ensures that the textures derived from drone imagery are applied without distortion, preserving the intricate details captured by the camera. This visual fidelity is crucial for tasks like identifying defects on building facades, tracking changes in land use, or assessing vegetation health. Distorted textures, a common symptom of poor UV mapping, can obscure critical features, lead to misinterpretations, and ultimately compromise the accuracy of data extraction. When inspecting infrastructure or mapping complex urban environments, the ability to zoom in on a 3D model and clearly discern features like cracks, structural anomalies, or specific plant species is directly enabled by effective UV mapping.
Precision in Digital Twins and Simulations
The concept of a “digital twin” – a virtual replica of a physical asset or system – is gaining significant traction in drone-based applications. Creating an accurate digital twin of a construction site, an industrial plant, or an entire city requires 3D models that are both geometrically precise and visually authentic. UV maps are indispensable in achieving this authenticity. They ensure that photographic textures, complete with all their nuances like paint colors, material surfaces, and environmental wear, are faithfully represented on the digital twin. This realism is not just aesthetic; it’s functional, enabling stakeholders to conduct virtual inspections, plan modifications, and run simulations with a high degree of confidence that the digital model accurately mirrors its real-world counterpart.
Overcoming Challenges: Texture Seams and Resolution
One common challenge in drone-derived 3D models relates to texture seams, which can appear as visible lines or inconsistencies where different parts of the texture atlas meet on the 3D model. While photogrammetry software automates much of this, complex geometries or inconsistent lighting conditions during drone capture can exacerbate these issues. Advanced UV mapping techniques, often involving texture blending and intelligent seam placement, help mitigate these visual artifacts. Furthermore, the resolution of the UV map—how much 2D texture space is allocated to different parts of the 3D model—directly impacts the level of detail that can be displayed. Ensuring sufficient texture resolution, especially for areas of interest, is a key consideration enabled by intelligent UV layout.
The Workflow: From Drone Capture to Textured 3D Model
The journey from raw drone footage to a fully textured 3D model, complete with an optimized UV map, typically follows a systematic workflow. Each step builds upon the last, culminating in a digital asset that is ready for analysis, visualization, or integration into other platforms.
Data Acquisition and Pre-processing
The process begins with meticulous drone flight planning and data acquisition. Drones equipped with high-resolution RGB cameras capture overlapping images of the target area, often following pre-programmed flight paths to ensure comprehensive coverage and optimal image overlap (typically 70-80% frontal and side overlap). Post-flight, these images undergo initial pre-processing, which may include geo-tagging, color correction, and removal of blurry or unsuitable images.
Photogrammetry Software Processing
The pre-processed drone images are then fed into specialized photogrammetry software (e.g., Agisoft Metashape, Pix4Dmapper, RealityCapture). This software performs several critical functions:
- Image Alignment and Sparse Point Cloud Generation: The software identifies common features across multiple overlapping images to determine the camera positions and orientations for each photo. This process generates a sparse point cloud.
- Dense Point Cloud Creation: From the sparse cloud, a much denser point cloud is generated, representing millions of accurate 3D points on the object or terrain surface.
- Mesh Generation: The dense point cloud is converted into a continuous 3D mesh, typically composed of triangular faces. This mesh defines the geometric shape of the captured environment.
- Texture Generation and UV Mapping: This is where UV mapping becomes integral. The software projects the original drone images onto the newly created 3D mesh. It intelligently calculates the UV coordinates for each face of the mesh, effectively unwrapping the 3D surface onto a 2D texture space. The colors and details from the drone imagery are then baked onto this 2D UV layout, creating the final texture map. This automated process minimizes manual intervention, making it highly efficient for large-scale drone mapping projects.
Model Refinement and Export
Once the initial textured 3D model is generated, it can undergo further refinement. This might involve cleaning up noise, simplifying the mesh to reduce file size without significant loss of detail, or making minor adjustments to the UV map if specific texture issues are identified. Finally, the complete 3D model, comprising the geometric mesh, the UV map, and the associated texture files, is exported in standard formats such as OBJ, FBX, or GLB, ready for use in various applications, from CAD software and game engines to web-based visualization platforms and digital twin environments. The integrity of the UV map throughout this workflow is paramount to ensuring the final model is a true and usable representation of the drone-captured reality.