
In the dynamic world of drone technology and innovation, understanding fundamental mathematical concepts can unlock deeper insights into how these sophisticated machines operate, navigate, and perform complex tasks. While “what does a quadratic function look like?” might initially seem like a question from a mathematics textbook, its implications are profoundly woven into the algorithms, physics, and engineering that enable autonomous flight, intelligent navigation, and advanced data processing in UAVs. At its core, a quadratic function paints a distinctive visual pattern, a parabolic curve, that is far more relevant to drone tech than one might imagine.
The Fundamental Shape: The Parabola
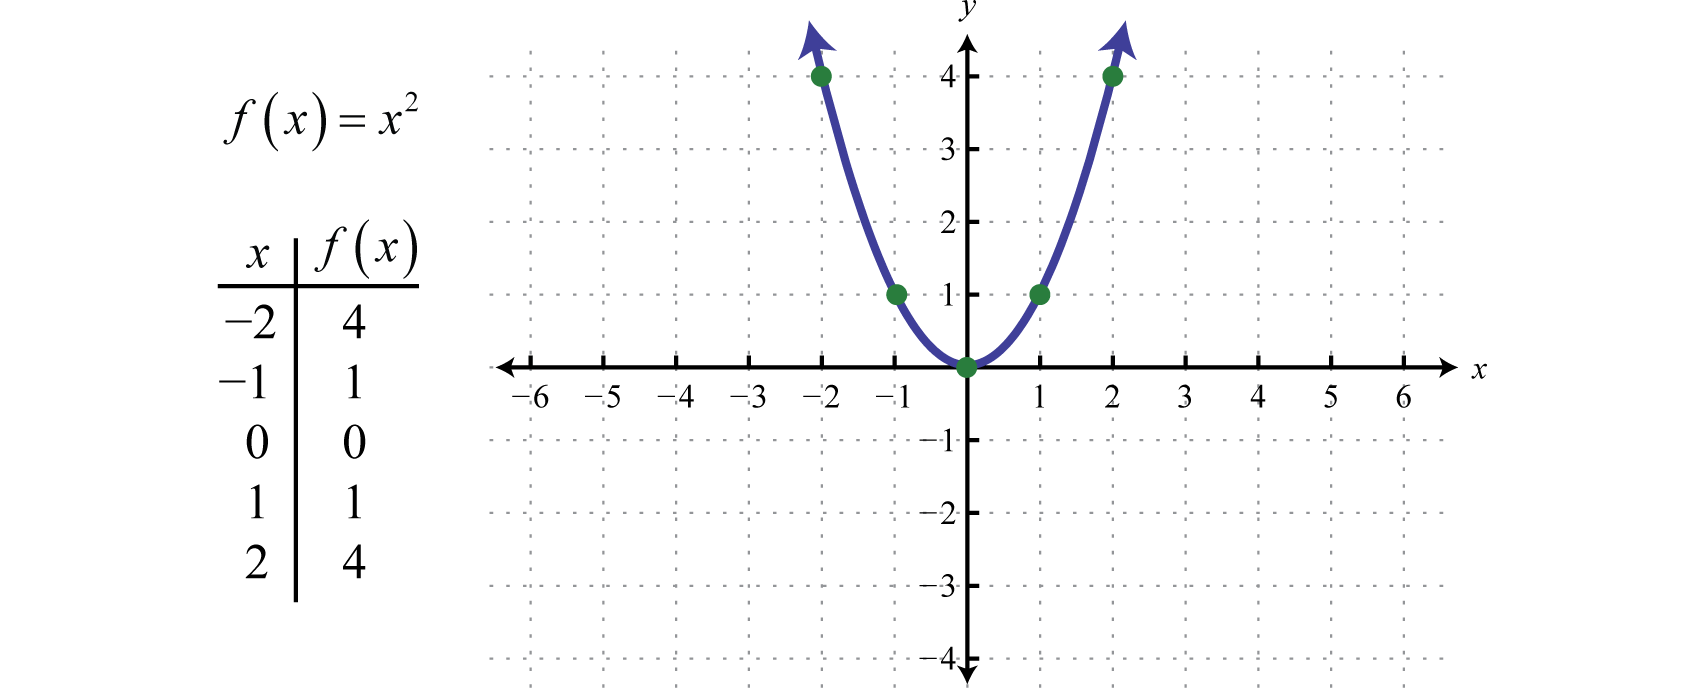
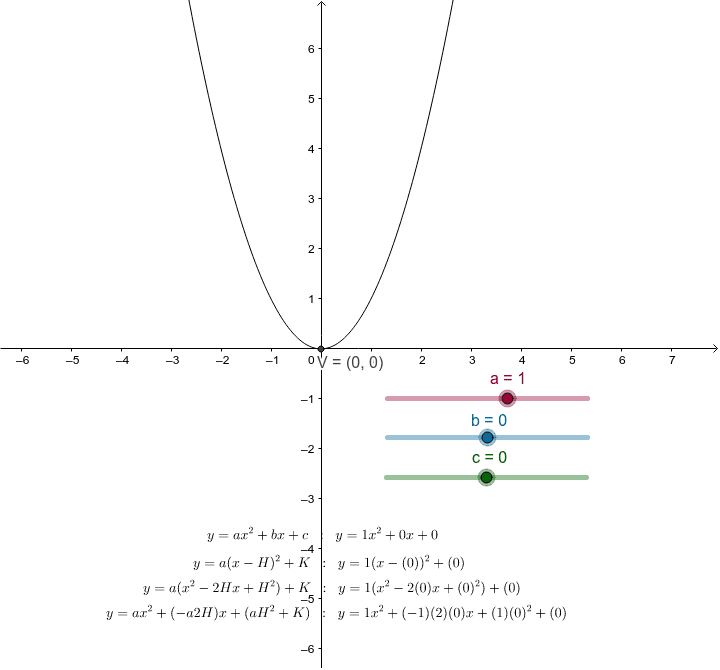
A quadratic function is a polynomial function of degree two, meaning the highest exponent of the variable (typically ‘x’) is 2. Its general form is expressed as y = ax^2 + bx + c, where ‘a’, ‘b’, and ‘c’ are constants, and ‘a’ cannot be zero. When graphed, a quadratic function always forms a symmetrical U-shaped curve known as a parabola.
The appearance of this parabola is dictated by the coefficient ‘a’:
- If
a > 0, the parabola opens upwards, resembling a smiling face or a valley. This indicates a minimum point, known as the vertex, at the bottom of the curve. - If
a < 0, the parabola opens downwards, like a frowning face or a hill. In this case, the vertex represents a maximum point at the top of the curve.
Key visual features of a parabola include:
- Vertex: The turning point of the parabola, where the curve changes direction. This is either the absolute minimum or maximum value of the function.
- Axis of Symmetry: A vertical line that passes through the vertex, dividing the parabola into two mirror-image halves.
- Intercepts: Points where the parabola crosses the x-axis (x-intercepts or roots) and the y-axis (y-intercept). These points provide critical information about the function’s behavior.
From a purely visual perspective, a quadratic function looks like a smooth, continuous arc. This seemingly simple curve is, however, the mathematical backbone for many natural phenomena and engineered systems, including the ballistic trajectory of projectiles – a concept highly pertinent to understanding how objects, including drones, move through the air under gravity.
Quadratic Functions in Drone Trajectory and Path Planning
The elegant curve of a parabola is not merely an abstract mathematical concept; it represents a fundamental principle in physics that directly applies to drone flight. Understanding quadratic functions helps engineers design smoother, more efficient, and safer flight paths for unmanned aerial vehicles (UAVs).
Modeling Flight Paths
Consider the simple physics of an object in freefall or a projectile launched into the air. Ignoring air resistance, the path it traces is a perfect parabola. While drones are powered and can actively resist gravity, this parabolic characteristic is still crucial for specific maneuvers or for understanding certain aspects of their flight envelope. For instance, in applications like package delivery drones, a carefully calculated parabolic descent or ascent might be more energy-efficient or visually appealing than a direct linear path, especially when considering the approach to a target. Engineers can design flight profiles that incorporate quadratic segments to ensure smooth acceleration and deceleration, preventing jerky movements that could destabilize the drone or its payload.
Waypoint Navigation and Curve Fitting
Modern autonomous drones rely heavily on waypoint navigation, where a series of GPS coordinates defines a desired route. Simply flying in straight lines between these points can result in abrupt changes in direction and speed, leading to inefficiency and potential instability. Here, quadratic functions, often as part of higher-order polynomial splines, come into play for curve fitting. By using quadratic interpolation, the drone’s flight control system can generate smooth, continuous curves that connect waypoints. This creates a much more natural and energy-efficient trajectory. For aerial filmmaking, such smooth, predictable arcs are essential for cinematic shots, allowing the drone to follow a subject or orbit a point with fluidity and precision, enhancing the visual quality of the captured footage. The algorithms determining these smooth paths often minimize a “cost function” that includes quadratic terms related to acceleration and jerk, thereby optimizing for flight comfort and energy consumption.
Obstacle Avoidance Trajectories
In dynamic environments, obstacle avoidance is a critical capability for autonomous drones. When a drone detects an obstacle, it doesn’t simply stop or sharply change direction; it must calculate a safe and smooth detour. Quadratic functions can be used to model potential escape trajectories that smoothly arc over, under, or around an impediment. The drone’s onboard processing unit might assess various parabolic paths, considering its current speed, altitude, and available thrust, to find the most optimal quadratic path that clears the obstacle while minimizing deviations from its original course. This real-time calculation of smooth, curved evasion paths is a hallmark of advanced autonomous flight systems, ensuring both safety and mission continuity.
Data Processing and Sensor Interpretation

Beyond trajectory planning, the distinct shape and mathematical properties of quadratic functions are fundamental in how drones process data from their myriad sensors and interpret their environment. This underpins the accuracy and reliability of autonomous operations.
Calibration Curves
Drone sensors, from altimeters and accelerometers to magnetometers, are not always perfectly linear in their output. Environmental factors, manufacturing variances, or sensor aging can introduce non-linearities. To compensate for these imperfections and ensure accurate readings, engineers develop calibration curves. Often, these curves are modeled using quadratic functions (or higher-order polynomials that include quadratic terms). By fitting a quadratic function to the measured sensor output versus known input values, the drone’s flight controller can correct raw sensor data, transforming it into precise and reliable information about its orientation, speed, altitude, and position. This meticulous calibration, often relying on quadratic modeling, is vital for stable flight and accurate navigation.
Signal Filtering and Noise Reduction
In complex environments, drone sensors are constantly bombarded with noise and extraneous signals. Filtering these signals is crucial for extracting meaningful data. While many filters are linear, advanced estimation techniques like the Kalman filter, widely used in drone navigation and state estimation, fundamentally rely on quadratic forms. The Kalman filter optimally estimates the state of a system (e.g., position, velocity, orientation) by minimizing the mean squared error—a quadratic cost function—between predicted and measured values. This iterative process, leveraging quadratic mathematics, allows drones to fuse data from multiple noisy sensors (GPS, IMU, barometer) into a single, highly accurate, and robust estimate of its current state, enabling reliable autonomous flight even in challenging conditions.
Image Processing and Computer Vision
The ability of drones to “see” and understand their environment is powered by sophisticated computer vision algorithms. Quadratic functions play a subtle yet important role here. In tasks like lens distortion correction, where camera lenses can introduce barrel or pincushion effects, quadratic polynomial models are often used to map distorted image coordinates back to their true positions. Furthermore, in object detection and tracking, algorithms might fit quadratic curves to the boundaries of detected objects or to the predicted path of a moving target. For instance, if a drone is tracking a person (AI follow mode), predicting the subject’s future position often involves projecting their current velocity and acceleration over time, which can involve quadratic equations for motion under changing speed.
Optimization and Control Systems
The pursuit of efficiency, stability, and intelligent behavior in drones invariably leads to optimization problems. Many of these problems are naturally expressed and solved using quadratic functions, forming the bedrock of advanced control theory and artificial intelligence applications in UAVs.
Energy Efficiency
Maximizing a drone’s flight time and range is paramount. Achieving optimal energy efficiency often involves finding the “sweet spot” for parameters like flight speed, altitude, or motor RPM. The relationship between these parameters and energy consumption is frequently non-linear, and in many cases, can be approximated or modeled using quadratic functions. For example, aerodynamic drag, a major factor in energy consumption, often increases quadratically with airspeed. An optimization algorithm might seek to minimize a quadratic cost function representing energy usage, finding the velocity that yields the longest flight duration for a given battery capacity. This analysis, rooted in quadratic principles, allows drone systems to make intelligent decisions to conserve power.
PID Controllers and Quadratic Cost
While proportional-integral-derivative (PID) controllers are widely used in drones for their simplicity and effectiveness in stabilizing flight, more advanced control strategies delve deeper into mathematical optimization. Techniques like Linear Quadratic Regulator (LQR) control and Model Predictive Control (MPC) are heavily reliant on quadratic cost functions. LQR, for instance, seeks to find a control law that minimizes a quadratic cost function that penalizes deviations from the desired state (e.g., maintaining a specific altitude or heading) and the control effort (e.g., motor power). By minimizing these quadratic penalties, the system achieves optimal performance, characterized by smooth, stable, and responsive flight. These sophisticated controllers, drawing heavily from quadratic optimization, are crucial for larger, more complex drones performing critical missions.
Machine Learning and AI Algorithms
The “intelligence” of a drone, from its AI follow mode to autonomous decision-making in complex environments, is increasingly driven by machine learning algorithms. Many foundational machine learning models, particularly in supervised learning and neural networks, rely on optimizing objective functions that are quadratic in nature. For instance, the widely used Mean Squared Error (MSE) cost function, which measures the average squared difference between predicted and actual values, is a quadratic function. Minimizing MSE is a cornerstone of training models for tasks like object recognition, predictive analytics (e.g., predicting environmental changes), and system identification. The “gradient descent” algorithms used to train these models iteratively adjust parameters to find the minimum of these quadratic (or near-quadratic) loss surfaces, allowing drones to learn from data, adapt to new situations, and perform increasingly sophisticated autonomous tasks.
In summary, a quadratic function looks like a parabola—a simple, elegant curve. Yet, this shape and its mathematical properties are silently at work across the spectrum of drone technology and innovation, from guiding precise flight paths and refining sensor data to powering complex AI algorithms and optimizing energy consumption. Its pervasive presence underscores the fundamental role of mathematics in shaping the future of autonomous systems.