
In the dynamic realm of drone technology and innovation, the concept of “loops” underpins almost every intelligent function, from stable flight to sophisticated autonomous missions and intricate data analysis. Far more than just a programming construct, loops represent the cyclical processes of sensing, decision-making, and action that empower unmanned aerial vehicles (UAVs) to operate with unprecedented levels of autonomy and intelligence. Understanding loops is crucial for grasping the foundational mechanics of AI follow modes, precise mapping, remote sensing, and the very essence of autonomous flight.
The Fundamental Concept of Loops in Computing
At its most basic, a loop in computing is a sequence of instructions that is continually repeated until a certain condition is met. This fundamental principle of iteration is the backbone of all modern software, allowing complex tasks to be broken down into manageable, repetitive steps. Without loops, the computational power required for even simple tasks would be astronomical, and the development of intricate algorithms for drones would be impossible.
Iteration: The Core Principle
Iteration is the process of repeating a sequence of operations or calculations, often with the aim of approaching a desired result or processing a collection of data. In the context of drone software, iteration manifests in countless ways. A drone’s flight controller, for instance, continuously iterates through sensor readings, calculates necessary adjustments, and sends commands to motors. Similarly, an object detection algorithm might iterate through pixels in an image to identify patterns, or a mapping application might iterate through thousands of GPS data points to build a coherent representation of terrain. This constant, rapid repetition is what gives drones their agility and intelligence.
Types of Loops: A Primer
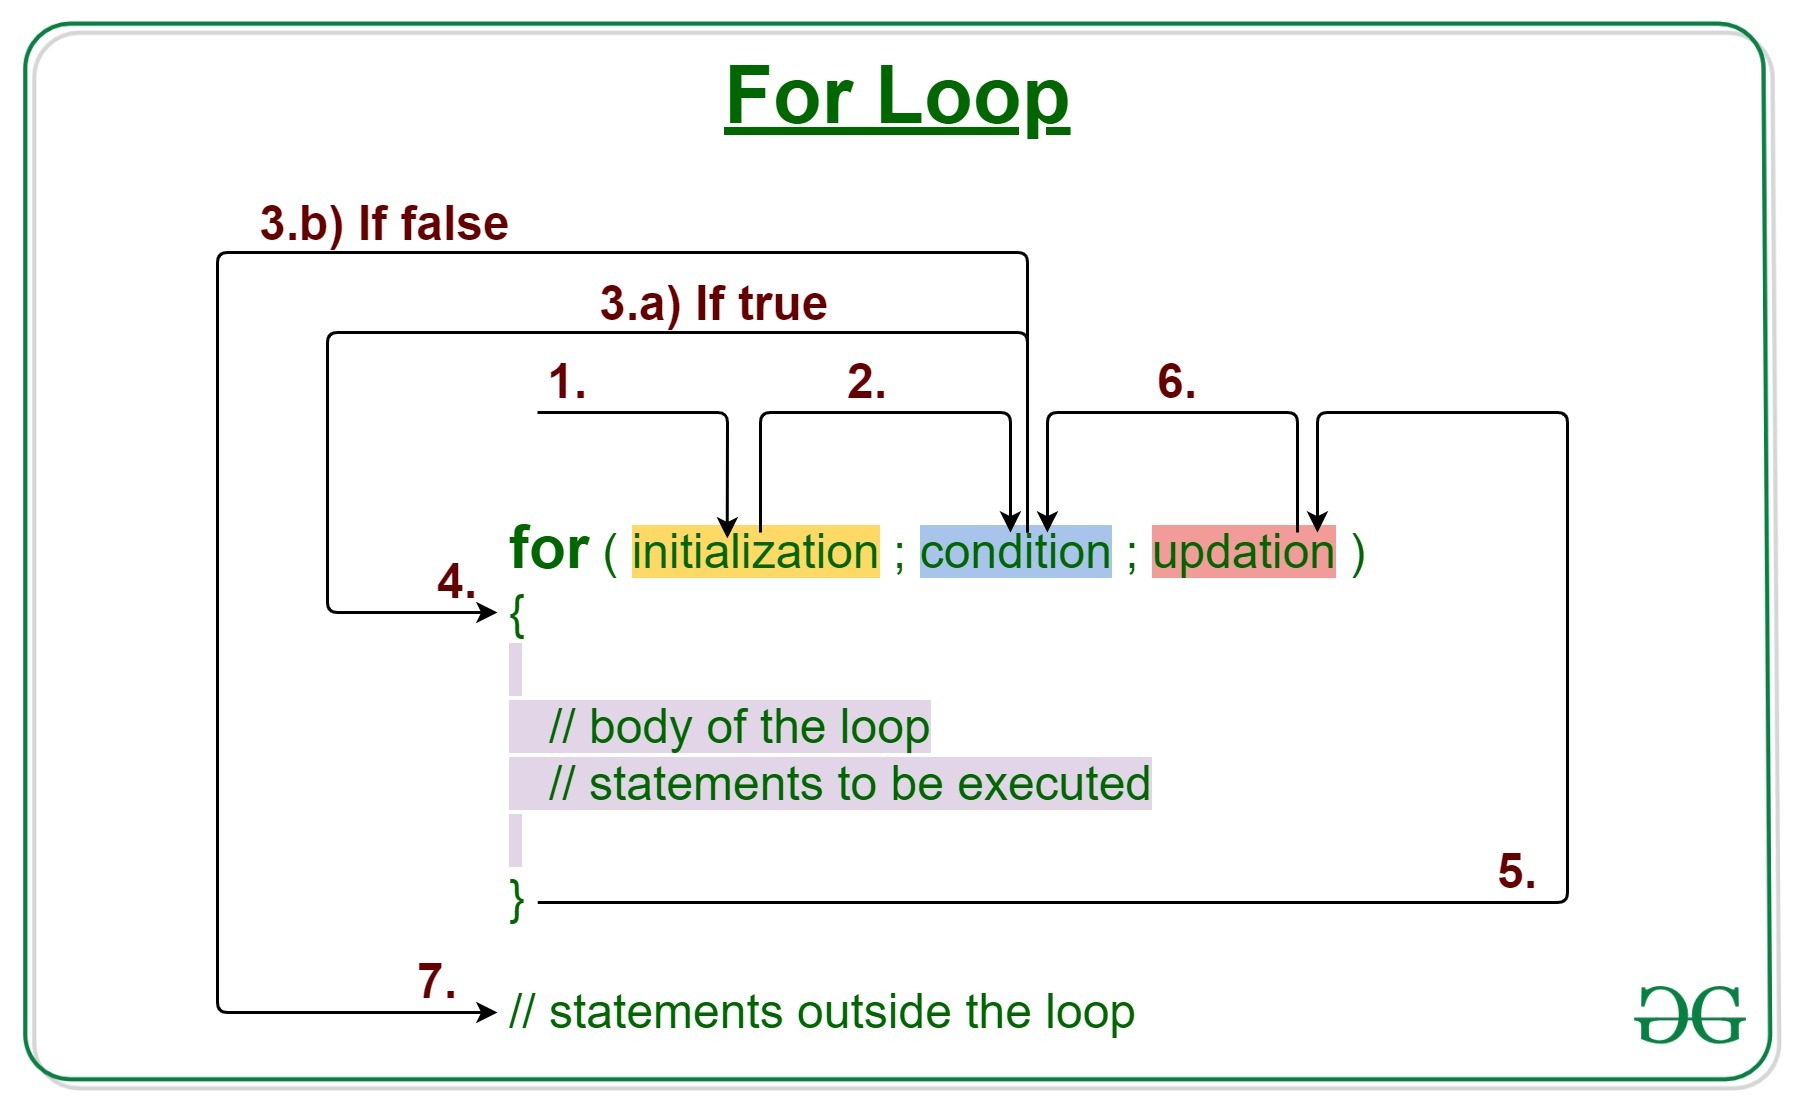
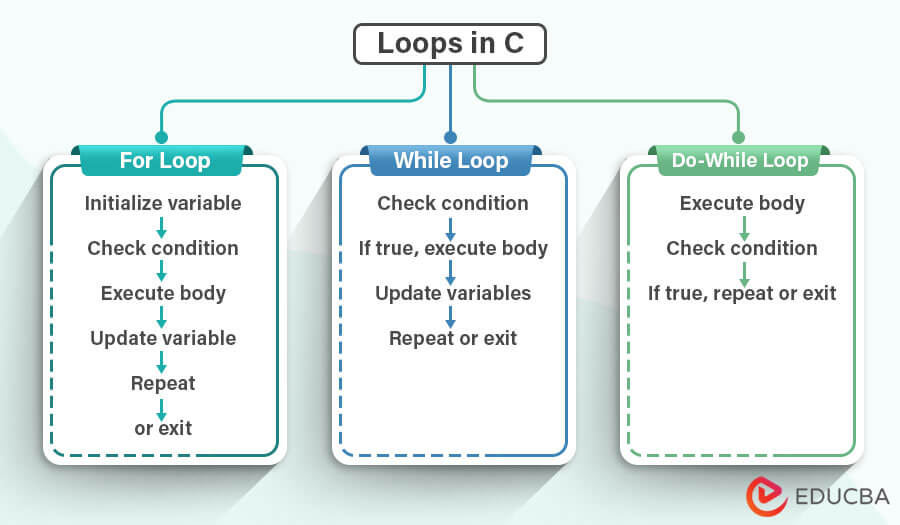
While the specifics vary across programming languages, the most common types of loops include for loops, while loops, and do-while loops.
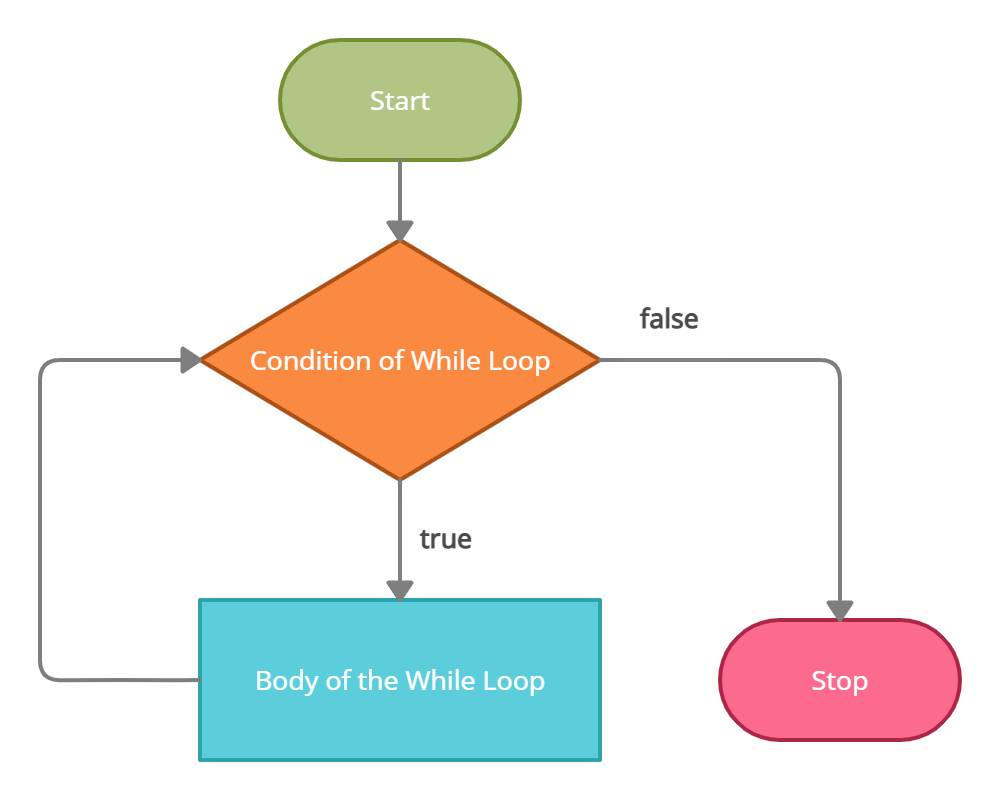
Forloops are typically used when the number of iterations is known in advance, such as processing a fixed array of sensor data or performing a specific maneuver a set number of times.Whileloops continue to execute as long as a specified condition remains true, making them ideal for tasks like maintaining altitude (while altitude is not target_altitude), or searching for a specific target (while target not found).Do-whileloops are similar towhileloops but guarantee at least one execution of the loop body before checking the condition, often used in scenarios requiring an initial action before validation.
These programming constructs are the building blocks that allow drone engineers to write efficient code that manages everything from motor speed and camera orientation to complex navigation and data processing routines.
Why Loops Are Indispensable for Software
Loops are indispensable because they enable automation, efficiency, and adaptability. They eliminate the need for redundant code, making software more concise and maintainable. More importantly, in drone technology, loops are the mechanism by which systems can continuously monitor their environment, adapt to changing conditions, and execute persistent tasks. Whether it’s the continuous polling of a GPS module, the iterative refinement of a navigation path, or the ongoing analysis of environmental data, loops ensure that the drone’s intelligence is always active and responsive.
Control Loops: The Brains of Autonomous Flight
Beyond the general programming concept, “control loops” represent a critical category within drone technology, especially pertinent to autonomous flight and stabilization. A control loop is a fundamental engineering concept where a system continuously measures an output, compares it to a desired input, and then makes adjustments to minimize the difference. This feedback mechanism is what gives drones their remarkable stability and precision.
Sensing, Processing, Actuation: A Continuous Cycle
Every autonomous drone operates on a fundamental control loop:
- Sensing: The drone’s array of sensors (IMUs, GPS, altimeters, cameras, LiDAR) constantly collects data about its state (position, velocity, orientation) and environment.
- Processing: This raw data is fed into the flight controller or onboard computer, where algorithms process it. This involves filtering noise, integrating various sensor inputs, and calculating the drone’s current state relative to its desired state (e.g., how far off course it is, or how much it’s tilting).
- Actuation: Based on the processing results, the system generates commands (actuation signals) that are sent to the drone’s actuators—primarily the motors and propellers—to correct any discrepancies and move the drone closer to its desired state.
This cycle repeats hundreds, often thousands, of times per second, forming an incredibly tight and responsive control loop that keeps the drone stable, on path, and performing its intended functions.
PID Controllers: The Ubiquitous Example
Perhaps the most common and effective example of a control loop in drone flight is the Proportional-Integral-Derivative (PID) controller. PID loops are widely used in flight controllers to maintain stability and control for attitude (pitch, roll, yaw), altitude, and position.
- Proportional (P) term: Responds to the current error (the difference between the desired state and the actual state). A larger error leads to a larger corrective action.
- Integral (I) term: Accounts for past errors, helping to eliminate steady-state errors (where the drone consistently deviates slightly from the target).
- Derivative (D) term: Predicts future errors based on the rate of change of the current error, dampening oscillations and improving stability.
By continuously calculating and combining these three terms, the PID controller generates precise adjustments to motor speeds, ensuring the drone responds smoothly and accurately to commands or environmental disturbances. This elegant looping mechanism is the unsung hero behind a drone’s ability to hover motionless or execute complex acrobatic maneuvers.
Beyond PID: Advanced Control Architectures
While PID controllers are foundational, modern autonomous drones often employ more sophisticated control architectures, especially for complex tasks. These can include cascaded PID loops (where one PID loop controls another, e.g., an outer position loop feeding into an inner velocity loop, which then feeds into an attitude loop), Model Predictive Control (MPC), and adaptive control systems. These advanced systems still rely on the fundamental principle of the control loop but incorporate more complex models of the drone’s dynamics and environment, allowing for greater robustness, efficiency, and ability to handle non-linear behaviors or external disturbances.
Loops in AI and Machine Learning for Drones
The advent of Artificial Intelligence (AI) and Machine Learning (ML) has profoundly transformed drone capabilities, and loops are central to how these intelligent systems perceive, learn, and act.
Iterative Learning and Optimization
Machine learning algorithms inherently rely on iterative processes. During training, neural networks for tasks like object detection or navigation typically go through thousands or millions of “epochs”—each epoch being an iteration where the model processes the entire training dataset, makes predictions, compares them to actual labels, calculates an error (loss), and then adjusts its internal parameters (weights and biases) to reduce that error. This continuous looping process of prediction, evaluation, and adjustment is how AI models learn and optimize their performance, enabling drones to recognize objects, classify terrain, or understand complex environments.
Perception-Action Loops in AI Follow Mode
AI follow mode, a popular feature in many consumer and professional drones, is a prime example of a tightly integrated perception-action loop.
- Perception: The drone’s camera and vision processing unit continuously capture video frames and identify the target (e.g., a person or vehicle) using object detection algorithms.
- Tracking & State Estimation: The system then tracks the target’s position, velocity, and trajectory relative to the drone.
- Decision-Making: Based on the target’s movement and desired follow parameters (distance, angle), the AI algorithm decides on the optimal flight path and drone maneuvers.
- Actuation: Commands are sent to the flight controller to adjust the drone’s position, speed, and orientation to maintain the follow.
This loop executes in real-time, often at 30-60 frames per second, allowing the drone to seamlessly track and film moving subjects, demonstrating a sophisticated interplay of sensory input, intelligent processing, and precise physical action, all orchestrated through continuous iteration.
Reinforcement Learning: Looping Towards Intelligence
Reinforcement Learning (RL) is a paradigm of AI where an agent (like a drone) learns to make decisions by performing actions in an environment and receiving feedback in the form of rewards or penalties. This learning process is fundamentally cyclical:
- Observe State: The drone perceives its current environment.
- Choose Action: Based on its current policy (learned strategy), it selects an action.
- Perform Action: The drone executes the chosen action.
- Receive Reward/Penalty: The environment provides feedback on the action’s success.
- Update Policy: The drone updates its policy to favor actions that led to rewards and avoid those that led to penalties.
This continuous loop of observation, action, feedback, and policy update allows drones to learn optimal behaviors for complex tasks like navigating unknown terrains, performing intricate maneuvers, or even coordinating with other drones, mimicking a trial-and-error learning process but at machine speed.
Data Processing and Mapping: Iterative Approaches
The vast amounts of data collected by drones for mapping, remote sensing, and inspection require sophisticated iterative processing techniques to transform raw information into actionable insights.
Processing Sensor Data Streams
Drones equipped with various sensors (Lidar, multispectral cameras, thermal imagers) generate continuous streams of data. Processing this data often involves iterative algorithms. For instance, in Simultaneous Localization and Mapping (SLAM), the drone continuously processes new sensor readings (e.g., camera images, LiDAR scans) while simultaneously building a map of its environment and estimating its own position within that map. This is a complex, interleaved loop where mapping improves localization, and better localization refines the map, iteratively converging on an accurate representation.
Building 3D Models and Maps
Creating high-resolution 3D models and precise orthomosaic maps from drone imagery involves extensive iterative computations. Photogrammetry software, for example, uses algorithms that iteratively identify matching features across multiple overlapping images, calculate camera positions and orientations, and then reconstruct the 3D geometry of the scene. This process might involve several passes, refining the initial estimations with each iteration until a dense point cloud or textured mesh model is accurately generated.
Remote Sensing Data Analysis
In remote sensing, drones collect data for applications like agricultural monitoring, environmental surveys, and infrastructure inspection. Analyzing this data often requires iterative statistical methods and machine learning algorithms to extract specific features or patterns. For instance, detecting crop stress from multispectral imagery might involve iteratively classifying pixels based on spectral signatures, refining thresholds, and segmenting regions of interest, cycling through the data to identify anomalies or changes over time.
The Future of Looping Intelligence
As drone technology evolves, the sophistication and autonomy of these “loops” will only increase. Real-time adaptive systems, where drones can adjust their internal models and control strategies on the fly based on observed environmental changes, represent the next frontier. The concept of “human-in-the-loop” operations, where human oversight is maintained, will gradually shift towards fully autonomous “machine-in-the-loop” decision-making for a wider range of applications. Ultimately, the continuous improvement and self-correction offered by increasingly intelligent and complex looping mechanisms will define the future capabilities of drones, enabling them to perform tasks with an unparalleled degree of independence, precision, and efficiency.