
The Core of Aerial Operations: Defining Computer Systems in Flight Technology
At the heart of every modern drone, from compact recreational quadcopters to sophisticated industrial UAVs, lies an intricate network of computer systems. Far more than just processors and memory, these systems represent the seamless integration of specialized hardware and intelligent software, meticulously engineered to facilitate autonomous flight, precise navigation, and real-time operational awareness. In the realm of flight technology, a computer system is the digital brain and nervous system that enables an aerial platform to perceive its environment, make critical decisions, execute complex maneuvers, and communicate effectively, all while maintaining stability and safety.

These specialized computer systems are distinct from general-purpose computers, being highly optimized for the demanding, low-latency, and often safety-critical requirements of aerial operations. They are designed to operate under dynamic conditions, processing vast streams of sensor data, executing complex algorithms, and controlling multiple actuators with unwavering precision and reliability. The efficacy of a drone’s flight performance, its ability to navigate challenging terrains, avoid obstacles, and perform its designated mission, hinges entirely on the sophistication and robustness of its embedded computer systems. Without these digital architects, the advanced capabilities we associate with modern flight technology—from autonomous delivery to aerial mapping—would simply not be possible. They are the unseen heroes, constantly working to interpret, decide, and act, transforming raw data into intelligent flight.
Architectural Backbone: Hardware and Software for Flight Control
The functional essence of computer systems in flight technology is embodied by their tightly interwoven hardware and software architectures. Each component plays a critical role in the overall system’s ability to manage flight dynamics, process sensory input, and execute commands.
Hardware Components: The Physical Infrastructure
The hardware layer provides the physical foundation for all computations and operations. Key components include:
- Flight Controller (FC) / Main Processing Unit (MPU): This is the central processing unit, often a microcontroller (MCU) or a more powerful embedded processor, specifically designed for drone applications. It runs the primary flight control algorithms, interprets commands from the ground station or onboard intelligence, and translates them into control signals for the motors. Its compact size, low power consumption, and high processing capabilities are critical for aerial platforms.
- Inertial Measurement Unit (IMU): A crucial sensor package comprising accelerometers, gyroscopes, and often magnetometers. Accelerometers measure linear acceleration, gyroscopes detect angular velocity (rotational changes), and magnetometers provide heading information relative to the Earth’s magnetic field. The IMU feeds critical data about the drone’s orientation, velocity, and attitude directly to the flight controller, forming the bedrock of stabilization.
- Global Positioning System (GPS) Module: Essential for outdoor navigation, a GPS module receives signals from satellites to determine the drone’s precise latitude, longitude, and altitude. This data is fundamental for waypoint navigation, position hold, and return-to-home functions.
- Barometer: Measures atmospheric pressure to provide highly accurate altitude data, complementing or enhancing GPS altitude readings, especially for maintaining a consistent altitude or during vertical maneuvers.
- Electronic Speed Controllers (ESCs): While not processing units themselves, ESCs are specialized electronic circuits that convert commands from the flight controller into appropriate power signals for the drone’s brushless motors. They are integral to the control loop, directly influencing the thrust and rotation of each propeller.
- Communication Modules: These include radio transceivers for communicating with the remote controller (RC link) and often Wi-Fi or cellular modules for telemetry, data transmission, and advanced command-and-control with ground stations.
Software Components: The Digital Intelligence
The software layer brings the hardware to life, providing the intelligence and logic necessary for autonomous and controlled flight:
- Firmware and Operating System: Low-level software residing on the flight controller that manages hardware resources, interfaces with sensors, and provides a stable environment for higher-level applications. Many flight controllers run specialized real-time operating systems (RTOS) for predictable performance.
- Flight Control Algorithms: These are the sophisticated mathematical routines that take sensor data (from IMU, GPS, barometer), interpret pilot commands, and calculate the precise motor outputs required to achieve the desired flight state (e.g., maintaining level flight, executing a turn, holding position). Proportional-Integral-Derivative (PID) controllers are a classic example, constantly adjusting motor speeds based on error between desired and actual states.
- Sensor Fusion Algorithms: Complex algorithms that combine and filter data from multiple, often redundant, sensors (e.g., GPS, IMU, barometer, optical flow) to produce a more accurate and robust estimation of the drone’s state (position, velocity, attitude) than any single sensor could provide. This enhances reliability and performance, especially in challenging environments where one sensor might be compromised.
- Navigation and Path Planning Software: Higher-level software that uses processed positional data to guide the drone along predefined waypoints, execute search patterns, or dynamically plan routes to avoid detected obstacles.
The symbiotic relationship between these hardware and software elements forms a robust computer system capable of handling the complex demands of aerial robotics, enabling precise control, reliable navigation, and adaptive intelligence in flight.
Navigational Precision: Guiding Drones with Integrated Computing
Accurate navigation is paramount for any aerial vehicle, and computer systems are the architects of this precision. They integrate data from various sources to build a comprehensive understanding of the drone’s position, velocity, and orientation, translating this into actionable flight commands.
Global Positioning System (GPS) and its Enhancement
GPS receivers are a cornerstone of outdoor drone navigation, providing global coordinates (latitude, longitude, altitude). However, raw GPS data can be susceptible to inaccuracies due to atmospheric conditions, satellite availability, or signal reflections (multipath effects), particularly in urban canyons or near large structures. Computer systems mitigate these limitations through:
- Differential GPS (DGPS) and Real-Time Kinematic (RTK)/Post-Processed Kinematic (PPK): These advanced techniques use a stationary ground reference station to transmit correction data to the drone, significantly reducing positional errors to centimeter-level accuracy. The drone’s onboard computer system processes these corrections in real-time (RTK) or after the flight (PPK) to refine its location estimate.
- Integration with GLONASS, Galileo, and BeiDou: Modern computer systems often support multiple Global Navigation Satellite Systems (GNSS) concurrently. By processing signals from a larger constellation of satellites, the system can achieve greater availability, robustness, and accuracy, especially in areas with limited visibility to a single system.
Inertial Measurement Units (IMUs) and Sensor Fusion
While GPS provides absolute position, IMUs offer relative motion data. The drone’s computer system constantly fuses data from accelerometers, gyroscopes, and magnetometers to track minute changes in orientation and movement.
- Attitude and Heading Reference System (AHRS): Through complex sensor fusion algorithms (e.g., Kalman filters, Extended Kalman filters), the computer system combines IMU data with GPS, barometric pressure, and sometimes optical flow sensors to generate a stable, accurate estimate of the drone’s attitude (pitch, roll, yaw), heading, and velocity. This integrated understanding is crucial for smooth flight control and precise maneuvering, especially when GPS signals are weak or unavailable.
- Dead Reckoning: In situations where GPS is completely lost, the computer system can use IMU data to estimate position based on previous known positions and calculated movements. While subject to drift over time, it can provide temporary navigation capabilities.
Flight Path Algorithms and Waypoint Navigation
The ability to follow precise flight paths and execute automated missions relies heavily on sophisticated computer algorithms:
- Waypoint Navigation: Users define a series of geographical points (waypoints), and the computer system calculates the optimal trajectory between them, considering factors like altitude, speed, and turns. The system continuously compares the drone’s current position (derived from fused sensor data) with the planned path and generates control commands to correct any deviations.
- Mission Planning Software: Onboard computer systems interface with ground control station (GCS) software, which allows operators to pre-plan complex missions, define specific actions at waypoints (e.g., hover, take photo, change altitude), and monitor flight progress in real-time. The drone’s computer system autonomously executes these pre-programmed instructions.
- Dynamic Path Planning: More advanced systems can dynamically adjust flight paths in response to environmental changes or newly detected obstacles, ensuring the drone reaches its destination safely and efficiently. This requires real-time data processing and decision-making capabilities within the onboard computer.
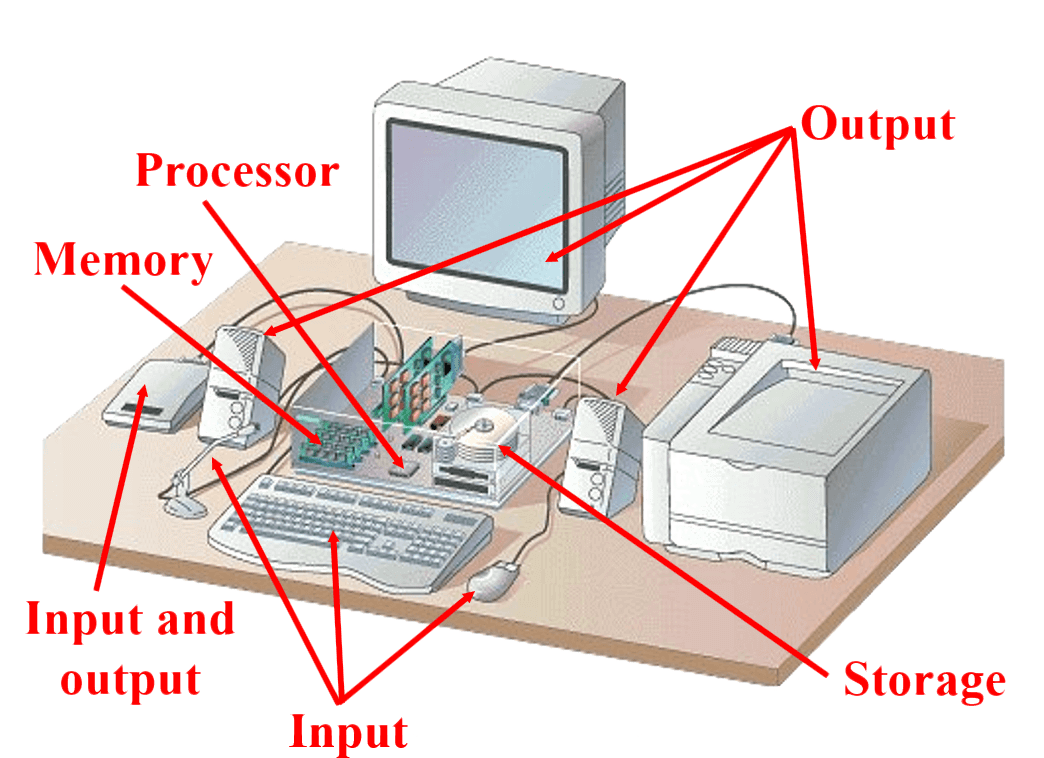
Through this intricate integration of hardware and software, computer systems empower drones with unparalleled navigational precision, enabling them to execute complex missions with reliability and autonomy.
Environmental Perception: Sensors and Real-Time Obstacle Avoidance Systems
A critical function of computer systems in modern flight technology is to enable drones to perceive their surroundings and react intelligently, particularly for obstacle avoidance and safe operation. This relies on an array of sensors and advanced processing capabilities.
Diverse Sensory Input for Comprehensive Awareness
Drones employ various types of sensors, each providing unique data about the environment:
- Optical Cameras (RGB and Stereo Vision): Standard RGB cameras capture visual information. When two or more cameras are used (stereo vision), the computer system can process the images to create a 3D depth map of the environment, crucial for understanding spatial relationships and identifying obstacles.
- Thermal Cameras: Detect infrared radiation, allowing the drone to “see” heat signatures. This is valuable for search and rescue operations, wildlife monitoring, or inspecting infrastructure for heat anomalies, even in low-light conditions.
- Lidar (Light Detection and Ranging): Emits pulsed laser light and measures the time it takes for the light to return. This provides highly accurate 3D point cloud data, creating a detailed map of the environment and precise distances to objects, regardless of ambient light.
- Sonar/Ultrasonic Sensors: Emit sound waves and measure the time for the echo to return. These are effective for short-range distance measurements, particularly useful for precision landing, terrain following, or detecting obstacles close to the drone in environments where optical sensors might struggle (e.g., fog).
- Radar: Uses radio waves to detect objects and measure their range, velocity, and angle. More robust in adverse weather conditions (rain, fog) than optical or Lidar sensors, radar is increasingly being integrated for longer-range obstacle detection.
Real-Time Data Processing and Object Recognition
The sheer volume of data generated by these sensors requires robust processing capabilities within the drone’s computer system.
- Dedicated Processors: Many advanced drones incorporate specialized processors, such as Graphics Processing Units (GPUs) or Neural Processing Units (NPUs), specifically designed for high-speed image and point cloud processing. These units excel at parallel computing, making them ideal for running complex algorithms for object recognition and environmental mapping.
- Algorithms for Object Detection and Classification: Software algorithms leverage machine learning and computer vision techniques to analyze sensor data. They identify objects (e.g., trees, buildings, power lines, other aircraft), classify them, and track their movement. This enables the drone to differentiate between static obstacles and moving elements in its flight path.
- Simultaneous Localization and Mapping (SLAM): For drones operating in GPS-denied environments (indoors, dense forests), SLAM algorithms allow the computer system to simultaneously build a map of an unknown environment while tracking the drone’s own location within that map using sensor data (e.g., visual odometry from cameras, Lidar scans).
Proactive Obstacle Avoidance and Collision Detection
Based on the processed environmental data, the computer system makes real-time decisions to prevent collisions.
- Predictive Modeling: The system uses collected data to build a dynamic 3D model of the drone’s immediate surroundings. It then projects the drone’s intended flight path against this model to identify potential collision points.
- Path Re-planning: If a collision threat is detected, the computer system autonomously calculates and executes an alternative flight path, either by altering the drone’s trajectory (e.g., flying around, over, or under the obstacle) or by initiating a controlled stop or hover.
- Multi-sensor Fusion for Redundancy: By fusing data from multiple sensor types (e.g., Lidar for distance, stereo cameras for object classification), the system gains a more robust and reliable understanding of its environment, reducing the chance of false positives or missed obstacles. This redundancy is critical for safety-of-flight operations.
Through these integrated sensory and computational systems, drones can navigate complex environments with unprecedented safety and autonomy, adapting to unforeseen circumstances and protecting both the aircraft and its surroundings.
Stabilization and Control: The Dynamic Role of Flight Computers
The hallmark of a well-engineered drone is its inherent stability and responsive control, even in challenging atmospheric conditions. This is meticulously managed by the drone’s flight computer system, which acts as the ultimate arbiter of dynamic flight.
The Feedback Loop: Sensing, Processing, Actuating
At its core, drone stabilization is a continuous, high-frequency feedback loop managed by the flight computer:
- Sensing (Input): The IMU (accelerometers, gyroscopes), barometer, GPS, and other positional sensors constantly feed data to the flight controller, providing real-time information about the drone’s attitude, velocity, position, and external forces acting upon it.
- Processing (Computation): The flight controller’s CPU, running its sophisticated flight control algorithms, ingests this sensor data. It compares the drone’s current state with the desired state (e.g., hovering level, moving forward at a specific speed, executing a turn as commanded by the pilot or autonomous mission).
- Actuating (Output): Based on the calculated “error” between the actual and desired states, the flight computer generates precise control signals. These signals are sent to the Electronic Speed Controllers (ESCs), which in turn adjust the rotational speed of each motor. By subtly increasing or decreasing the thrust of individual propellers, the drone can be precisely tilted, moved, or stabilized.
This entire loop occurs hundreds, if not thousands, of times per second, allowing the drone to react almost instantaneously to disturbances like wind gusts or pilot inputs, maintaining a remarkably stable platform.
PID Control and Advanced Algorithms
The fundamental algorithm driving this feedback loop is often a variant of the Proportional-Integral-Derivative (PID) controller.
- Proportional (P): Reacts to the current error, providing an immediate correction proportional to the deviation.
- Integral (I): Addresses accumulated past errors, eliminating steady-state offsets (drift).
- Derivative (D): Anticipates future errors based on the rate of change of the current error, damping oscillations and improving responsiveness.
Modern flight computers often employ more advanced control algorithms that build upon or augment PID control. These may include model predictive control, adaptive control, or robust control techniques, which can better handle complex aerodynamic interactions, varying payloads, and unexpected disturbances. These algorithms are computationally intensive, requiring significant processing power and optimized software to execute within the strict real-time constraints of flight.

Thrust Vectoring and Redundancy Management
Beyond basic attitude control, flight computers are responsible for more nuanced aspects of performance:
- Thrust Vectoring for Maneuverability: In multi-rotor drones, the flight computer dynamically adjusts the thrust of each motor to create a combined resultant force vector that controls the drone’s movement and attitude. This precise thrust vectoring is key to the agile and versatile flight capabilities of drones.
- Power Management and Efficiency: The computer system constantly monitors battery voltage, current draw, and motor temperatures. It can optimize motor commands to enhance flight efficiency, extend endurance, or trigger emergency landing protocols if power reserves become critically low.
- Redundancy and Failsafe Mechanisms: For enhanced reliability, especially in professional and industrial drones, computer systems often incorporate redundancy. This can involve multiple flight controllers, redundant sensors, or power systems. The main flight computer is programmed with sophisticated failsafe logic to handle component failures (e.g., motor failure) by attempting to stabilize the drone with remaining operational components or initiating an emergency landing procedure. This also includes “return-to-home” functions triggered by loss of signal or low battery, autonomously guiding the drone back to a predefined safe location.
The continuous, intelligent operation of these computer systems ensures that drones are not merely flying machines but sophisticated, stable, and controllable aerial platforms capable of executing complex tasks with precision and reliability.