
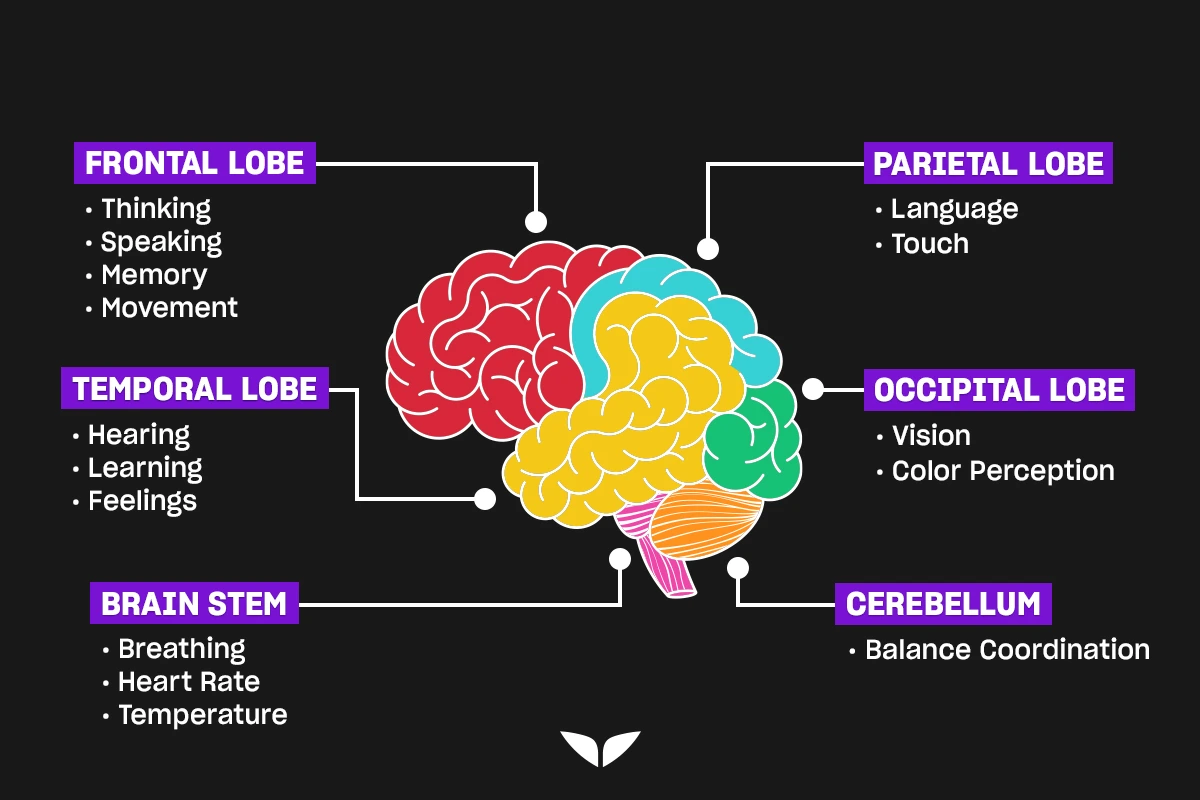
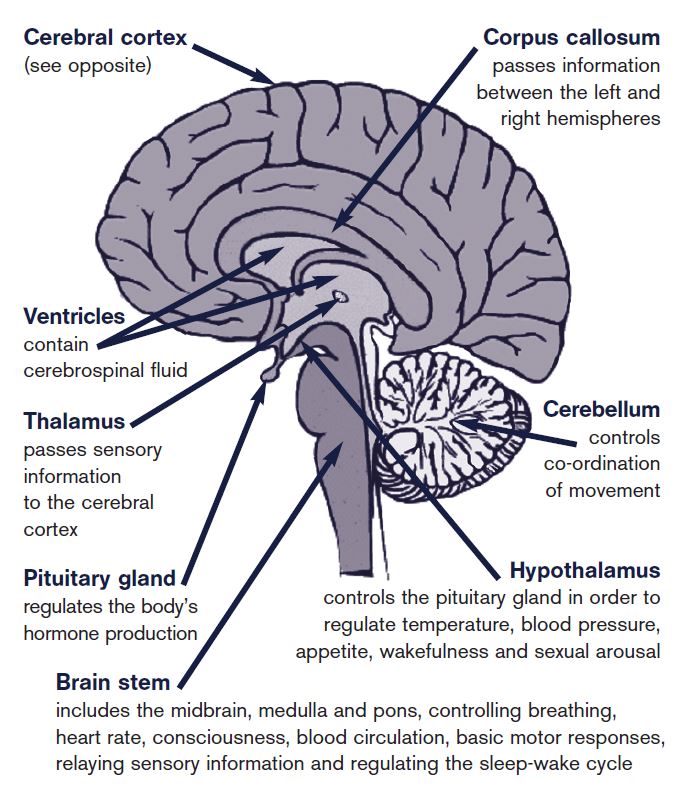
In the intricate world of unmanned aerial vehicles (UAVs), commonly known as drones, the concept of a “brain” is not biological but rather a sophisticated ensemble of interconnected technologies that govern flight, navigation, and mission execution. Just as the human brain orchestrates complex movements and sensory processing, a drone’s flight control system acts as its central nervous system, integrating data from various sensors, processing commands, and issuing instructions to propulsion and stabilization mechanisms. Understanding these “parts of the brain” is crucial to appreciating the sophisticated engineering behind modern flight technology, from recreational quadcopters to advanced industrial UAVs.
The Central Nervous System: The Flight Controller Unit (FCU)
At the core of every drone’s “brain” is the Flight Controller Unit (FCU). This compact circuit board is the command center, the equivalent of a human brain’s cerebrum, responsible for interpreting pilot inputs, analyzing sensor data, and sending precise commands to the motors to maintain stable flight or execute maneuvers. The FCU is a marvel of miniaturized computing, housing microcontrollers, memory, and various input/output interfaces. Its primary function is to execute the flight control software, which is the “intelligence” that translates raw data into actionable flight directives.
Microcontrollers and Processors
The computational horsepower of the FCU comes from its microcontrollers and dedicated processors. These chips are optimized for real-time processing, crucial for maintaining dynamic stability in a constantly changing aerial environment. They execute millions of calculations per second, integrating data from gyroscopes, accelerometers, magnetometers, and barometers. Advanced FCUs may incorporate more powerful multi-core processors, enabling complex algorithms for autonomous flight, object recognition, and sophisticated path planning. The choice of microcontroller significantly impacts the drone’s responsiveness, the complexity of the flight modes it can support, and its overall performance envelope.
Firmware and Operating Systems
The FCU is only as intelligent as the software it runs. This software, often referred to as firmware, is the drone’s operating system. It defines how the drone interprets commands, processes sensor data, and controls its motors. Open-source firmware like ArduPilot and Betaflight, or proprietary systems developed by manufacturers, provide the algorithms for stabilization (e.g., PID controllers), navigation (e.g., GPS waypoint following), and various flight modes (e.g., altitude hold, position hold, acrobatic mode). Regular updates to this firmware introduce new features, improve stability, and enhance safety, demonstrating the evolving intelligence of the drone’s “brain.” The efficiency and robustness of this firmware are paramount for predictable and reliable flight operations.
Sensory Input: The Eyes and Ears of the Drone
For the FCU to make informed decisions, it requires a constant stream of accurate environmental data. This data is gathered by an array of sophisticated sensors, acting as the drone’s “eyes” and “ears,” providing critical feedback on its orientation, position, altitude, and surrounding environment. Without these sensory inputs, the FCU would be blind and unable to control the drone effectively.
Inertial Measurement Units (IMUs): Accelerometers and Gyroscopes
The foundational elements of a drone’s sensory system are its Inertial Measurement Units (IMUs). An IMU typically comprises accelerometers and gyroscopes. Accelerometers measure linear acceleration along three axes (X, Y, Z), detecting changes in speed and gravitational forces. Gyroscopes, on the other hand, measure angular velocity, providing data on the drone’s rotation around its pitch, roll, and yaw axes. By fusing the data from these two types of sensors, the FCU can determine the drone’s precise orientation and how it’s tilting or turning in space. This real-time orientation data is absolutely critical for stabilization, ensuring the drone remains level and responsive to control inputs. Without accurate IMU data, stable flight would be impossible.
Global Navigation Satellite Systems (GNSS): GPS, GLONASS, Galileo
To know its position in the world, drones rely on Global Navigation Satellite Systems (GNSS) receivers, with GPS (Global Positioning System) being the most common. These receivers triangulate the drone’s position by receiving signals from multiple orbiting satellites, providing precise latitude, longitude, and altitude data. More advanced drones may integrate multiple GNSS constellations like GLONASS, Galileo, and BeiDou for improved accuracy and reliability, especially in challenging environments where satellite visibility might be limited. GNSS data is essential for features like position hold, waypoint navigation, automated flight paths, and return-to-home functions, allowing the drone’s “brain” to understand its location and navigate autonomously.
Barometers and Magnetometers
Altitude control and heading are further refined by barometers and magnetometers. A barometer measures atmospheric pressure, which correlates directly with altitude. This allows the drone to maintain a stable height above ground, critical for consistent aerial photography or mapping missions. Magnetometers, also known as electronic compasses, detect the Earth’s magnetic field, providing the drone with its absolute heading (north, south, east, west). While GNSS provides relative bearing, a magnetometer offers a true magnetic heading, correcting for drift and ensuring the drone maintains its intended direction, particularly important for precise flight paths and orientation-dependent tasks.

Vision Systems and Ultrasonic Sensors
For closer-range awareness and advanced functionalities, many modern drones incorporate vision systems and ultrasonic sensors. Vision systems, often consisting of downward-facing optical flow cameras, help with precise hovering by tracking patterns on the ground. These are especially useful indoors or in environments where GNSS signals are weak or unavailable. Ultrasonic sensors emit sound waves and measure the time it takes for them to bounce back, providing accurate proximity data to objects below or around the drone. This technology is vital for features like automatic landing assistance, terrain following, and rudimentary obstacle avoidance, allowing the drone’s “brain” to “see” and react to its immediate environment. Lidar systems offer even more sophisticated 3D environmental mapping for highly advanced obstacle avoidance and autonomous navigation.
Command Execution: Motor Control and Actuation
Once the FCU has processed sensory data and determined the necessary actions, it must translate these decisions into physical movement. This involves precise control over the drone’s motors and propellers, the limbs and muscles of the aerial system. The efficiency and responsiveness of this command execution pathway are paramount for agile and stable flight.
Electronic Speed Controllers (ESCs)
The FCU communicates its commands to the motors via Electronic Speed Controllers (ESCs). Each motor on a multirotor drone typically has its own ESC. These devices take the low-voltage control signals from the FCU and convert them into higher-power signals to drive the brushless DC motors. ESCs regulate the speed and direction of each motor independently and with extreme precision. They are crucial for rapid changes in thrust needed for stabilization, maneuvering, and altitude adjustments. High-quality ESCs feature fast response times and efficient power delivery, minimizing latency between the FCU’s decision and the motor’s reaction, which is critical for smooth and stable flight, especially during aggressive maneuvers or in windy conditions.
Propellers and Motors
The ultimate actuators of a drone’s flight are its motors and propellers. Brushless DC motors are preferred for their efficiency, power-to-weight ratio, and reliability. The FCU, via the ESCs, dictates the rotational speed of these motors. Propellers convert this rotational motion into thrust, generating lift. By varying the speed of individual motors, the drone can control its pitch, roll, yaw, and overall thrust. For instance, to move forward, the FCU might slightly decrease the speed of the front motors and increase the speed of the rear motors, causing the drone to tilt forward. The precise synchronization and independent control of these motor-propeller combinations are the physical manifestation of the drone’s “brain” orchestrating its movement in three-dimensional space.
The Intelligence Layer: Navigation and Stabilization Algorithms
Beyond merely processing inputs and controlling outputs, the “brain” of a drone contains a sophisticated layer of intelligence in the form of algorithms. These mathematical models and computational procedures are what truly enable the drone to understand its environment, maintain stability, and execute complex flight missions, moving it beyond a simple remote-controlled toy to an autonomous aerial platform.
PID Controllers for Stability
The backbone of almost all drone stabilization systems is the Proportional-Integral-Derivative (PID) controller. This algorithm constantly analyzes the difference between the drone’s desired state (set by the pilot or autonomous system) and its actual state (reported by the IMU). The “Proportional” term responds to the current error, the “Integral” term accumulates past errors to eliminate steady-state offset, and the “Derivative” term anticipates future errors based on the rate of change. By meticulously tuning the ‘P’, ‘I’, and ‘D’ gains for pitch, roll, and yaw axes, the FCU can counteract external disturbances (like wind) and maintain stable, level flight or execute smooth, controlled maneuvers. PID controllers are a fundamental component, constantly working in the background to keep the drone airborne and responsive.
Waypoint Navigation and Path Planning
For autonomous missions, the drone’s “brain” utilizes algorithms for waypoint navigation and path planning. Waypoint navigation involves providing the drone with a series of geographical coordinates (waypoints) that it must follow in a specific sequence. The FCU, using GNSS data and its internal map of the mission, calculates the optimal trajectory between these points, factoring in desired altitude, speed, and any programmed actions at each waypoint. More advanced path planning algorithms can dynamically generate or modify flight paths in real-time to optimize for factors like efficiency, battery life, sensor coverage, or to avoid known no-fly zones and dynamic obstacles. These algorithms represent a significant leap in drone autonomy, allowing complex missions to be executed with minimal human intervention.
Obstacle Avoidance Protocols
One of the most critical aspects of advanced drone flight technology is obstacle avoidance. This “brain” function relies on data from various sensors—vision systems, ultrasonic, lidar, and even radar—to detect objects in the drone’s flight path. Obstacle avoidance protocols then use sophisticated algorithms to process this sensor data in real-time, identify potential collisions, and automatically generate alternative flight paths or initiate braking maneuvers to prevent an impact. These algorithms often employ techniques like Kalman filters for sensor data fusion, machine learning for object recognition, and predictive modeling to anticipate object movement. The continuous improvement of these protocols enhances safety, opens up new operational possibilities in complex environments, and moves drones closer to true autonomous decision-making capabilities.
In summary, the “parts of the brain” that control a drone are a synergistic blend of hardware and software. From the processing power of the FCU and its sophisticated firmware to the array of sensors that feed it environmental data, and the precise motor control systems that act upon its decisions, every component plays a vital role. The intelligence layer, with its stabilization, navigation, and obstacle avoidance algorithms, orchestrates these elements, transforming raw data into graceful, controlled flight. As flight technology continues to evolve, these “brains” will only become more integrated, autonomous, and capable, pushing the boundaries of what UAVs can achieve.