
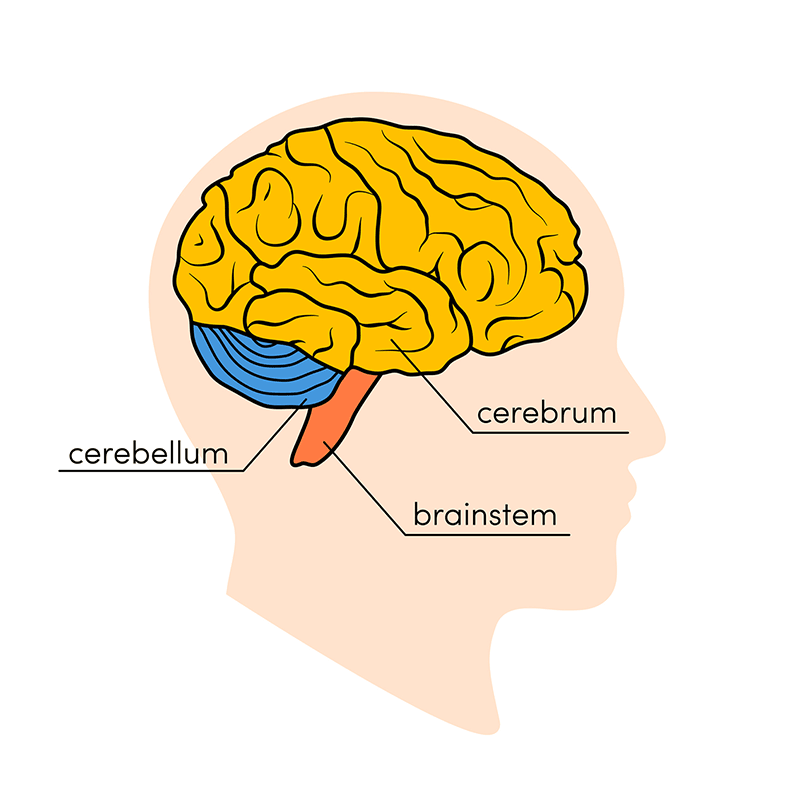
In the rapidly evolving landscape of autonomous aerial systems, particularly advanced drones and UAVs, the concept of a “brain” is not merely metaphorical but a functional blueprint for sophisticated operation. When deconstructing the intricate architecture of these intelligent flying platforms, their operational core can be conceptualized into three fundamental, interconnected parts: perception, processing, and actuation. These components work in concert, mirroring the complex integrated functions observed in biological systems, to enable capabilities ranging from AI follow mode and autonomous flight to precision mapping and remote sensing. Understanding these distinct yet interdependent elements is crucial for appreciating the technological prowess behind modern aerial robotics and anticipating future innovations in drone intelligence and autonomy.
The Sensory Cortex: Perception and Data Acquisition
The first critical “part of the brain” for any autonomous aerial system lies in its ability to perceive and interact with its environment. This sensory cortex is composed of an array of sophisticated sensors designed to gather real-time data, transforming raw physical inputs into actionable digital information. Without accurate and comprehensive perception, a drone cannot understand its surroundings, navigate effectively, or execute complex tasks.
Advanced Sensor Arrays
Modern drones are equipped with an impressive suite of sensors that mimic and often exceed human sensory capabilities. High-resolution optical cameras, capable of capturing 4K video and high-fidelity still images, serve as the primary visual input, enabling object detection, identification, and tracking. Complementing optical sensors are thermal cameras, which detect heat signatures, invaluable for search and rescue operations, industrial inspections, and wildlife monitoring, especially in low-light conditions. LiDAR (Light Detection and Ranging) systems emit laser pulses to measure distances and create highly detailed 3D maps of environments, offering unparalleled accuracy for terrain modeling and obstacle avoidance. Radar sensors provide robust performance in challenging weather conditions, penetrating fog, rain, and smoke to detect larger objects and provide velocity information. Additionally, ultrasonic sensors offer short-range proximity detection, crucial for precise landings and close-quarter maneuvers.
Environmental Mapping and SLAM
Beyond individual sensor readings, the drone’s brain must integrate these inputs to construct a coherent understanding of its environment. This is achieved through sophisticated environmental mapping techniques. Simultaneous Localization and Mapping (SLAM) algorithms are central to this process. SLAM allows a drone to build a map of an unknown environment while simultaneously determining its own position within that map. This capability is vital for autonomous navigation in complex or GPS-denied environments, such as indoor inspections or dense urban areas. By continuously updating its understanding of the space around it, the drone creates a dynamic spatial model, populating it with detected obstacles, points of interest, and navigational waypoints. This creates a rich, digital representation of the world, serving as the foundational data for subsequent decision-making processes.
Data Filtering and Pre-processing
The sheer volume of data collected by these sensor arrays can be overwhelming. Therefore, an essential function of the perception system is data filtering and pre-processing. Raw sensor data often contains noise, redundancies, or irrelevant information that needs to be refined before being passed to the processing unit. Algorithms are employed to denoise images, filter out sensor anomalies, synchronize data streams from multiple sources, and perform initial feature extraction. For instance, edge detection algorithms might highlight structural boundaries from optical images, while point cloud filtering can simplify complex LiDAR data without losing critical information. This pre-processing step optimizes the data flow, ensuring that the central processing unit receives clean, concise, and relevant information, thereby enhancing computational efficiency and accuracy for subsequent decision-making.
The Cerebellum of Computation: Processing and Decision-Making
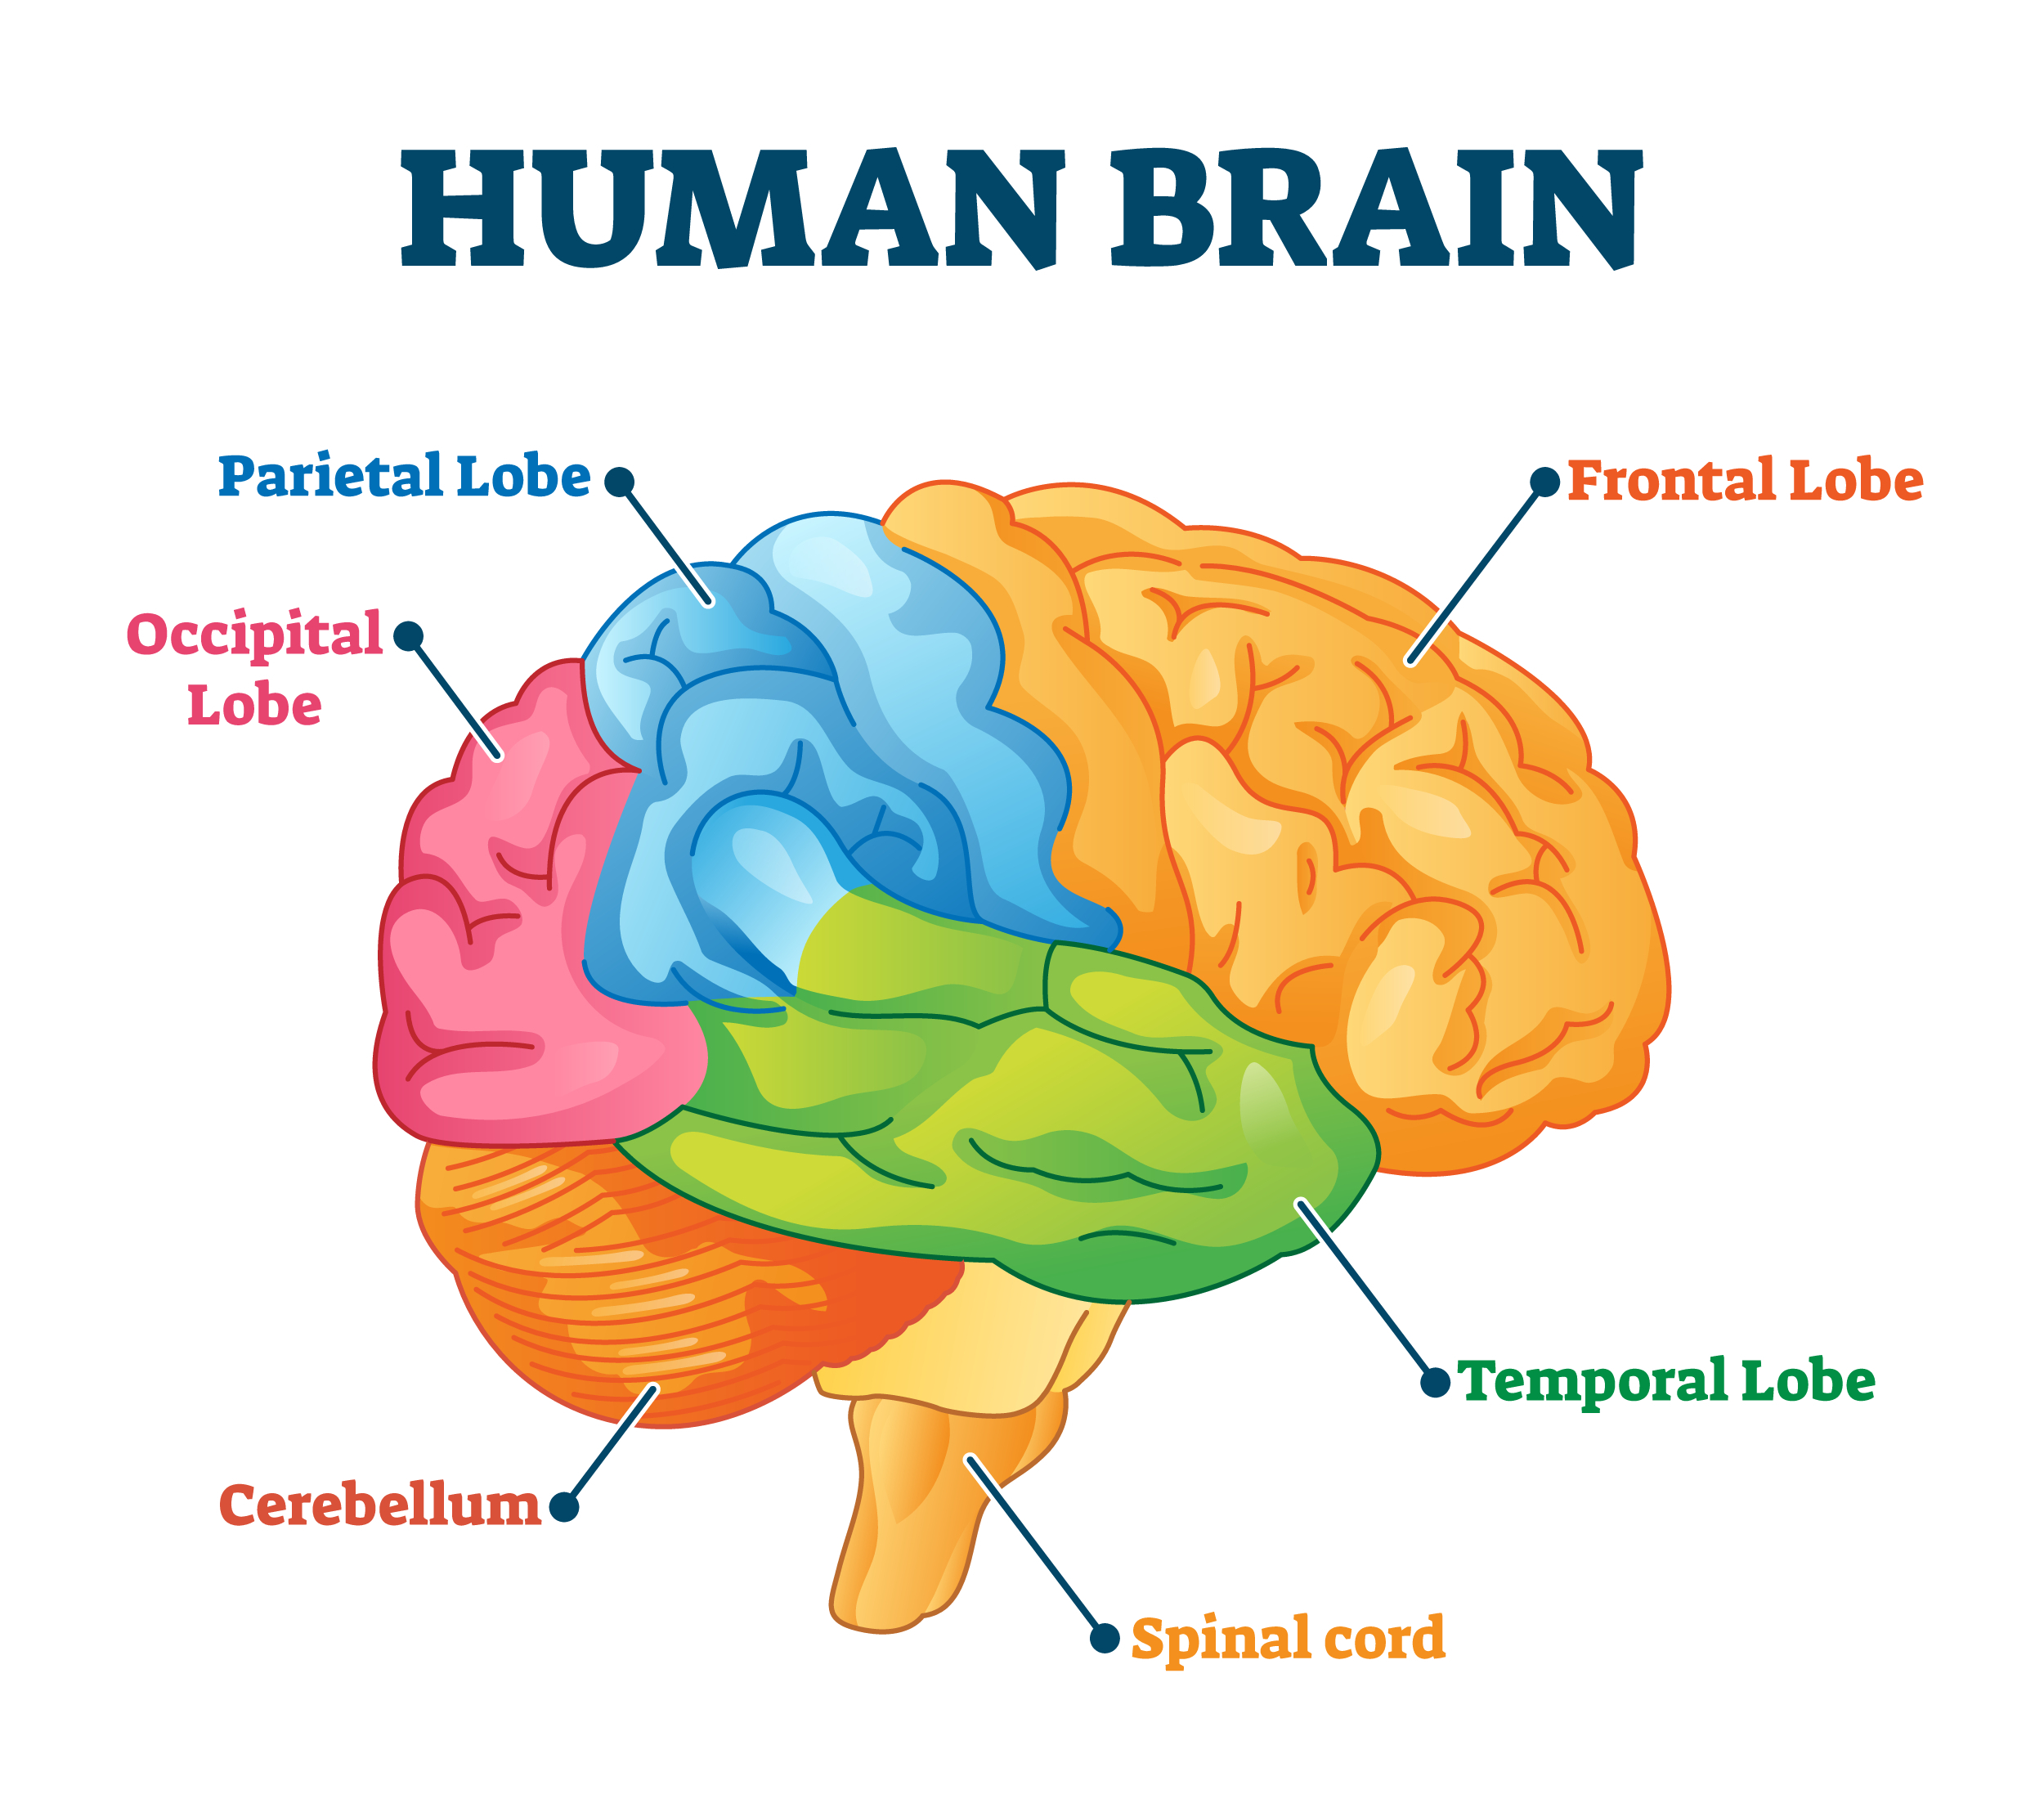
Once sensory data is acquired and pre-processed, the second main “part of the brain” takes over: the central processing unit. This is where the drone “thinks,” analyzes information, and makes critical decisions regarding its flight path, mission objectives, and responses to environmental changes. This computational core represents the intelligence of the autonomous system.
Onboard Flight Controllers and Microprocessors
At the heart of the processing unit are powerful onboard flight controllers and microprocessors. These specialized computers are engineered for real-time operation, executing complex algorithms at extremely high speeds. The flight controller acts as the central nervous system, managing everything from basic flight stability (maintaining level flight, altitude, and heading) to advanced navigation and mission planning. Modern flight controllers often feature multiple core processors and dedicated graphics processing units (GPUs) to handle parallel computations, essential for tasks like real-time video analysis and complex pathfinding. Their architecture is designed for fault tolerance and redundancy, ensuring continued operation even if minor component failures occur, a critical safety feature for autonomous platforms.
AI and Machine Learning Algorithms
The true intelligence of an autonomous drone emerges from its integrated AI and machine learning (ML) algorithms. These algorithms enable the drone to learn from data, recognize patterns, and make intelligent decisions beyond pre-programmed instructions. Object recognition algorithms, for example, allow drones to identify specific targets, whether it’s a person in a search and rescue scenario or a defect on an inspection subject. Predictive analytics can forecast potential obstacles or changes in flight conditions, allowing the drone to adjust its trajectory proactively. AI follow mode relies on deep learning models to track moving subjects smoothly, anticipating their movements and maintaining optimal framing. For mapping and remote sensing, ML algorithms can autonomously classify terrain features, identify crop health anomalies, or detect changes over time, turning raw sensor data into meaningful insights without human intervention.
Real-time Data Fusion and Cognitive Mapping
The processing unit is responsible for real-time data fusion, where information from disparate sensors is combined to create a more robust and comprehensive understanding than any single sensor could provide. For instance, combining LiDAR data with optical imagery can create photorealistic 3D models with precise spatial accuracy. This fused data contributes to the drone’s “cognitive map”—a dynamic, internal representation of the environment that includes not only physical obstacles but also semantic information (e.g., “this is a building,” “this is a road,” “this is a person”). This cognitive map is continuously updated and refined, serving as the basis for sophisticated path planning, obstacle avoidance, and mission execution. The ability to interpret and integrate diverse data streams in real-time is what allows for truly autonomous and adaptive behavior in dynamic environments.
The Motor Cortex: Actuation and Mission Execution
The third primary “part of the brain” focuses on transforming the decisions made by the processing unit into physical actions. This actuation system is responsible for the drone’s physical movement, control over its payload, and the execution of its programmed or autonomous mission objectives. It is the effector arm of the aerial system’s intelligence.
Precision Navigation and Control Systems
The core of the actuation system is the drone’s precision navigation and control systems. This includes the electronic speed controllers (ESCs) that regulate power to the motors, dictating propeller speed and direction to achieve thrust, lift, and yaw. High-performance gyroscopes and accelerometers, often integrated into the flight controller, provide precise attitude and position data, feeding back into a closed-loop control system. This feedback loop continuously compares the drone’s actual state to its desired state and makes micro-adjustments hundreds or thousands of times per second. This enables stable hovering, smooth transitions, and precise waypoint navigation. Advanced control algorithms allow for complex maneuvers, such as tight turns, rapid ascents, and controlled descents, essential for intricate aerial filmmaking or industrial inspection in constrained spaces.
Dynamic Obstacle Avoidance and Adaptive Flight Paths
A key function of the actuation system, driven by the processing unit’s decisions, is dynamic obstacle avoidance. Utilizing the cognitive map derived from fused sensor data, the drone can identify potential collisions in real-time. Sophisticated algorithms then calculate and execute evasive maneuvers, autonomously adjusting the flight path to circumnavigate obstacles while maintaining mission objectives. This capability is paramount for safe autonomous flight, especially in complex environments with unpredictable elements like moving vehicles or changing vegetation. Adaptive flight paths mean the drone isn’t rigidly adhering to a pre-programmed route but is constantly optimizing its trajectory based on current environmental conditions and mission priorities, showcasing a high degree of autonomy and responsiveness.
Automated Task Performance
Beyond mere flight, the actuation system extends to the control of various payloads and the execution of automated tasks. For aerial filmmaking, this includes precise control over gimbal-stabilized cameras, adjusting pan, tilt, and roll to capture cinematic shots according to pre-programmed flight paths or real-time AI directives. For mapping missions, the actuation system ensures the drone flies specific grid patterns at precise altitudes and speeds to capture overlapping imagery for photogrammetry. In industrial inspection, it guides the drone to specific points of interest, maintaining optimal standoff distance for thermal or optical analysis. For remote sensing, it can deploy sensors or samplers and execute specific data collection routines. These automated task performances represent the culmination of perception and processing, translated into tangible, purposeful actions that define the drone’s utility.
The Interconnected Neural Network: Seamless Integration
While these three parts—perception, processing, and actuation—are distinct in their primary functions, their true power lies in their seamless, continuous integration. They form an interconnected neural network, constantly exchanging data and feedback to achieve comprehensive situational awareness and intelligent behavior.
Communication Protocols and Telemetry
The efficient operation of this “brain” relies heavily on robust communication protocols and telemetry systems. Internal communication within the drone ensures that sensor data flows to the processor, and control commands flow to the actuators without latency. External communication, via radio links or cellular networks, allows for human oversight, real-time data transmission to ground stations, and mission updates. Encrypted, high-bandwidth telemetry streams convey crucial flight parameters, system health, and payload data, providing operators with a comprehensive understanding of the drone’s status and performance.
Human-Machine Interface and Operator Oversight
Even with advanced autonomy, human-machine interface (HMI) remains a vital component, allowing operators to set mission parameters, monitor progress, intervene in emergencies, or take manual control when necessary. Intuitive ground control stations (GCS) with real-time mapping, video feeds, and customizable controls provide a window into the drone’s “mind.” This blended autonomy, where human intelligence can guide or override machine intelligence, offers the optimal balance of efficiency, safety, and adaptability, crucial for complex operations.
Future Directions: Swarm Intelligence and Fully Autonomous Ecosystems
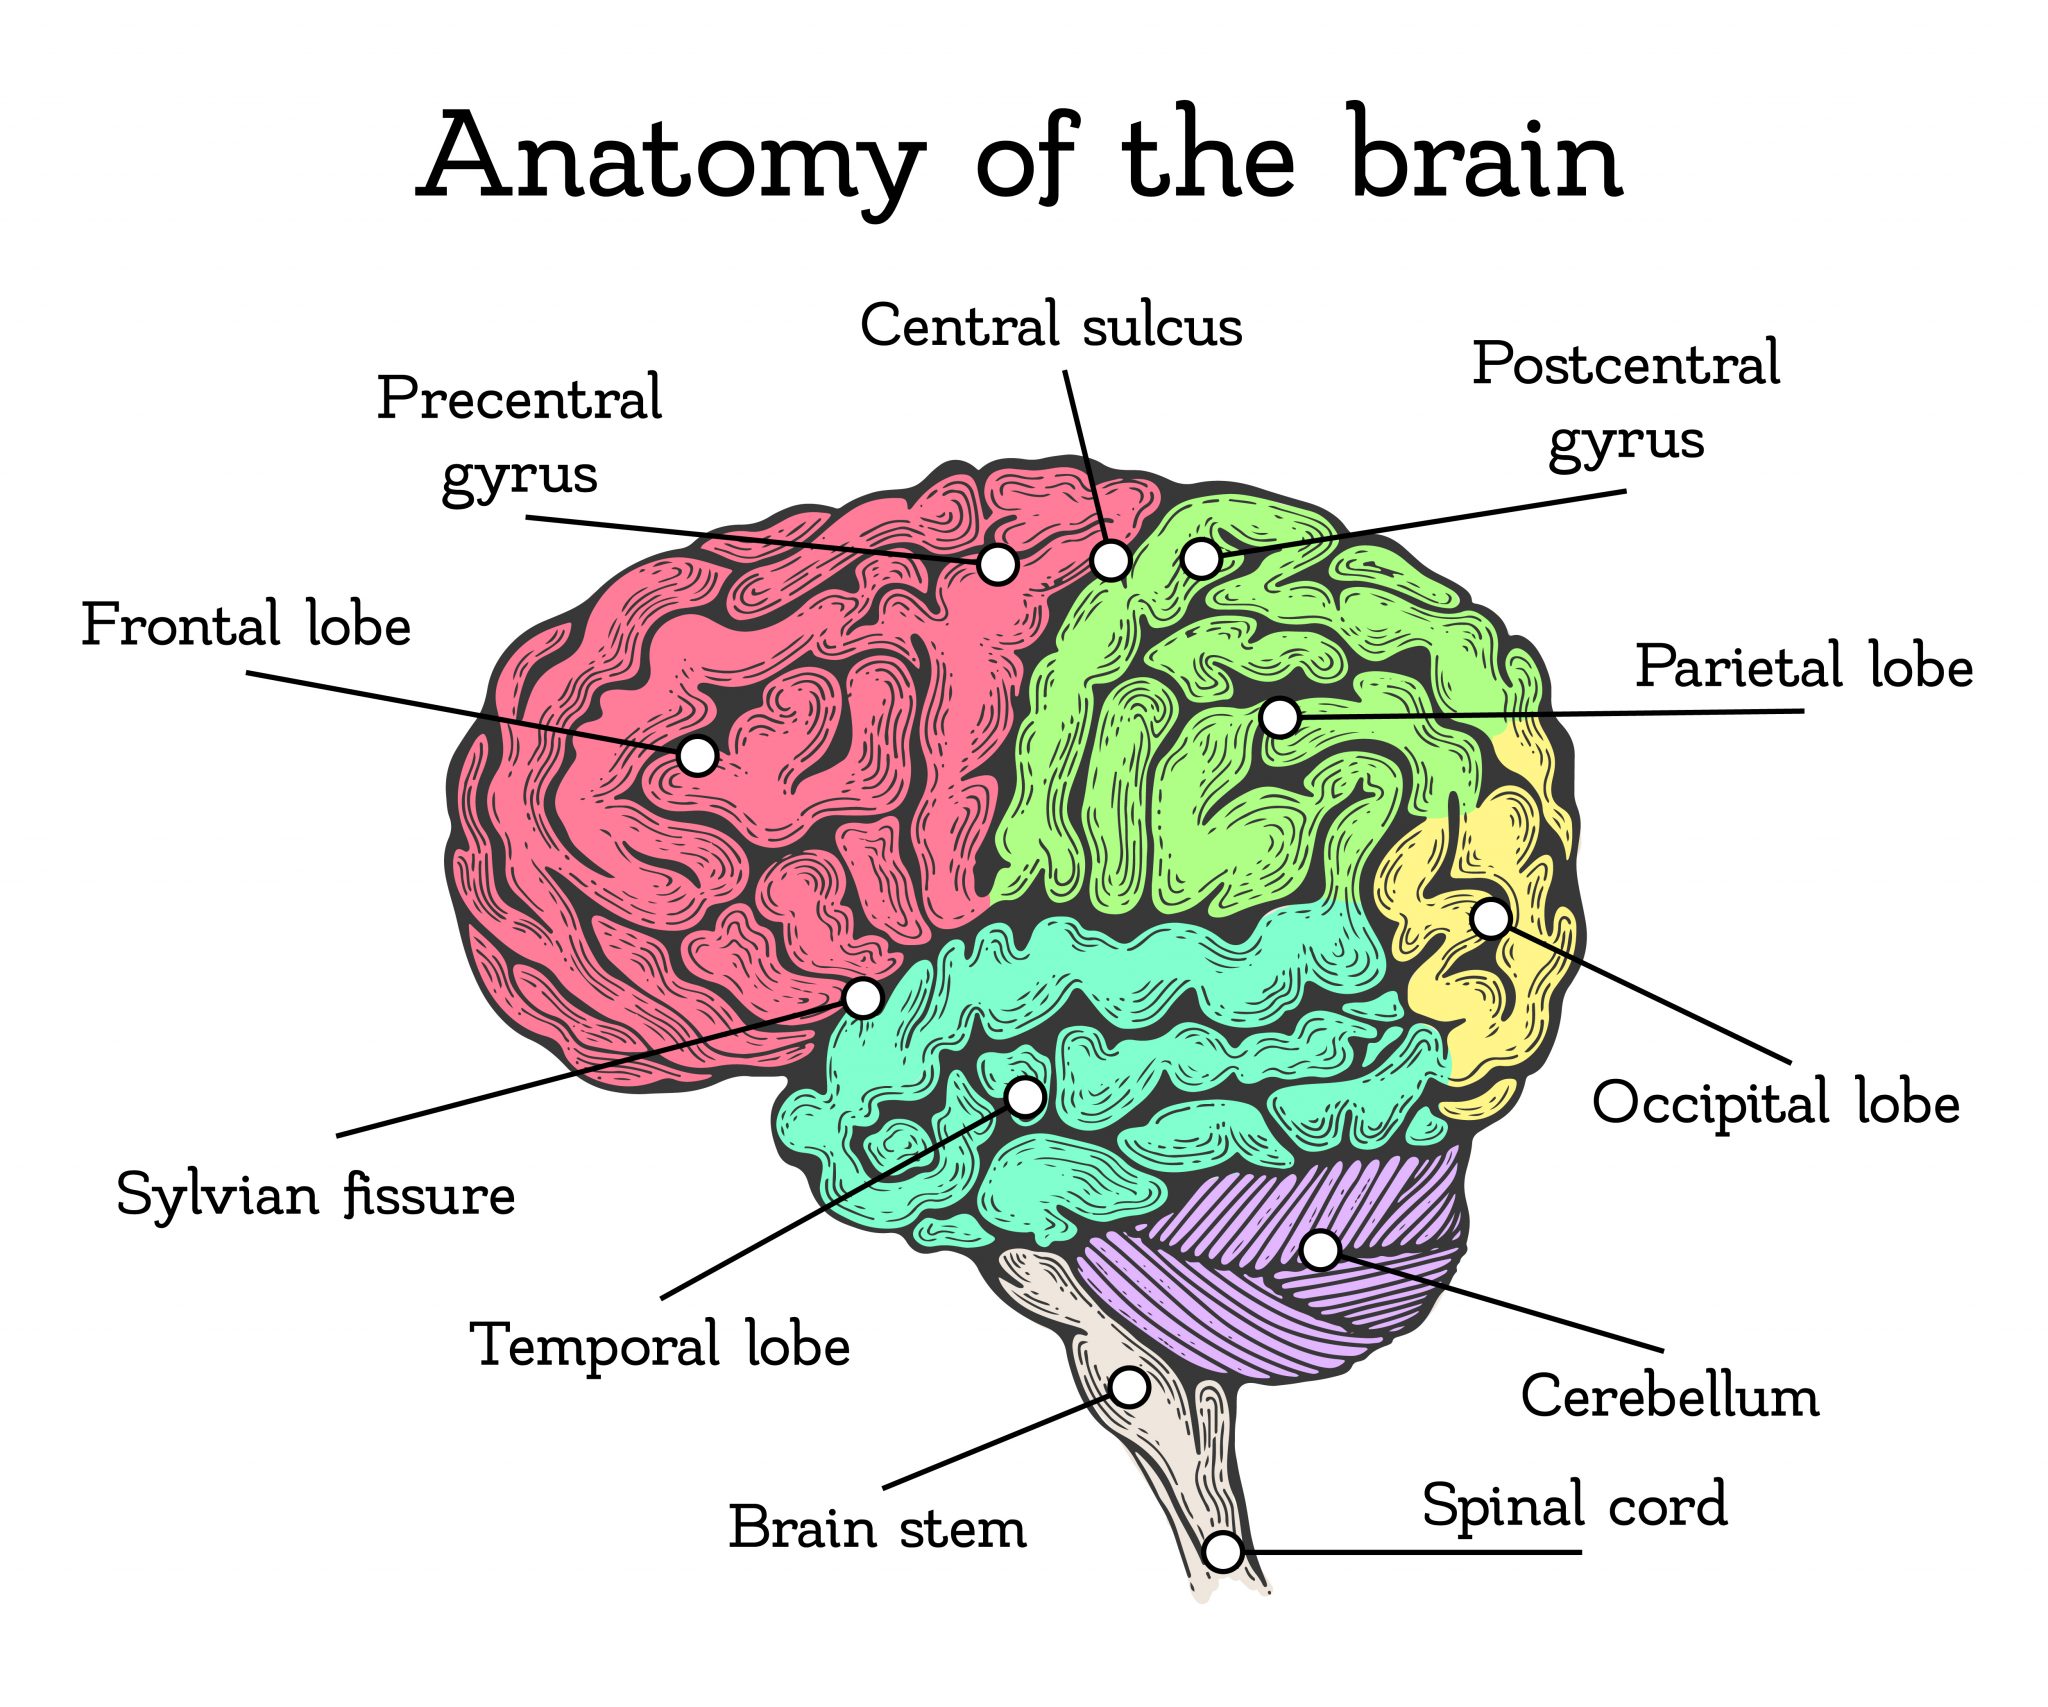
Looking ahead, the evolution of these three brain parts points towards even greater sophistication. Future autonomous aerial systems will likely feature enhanced perception through hyperspectral imaging and quantum sensors, processing capabilities leveraging neuromorphic computing and federated AI, and actuation systems enabling greater agility and energy efficiency. The ultimate frontier lies in swarm intelligence, where multiple drones act as a single, coordinated “super-brain,” sharing perceived data, distributing processing loads, and executing synchronized actuation for complex, large-scale missions like environmental monitoring of vast areas or rapid disaster response. These fully autonomous ecosystems represent the logical evolution of the three main parts of the brain in the realm of aerial robotics, promising transformative impacts across countless industries.